Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • MAVSDK

    Unsolved
    2
    0 Votes
    2 Posts
    399 Views
    modaltbM
    On VOXL1, we've done this via a Docker image. The image might be a bit out of date, but the idea remains the same: https://gitlab.com/voxl-public/voxl-docker-images/voxl-docker-mavsdk-cpp
  • How to convert voxl map files ESDF and TSDF to other format

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    KenK
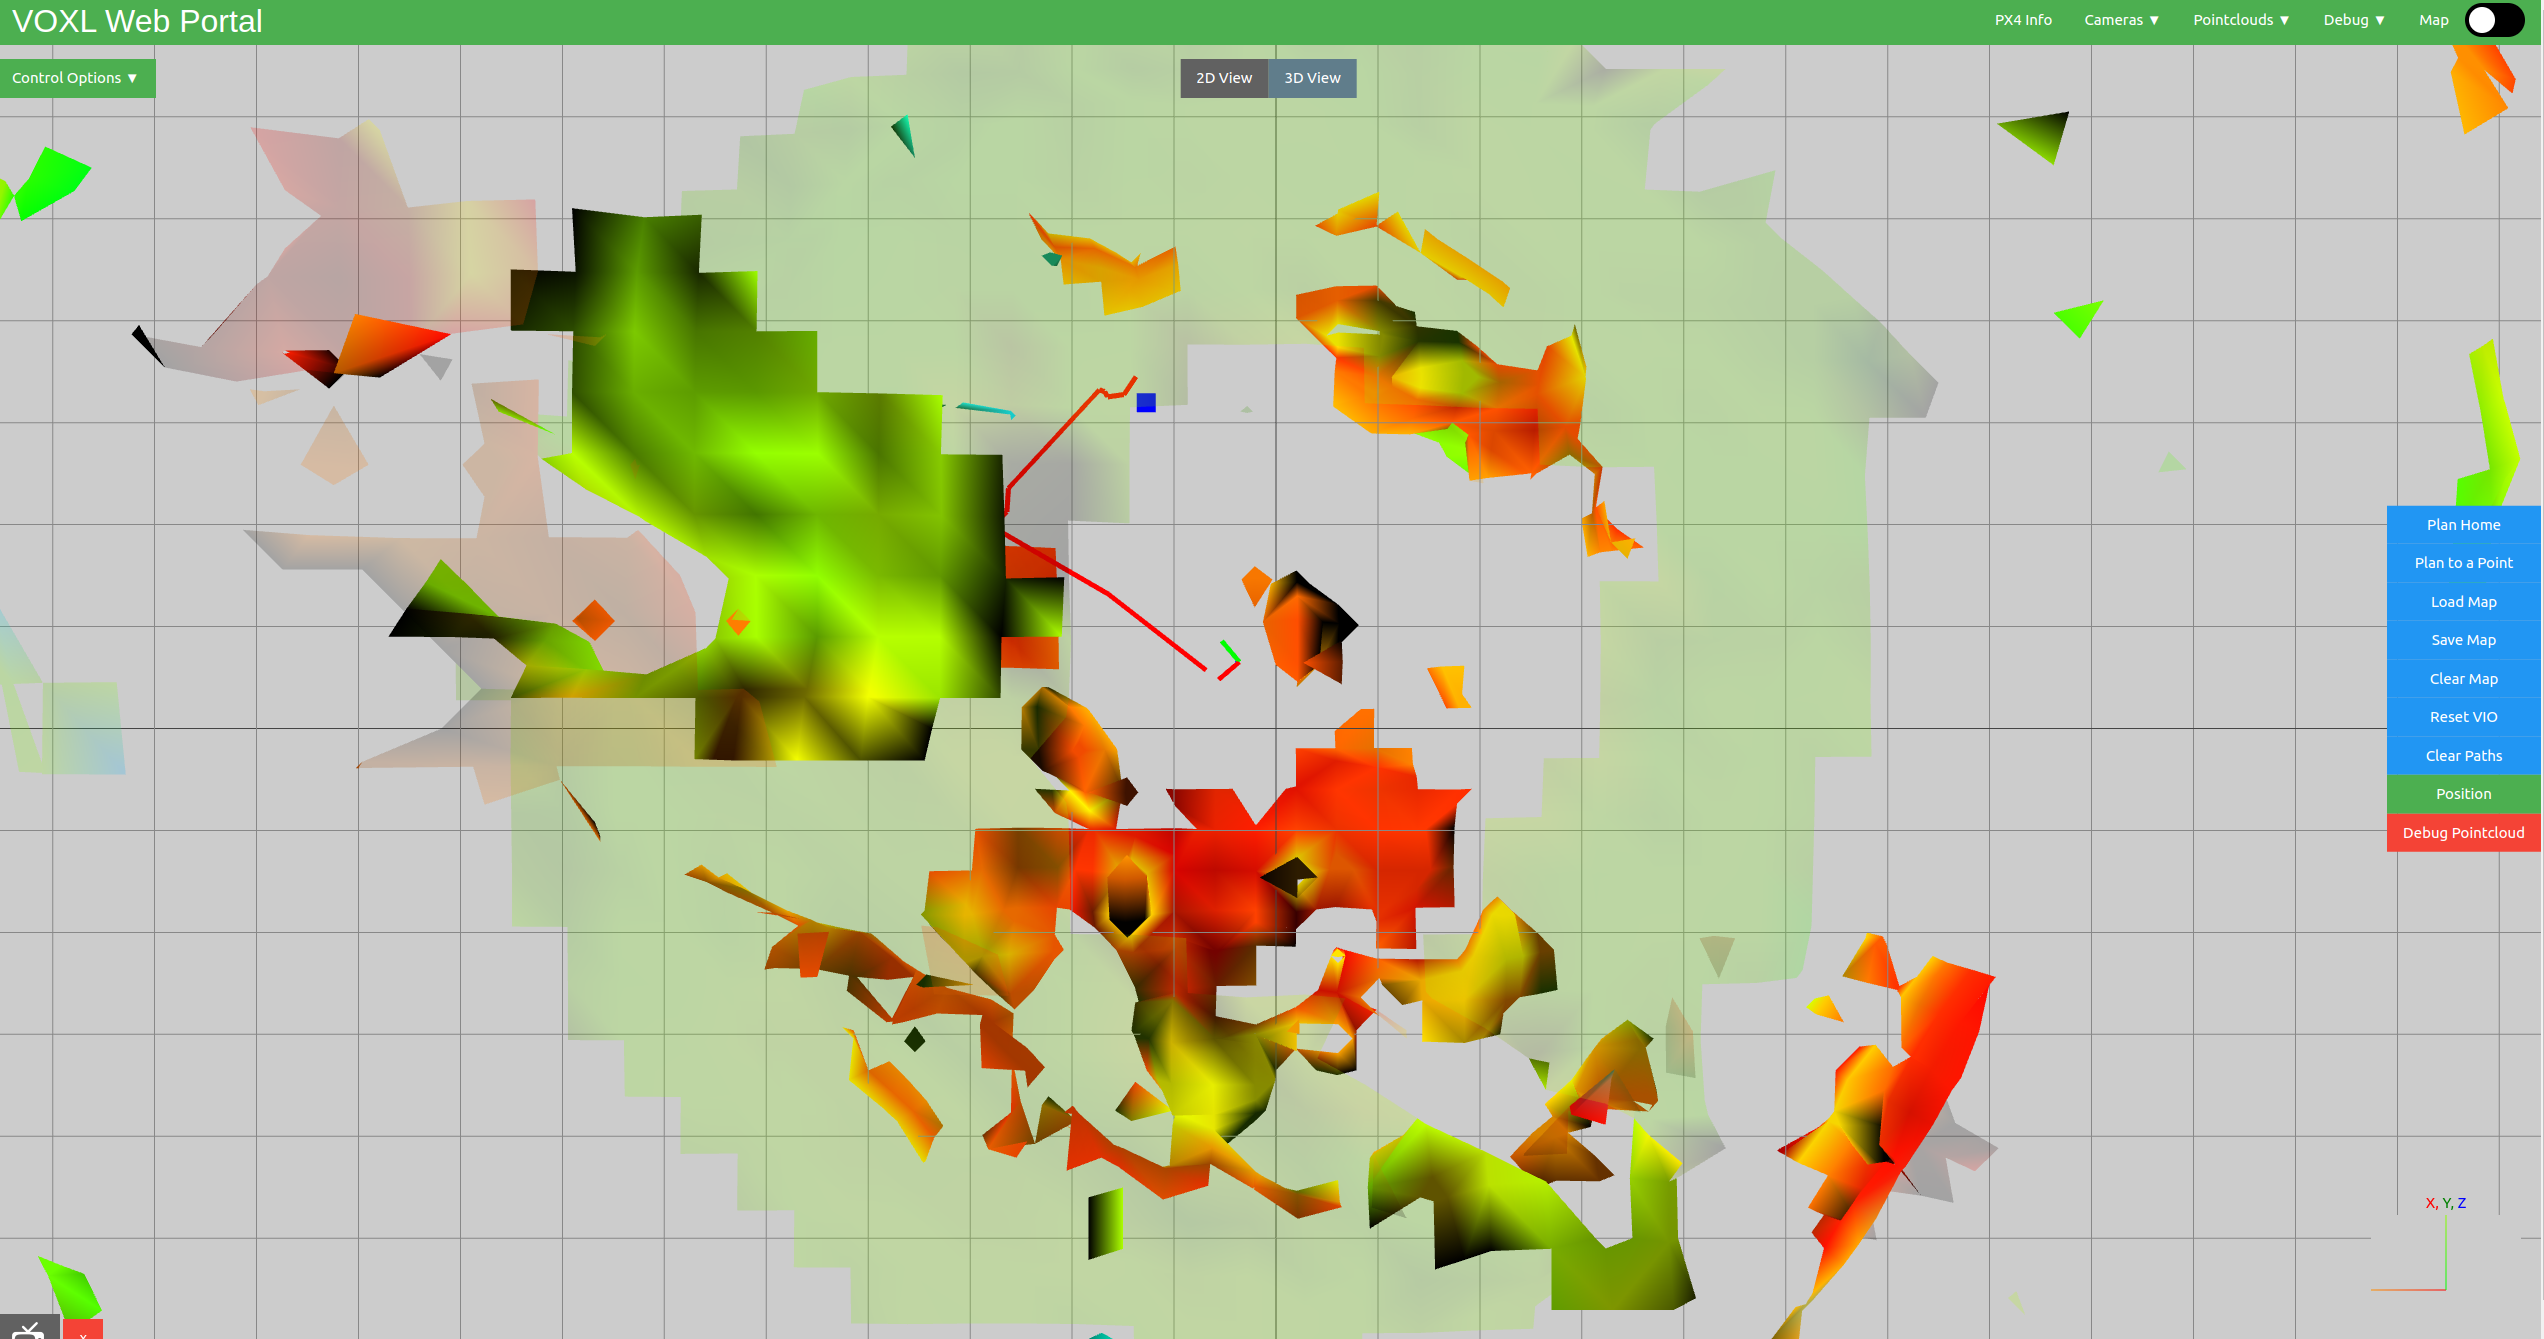
    Hello @Matt-Turi Thank you for your response. For some reason, I can not use the latest version voxl-mapper. I want to know how to generate mesh.ply in old version of voxl-mapper. I clicked the 「save map」button by voxl-portal and I went to the path /data/voxl_mapper/. I found the tsdf file and esdf file and both are not empty files. However, I found the mesh.ply file is empty. Do you know why the mesh.ply is empty file ? And how could I solve it ? Sample Photo (sorry for that I forget to get a screenshot with 3D View) [image: 1665052578742-voxl-web-portal-resized.png]
  • PX4 parameter file for VOXL2

    Unsolved
    2
    0 Votes
    2 Posts
    316 Views
    modaltbM
    There are some defaults setup here, which get set on first run: https://github.com/modalai/px4-firmware/blob/voxl-dev/boards/modalai/rb5-flight/voxl-px4-set-default-parameters.config Now other settings depend on the airframe etc, but this is for our Sentinel reference drone, as reference: https://gitlab.com/voxl-public/flight-core-px4/px4-parameters/-/blob/master/platforms/v1.12/Sentinel/Sentinel_v1_param_rev_C.params
  • Trouble with EM7565 startup...

    Unsolved
    24
    0 Votes
    24 Posts
    7k Views
    Ed SutterE
    @Eric-Katzfey @tom Digging a bit deeper into this, I see that the voxl-build procedure does patch the qmi_wwan.c file, and after the patch, the VID/PID for EM7565 is in there. On one hand this is good news because it implies that the kernel does have support for the modem I'm trying to use; however, its not-so-good news for me because running with that modem has not reliable on VOXL. Aside from verifying that I am actually running the same version on my VOXL-Flight-Deck as is being built in voxl-build (see below), I'm at a loss regarding other things to do to debug this. Any thoughts on this? Following is the output of voxl-version on my board: / # voxl-version cat: /etc/modalai/voxl-software-bundle-version.txt: No such file or directory -------------------------------------------------------------------------------- system-image: ModalAI 3.3.0 BUILDER: ekatzfey BUILD_TIME: 2021-06-06_19:28 kernel: #1 SMP PREEMPT Sun Jun 6 19:41:01 UTC 2021 3.18.71-perf factory-bundle: 1.0.1 (Yocto installation) -------------------------------------------------------------------------------- architecture: aarch64 processor: apq8096 os: GNU/Linux -------------------------------------------------------------------------------- voxl-suite: Package: voxl-suite Version: 0.5.0 Depends: libjpeg_turbo (>= 9.0.4), libmodal_exposure (>= 0.0.2), libmodal_json (>= 0.3.6), libmodal_pipe (>= 2.1.1), lib rc_math (>= 1.1.5), libvoxl_cutils (>= 0.0.2), libvoxl_io (>= 0.5.4), mavlink-camera-manager (>= 0.0.2), mongoose (>= 7. 3.0), opencv (>= 4.5.2-2), openmp (>= 10.0.2), voxl-camera-calibration (>= 0.1.1), voxl-camera-server (>= 0.8.1), voxl-c pu-monitor (>= 0.2.0), voxl-dfs-server (>= 0.2.2), voxl-docker-support (>= 1.1.3), voxl-gphoto2 (>= 0.0.5), voxl-imu-ser ver (>= 0.9.1), voxl-mavlink (>= 0.0.2), voxl-modem (>= 0.12.0), voxl-mpa-tools (>= 0.3.6), voxl-nodes (>= 0.2.0), voxl- portal (>= 0.1.2), voxl-qvio-server (>= 0.3.4), voxl-streamer (>= 0.2.6), voxl-tag-detector (>= 0.0.2), voxl-tflite (>= 2.2.3), voxl-tflite-server (>= 0.1.5), voxl-utils (>= 0.8.4), voxl-vision-px4 (>= 0.9.5), voxl-vpn (>= 0.0.3) Status: install user installed Section: base Architecture: all Maintainer: james@modalai.com MD5Sum: 172dd2541a4b01ec415651b5ded3afab Size: 1956 Filename: voxl-suite_0.5.0_202111041852.ipk Description: meta-package for voxl-suite software collection Installed-Time: 144 --------------------------------------------------------------------------------
  • Voxl_mpa_to_ros

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    Dong LiuD
    @gauravshukla914 I also noticed it. Somehow on the drone's ROS indigo system. roslaunch voxl_mpa_to_ros voxl_map_to_ros.launch won't honor the existing ROS_MASTER_URI, it always source ROS_MASTER_URI etc from my_ros_env.sh
  • VOXL2 ADB not working

    Unsolved
    18
    0 Votes
    18 Posts
    4k Views
    D
    @modaltb Yes, we used r14.1a_1.1.2-M0054-14.1a-FLAT-V3.zip as well. We will make a try with removing all the hardware connection.
  • Issues with indoor mapping speed and path planning with voxl-mapper

    Unsolved
    1
    2
    0 Votes
    1 Posts
    500 Views
    No one has replied
  • voxl_qvio_server version problem

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    Dong LiuD
    @Alex-Gardner Thanks!
  • Does VOXL deal well with multiple interfaces?

    Unsolved
    2
    0 Votes
    2 Posts
    632 Views
    Ed SutterE
    @Ed-Sutter Ok, I see in the actual busybox code for udhcpc it uses /usr/share/udhcpc/default.script, and I just verified that this script does execute on VOXL. Still I don't understand why /etc/resolv.conf gets overwritten. I don't know a lot about this, does anyone know if it is supposed to overwrite?
  • Camera Servers, Docker/Build, royale-331-spectre-4-7

    Unsolved
    4
    0 Votes
    4 Posts
    978 Views
    ?
    Yes, Very! We've got everything working internally and are just cleaning up a few last system image tweaks allowing the sensor writebacks then we'll publish everything!
  • This topic is deleted!

    4
    0 Votes
    4 Posts
    12 Views
  • Should I upgrade?

    Unsolved
    33
    0 Votes
    33 Posts
    9k Views
    tomT
    @Anton-Gereles If you have a specific question that we can help you with please open a new forum post and we'd be more that happy to help get you going.
  • Location of SoC on VOXL1

    Unsolved
    3
    0 Votes
    3 Posts
    504 Views
    H
    @Chad-Sweet thanks!
  • Motor Damaged

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    Juan de Dios Oseas Gutiérrez OrtizJ
    @tom Thank you! @Jeremy-Schmidt I see that you recommend the racerstar 2216/810kv motors, do you know if the propellers from m500 match this motors?
  • Drone not switching flight modes

    Unsolved
    3
    1
    0 Votes
    3 Posts
    1k Views
    R
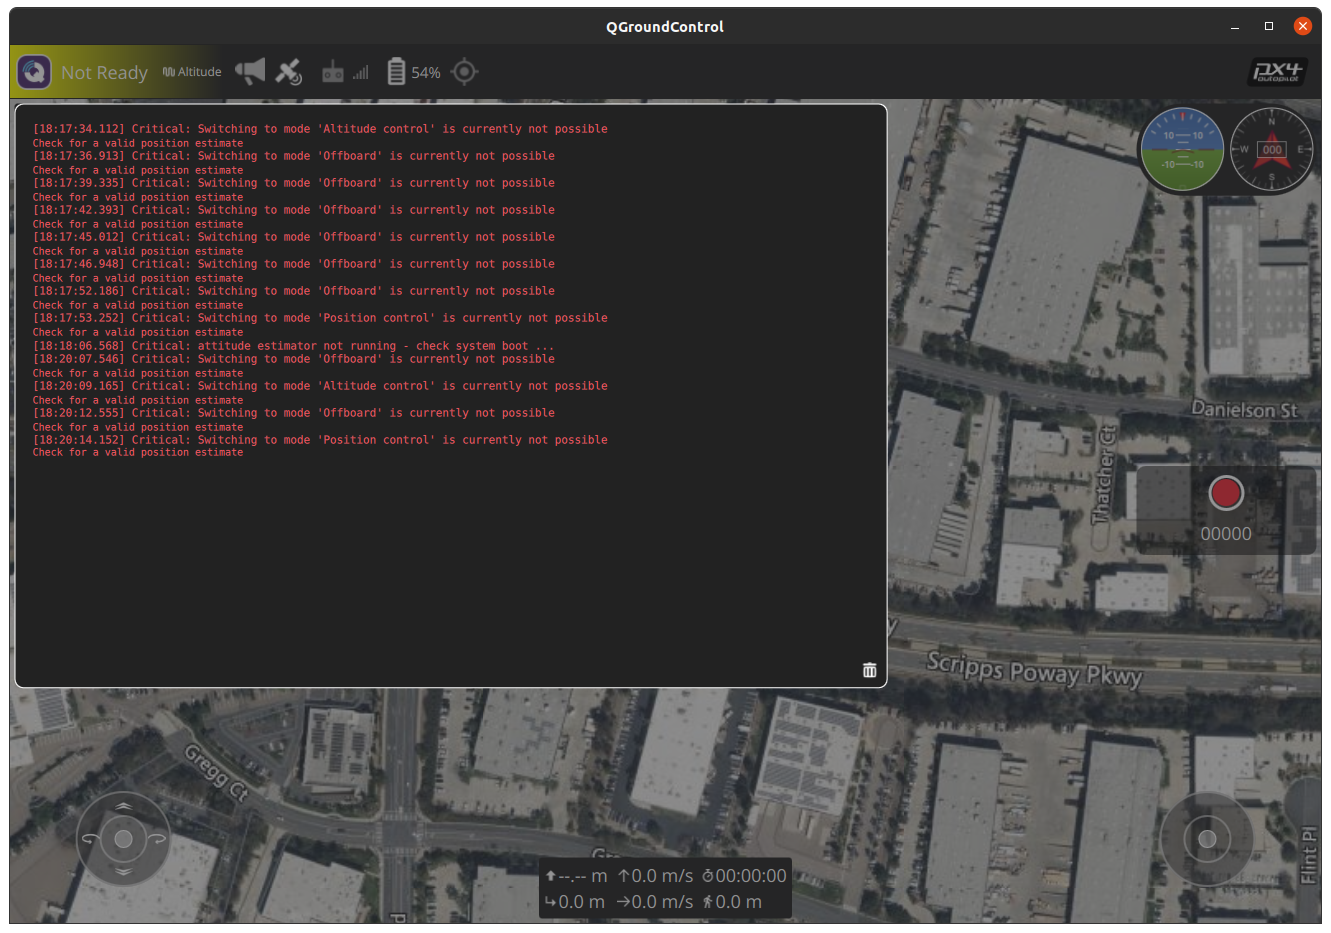
    I changed a few PX4 params stated in the link you posted. I stopped most voxl services. And then did voxl-calibrate-imu-temps first followed by voxl-calibrate-imu. Rebooted the drone and started/configured all the necessary voxl-services. Now I am able to switch to Position and Altitude. But not Offboard mode. Same error as earlier Check for a valid position estimate The drone is stationary on my desk and not flying. Can I only switch to offboard mode when the drone is in the air? Are there any params that I might be missing to make sure it switches to Offboard mode? Will installing a newer voxl version fix the issue?
  • VOXL2 IO board only spinning 4 of 6 motors

    Unsolved
    3
    0 Votes
    3 Posts
    686 Views
    I
    @modaltb Thanks! Finding the correct mixer file solved my problem. Thank you!
  • 4k hi-res camera part number changed?

    Unsolved
    5
    0 Votes
    5 Posts
    713 Views
    H
    @Chad-Sweet I see... let me test it out first then. Might want to consider making a note on the store page in case this affects someone else as well. For one, the photo shown on the store does not match the product that is actually being sold.
  • Apriltag landing fixed frame ROS interface

    Unsolved
    1
    1 Votes
    1 Posts
    619 Views
    No one has replied
  • New Sentinel came with a broken stereo camera?

    Unsolved
    3
    0 Votes
    3 Posts
    697 Views
    R
    Cool I will bring it in today
  • 0 Votes
    3 Posts
    880 Views
    ?
    Also, opkg list shows all available versions of packages, so to see what you are actually using you can run opkg list-installed