Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • How to send the GPS data to the Drone

    Unsolved
    2
    0 Votes
    2 Posts
    726 Views
    Chad SweetC
    You will have to study PX4 architecture and work through the code to create a new type of GPS input Did you go through the VIO troubleshooting steps? https://docs.modalai.com/flying-with-vio/#troubleshooting-vio
  • Can't Connect to QGC Microhard

    Unsolved
    3
    3
    0 Votes
    3 Posts
    832 Views
    Z
    nvm, solved it. Had to enable and run the service voxl-mavlink-server first, then do the same with the voxl-vision-px4 service. I'll leave this here for posterity
  • Mapping and planning using TOF sensor

    Unsolved
    2
    0 Votes
    2 Posts
    656 Views
    ?
    Hi, While we so technically support mapping using stereo we almost always use the tof sensor ourselves since it's much more accurate at higher resolutions. The default for our voxl-mapper project uses the tof sensor for mapping with option to enable stereo if that's what you want to use. We generally just use stereo for collision prevention since it's pretty reliable at detecting if something is in front of it or not but can struggle to populate a detailed full-fov image in realtime.
  • Does VOXL2 support UAVCAN?

    Unsolved
    3
    0 Votes
    3 Posts
    654 Views
    Patrick HincheyP
    Thanks Eric, I'll look into the legacy mode
  • Does VOXL series drone development board support makroBUS interface?

    Unsolved
    3
    0 Votes
    3 Posts
    744 Views
    Suvasis MS
    Sorry it's mikrobus.
  • SSH Halloween theme

    Unsolved
    3
    1
    2 Votes
    3 Posts
    823 Views
    Patrick HincheyP
  • Camera auto-exposure configuration

    Unsolved
    1
    0 Votes
    1 Posts
    295 Views
    No one has replied
  • Seeker drone "backtracking" when it stops to hover

    Unsolved
    3
    1
    0 Votes
    3 Posts
    531 Views
    H
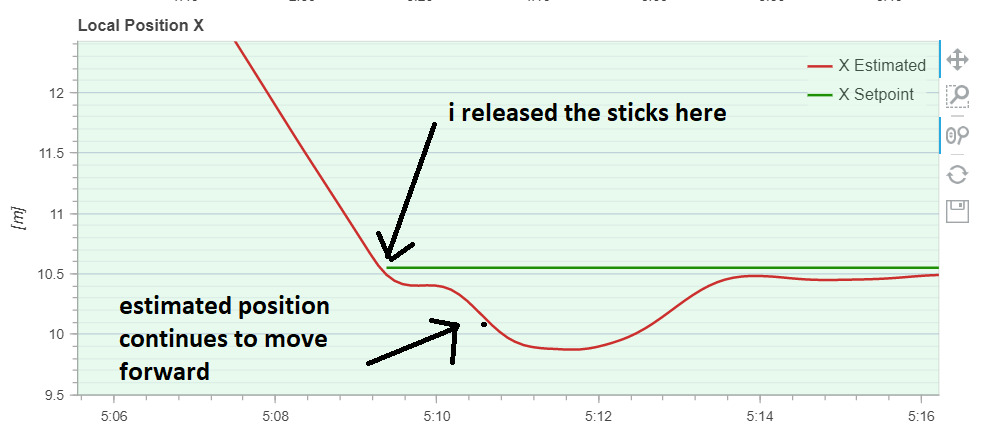
    @Steve-Turner said in Seeker drone "backtracking" when it stops to hover: I don't work for Modal, so take this with a grain... MPC_POS_MODE controls some of this behavior. https://docs.px4.io/v1.12/en/advanced_config/parameter_reference.html has a description and you can try the other options to see how that influences the behavior. https://docs.px4.io/v1.9.0/en/config_mc/advanced_mc_position_tuning.html Should help with some of the tuning parameters that control position behavior. Additionally, the PID loop for position might need some tuning if you want it to stop more aggressively. Thanks for the suggestion but I'm quite certain it has nothing to do with MPC_POS_MODE nor the tuning of the velocity/position controller. The phenomenon I described only happens sometimes - especially when VIO quality is low for that stretch of journey just before the drone comes to a stop
  • full-flash.sh occur Last flash failed:Volume Full

    Unsolved
    4
    1
    0 Votes
    4 Posts
    1k Views
    tomT
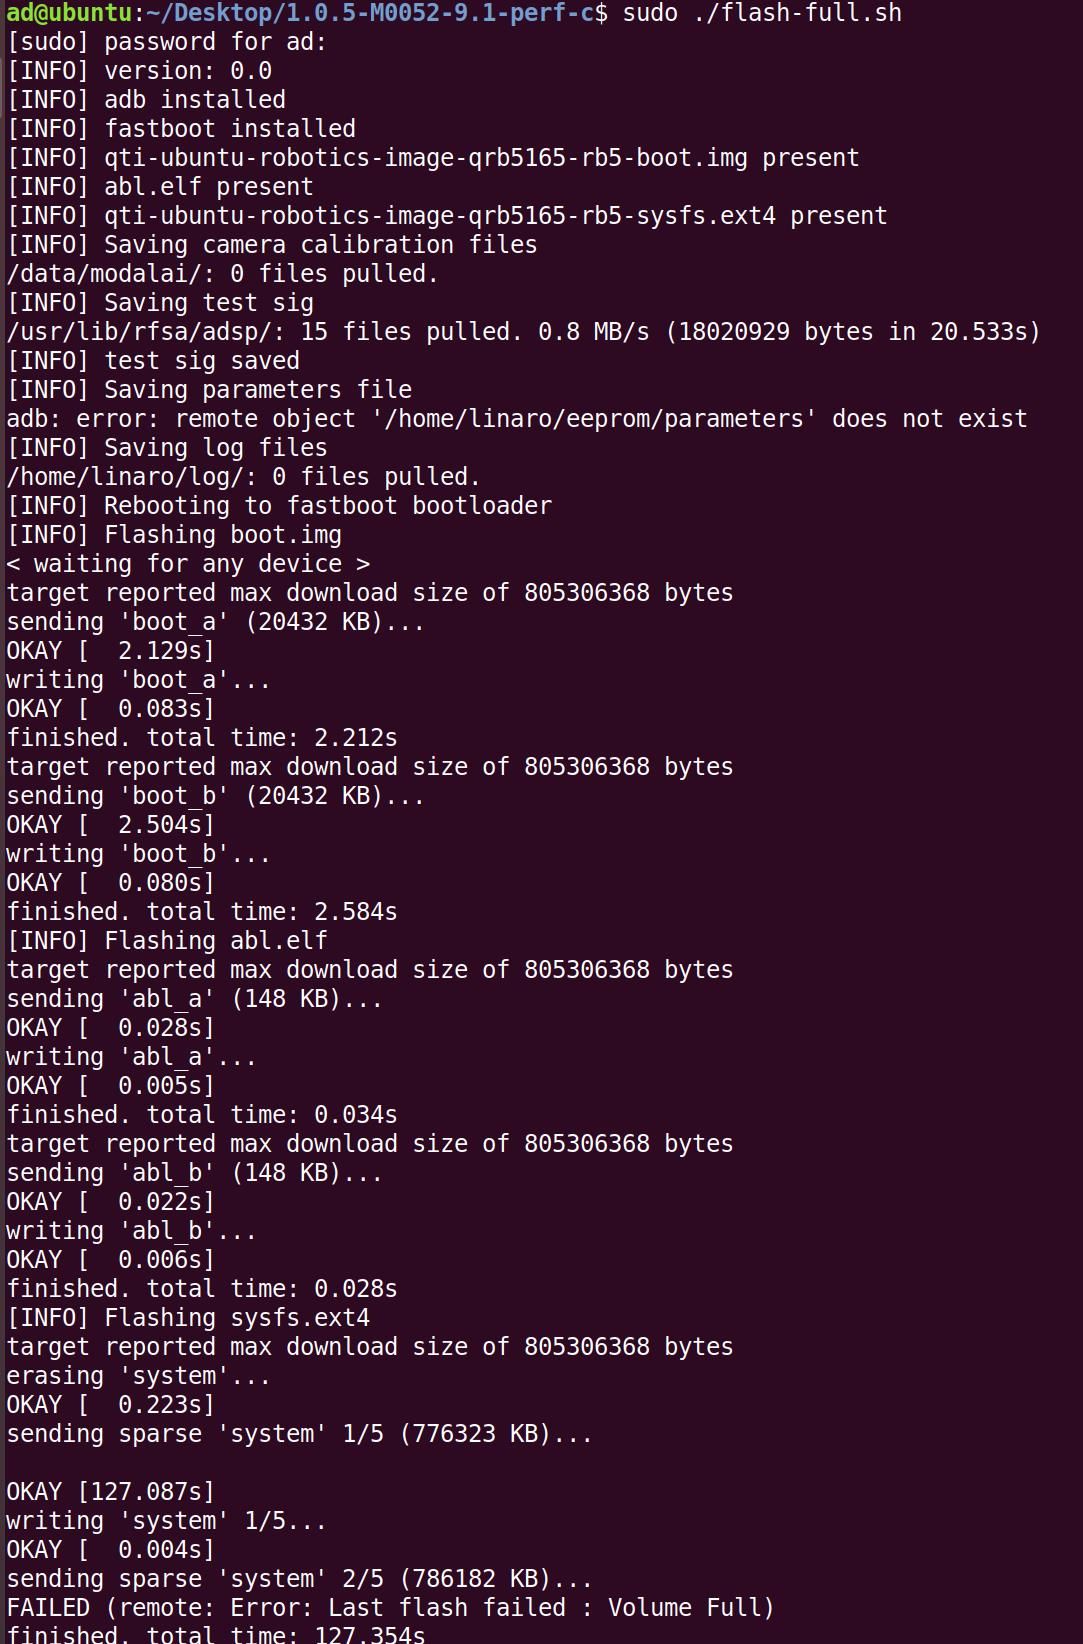
    @yitakabe Can you post either a screenshot or copy/paste the error you're seeing?
  • Pi or Jetson companion computer installation and interfacing step-by-step

    Unsolved
    4
    0 Votes
    4 Posts
    946 Views
    Chad SweetC
    OK. We don't have a documented way, but VOXL 2 is a Linux computer. So you could use some form of networking: ROS or other. There are also UARTs, etc
  • vslam map export and import

    Unsolved
    2
    0 Votes
    2 Posts
    604 Views
    Steve TurnerS
    QVIO does not perform SLAM, only visual tracking to aid in stability by tracking the velocity vectors of key points through a camera. https://gitlab.com/voxl-public/voxl-sdk/services/voxl-mapper performs mapping and planning. Data can be imported and exported through VOXL Portal with "Load Map" / "Save Map"
  • wifi routing dies after 30s

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    Patrick HincheyP
    Interesting! I'll keep watching this thread for when you commit a proper fix in voxl-modem. For the meantime, my hack is working for me. Thanks!
  • cannot connect to Seeker using usb: adb devices not found

    Unsolved
    8
    4
    0 Votes
    8 Posts
    2k Views
    tomT
    @ahmed-mustahid Unfortunately the "QUSB_BULK" mode that your VOXL is enumerating in cannot be fixed by our unbricking process and will have to be sent in for an RMA. See here for info on the RMA process: https://www.modalai.com/pages/rma
  • Voxl new sdk-0.9

    Unsolved
    4
    0 Votes
    4 Posts
    829 Views
    tomT
    @Maxim-Temp That image is also still in test.
  • image compression API?

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    Dong LiuD
    @Eric-Katzfey Hi Eric. The jpeg compression imposes a lot of load on the CPU, especially we're using the hires camera. Is there any way you can make the HW jpeg encoding available for us to test it? Thanks!
  • hires image upside down?

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Dong LiuD
    @tom Ok, thanks!
  • Any example I2C code for VOXL1?

    Unsolved
    1
    0 Votes
    1 Posts
    454 Views
    No one has replied
  • Can I fly voxl2 manually without keeping qvio on ?

    Unsolved
    5
    0 Votes
    5 Posts
    536 Views
    Tamas Pal 0T
    @Adrian-Hidalgo I get it. But from the moment I am giving throttle the vehile starts wobbling and it increase. I am unable to fly it for a second.
  • offboard height problem

    Unsolved
    4
    0 Votes
    4 Posts
    954 Views
    張為超張
    @Adrian-Hidalgo @Dobry-Kolacz Thanks for your reply, so the drone uses QVIO to control the altitude (I think it uses barometer or something else) which perfectly explains why the altitude sometimes drifts as our floors are a bit lacking in texture. I'll try adding some texture to the floor and give it a try. Thanks.
  • Voxl-px4-imu-server

    Unsolved
    4
    0 Votes
    4 Posts
    630 Views
    ?
    Yes, the service doesn't need to be enabled on voxl/voxl2 (the configure-mpa script will enable the correct imu server for whichever platform you're on)