Skip to content
  • 0 Votes
    35 Posts
    10k Views
    Jetson NanoJ
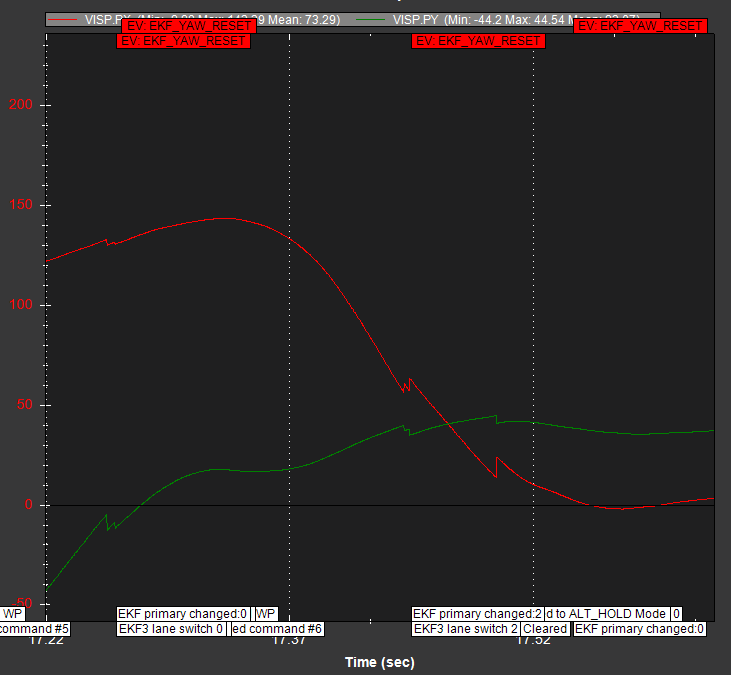
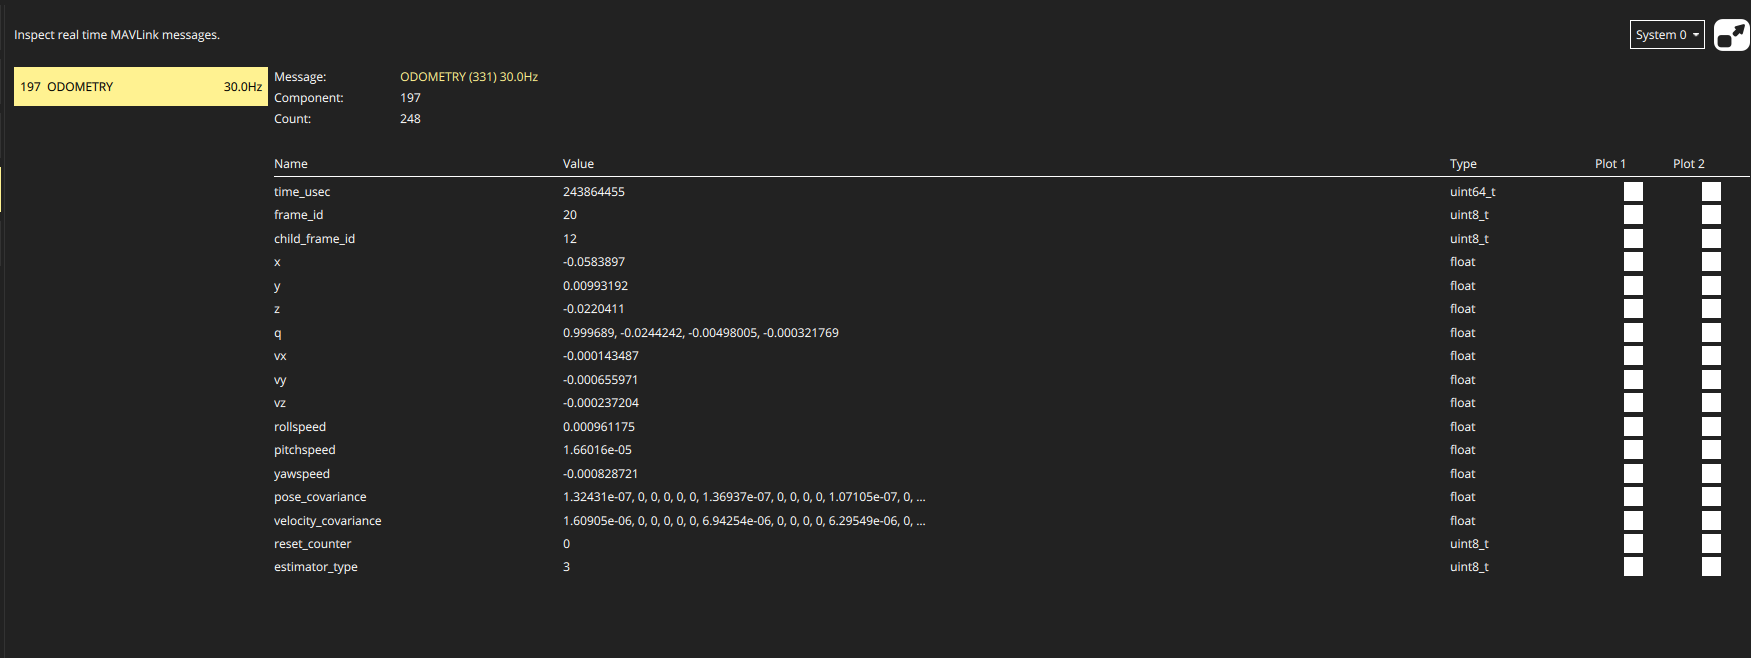
    Hey @Eric-Katzfey I was able to solve it. I was able to shift the drone to offboard-mode, the drone doesn't drift away. In voxl-vision-hub, I have the set the parameter to figure_eight. I'm getting the stream to VOXL2 from Flight Core v2. I had to run it on 2 different ports. mavlink stream -r 30 -s ODOMETRY -d /dev/ttyS4 mavlink stream -r 30 -s ODOMETRY -d /dev/ttyS6 But I'm getting the #331 odometry message when using only ttyS6 port. [image: 1732544018893-screenshot-from-2024-11-25-18-52-49.png] Now the drone is able to figure_eight loop without loosing height estimates.
  • 0 Votes
    6 Posts
    1k Views
    Alex KushleyevA
    @Jeremy-Frederick , If VIO is working, then there is a very high chance that you got the orientation correct . If the camera to IMU orientation is off by something like 90 degrees in any direction, VIO is pretty much guaranteed to fail. So if you are getting normal VIO performance, quick initialization, across multiple tests, then I would say that your orientation parameters are correct for VIO. Please keep in mind that if you flipped the board and if you are planning to fly with PX4, you will need to change the imu rotation params in PX4 (also keep in mind that PX4 is using a different IMU that is connected to the DSP)
  • Adding more cameras to VIO

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    2
    1 Votes
    2 Posts
    2k Views
    K
    Adding more cameras can definitely improve robustness, but synchronization and calibration become super important once you go beyond the default setup. Even small timestamp offsets between sensors can throw VIO off pretty badly. I’d also keep an eye on bandwidth and CPU usage because extra camera streams add up fast on embedded systems.
  • 0 Votes
    5 Posts
    1k Views
    Eric KatzfeyE
    @Adriano-Del-Pino-Lino Please reference this other post: https://forum.modalai.com/topic/3341/odometry-message/2
  • qvio ros2 topics

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    2
    0 Votes
    2 Posts
    640 Views
    Zachary Lowell 0Z
    Yes you can look at it that way. Pose is just the generic positional data inclusive of the quaternion and imu wrt vio/camera - odometry is that as well as things like the twist or better known as velocity wrt to the vio instance/camera and the angular velocity wrt to the vio/camera. Let me know if this better helps you understand - all the code is open sourced btw so feel free to take a gander for a programatic understanding: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-to-ros2/-/blob/master/colcon_ws/src/voxl_mpa_to_ros2/src/interfaces/qvio_interface.cpp?ref_type=heads#L113
  • VIO Algorithms

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    3
    0 Votes
    3 Posts
    935 Views
    leonardo Andrade 0L
    @Alex-Kushleyev Thanks mate!
  • Qvio recovery after blowups taking too long

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    1
    0 Votes
    1 Posts
    584 Views
    No one has replied
  • will VOXL 2 support Voxblox and GBPlanner

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    1
    0 Votes
    1 Posts
    724 Views
    No one has replied
  • VOXL2 QVIO Pipeline Failing to Run

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    4
    2
    0 Votes
    4 Posts
    1k Views
    Jeremy FrederickJ
    @tom SOLVED, thanks Tom, that command line prompt showed me that I needed to voxl-configure-extrinsics. Thank you!
  • Troubleshooting/Improving VIO Accuracy

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    13
    1
    0 Votes
    13 Posts
    4k Views
    nickyblanchN
    @AP123 Hi, I have not seen this before, but I also haven't tried enabling obstacle avoidance. I can't pretend to know much about the obstacle avoidance code running inn the VOXL SDK, but I suppose this error could be caused by some obstacle avoidance service not running on the VOXL when it should be, hence QGroundcontrol being confused.
  • OV9782 VIO parameters

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    7
    0 Votes
    7 Posts
    2k Views
    P
    @david-moro That is my impression too, that and, it does not seem to be all that robust in general. I am very interested in using an open source VIO solution, and build it to be a mostly drop-in replacement for Qvio. I need it for high-altitude flight too, in mostly texture-less environments, a most robust solution seems necessary. I only just started looking into which methods could be interesting to use, and came across DM-VIO: Delayed Marginalization Visual-Inertial Odometry which seems to be very modern and robust. The paper for this states that it was run in real time on a 2013 mobile i7 at 2.3GHz, so I am hopeful that it could run on the VOXL 2. I would be interested in following along if any of you decide to go in another direction than Qvio.
  • 0 Votes
    1 Posts
    1k Views
    No one has replied
  • OV9782 VIO jumps but does not reset

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    3
    1
    0 Votes
    3 Posts
    872 Views
    D
    @Moderator will try to on our next flight. Do you have an easy way to trigger a capture when certain conditions are met? It is hard to correlate hundred of images to the autopilot logs to find these instances. We are working on streaming the qvio-overlay as an RTSP stream down to the GCS. That might be easier. Unrelated question. Can the VIO algorithm use the colored images coming from the camera? If yes, is there an advantage at all?
  • 0 Votes
    12 Posts
    4k Views
    ?
    @SMRazaRizvi @madswamp @Jgaucin @AndriiHlyvko @camharrisvayu Hey all, apologies on this. We were finally able to recreate the issue but unable to determine what the root cause was. Regardless, we have a new SDK (1.1.0) released which isn't showing the stack smashing issue. https://developer.modalai.com/asset/2 Please let me know if this is still an issue and sorry for the wait on this. Thanks, Thomas Patton
  • 0 Votes
    1 Posts
    753 Views
    No one has replied
  • 0 Votes
    7 Posts
    3k Views
    tomT
    @KevinChan 0.9.5 is the newest, 0.9 is second newest, 1.3.1-0.8 (0.8) is super old. We changed our naming scheme some time ago so I can understand the confusion
  • VIO for Outdoors

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    4
    0 Votes
    4 Posts
    2k Views
    Chad SweetC
    You can't really tune the feature detection algorithm. You can tune the exposure algorithm. You might try to increase ae_msv parameter in camera-server config to maybe add more contrast?
  • VOXL2-based Sentinel voxl-qvio-server crashes

    Unsolved Autonomy: VIO, Mapping and Navigation vio
    3
    0 Votes
    3 Posts
    1k Views
    T
    Thank you. I got the VIO going on the drone. I noticed that when running the VIO server, the IMU_BW error kept coming up and that was the cause of the server's crash. Therefore, I increased the limited_imu_bw_trigger parameter in the voxl-qvio-server.conf arbitrarily to 100 and it worked fine.
  • 0 Votes
    5 Posts
    2k Views
    Sem AndewegS
    @Steve-Turner - Yeah I have put EKF2_AID_MASK to 0. Then the drone would just be behaving normally. @Cliff-Wong - I understand that I would have to disable qvio-server, if I would only fly in non-evdata modus. But when flying with evdata, if then the evdata goes bad, I need to switch to non-evdata to be able to save the drone from crashing. But now the drone will still crash!