Skip to content

Development Drones

640 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Starling 2 Motor EOL (M10000633) replacement & Battery specs for EU sourcing

    Unsolved
    3
    0 Votes
    3 Posts
    75 Views
    L
    Hi again, Thank you for the clarification on the battery specs and for highlighting the risks. Given that the original motor (1504 3000KV, PN: M10000633) is now officially obsolete/end-of-life (as shown in your product specs) and replaced by M10001231, we will strictly follow your advice and avoid any hardware hacks or mixing different motor specs. PNG However, having to replace three perfectly operational motors simply because the single original part was discontinued leaves us in a difficult position for a routine repair. Since we need a reliable and official path forward to get our Starling 2 flying again, could you please advise on how ModalAI handles this situation? EOL Support / Single Motor Solution: Is there any remaining stock of the original M10000633 motor for RMA/repair cases, or any official solution to avoid replacing the entire set of 4 motors when only one is damaged? Official Replacement Path: If replacing all 4 motors with the 1503 2900KV (M10001231) model is strictly mandatory, do you offer a replacement bundle/discount for users impacted by this EOL transition? Firmware / PID Configuration: If we are forced to replace all 4 motors with the 1503 2900KV model, does ModalAI provide an updated PX4/VOXL parameters file/tune for this hardware revision, or does the default factory tune handle the change automatically? We appreciate your guidance to ensure our autonomous flight testing remains safe, supported, and cost-effective. Best regards, [image: 1790346499104-074a5467-963f-4cde-812f-9d77ff039cfb.png]
  • Starling 2 intermittently rebooting / VOXL losing power and ESC LEDs stopping

    Unsolved
    2
    1 Votes
    2 Posts
    100 Views
    Marcos CorreaM
    Pressing down on the The M0141 also causes this reboot any thoughts I can show video if needed. @administrators
  • SDK 1.6.4 on a Stinger X8: lepton0_encoded never publishes H265 frames

    Unsolved
    1
    0 Votes
    1 Posts
    19 Views
    No one has replied
  • Camera Calibration – Starling 2 Max

    Solved
    5
    0 Votes
    5 Posts
    96 Views
    V
    @tom thank you
  • VOXL2 randomly reboots during flight – PMIC reports S3_RESET_PBS_WATCHDOG_TO

    Unsolved
    2
    0 Votes
    2 Posts
    82 Views
    ModeratorM
    Most power issues with VOXL 2 relate to MCBL-00001 connector becoming dislodged. People often pull the cable instead of depress the connector for proper removal. Is there any chance you have a cabling issue? This is the most common cause of failure. Assuming you don't have major software changes, we're not tracking any issues that cause random flight reboots.
  • plz

    Unsolved
    2
    0 Votes
    2 Posts
    85 Views
    Eric KatzfeyE
    Most of this can be answered by our documentation here: https://docs.modalai.com/. If after reading through that you still have any specific questions feel free to reach out here on the forum. The short answer to most of your questions is "yes".
  • Possible camera orientations for Starling 2 Max dev drone

    Unsolved
    3
    0 Votes
    3 Posts
    217 Views
    Dylan GreshamD
    Hi @tom, That's exactly what I was looking for, thank you!
  • Starling 2 Max - Power issues when starting process

    Unsolved
    5
    3
    0 Votes
    5 Posts
    177 Views
    Eric KatzfeyE
    There are likely 2 issues here. One was a floating point math fix that is in newer versions of PX4. Can you update to latest px4: http://voxl-packages.modalai.com/dists/qrb5165/dev/binary-arm64/voxl-px4_1.14.0-2.0.146-202607161052_arm64.deb and try again? The other issue is that sending in trajectory setpoints from your external application, even when in altitude mode, will go straight into the position controller and affect flight. So, I would only send those in when in offboard mode.
  • 0 Votes
    3 Posts
    274 Views
    tomT
    Hi @alraj, 05c6:900e QUSB_BULK is not EDL (that is 9008). It is the SoC crash-dump mode, so the board is attempting to boot and failing before the OS comes up. Since Sahara/Firehose completed with the correct M0054-2 image, the flash contents are unlikely to be the problem. In past cases a board that returns to 900e after a successful QDL has not been recoverable by reflashing (https://forum.modalai.com/topic/1468 and https://forum.modalai.com/topic/3263), and a similar Sentinel case came back from RMA as a damaged main board (https://forum.modalai.com/topic/2131). Two things worth ruling out first. Pull the VOXL 2 out of the drone and boot it bare with every camera and add-on disconnected, since a mis-seated camera connector produced this same 900e state once (https://forum.modalai.com/topic/3230). Then re-check the steps at https://docs.modalai.com/voxl2-unbricking/#if-the-device-still-shows-900e-or-boot-loops-after-a-successful-flash and repeat the flash once. If it still comes back as 900e, an RMA is the next step: https://www.modalai.com/pages/rma. Include the serial number and QDL log. Keep the crash dump private, support can request it if needed.
  • Re-configure VOXL2 1.4 for GHOST Receiver/Transmitter?

    Solved sentinel
    14
    0 Votes
    14 Posts
    614 Views
    Maxwell SchaeferM
    The ExpressLRS receiver requires* one additional wire. The ghost atto only connects one wire to the VOXL RC RX pin, but the ELRS receiver will also require a connection to the VOXL RC TX pin, otherwise the wiring is identical. Pre-crimped wires can be found easily for the JST GH connectors (J19) to make adding connections simple. *You could leave the receiver's RX line (the VOXL's RC TX) disconnected; this would make updates and other control using the voxl-elrs application impossible but basic RC functionality would work.
  • Camera Intrinsics, VIO and more..

    Unsolved starling
    7
    0 Votes
    7 Posts
    2k Views
    Dinesh Varun KandiyappanD
    @alex-kushleyev Thanks for the response! A control model is a simple MLP (multi-layer perceptron) Input observation space: PX4 odometry topics, ToF depth/Depth estimation model, object detections. Output action space: PX4 offboard commands ( position and yaw for now, but we might extend to velocity/Collective thrust and body rates)
  • Does Startling 2 Max have ASDA and FAR 52.240-1 compliance

    Unsolved starling
    1
    0 Votes
    1 Posts
    75 Views
    No one has replied
  • Battery Data Collection

    Unsolved stinger
    4
    0 Votes
    4 Posts
    175 Views
    Vipul BansalV
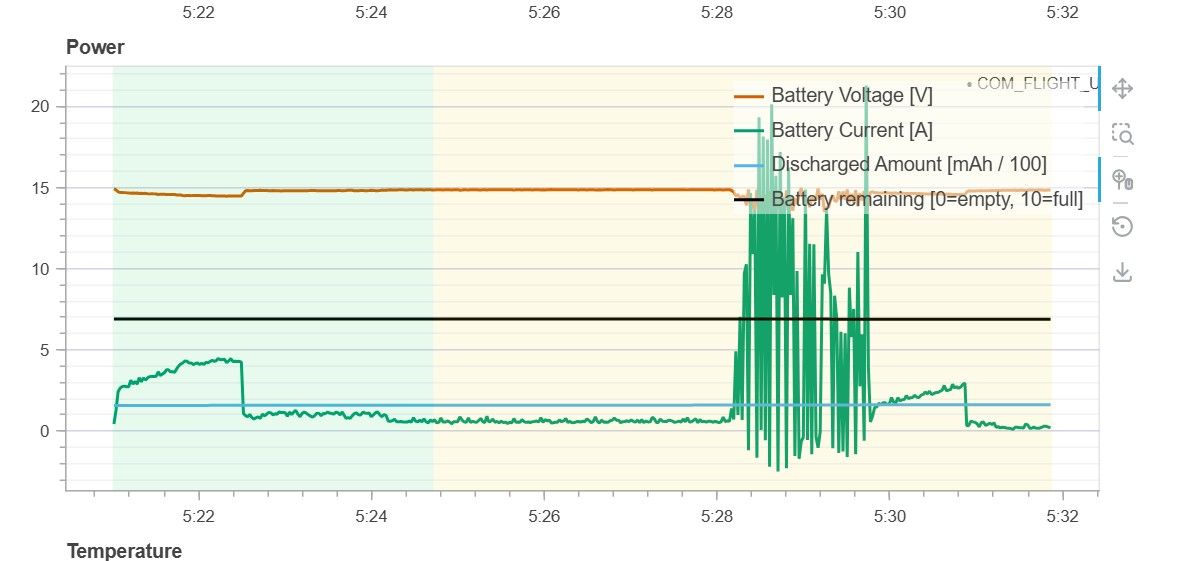
    I want to develop a battery management system to read live battery data and use it into a software that plans launch, path, return and control of the drone
  • QDL - 'received non-successful result'

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    541 Views
    P
    RMA'd the VOXL2 board, it was found to be unrepairable.
  • stinger + TOF

    Unsolved stinger
    1
    0 Votes
    1 Posts
    113 Views
    No one has replied
  • VRX Ground Unit Baked In OSD Elements

    Unsolved fpv
    1
    0 Votes
    1 Posts
    96 Views
    No one has replied
  • Hardware: Starling 2 Max Landing Legs CAD different from drone

    Unsolved starling
    2
    0 Votes
    2 Posts
    170 Views
    S
    The specific leg in question has a number on it - 1460. The legs in the CAD for the C28 show 868B.
  • Seeker User Manual

    Solved seeker
    2
    0 Votes
    2 Posts
    206 Views
    tomT
    Please reach out here: https://www.modalai.com/pages/blue-uas-cleared-fpv-customer-intake-form
  • Purchasing Starling 2

    Unsolved starling
    1
    0 Votes
    1 Posts
    122 Views
    No one has replied
  • Starling 2 Purchase

    Unsolved
    1
    0 Votes
    1 Posts
    114 Views
    No one has replied