Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Which 4g module can I use on the m500?

    Unsolved
    4
    0 Votes
    4 Posts
    742 Views
    tomT
    @José-Quintanilla WP7610 or RC7611 should work for you
  • External payload and centre of gravity setting.

    Unsolved
    3
    0 Votes
    3 Posts
    487 Views
    S
    @Moodsh00 Were you able to successfully attach and configure the additional payload? Can you also share which gimbal did you attach? I am also in the phase of attaching a ~900g Gimbal to the Sentinel and I'm trying to see if that's possible.
  • Support Required for UAV Coordinate and Parameter Issues in newly unboxed sentinel

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    Eric KatzfeyE
    @Amisha-Bhaskar However, it won't revert to 0 if you change it. The parameters that you update are saved in the file /data/px4/param/parameters. Do you have that file in your filesystem?
  • High framerate support for OV7251

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    modaltbM
    @elfowl currently, we have to use a proprietary Qualcomm toolchain to generate camera binaries... we would need to add this setting. Our goal is to open up this area such that we can all customize as needed but we don't have this functionality yet. The framework we are using is in general setup for phone manufactures to add a sensor or two to a phone to known locations, so we are kind of hacking it to allow folks to add numerous types to up to 6 locations, which involves removing some onion layers
  • Stereo camera and UVC server compatiability

    Unsolved
    2
    0 Votes
    2 Posts
    562 Views
    Eric KatzfeyE
    @bgaudel said in Stereo camera and UVC server compatiability: 2b03:f781 Here are the instructions for how to use voxl-uvc-server. Make sure you are correctly specifying the resolution and frame rate. The Stereolabs ZED doesn't output 640x480 30fps. https://docs.modalai.com/voxl-uvc-server/
  • How can I use qvio or tracking camera as v4l2src in voxl2?

    Unsolved
    4
    2
    0 Votes
    4 Posts
    515 Views
    Eric KatzfeyE
    @Dongoo-Lee The code is open source. You are free to modify it to do whatever you want. https://gitlab.com/voxl-public/voxl-sdk/services/voxl-streamer
  • Multi-Camera Setup - question on feasibility (IMX335 / OV64B)

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    E
    Any rough guidance here would be great. As you can see in the related posts there are quite a few others interested in this.
  • RB5 running VOXL cannot connect to QGroundControl over WiFi

    Unsolved
    2
    1
    0 Votes
    2 Posts
    624 Views
    Martin BrandtM
    We figured it out, the answer is explained in this reply to another question: https://forum.modalai.com/post/9575
  • Change hires camera encoding/format

    Unsolved
    1
    0 Votes
    1 Posts
    301 Views
    No one has replied
  • Communication through J18

    Unsolved
    23
    0 Votes
    23 Posts
    7k Views
    Filip Slezak 0F
    @modaltb Hey, thanks for the quick reply. Unfortunately, none of these work for us since it seems exposing one port prevents us from accessing another (I also can't find a ref to buy the M0130). We found a workaround by having a USB hub on the m0125 instead of going over the native uart.
  • Recommend Update to PX4 param helper files

    Unsolved
    1
    0 Votes
    1 Posts
    345 Views
    No one has replied
  • the Newbie don't know how to make it fly

    Unsolved
    1
    0 Votes
    1 Posts
    263 Views
    No one has replied
  • VOXL Mini 4in1 ESC conflicts with Power Module v3

    Unsolved
    14
    0 Votes
    14 Posts
    2k Views
    H
    @Eric-Katzfey It work! Thank you!
  • Odd conditions resulting in voxl-camera-server crash

    Unsolved
    4
    0 Votes
    4 Posts
    866 Views
    H
    @Thomas-Patton thanks for looking into this. The random crash that I described in my second message in this thread is not related to the OS on which I run putty on. The crash happens on the VOXL2, sometimes even before I SSH in.
  • Support for Ubuntu 22.04

    Unsolved
    4
    0 Votes
    4 Posts
    719 Views
    Eric KatzfeyE
    @Praveen We provide the docker image so that you do not have to build it. It is just a tool that is needed to build some of our software packages. As long as it is doing that then there is no need to update it.
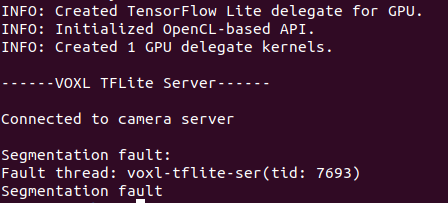
  • Voxl-tflite-server error with a custom model

    Unsolved
    2
    1
    1 Votes
    2 Posts
    666 Views
    P
    @Maxim-Temp hi, I'm facing the same issue, did you manage to solve this?
  • Propeller Coefficients for Starling V2

    Unsolved starlingv2 propellers
    2
    0 Votes
    2 Posts
    2k Views
    Alex KushleyevA
    Hello @Kashish-Garg-0 we have a curve that is "motor voltage vs rpm", meaning that for a desired RPM, it tells the ESC what average motor voltage should be applied. The average motor voltage is defined as battery_voltage * motor_pmw_duty_cycle. The battery voltage in this curve is in millivolts. Since you are typically controlling the desired RPM, as a user you do not need to worry about what "throttle" or voltage to apply - the ESC does this automatically in order to achieve the desired RPM. this calibration curve is used as a feed-forward term in the RPM controller. The ESC does support an "open loop" type of control where you specify the power from 0 to 100%, which is similar to a standard ESC, but PX4 does not use that ESC control mode. By the way, you can test the ESC directly (not using PX4) using our voxl-esc tools (https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/tree/master/voxl-esc-tools) which works directly on VOXL2 or a standalone linux PC (or mac). voxl-esc-spin.py has a --power argument where you specify the power from 0 to 100, which translates directly to the average duty cycle applied to the motor. Here is the calibration for the Starling V2 motor / propeller that we use: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/master/voxl-esc-params/mavic_mini_2/mavic_mini_2.xml?ref_type=heads#L63 Also, you can take a look at this post to see how to interpret those parameters a0, a1, a2 : https://forum.modalai.com/topic/2522/esc-calibration/2 We also have some dyno tests for this motor / propeller : https://gitlab.com/voxl-public/flight-core-px4/dyno_data/-/blob/master/data/mavic_mini2_timing_test/mavic_mini2_modal_esc_pusher_7.4V_timing0.csv . We are not sure how accurate that is, but it can be used as a starting point. @James-Strawson can you please confirm that is the correct dyno data for the Starling V2 motors? Alex
  • Latency bug in voxl-mavlink-server

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    H
    @Eric-Katzfey thanks for the 2 fixes in a single package! Will try it out and report back tmr
  • GPS Issues w/ VOXL 2 PX4 (M8N and Here+)

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    Eric KatzfeyE
    @majjam Okay, so I'm guessing that you are using 0.9.5 then? The only known issue with those Holybro GPS units was the baudrate thing. Some units are not set at 115200 so the command to start the gps with that baudrate will fail on units with a different baudrate setting. Changing the start line to remove the forced 115200 and let the driver choose the correct baudrate on it's own was the resolution of that issue. Beyond that we are not aware of any other issues. Can you verify that the M8N unit is working on another platform? Can you use an oscilloscope on the M8N UART TX line and see any activity?
  • VOXL1 and VOXL2 hardware fitting on m500 drone

    Unsolved
    7
    0 Votes
    7 Posts
    551 Views
    Darshit DesaiD
    @Vinny @wilkinsaf Thank you for your responses. This clarifies a lot of my questions.