Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Stream the video data via WIFI

    Unsolved
    2
    0 Votes
    2 Posts
    639 Views
    Eric KatzfeyE
    @Ruijie-Geng Yes, you certainly can. However, using WIFI usually results in local IP addresses which are not routable over the Internet. For someone to connect to your WIFI video stream from the Internet you will need to make your IP address visible to the Internet. There are different ways to accomplish this but we usually use a VPN for this purpose. We have some documentation on VPN use with Voxl here: https://docs.modalai.com/voxl-vpn/
  • This topic is deleted!

    2
    0 Votes
    2 Posts
    2 Views
  • error compiling voxl-vision-px4 from source

    Unsolved
    8
    1
    0 Votes
    8 Posts
    2k Views
    tomT
    @Aldo-Castro-Freire Great to hear!
  • Mavlink Telemetry Routing, port selection

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Aldo Castro FreireA
    Yes, I tried apparently master and v0.68 of the code are different while in master is not hardcode the udp port. For v0.68 it is hardcode. So I assumed my version is hardcode because nothing seem to change. Do I need to delete my voxl-vision-px4? To install a new custom version?
  • Does voxl support Retractable Landing Gear

    Unsolved
    6
    0 Votes
    6 Posts
    950 Views
    Chad SweetC
    I think you mean you would prefer that VOXL supports PCA9865 natively. We have an I/O library ready to go, libvoxl_io. voxl-i2c is an application that is an example of using libvoxl_io for i2c commands. One would need to implement the PCA9865 i2c protocol using libvoxl_io to control that part externally from VOXL. As mentioned previously, Flight Core has native PWM support if you were to send over MAVLink
  • Missing sensor-imu

    Unsolved
    4
    0 Votes
    4 Posts
    958 Views
    ray tsouR
    @Chad-Sweet This works, thanks. When will this be fixed?
  • ESC Calibration issues

    Unsolved
    29
    0 Votes
    29 Posts
    8k Views
    modaltbM
    Hi @Riley-Dove , Want to try to do a screen share tomorrow AM? I'll send an email to what's registered on this account. Some of the errors looked like config file parsing, but the first one was truncated a bit. If the device is in the failed currently, and you don't mind, you can throw the output of systemctl status voxl-vision-px4 -l here in preps. Thanks, we'll figure out what's going on!
  • Voxl I2C port implementation

    Unsolved
    1
    0 Votes
    1 Posts
    395 Views
    No one has replied
  • Mapping

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    Chad SweetC
    I think you'll need to reflash the system image. From your previous posts it sounded like ADB goes away consistently after a few minutes. If you can't get to ADB after reboot, then it sounds like it's bricked. See here: https://docs.modalai.com/unbrick-voxl/
  • offboard mode in voxl m500

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    modaltbM
    @mr-TOKI , Are you taking off and trying to fly first to 0.3m? Takeoff is a somewhat of a “jerky” maneuver. You can imagine that the flight controller will begin respond quickly, but there are still some factors that could make a takeoff “vary” and thus not have an immediate perfect response. Takeoff and then a halt at 30cm is pretty aggressive.
  • Update GCC to use C_make_standard 17

    Unsolved
    1
    1 Votes
    1 Posts
    518 Views
    No one has replied
  • Streaming video over LTE

    Unsolved
    15
    0 Votes
    15 Posts
    2k Views
    tomT
    Yes you can use vi on VOXL
  • I cannnot access mavlink console

    Unsolved
    3
    0 Votes
    3 Posts
    571 Views
    Aldo Castro FreireA
    I am not sure I usually can read the contents from the sd-card it is just weird to me that i cannot enter any command on the shell when the sd_card is on
  • VOXL flight deck + toF Positioning

    Unsolved voxl-flight tof 3d print
    3
    0 Votes
    3 Posts
    2k Views
    G
    Thank you so much for this. This was of great help @Chad-Sweet
  • Modem LTE support

    Unsolved
    1
    1 Votes
    1 Posts
    536 Views
    No one has replied
  • Streaming data from multiple IMUs to QGroundControl

    Unsolved
    5
    0 Votes
    5 Posts
    2k Views
    modaltbM
    Hi @Daniel-Gauthier , Partial answers here but hopefully can git things moving. Also, I'm making assumptions here that you are OK "opening up the hood" and modifying code Consider voxl-imu-serverand the two IMUs on VOXL as not accessible via PX4/QGC. Let me reach out to a colleague who's more in this area and I'll get back to you. We have some tools in the works for logging VOXL IMUs (and other) data easily on the VOXL side. I'll need to touch base on timeline, we are looking for a mid-end Feb release but have a developer channel that you could use if you're OK with pre-release SW (e.g. not ready for prime time...). OK for the PX4 side I'm more versed on. The 42688p driver is here: At least in v1.10 and v1.11, PX4 uses a single IMU as input to EKF2. Whatever has the highest priority and is functional.... A little silly, but the two extra IMUs on there are from the v5x design spec which we were asked to try to implement, but are used as 'backups' basically.. and thus far I don't believe the backups have been used.... So it's really based on a sensor priority (which ICM42688 and ICM20648 share the same) and what sensor is started first (right now, 20602). --> https://github.com/PX4/PX4-Autopilot/blob/master/boards/modalai/fc-v1/init/rc.board_sensors#L13 You can change the order here/comment out sensors, and it will change the default IMU being used. For validation testing, I commented out the 20602 line. So, to make the 42688p default, make it startup first in that script. Here's the 42688p driver for PX4: --> https://github.com/PX4/PX4-Autopilot/tree/master/src/drivers/imu/invensense/icm42688p Here's the 42688p driver for VOXL: -> https://gitlab.com/voxl-public/modal-pipe-architecture/voxl-imu-server/-/blob/master/server/src/icm42688.c Keep questions coming and we'll get to them!
  • GPS not acquiring

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    Daniel RyuD
    Resetting the parameters to outdoor mode seemed to have worked! The GPS acquired a signal and I am able to fly in Mission mode. Thank you!
  • Connecting WiFi in station mode on a secure network

    Unsolved
    3
    0 Votes
    3 Posts
    826 Views
    Daniel GauthierD
    Thanks Chad. I was being a dunderhead. I will using the SSID and password for the drone, not my local network. Just got it working.
  • ToF sensor

    Unsolved ros tof
    29
    1
    0 Votes
    29 Posts
    9k Views
    modaltbM
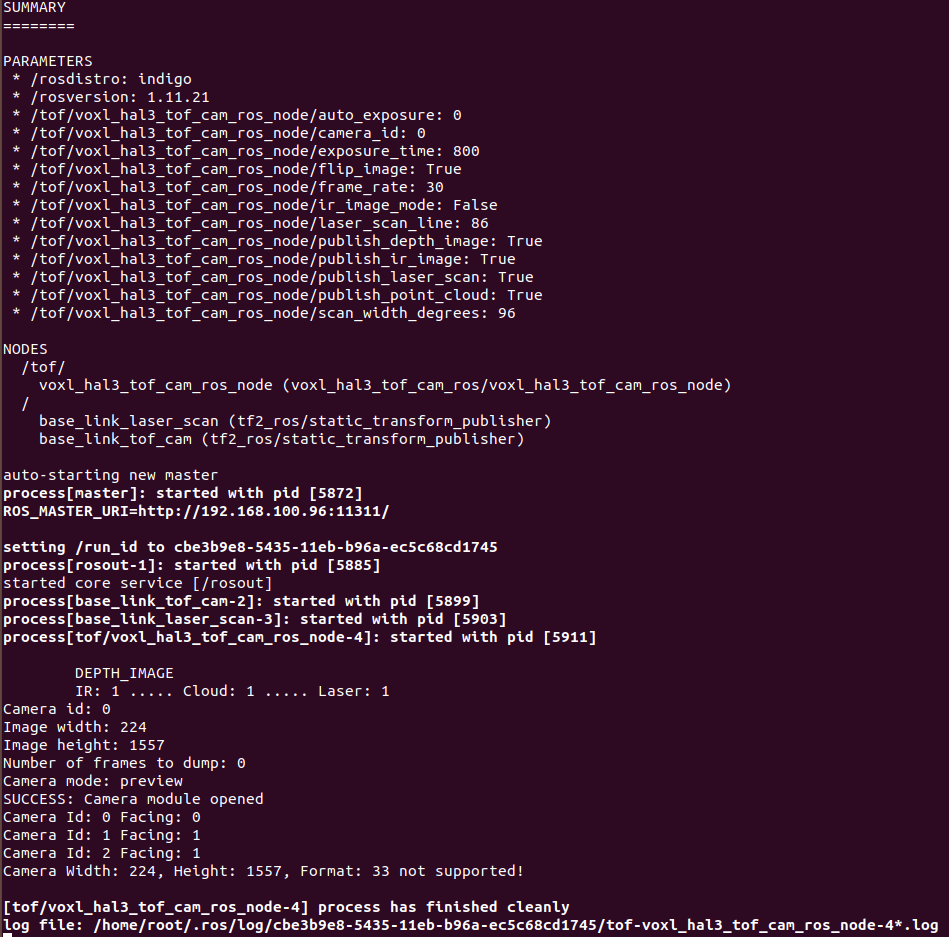
    Hi @gauravshukla914 , Thanks for the help with this. We've released a new beta version of the voxl-hal3-tof-cam-ros that supports auto detection of ToF and defaults the persist.camera.modalai.tof setting properly. It will be in out next voxl-suite release, but is available from our dev channel here if you are interested in using this link The updated readme is here. Thanks!
  • Simulation Software for drones

    Unsolved
    2
    1 Votes
    2 Posts
    651 Views
    modaltbM
    Hi @SHAURYA-PANTHRI , We don't have a model for Gazebo, but the frame is essentially a Holybro s500, and there may be some out there. I've used JMAVSim a bit and it works well. We have a HIL tutorial here: https://www.youtube.com/watch?v=-uoIxAkiYtk That might be a little overkill and software in the loop might work: https://dev.px4.io/v1.11/en/simulation/#sitl-simulation-environment I'm actually pretty new to flying still. The m500 at first was intimidating for me (I'd come into the office early before everyone else so I could fly without any pressure haha ;). I bought a little toy $25 USD drone off amazon and flew that at home for a while, and then moving to the m500 was actually pretty easy!