Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • PX4 stopped working

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    G
    @modaltb Yes you're right. Its not connecting to QGC via usb too.
  • LTE concurrent with Microhard

    2
    0 Votes
    2 Posts
    455 Views
    tomT
    It is possible to run concurrent LTE and Microhard connections on VOXL. This can be accomplished using a combination of the two modems, either with an add-on LTE modem and a standalone Microhard modem plugged in to the add-on or an add-on Microhard modem with a standalone LTE modem plugged in to the add-on. In order for both networks to start correctly, the LTE network will need to be brought up first, then the Microhard network. This can be set up easily by creating a custom startup service. The LTE network will use the wwan0 network interface while the Microhard network will use the eth0 network interface.
  • Trouble configuring m500 into Station Mode

    Unsolved
    12
    1
    0 Votes
    12 Posts
    3k Views
    Eric KatzfeyE
    @Alfonso-Ponce We don't have any recommendations on how to create such a mobile application. However, whatever path you choose, you will most likely need the app to be sending Mavlink packets to the drone to carry out the instructions. Also, QGroundControl can be run as a mobile app and it is open source so you could look to that as an example.
  • Collision prevention

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    modaltbM
    The only lower bound I've seen is 20cm here: https://gitlab.com/voxl-public/modal-pipe-architecture/voxl-vision-px4/-/blob/master/src/voa_manager.c#L165 So I'm still puzzled. If you debug stereo, what kind of data are you seeing? https://docs.modalai.com/voxl-vision-px4-collision-prevention/#debug-tools
  • Can I develope VOXL in a Docker using Windows?

    Unsolved
    3
    2
    0 Votes
    3 Posts
    872 Views
    Eric KatzfeyE
    You could also convert the script into a Windows batch file or some other Windows scripting language. But there are Debian specific things in the script file that you would need to convert to the Windows alternative. For example, there are package management commands (apt) that would need to be changed into something for Windows and you would need to use the Windows version of QEMU. This could be a challenging task!
  • Running MAVROS and building other ROS nodes

    Unsolved
    3
    0 Votes
    3 Posts
    960 Views
    K
    @Voxlady Thanks for the clarification I'll report my findings here.
  • Connect a modem using USB

    Unsolved
    2
    0 Votes
    2 Posts
    575 Views
    Chad SweetC
    A lot of effort goes in to supporting a new modem on a companion computer. The kernel needs to be modified, drivers need to be developed. We sell specific accessories that we put that effort in to so they can work with VOXL. Without knowing what type of modem you are trying to connect, it is difficult to suggest where to begin. Some things that might help: What type of modem is it? What interface are you connecting with? USB, serial or Ethernet? Does it have an available Linux driver? If it is USB, and you type 'lsusb', does it appear?
  • Running PX4 on VOXL without Flight Core

    Unsolved
    2
    0 Votes
    2 Posts
    642 Views
    Chad SweetC
    The short answer is yes, the long answer is that it is probably a decent amount of work. PX4 1.9 builds and runs for this platform, but may not fly. With that build, you need UART based ESCs like we have here: https://modalai.com/esc Mid-PX4 1.10 development c++14 was introduced. The SLPI compiler does not support c++14. IMO it would be fairly straight-forward to either comment out that code (it's for simulation), or just use boost to fix the issue. We just haven't done that or put much effort into it. You can take a look here: branch https://github.com/PX4/Firmware/commits/excelsior_1.9 Build the firmware with "make atlflight_excelsior_default" to build the posix side and "make atlflight_execelsior_qurt-default"
  • Does EM9190 or EM9190 modules works with voxl modem

    Unsolved
    2
    0 Votes
    2 Posts
    531 Views
    modaltbM
    No, those are PCIe interfaced, so form factor wouldn't plug in. The "WP" series is the correct form factor, we've tested against 7610 and 7607, but there are more listed: https://source.sierrawireless.com/devices/wp-series/wp7610/
  • is there any 5G Modem ?

    Unsolved
    2
    0 Votes
    2 Posts
    735 Views
    tomT
    Hi @Aldo-Castro-Freire , We don't support any 5G modems on VOXL today, however we expect to in the next few months.
  • Unable to access Tracking camera

    Unsolved flight-dec tracking-camera voxl-3.1.0
    5
    2
    0 Votes
    5 Posts
    2k Views
    A
    @Chad-Sweet [image: 1620141446462-img_20210504_100858-1.jpg] These are default connection on the board yocto:/# voxl-configure-cameras 3 attempting to use camera configuration 3 adding override_cam_id value=1 to /etc/snav/camera.downward.xml adding override_cam_id value=2 to /etc/snav/camera.stereo.xml yocto:/# cat /etc/modalai/camera_env.sh export CAM_CONFIG_ID=3 export HIRES_CAM_ID=0 export TRACKING_CAM_ID=1 export STEREO_CAM_ID=2 export TOF_CAM_ID=-1 After setting configuration to 3 as well yocto# roslaunch voxl_cam_ros tracking ... logging to /home/root/.ros/log/1f7737e8-ad09-11eb-b4a1-ec5c68cd1745/roslaunch-apq8096-3742.log Checking log directory for disk usage. This may take awhile. Press Ctrl-C to interrupt Done checking log file disk usage. Usage is <1GB. started roslaunch server http://192.168.100.90:46578/ SUMMARY ======== PARAMETERS * /rosdistro: indigo * /rosversion: 1.11.21 * /tracking/voxl_cam_nodelet/cam_id: 0 * /tracking/voxl_cam_nodelet/cam_name: tracking * /tracking/voxl_cam_nodelet/frame_id: tracking_frame * /tracking/voxl_cam_nodelet/frame_rate: 15 * /tracking/voxl_cam_nodelet/height: 480 * /tracking/voxl_cam_nodelet/is_cam_master: False * /tracking/voxl_cam_nodelet/skip_n_frames: 0 * /tracking/voxl_cam_nodelet/snav_raw10_compatability: True * /tracking/voxl_cam_nodelet/width: 640 NODES /tracking/ tracking_nodelet_manager (nodelet/nodelet) voxl_cam_nodelet (nodelet/nodelet) auto-starting new master process[master]: started with pid [3761] ROS_MASTER_URI=http://localhost:11311/ setting /run_id to 1f7737e8-ad09-11eb-b4a1-ec5c68cd1745 process[rosout-1]: started with pid [3774] started core service [/rosout] process[tracking/tracking_nodelet_manager-2]: started with pid [3780] process[tracking/voxl_cam_nodelet-3]: started with pid [3788] [ INFO] [1620154027.140051685]: Initializing nodelet with 4 worker threads. [ INFO] [1620154027.459145704]: SnapCamDriver Starting [ INFO] [1620154027.459566279]: Monotonic offset: 1620153449.753732686 libcam.enable.publish 1 libcam.enable.publish.dump 0 libcam.publish.buffer.policy max libcam.publish.buffer.max 3 libcam.debug.level info libcam.dump.dir /data/misc/camera/dumps ERROR: could not open camera subscriber for cam id 0 [ERROR] [1620154044.976910041]: CameraManager::Initialize() failed [ERROR] [1620154044.977876660]: Unable to open camera.
  • I messed up the voxl-vision-px4.conf file

    Unsolved
    4
    1
    0 Votes
    4 Posts
    974 Views
    modaltbM
    @Alfonso-Ponce the -f is for a factory setup (a quick way for us to set the default configuration for the m500 drones)
  • Failed to start Stereo Camera Nodelet

    Unsolved ros camera
    12
    0 Votes
    12 Posts
    3k Views
    K
    nothing else has changed.
  • ADB no device showing in terminal

    Unsolved
    16
    0 Votes
    16 Posts
    3k Views
    modaltbM
    Hi @Sébastien-de-Pret-Roose-de-Calesberg , I'll get an email going to this address on this account, I'm not clear what's going on and perhaps we need to send it in. Thanks and sorry for the inconvenience, Travis
  • Binning Camera Data

    Unsolved
    1
    0 Votes
    1 Posts
    494 Views
    No one has replied
  • Camera configuration error

    Unsolved flight-deck camera
    1
    0 Votes
    1 Posts
    1k Views
    No one has replied
  • VIO altitude estimation error

    Unsolved
    2
    0 Votes
    2 Posts
    778 Views
    Chad SweetC
    It is likely there were not stable visual features on takeoff. A field of grass is not that great for visual feature tracking. You could try putting something in front of the drone on the ground for it to look at and see if that helps
  • How to get m500 to station keep

    Unsolved
    2
    0 Votes
    2 Posts
    462 Views
    Chad SweetC
    It sounds like you are putting the drone into offboard mode, with the offboard mode set to "figure_eight". https://docs.modalai.com/voxl-vision-px4-other-features/ You shouldn't need to be in offboard mode to use the apriltag relocalization, see here: https://docs.modalai.com/voxl-vision-px4-apriltag-relocalization/
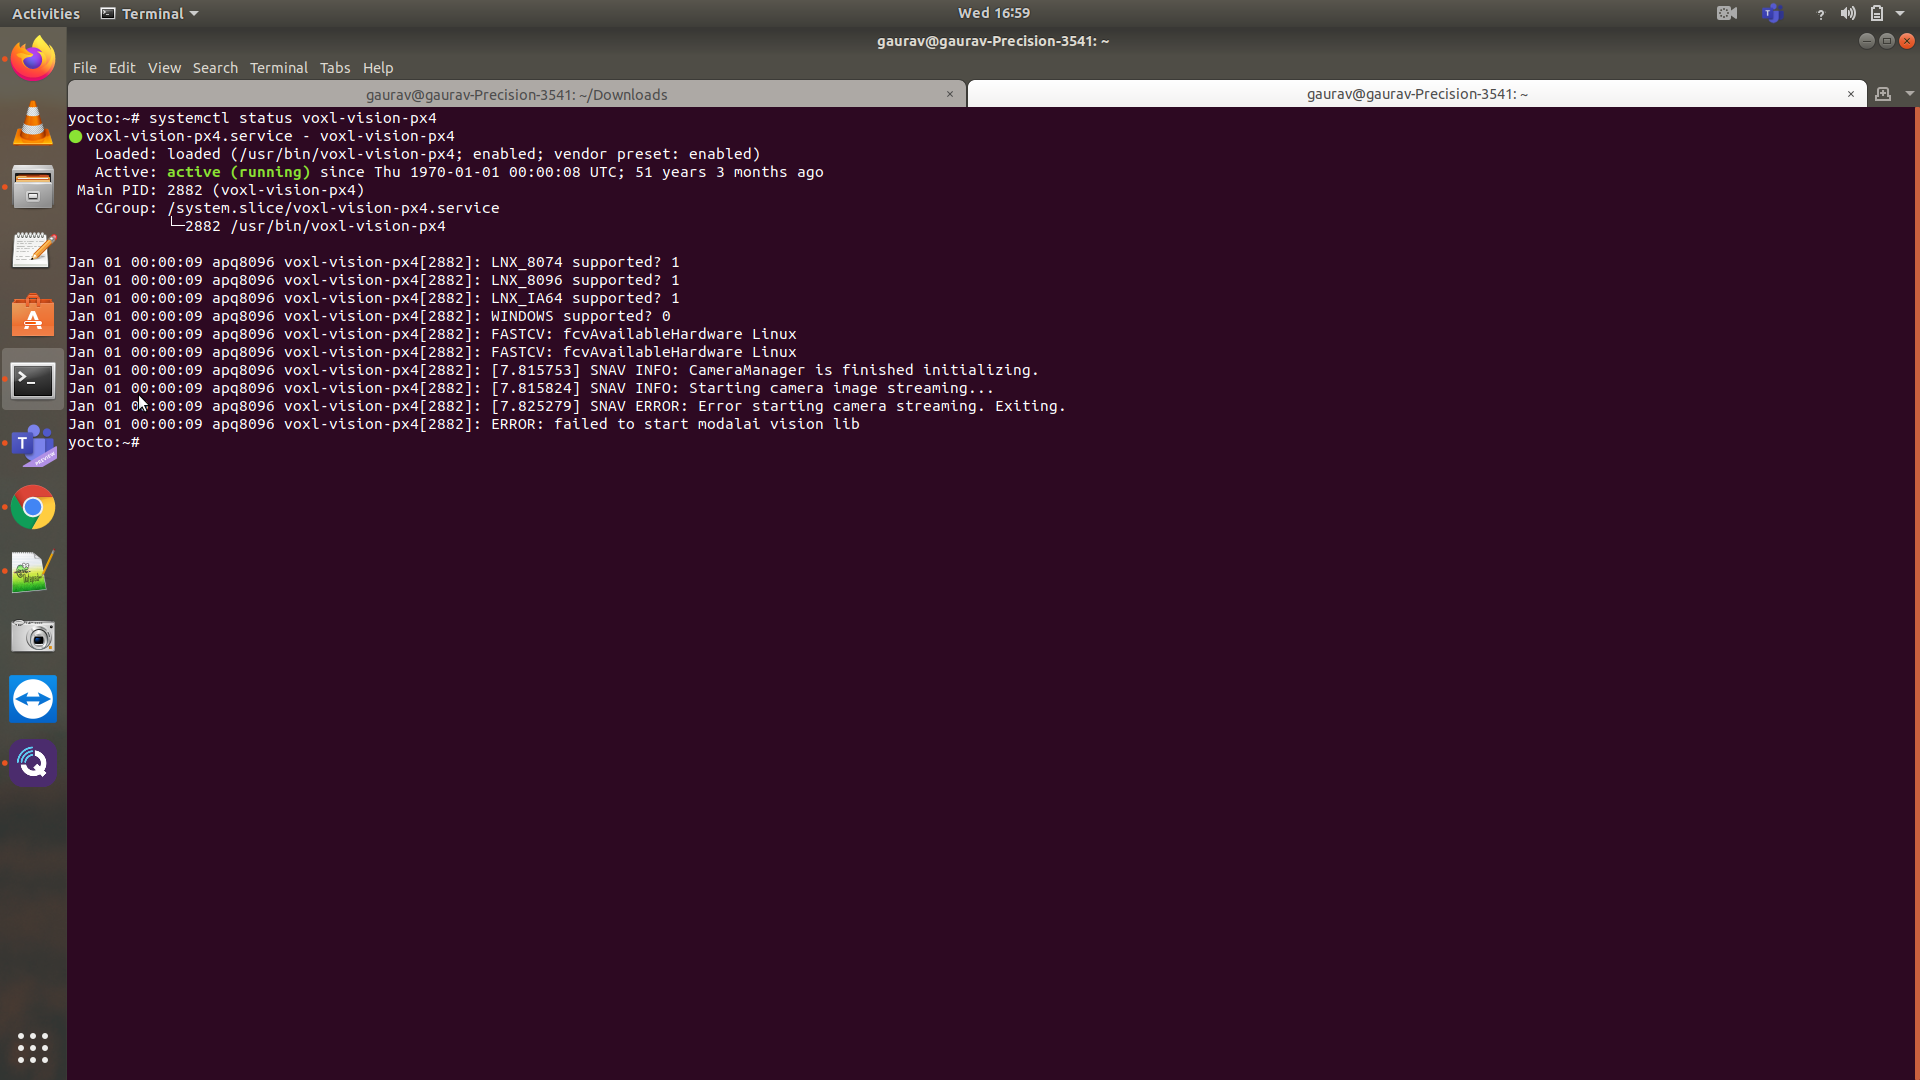
  • ERROR: failed to start modalai vision lib

    Unsolved
    1
    1
    0 Votes
    1 Posts
    552 Views
    No one has replied
  • Moving M500 to 250mm vehicle

    Unsolved

    4
    0 Votes
    4 Posts
    983 Views
    modaltbM
    Hi @kiprock , The motor test commands I've used were from the MAVLink shell, but using the pwm test command: https://dev.px4.io/master/en/middleware/modules_command.html#pwm I've seen similar issues when trying to use the built in QGC PWM calibration feature... Since the Flight Core v1 can't be powered over USB (an artifact of sharing the 5VDC rail with VOXL when paired together and the fact that 500mA isn't enough to juice VOXL), it requires the python util that you linked above.