Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Seeker maps its own props in Voxl-mapper

    Unsolved
    2
    1 Votes
    2 Posts
    570 Views
    C
    Here are some pictures of the issue. Did some more testing and it might not be the props as I tested with the props off and the close points are still there. Is there something wrong or blocking the TOF sensor on the seeker? [image: 1668213067386-screenshot-from-2022-11-11-17-07-51.png] [image: 1668213085769-screenshot-from-2022-11-11-17-11-39.png]
  • Estimated delivery time

    Unsolved
    2
    0 Votes
    2 Posts
    524 Views
    Adrian HidalgoA
    @wxyLuna we do offer express delivery. If you would like an estimated time and cost I would send an email to contact@modalai.com with your preferred selection of drone config and address. The ten days you are referring to is the estimated lead time to build the drone, not shipping time duration. We build each drone to order, making sure the product is built to our high standards.
  • How to increase i2c frequency -> no "bus_clk_rate" file to edit?

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    tanguy sagereT
    @modaltb Hey! Thank you for the reply ahaha, I understand its a busy quarter for everyone We are connecting the IMU to the I2C3 pins of the J9 6-pin pinout of the 5G Modem. On other devices (such as the jetson AGX orin) we are able to get a data rate of 928 hz , but on the VOXL its stuck at around 628 Hz in ROS. For the ORIN we were able to increase the rate by modifying a bus_clk_rate file in /sys/bus/i2c/devices/i2c-1 but there appears to be no equivalent here. I found a voxl_i2c_write function in your docs that looks like it could increase I2C bus rate, but unsure how to access and use it. Also tried changing the device tree file to increase the rate ceiling and making a .patch to change it and add changes to kernel_patches but that dropped the rate to 120-ish, and never increased it. Quite confusing! Thanks for your time and have a nice day!
  • Subscribe data from added sensor?

    Unsolved
    3
    0 Votes
    3 Posts
    640 Views
    W
    Thank you. Also for the purchase delivery, how fast can a m500 order arrive to Illinois? 10days? Is express delivery available?
  • RC Module (MCCA-M0094-2) Datasheet

    2
    0 Votes
    2 Posts
    412 Views
    VinnyV
    We just made a new page for the M0094 product. Please check out the following link for a detailed description of the M0094 board and the pin tables for both RB5 Flight and Sentinel drone platforms. https://docs.modalai.com/sentinel-spektrum-bind-board/ Thanks!
  • Overriding in-use UART ports

    Unsolved
    5
    1
    0 Votes
    5 Posts
    1k Views
    modaltbM
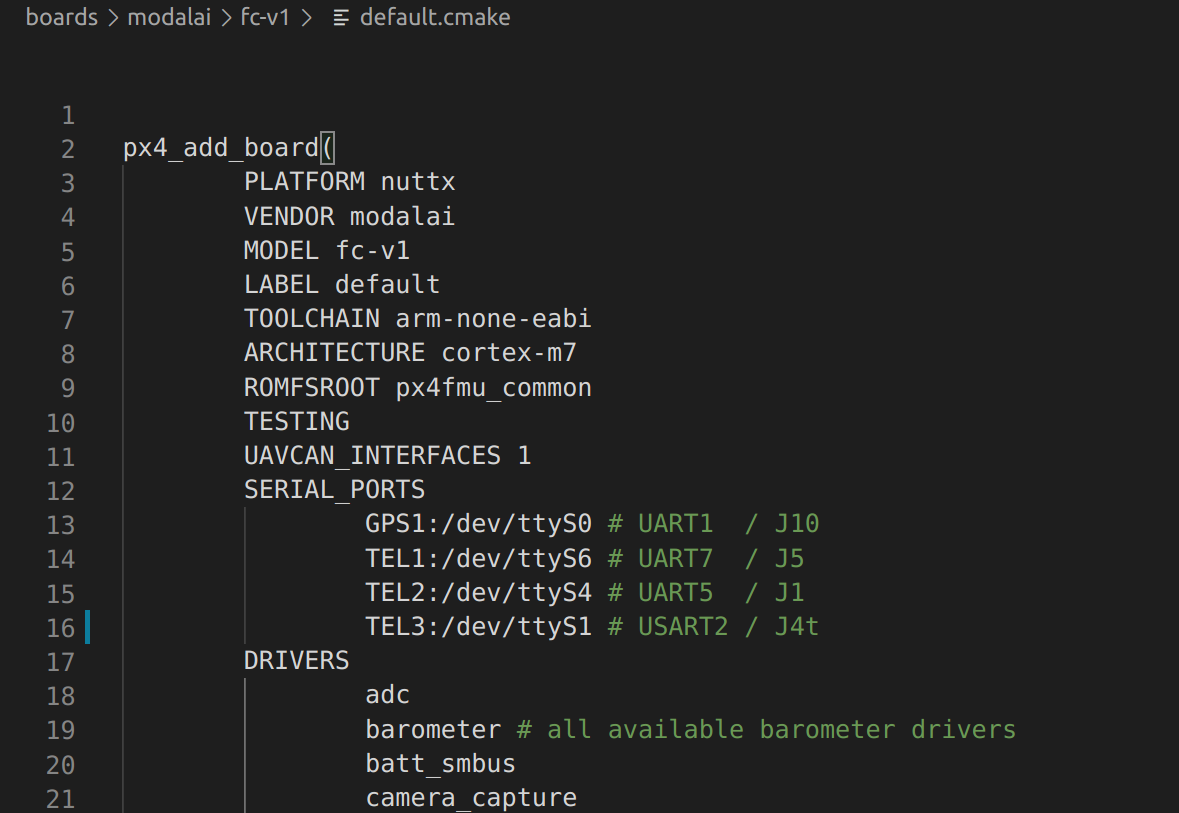
    @Sem-Andeweg I haven't personally tried, but: J4 on Flight Core is by default a TELEM3 so should be OK to just use (3.3V TTL) https://docs.modalai.com/flight-core-datasheets-connectors/#j4---uart-esc-uart2telem3 J2 by default is the nuttx shell interface. I have always left this as I use it for debug.... but I believe you could remap it. There are some limitations on number of MAVLink instances in PX4, but both your use cases above sound like "not MAVLink", so it would be a matter of messing around with the source code a bit.
  • HITL FTDI Cable

    Unsolved
    3
    0 Votes
    3 Posts
    743 Views
    Taylor PresleyT
    Thanks Eric!
  • Qualcomm Flight™ RB5 5G Platform Drone

    Unsolved
    3
    0 Votes
    3 Posts
    859 Views
    Suvasis MS
    @tom to customize the payload to say 2-5kg, is it possible to customize or reconfigure another drone with voxl2 and 5g modem etc?
  • Is the camera driver source code public?

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    modaltbM
    Build time
  • Create Cloned Backup Image from VOXL?

    Unsolved
    2
    0 Votes
    2 Posts
    644 Views
    Chad SweetC
    We do not currently have that tool
  • How to send the GPS data to the Drone

    Unsolved
    2
    0 Votes
    2 Posts
    697 Views
    Chad SweetC
    You will have to study PX4 architecture and work through the code to create a new type of GPS input Did you go through the VIO troubleshooting steps? https://docs.modalai.com/flying-with-vio/#troubleshooting-vio
  • Can't Connect to QGC Microhard

    Unsolved
    3
    3
    0 Votes
    3 Posts
    808 Views
    Z
    nvm, solved it. Had to enable and run the service voxl-mavlink-server first, then do the same with the voxl-vision-px4 service. I'll leave this here for posterity
  • Mapping and planning using TOF sensor

    Unsolved
    2
    0 Votes
    2 Posts
    628 Views
    ?
    Hi, While we so technically support mapping using stereo we almost always use the tof sensor ourselves since it's much more accurate at higher resolutions. The default for our voxl-mapper project uses the tof sensor for mapping with option to enable stereo if that's what you want to use. We generally just use stereo for collision prevention since it's pretty reliable at detecting if something is in front of it or not but can struggle to populate a detailed full-fov image in realtime.
  • Does VOXL2 support UAVCAN?

    Unsolved
    3
    0 Votes
    3 Posts
    631 Views
    Patrick HincheyP
    Thanks Eric, I'll look into the legacy mode
  • Does VOXL series drone development board support makroBUS interface?

    Unsolved
    3
    0 Votes
    3 Posts
    706 Views
    Suvasis MS
    Sorry it's mikrobus.
  • SSH Halloween theme

    Unsolved
    3
    1
    2 Votes
    3 Posts
    785 Views
    Patrick HincheyP
  • Camera auto-exposure configuration

    Unsolved
    1
    0 Votes
    1 Posts
    277 Views
    No one has replied
  • Seeker drone "backtracking" when it stops to hover

    Unsolved
    3
    1
    0 Votes
    3 Posts
    495 Views
    H
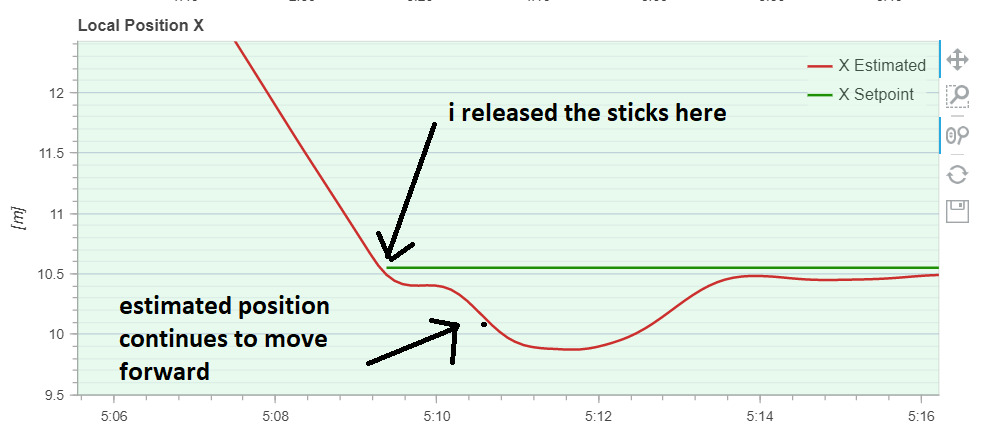
    @Steve-Turner said in Seeker drone "backtracking" when it stops to hover: I don't work for Modal, so take this with a grain... MPC_POS_MODE controls some of this behavior. https://docs.px4.io/v1.12/en/advanced_config/parameter_reference.html has a description and you can try the other options to see how that influences the behavior. https://docs.px4.io/v1.9.0/en/config_mc/advanced_mc_position_tuning.html Should help with some of the tuning parameters that control position behavior. Additionally, the PID loop for position might need some tuning if you want it to stop more aggressively. Thanks for the suggestion but I'm quite certain it has nothing to do with MPC_POS_MODE nor the tuning of the velocity/position controller. The phenomenon I described only happens sometimes - especially when VIO quality is low for that stretch of journey just before the drone comes to a stop
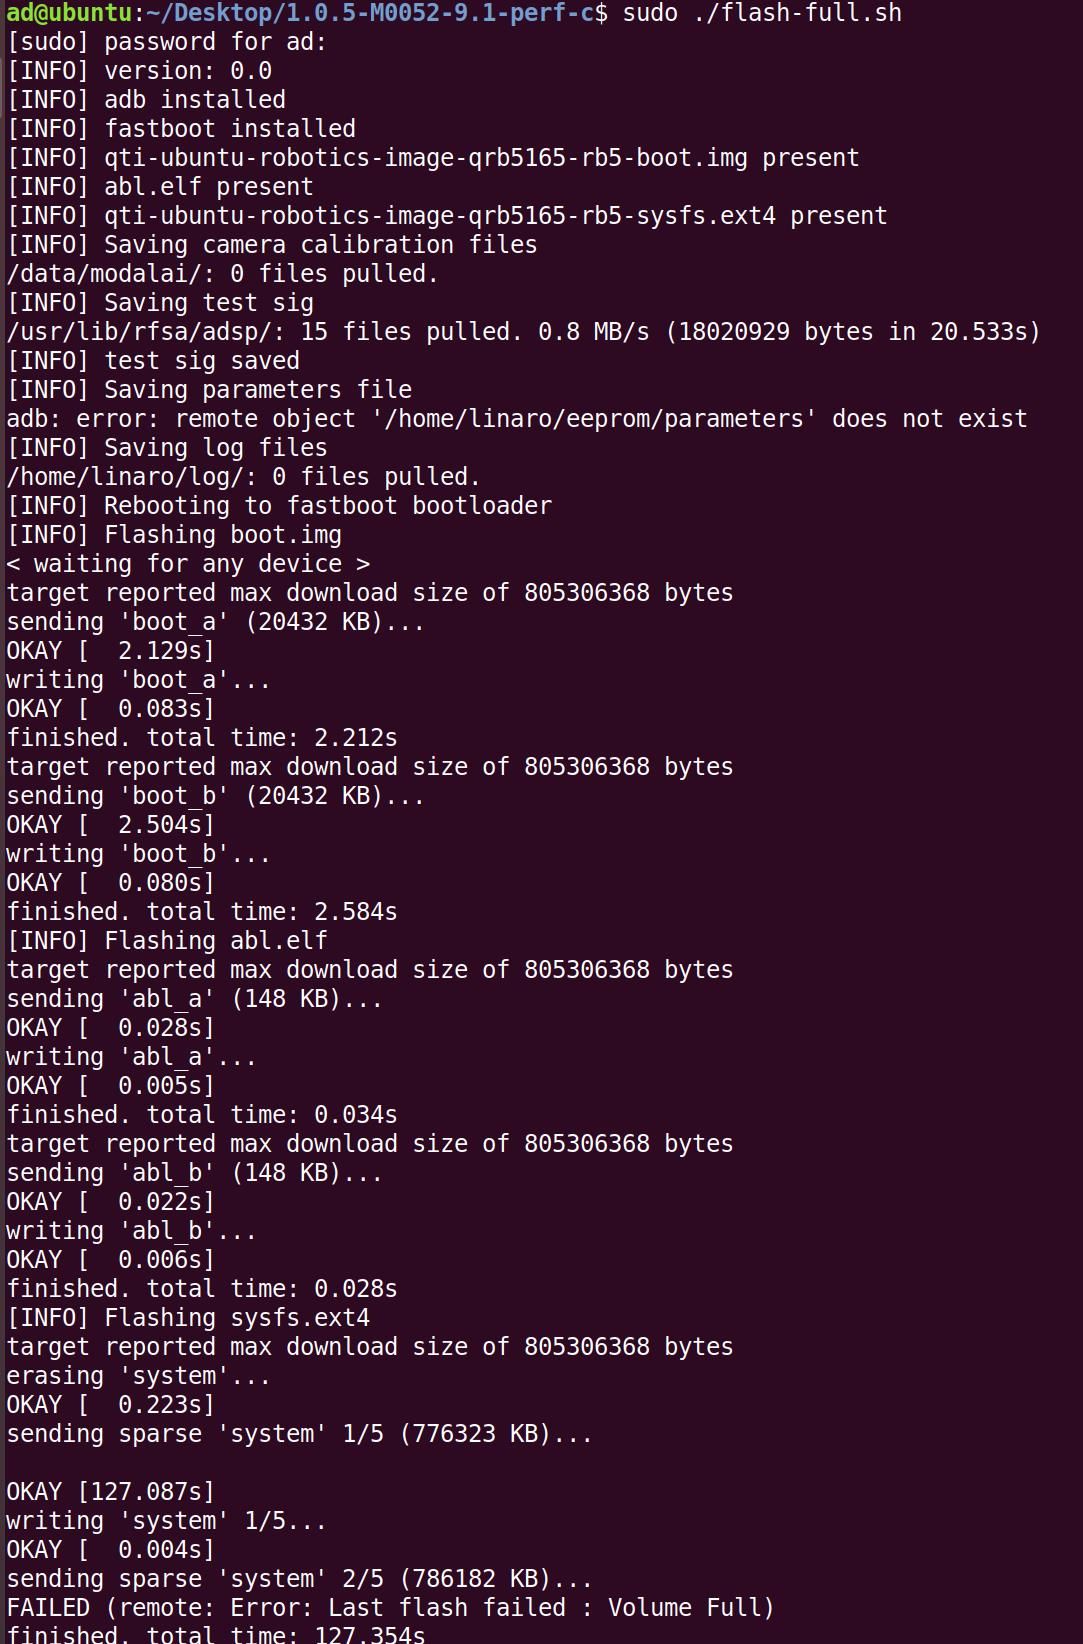
  • full-flash.sh occur Last flash failed:Volume Full

    Unsolved
    4
    1
    0 Votes
    4 Posts
    1k Views
    tomT
    @yitakabe Can you post either a screenshot or copy/paste the error you're seeing?
  • Pi or Jetson companion computer installation and interfacing step-by-step

    Unsolved
    4
    0 Votes
    4 Posts
    899 Views
    Chad SweetC
    OK. We don't have a documented way, but VOXL 2 is a Linux computer. So you could use some form of networking: ROS or other. There are also UARTs, etc