
Seeker drone "backtracking" when it stops to hover
-
Hi devs
I have a Seeker drone and i have been testing it extensively indoors with VIO. It works well enough in most situations and im happy with it. But i have been witnessing a behavior sometimes that i could not understand why.
After flying for some distance in Position mode, i would release the sticks and let the drone hover in place. When i do that, sometimes the drone "backtracks" (heading does not change) a little (as much as 1 metre sometimes).
I pulled out the flight logs and saw:
-When i release the sticks, the setpoint is set and PX4 activates its position controller. When the Seeker was moving it was using the velocity controller
-The local position estimate continued propagating forward in the direction of my stick although i have already released it.
-The drone responds by correctly reversing/"backtracking" to hover at the setpoint position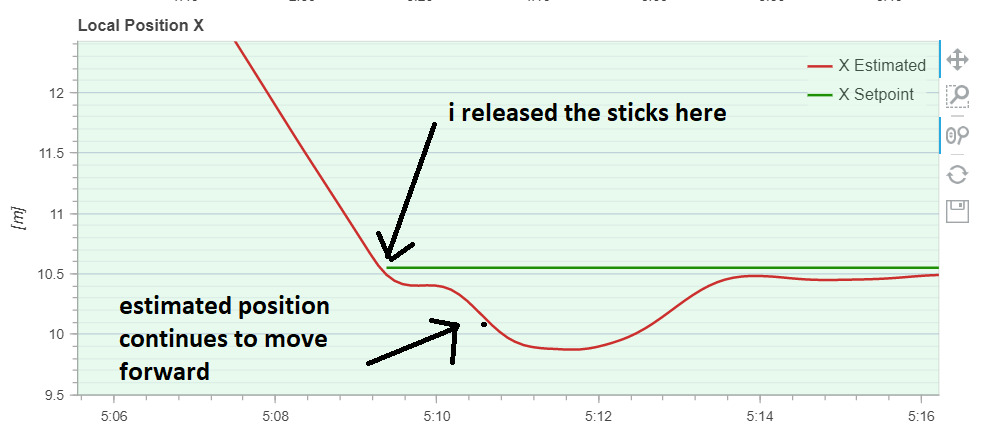
How could i minimize/prevent this from happening?
-
I don't work for Modal, so take this with a grain...
MPC_POS_MODEcontrols some of this behavior. https://docs.px4.io/v1.12/en/advanced_config/parameter_reference.html has a description and you can try the other options to see how that influences the behavior.https://docs.px4.io/v1.9.0/en/config_mc/advanced_mc_position_tuning.html Should help with some of the tuning parameters that control position behavior.
Additionally, the PID loop for position might need some tuning if you want it to stop more aggressively.
-
I don't work for Modal, so take this with a grain...
MPC_POS_MODEcontrols some of this behavior. https://docs.px4.io/v1.12/en/advanced_config/parameter_reference.html has a description and you can try the other options to see how that influences the behavior.https://docs.px4.io/v1.9.0/en/config_mc/advanced_mc_position_tuning.html Should help with some of the tuning parameters that control position behavior.
Additionally, the PID loop for position might need some tuning if you want it to stop more aggressively.
@Steve-Turner said in Seeker drone "backtracking" when it stops to hover:
I don't work for Modal, so take this with a grain...
MPC_POS_MODEcontrols some of this behavior. https://docs.px4.io/v1.12/en/advanced_config/parameter_reference.html has a description and you can try the other options to see how that influences the behavior.https://docs.px4.io/v1.9.0/en/config_mc/advanced_mc_position_tuning.html Should help with some of the tuning parameters that control position behavior.
Additionally, the PID loop for position might need some tuning if you want it to stop more aggressively.
Thanks for the suggestion but I'm quite certain it has nothing to do with MPC_POS_MODE nor the tuning of the velocity/position controller. The phenomenon I described only happens sometimes - especially when VIO quality is low for that stretch of journey just before the drone comes to a stop
Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login