Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Adb shell not working on Starling Drone

    Unsolved starling
    6
    1
    0 Votes
    6 Posts
    1k Views
    VinnyV
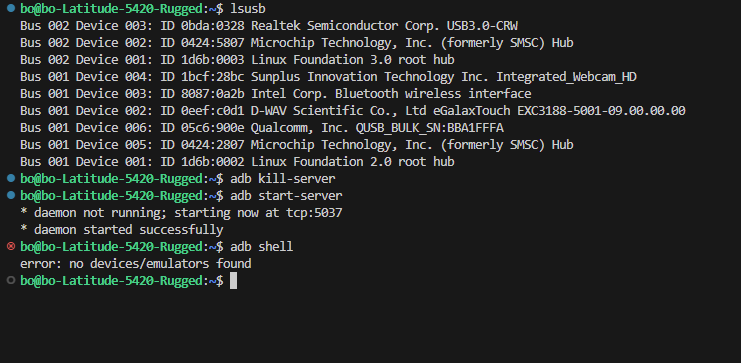
    Hi @riteshsharma We usually recommend a small screwdriver (flat edge) or tweezers to actuate those small switches. For the FASTBOOT switch, you need to use something less likely to break the top plastic, so the back end of a qtip or a pencil is good for that one.
  • Sentinel Drone Rangefinder

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    815 Views
    Chad SweetC
    Hi Erik, thanks for pointing that out. It was a mistake, it has now been fixed as there are no CH-201 sensors
  • Question on Sentinel Battery Compatibility

    Unsolved sentinel
    5
    0 Votes
    5 Posts
    906 Views
    ModeratorM
    @jmltt no, if you use the standard battery all should work as expected
  • qvio error: IMU_MISSING STALLED

    Unsolved rb5
    8
    10
    1 Votes
    8 Posts
    2k Views
    S
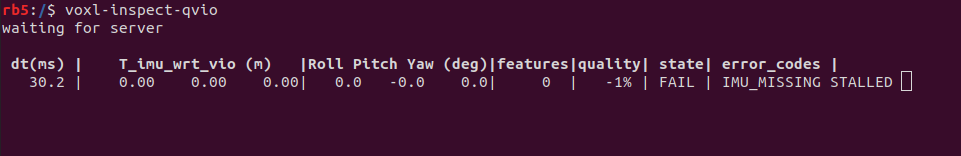
    @tom thanks tom! with voxl-configure-sku -w I assumed the option to select is 6) px4-autonomy-dev-kit i then ran voxl-configure-mpa saw a few errors but the qvio is working now with no errors. Sabri
  • Need Help Troubleshooting Failed First Flight Attempt

    Unsolved sentinel
    3
    0 Votes
    3 Posts
    716 Views
    J
    @Alex-Kushleyev Thanks for getting back to me I can't fly again until tomorrow but I will upload the log after we attempt a hover test. We were actually able to fly on Monday and we could achieve stable flight in acro mode off a fresh battery but only for about 30 seconds. We're getting new batteries to see if that's contributing. Don't know why it would cause the system (or at-least PX4) to continuously crash/reboot though. Here are the results of the esc checks: voxl2:/usr/share/modalai/voxl-esc-tools$ ./voxl-esc-scan.py Detected Python version : 3.6.9 (default, Mar 10 2023, 16:46:00) [GCC 8.4.0] Found voxl-esc tools bin version: 1.4 VOXL Platform: M0054 Detected RB5 Flight, VOXL2 M0054 or M0104! INFO: Scanning for ESC firmware: /dev/slpi-uart-2, baud: 2000000 Sending library name request: libslpi_qrb5165_io.so Received standard error event 2 Sending initialization request INFO: ESC(s) detected on port: /dev/slpi-uart-2, baud rate: 2000000, protocol: firmware INFO: Verifying ESC Params.. INFO: ESC Information: INFO: --------------------- ID : 0 Board : version 31: ModalAi 4-in-1 ESC V2 RevB (M0049) UID : 0x2033393953435708003A0048 Firmware : version 39, hash d4fe8e3d Bootloader : version 183, hash 0a80a32a Params : ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml ID : 1 Board : version 31: ModalAi 4-in-1 ESC V2 RevB (M0049) UID : 0x203339395343570800340041 Firmware : version 39, hash d4fe8e3d Bootloader : version 183, hash 0a80a32a Params : ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml ID : 2 Board : version 31: ModalAi 4-in-1 ESC V2 RevB (M0049) UID : 0x2033393953435708003A004F Firmware : version 39, hash d4fe8e3d Bootloader : version 183, hash 0a80a32a Params : ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml ID : 3 Board : version 31: ModalAi 4-in-1 ESC V2 RevB (M0049) UID : 0x2033393953435708003A0056 Firmware : version 39, hash d4fe8e3d Bootloader : version 183, hash 0a80a32a Params : ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml voxl2:/usr/share/modalai/voxl-esc-tools$ ./voxl-esc-verify-params.py Detected Python version : 3.6.9 (default, Mar 10 2023, 16:46:00) [GCC 8.4.0] Found voxl-esc tools bin version: 1.4 VOXL Platform: M0054 Detected RB5 Flight, VOXL2 M0054 or M0104! INFO: Scanning for ESC firmware: /dev/slpi-uart-2, baud: 2000000 Sending library name request: libslpi_qrb5165_io.so Received standard error event 2 Sending initialization request INFO: ESC(s) detected on port: /dev/slpi-uart-2, baud rate: 2000000 INFO: Params from ID 0 match ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml INFO: Params from ID 1 match ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml INFO: Params from ID 2 match ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml INFO: Params from ID 3 match ../voxl-esc-params/Sentinel_V1/Sentinel_V1.xml INFO: Success! Params in all ESCs are valid and identical. Let me know if you'd like me to look at anything specifically in the flight logs from our previous attempts. Otherwise I'll follow up tomorrow after our next attempt. Thanks!
  • HexagonSDK4.1.0.4 installation fails due to erro on license verification

    Unsolved px4-dev-kit
    13
    1
    0 Votes
    13 Posts
    4k Views
    E
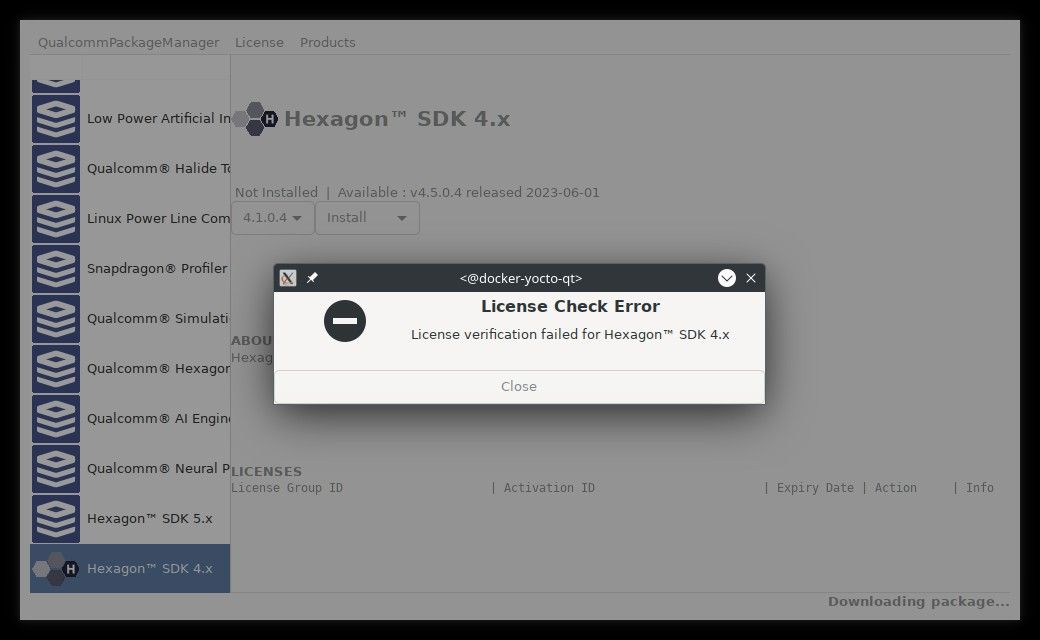
    @Eric-Katzfey thanks, I completed all steps successfully and also built the px4 image for voxl2 Thanks a lot for your help Enrico
  • ROS 2 Setup on RB5 Flight

    Unsolved rb5
    3
    0 Votes
    3 Posts
    1k Views
    A
    @tom Thank you for your response, I went through the link you mentioned and had the following issues: I had already setup the environment source from the video I mentioned earlier with the line: source opt/ros/dashing/setup.bash Is there a way to change it, or would it require a clean install? Moreover, as I am new to this, I am having some trouble understanding the "MPA - to - Ros2" steps mentioned in the document. Can you please elaborate on the command lines I should execute for the steps mentioned. Thanks again!
  • Sentinel (VOXL2) not booting/not flashing

    Unsolved sentinel
    17
    0 Votes
    17 Posts
    4k Views
    J
    @Andre-Moura That's alright, thank you so much for all your help on this!
  • Question on Custom Controller Implementation

    Unsolved sentinel
    4
    0 Votes
    4 Posts
    706 Views
    Eric KatzfeyE
    @josephmlullo The build environment for px4 is within a Docker container. You can find the instructions on how to create this Docker image here: https://gitlab.com/voxl-public/rb5-flight/rb5-flight-px4-build-docker
  • Starling Hires camera extrinsics

    Unsolved starling
    18
    0 Votes
    18 Posts
    3k Views
    Alex KushleyevA
    @Darshit-Desai , yes i believe you are showing the TOF and Hires camera local frames correctly. As for the vehicle, the convention we normally use is FRD, but since you mentioned that you are assuming FLU in your case, that also looks correct.
  • Thermal camera compatible with Sentinel?

    Unsolved sentinel
    3
    0 Votes
    3 Posts
    465 Views
    J
    @Moderator Great, thank you!
  • 0 Votes
    12 Posts
    2k Views
    Darshit DesaiD
    @thomas Thank you the update procedure worked and the results I posted in this thread https://forum.modalai.com/post/14049
  • Issues about ssh RB5

    Unsolved rb5
    19
    2
    0 Votes
    19 Posts
    3k Views
    Qin YangQ
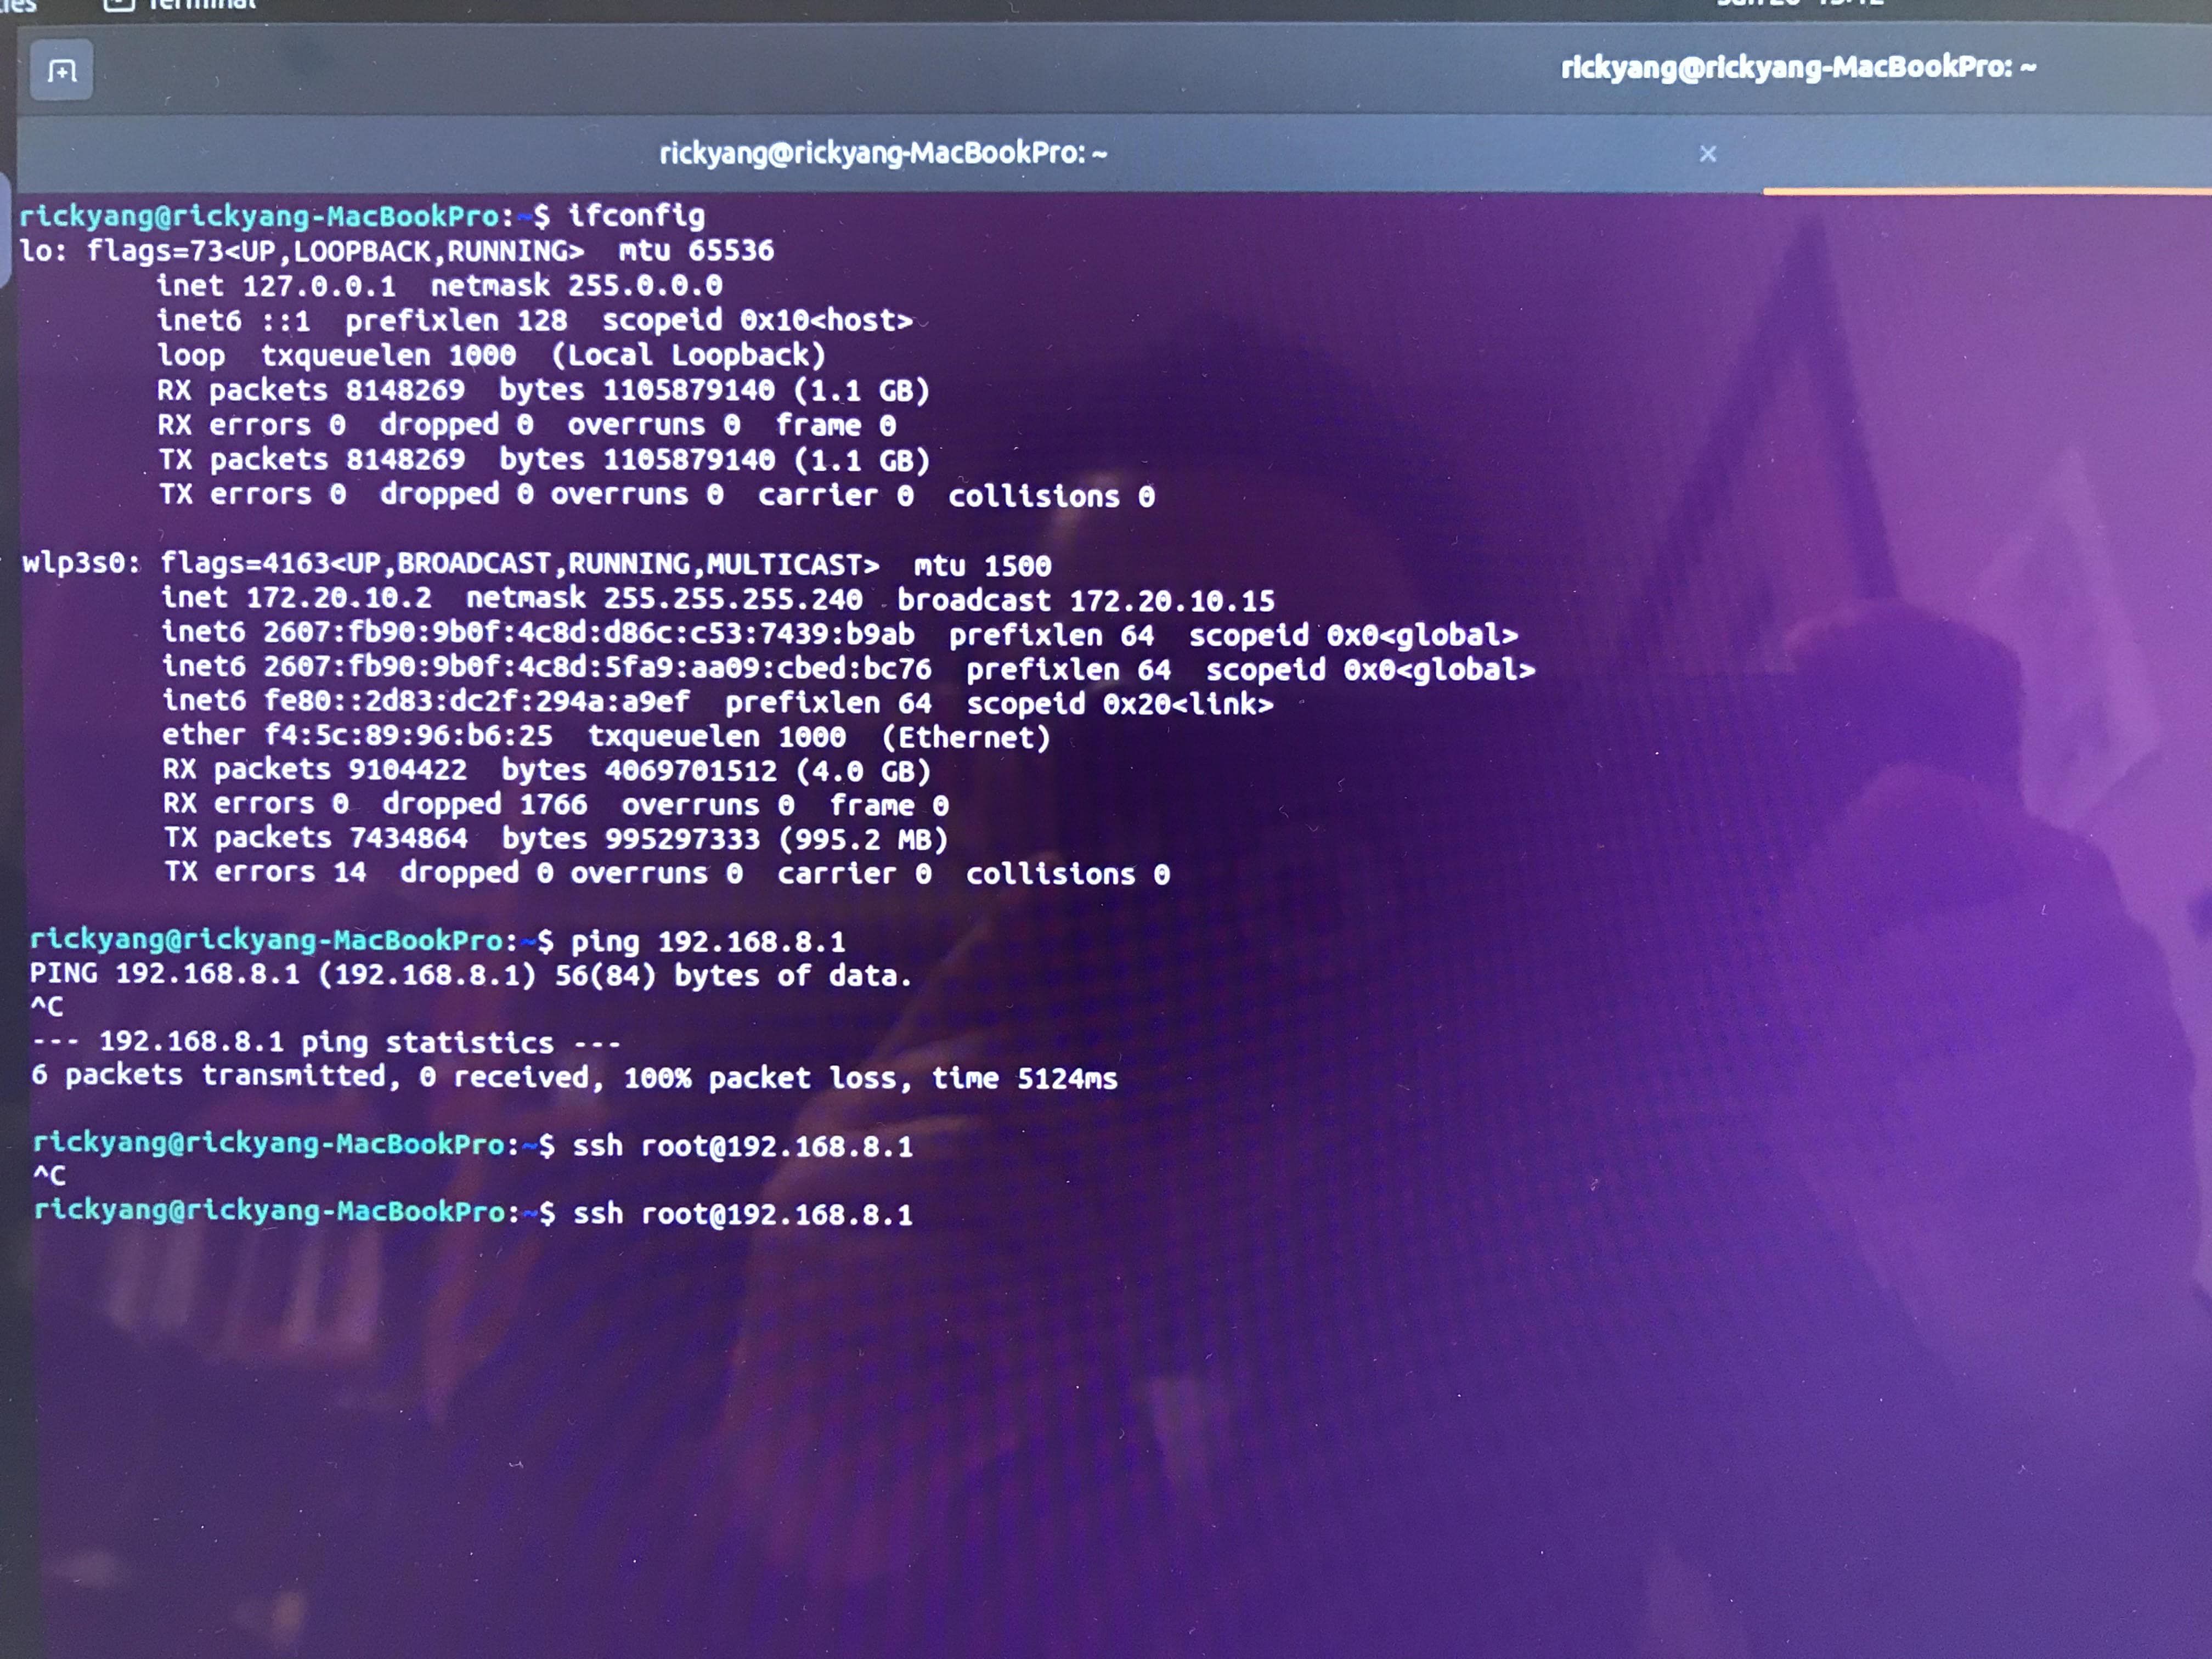
    @Alex-Kushleyev Thank you very much for the solution, I fix it and it works. : )
  • Qualcomm Flight RB5 5G Connecting to a Cellular Network?

    rb5
    2
    0 Votes
    2 Posts
    608 Views
    ModeratorM
    Yes, the Qualcomm Flight RB5 User Guide will send you to the 5G modem user guide if you are using the latest software.
  • Starling Motor ESC replacement

    Unsolved starling
    16
    0 Votes
    16 Posts
    3k Views
    V
    Thanks @Alex-Kushleyev, will do, much appreciated
  • Custom px4-firmware build on StarlingV2

    Unsolved microdds client voxl-px4 px4-firmware ros2 px4-dev-kit
    8
    0 Votes
    8 Posts
    4k Views
    Zachary Lowell 0Z
    @smilon said in Custom px4-firmware build on StarlingV2: I ran into an issue while installing the newly built voxl-px4 which states it depends on libfc-sensor(>=1.0.5) and I only have (1.0.4) on my system. @Eric-Katzfey I saw you authored some commits on libfc-sensor-api, do you have any clue how I can update? 1 Reply Last reply about 3 hours ago Reply @smilon I would recommend using ros2 wrapper around mavsdk instead of mavros, that is what we have done in the past as mavros and ros1 are both depricated and not supported anymore. Anyways, goodluck with the project!
  • IMU Noise Expectations

    Unsolved starling
    3
    2
    0 Votes
    3 Posts
    639 Views
    Alex KushleyevA
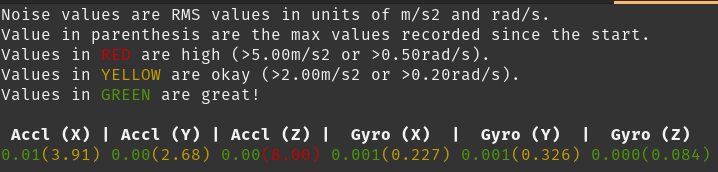
    @awoods , Here is a sample log from one of our recent tests using a Starling platform. You can review the PX4 log here : https://review.px4.io/plot_app?log=3a4c53fd-db88-4d54-8f2e-5f22e159bfc6 The accelerometer noise looks comparable to yours, perhaps a bit less. The main thing is that motor outputs are pretty clean, very minor oscillations. You can collect a similar log and compare using px4 flight review. Also look at gyro noise which more directly affects motor commands. [image: 1705697622723-starling_imu_noise_sample.png]
  • 4G/5G Module on the Starling

    Unsolved starling
    2
    0 Votes
    2 Posts
    617 Views
    ModeratorM
    @Mihir-Bala Technically it should work, we have not done any pre-integration as you've mentioned
  • S.Bus Receiver Compatibility and ESC Firmware

    Unsolved seeker
    4
    0 Votes
    4 Posts
    1k Views
    Alex KushleyevA
    @NUMETRIX , in order to check and upgrade your ESC firmware, you can install the latest VOXL2 SDK, which comes with voxl-esc tools. scan: voxl-esc scan upgrade firmware: voxl-esc upgrade_firmware for reference: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/master/scripts/voxl-esc?ref_type=heads (the voxl-esc tools are installed to /usr/share/modalai/voxl-esc-tools/) by the SDK. You can call the python scripts directly from there as well (as opposed to using voxl-esc wrapper). But make sure to stop PX4 first. Alex
  • Are there any URDF for the dev drones>?

    Unsolved
    4
    0 Votes
    4 Posts
    4k Views
    S
    @skl1g14 in case anyone looking for URDF for m500 drone, i have it here https://github.com/UoSM-CIRG/CAD-Files/tree/master/drone_dev_kit/catkin_ws/src/display_model/description/m500_urdf/urdf