Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • voxl2 rangefinder (lw20)

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    Eric KatzfeyE
    @voxltester Again, LW20 is not in the px4 build. Until you rebuild px4 with that driver you cannot use it within px4. So, you have 2 choices. Rebuild PX4 and try to get LW20 working within PX4 or take a look at the source code for voxl-rangefinder-server and see if you can add support for LW20 into that. It currently supports the vl53l1x rangefinder. Perhaps you can just switch to that rangefinder model? Otherwise the source code it here: https://gitlab.com/voxl-public/voxl-sdk/services/qrb5165-rangefinder-server
  • Explenation VOXL2 USB-C Port not usable

    Unsolved
    1
    0 Votes
    1 Posts
    522 Views
    No one has replied
  • Starling planning using waypoints

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    I
    @Jetson-Nano Unfortunately it is not yet fully working, as I said I managed to create plans with waypoints and to fly those plans we are currently launching the plans on a waypoint to waypoint basis so, no full trajectory without stopping (we don't have to click on the waypoints but the drone stops to plan the next strecht). We have done so because we don't trust the VIO to be able to mantain a correct pose for the long trajectory through the waypoints and we "stop" at the waypoints (where we placed april tags) to relocate and replan with a corrected position after a flight between waypoints. If you trust VIO to follow your planned trajectory it is possible. We have modified the planTo function from mapper to localize the closest waypoint to the clicked target and we launch global_planner_->createPlan(current_start, final_target, waypoints_); iteratively from way point to waypoint without clearing the waypoints_ vector until it reaches the last waypoint and then plan to the actual target. This creates a long trajectory that should be followed when you press follow button. As I said we have never tried to follow the long trajectory, but as far as I understand the drone should follow it given that qvio maintains a good enough pose. Right now we are experiencing stability issues when switching from position mode to trajectory mode. If we manage to solve that I can run a test with the long trajectory and get back to you.
  • How to configure RC control on the voxl?

    Unsolved
    2
    0 Votes
    2 Posts
    625 Views
    A
    @Ariel-Saez I already fix the problem, my seeker has the wrong sku version, more details with the fix, see my original topic: https://forum.modalai.com/topic/3286/qgroundcontrol-don-t-detect-transmitter
  • Failure to Ros2 topic echo messages from VOXL2 on my laptop using mpa-to-ros2

    Unsolved
    14
    0 Votes
    14 Posts
    4k Views
    dleeD
    @ggiacalone I found something. When I start echoing a topic in voxl2, that topic (echoing) shows up on my laptop. I think we need to figure out the ros2 configuration of voxl.
  • Unable to communicate with add-on board

    Unsolved
    13
    0 Votes
    13 Posts
    3k Views
    A
    @rogerli said in Unable to communicate with add-on board: @Vinny I have another VOXL2 where only DS1 and DS2 lights up constantly, but D1 doesn't light up. Is this normal? (There was a slight deformation near the power interface due to a previous fall.) @tom The SDK version of the VOXL2 that I'm using is 1.1.3. I initially bought two VOXL2 boards, both version 1.1.2. One was deformed due to a crash, but the other still works well. Later, I purchased two more VOXL2 boards, which arrived with version 1.1.3. One of them was completely non-functional, and the other also had communication issues. Due to time constraints, we urgently ordered two more VOXL2 boards. Should we downgrade the SDK to 1.1.2 for safety? Currently, as we are in the pre-mass production stage and sending products for inspection, we cannot afford sudden failures of critical components.
  • M500 drone parameters

    Unsolved
    4
    0 Votes
    4 Posts
    697 Views
    Alex KushleyevA
    @es24ucb , the M500 uses an off-the-shelf S500 V2 frame, which has 480mm diagonal distance between motors, so each motor is 240mm from the center. I hope this helps! I am sorry we do not have a CAD model of M500 that we can share at this time.
  • HiRes camera extrinsics config

    Unsolved
    2
    0 Votes
    2 Posts
    608 Views
    Alex KushleyevA
    @Gary-Holmgren , you are correct, the high resolution camera is not used for VIO, we typically use it just for video recording / streaming. You can certainly add a new transform to the extrinsics file and use it in your application. You should use the same name for the camera in the extrinsics file as you name it in voxl-camera-server.conf just to be consistent.
  • Output based on VOXL tflite live footage/bounding boxes

    Unsolved tflite tflite-server mobilenet
    2
    0 Votes
    2 Posts
    1k Views
    ?
    @Denver-Bennett Hey Denver, happy to try and help you out with this! Where you should start is our documentation for voxl-tflite-server which is how we often run ML models on VOXL. What you'll see from those docs is that we have a bunch of pretrained models already onboard as well as a bit of support for custom models. voxl-tflite-server then writes AI predictions out to a pipe using libmodal-pipe. However libmodal-pipe currently only has a C/C++ API and so you'd have to make a simple piece of C code to consume data from the pipe and invoke your Python script accordingly. I'm more than happy to help with this, but it would be good to do some reading first. I'd check out that documentation link above as well as the one on the Modal Pipe Architecture to learn how processes communicate with each other. From there I can start to answer more specific questions and help you build this out. Hope this helps! Thomas Patton
  • No WLAN0 found on VOXL2

    Unsolved
    3
    1
    0 Votes
    3 Posts
    657 Views
    tomT
    @Will-Anderson Yep, same deal. If you reach out to contact@modalai.com we can get you sorted. I'm passing this on to the operations team as well
  • No Power to WiFi Dongle

    Unsolved
    6
    1
    1 Votes
    6 Posts
    1k Views
    tomT
    @Stefan-Amundarain As a member of the software team I have no knowledge of your orders. I gave you the missing info you needed and a path forward using your existing hardware. If you'd like to get a replacement you can reach out to contact@modalai.com and they'll get you sorted quickly.
  • April Tag Setup Issues - Waiting for Server

    Unsolved
    3
    2
    0 Votes
    3 Posts
    784 Views
    Alex KushleyevA
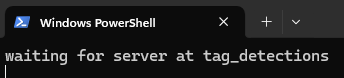
    vox-tag-detector requires camera calibration, path to which which is stored here in the configuration file : /etc/modalai/voxl-tag-detector.conf . If you have not performed calibration of your tracking camera, please do that: https://docs.modalai.com/calibrate-cameras/ After that, make sure the voxl-tag-detector.conf is set up to listen to the correct camera (input_pipe should match the name of the camera that you are looking at through voxl-portal, typically tracking for the tracking caemra). Also make sure the detector is enabled "enable": true in voxl-tag-detector.conf . Finally, as Tom suggested, if the tag detector encounters some error, it will display it in the log. You could just run the tag detector in the foreground by stopping the background service first and then running the detector in the terminal: systemctl stop voxl-tag-detector voxl-tag-detector
  • Can not connect to VOXL2

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    tomT
    @anghung Okay I would retry flashing using QDL. If you still have issue you can submit an RMA and we can fix it for you: https://www.modalai.com/pages/rma
  • Voxl starling crashed all motors stop working mid air

    Unsolved
    9
    0 Votes
    9 Posts
    1k Views
    Alex KushleyevA
    @Manu-Verma , that is great that you figured it out! Can you please help us understand where exactly the loose connection was? Could you please take a picture and mark the location of the issue? That would be really appreciated! Alex
  • Voxl2 Volume Full

    Unsolved
    4
    1
    0 Votes
    4 Posts
    702 Views
    tomT
    @Stefan-Amundarain Thanks for your patience! There is a slight bug in the flashing script that doesn't handle fixing the partition layout correctly without forcing it via. that arg. It'll be fixed in the next release (SDK 1.3..0)
  • Tracking camera won’t initialize when configured with stereo

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Alex KushleyevA
    @Gary-Holmgren, Based on your results, the tracking camera is found in both cases (cam slot 2). It looks like one of the stereo cameras is not detected in camera configuration 03. Are you using the dual flex extension (30cm)? Maybe try to swap out flex cables?
  • ROS foxy PCL ROS

    Unsolved
    7
    0 Votes
    7 Posts
    2k Views
    Darshit DesaiD
    @Zachary-Lowell-0 Yes I was able to install docker of u22.04, but at the same time when I was running everything on natively in melodic on the drone I was able to use 3rd party libraries like PCL ROS and I was able to install it, this was because the ROS installation was left on the user. I just thought it would be same with ROS2. Although now I have set up ARM64 dockers in my desktop ubuntu so now I can make as many changes on my desktop and just push the new docker
  • Automatic syncing object models across multiple VOXL2s

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    ModeratorM
    @Denver-Bennett Hi Denver, no voxl-tflite-server is a TensorFlow Lite runtime environment for VOXL. You will need to write your own code if you want to somehow mesh models together over a network. We aren't familiar with any software that handles that today
  • Stereo camera bit rate customization?

    Unsolved
    2
    0 Votes
    2 Posts
    501 Views
    Alex KushleyevA
    @Gary-Holmgren , Can you please confirm that in your 30cm extension use case you are using: (starting from VOXL side..) M0076 interposer 2x M0036 15cm flexes (connected back to back) M0010 stereo splitter 2x M0015 OV7251 cameras Also, are the cameras being detected when using voxl-camera-server -l but the stream does not work? or neither detection nor streaming work? We will try to reproduce your test case first and lets go from there.. Alex
  • Run code on boot from docker in voxl2

    Unsolved
    2
    0 Votes
    2 Posts
    717 Views
    tomT
    @Darshit-Desai Sure, the easiest way would be to create a custom systemd service file