Skip to content

VOXL SDK and Software

391 Topics 2.0k Posts

voxl-sdk releases, MPA services, camera and video pipelines, Remote ID, and building and deploying your own software on VOXL.

  • No Docker support on VOXL2

    Unsolved voxl-sdk
    2
    0 Votes
    2 Posts
    486 Views
    tomT
    @MikeD Docker is not installed by default, but you can follow the ubuntu install instructions on VOXL2:https://docs.docker.com/engine/install/ubuntu/
  • 0 Votes
    4 Posts
    2k Views
    Alex KushleyevA
    @griffin , this seems like an network issue. So please try the following: open a terminal and just run the following command to "inspect" the hires stream so that it is always going and you can check if it's running any time : voxl-inspect-cam hires_down_small_encoded start a continuous ping test from your host that is trying to receive the video feed keep testing the video feed until you see the issue occur and check if ping is dropping out and double check voxl-inspect-cam output to make sure the data is flowing. What i expect is the output of voxl-inspect-cam should be continuously updating and you may see ping having trouble. Please let me know what you observe. Regarding the voxl2 heating up, i will check with the team. open-vins-server is running (VIO) and it has been recently updated to use GPU for feature detection, so a slight increase in voxl2 temperature may be possible. Alex
  • QUP0 i2c access on VOXL2 mini

    Unsolved
    7
    0 Votes
    7 Posts
    4k Views
    J
    Awesome, thanks!
  • Image Metadata from Snahsopt doesn't match Camera Specs from Datasheet

    Unsolved voxl-sdk
    2
    0 Votes
    2 Posts
    581 Views
    Alex KushleyevA
    Hi @m1baldwin , are you using VOXL1 and VOXL2 ?
  • Connecting to QGroundControl

    voxl-sdk
    2
    0 Votes
    2 Posts
    719 Views
    ModeratorM
    @Moderator Have you gone through this document here: https://docs.modalai.com/qgc-wifi/ ?
  • Accessing the PMD TOF Data Programmatically

    camera
    3
    0 Votes
    3 Posts
    919 Views
    Alex KushleyevA
    and also a simple example here : https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-tools/-/blob/master/tools/voxl-inspect-tof.c?ref_type=heads
  • Dynamic notch filter on IMU_APPS based on Motor RPM

    Unsolved voxl-sdk
    8
    0 Votes
    8 Posts
    3k Views
    Alex KushleyevA
    Hi @LucaVertiq , this is cool stuff. I am curious if you were able to do any direct comparisons of qvio performance using unfiltered vs low pass (rpm-based) vs notch (rpm based)? In order to replicate the same conditions for each test, this would have to be done using mpa playback after collecting mpa logs of just imu data and images. since the rpm data is not coming from mpa, it cannot be logged / played back using our logger. However, one idea is to process the IMU data logs using RPM logs using a separate script and then run the playback + qvio to generate new results. The IMU data processing can have different options like the rpm-based notch filter and it would obviously also need to have a px4 log that contains the ESC status. This also leads to a question, whether the IMU data should be filtered in the imu server or the application that uses the imu, since the requirements for the IMU data may differ for different applications, so it may be best to leave the IMU server publishing the original data. But also, there could be a separate output pipe from the imu sever with the notch filtered imu data.. Anyway, just wanted to check if you happened to get any quantitative results from your testing that show how the filtering helps with QVIO performance. My understanding from working with QVIO in the past was that the best thing to do was to feed unfiltered imu data into QVIO and let it integrate the noisy data. low pass filtering the IMU data too much would actually remove some of the actual components of motion that are important for motion tracking. So i am curious what exactly has improved in your case when you added notch filtering - is the drift vs distance improved or the number of VIO "blow-ups" has reduced? Lots of questions, but I am happy to discuss this further and see how we can improve performance of our VIO stack Alex
  • Factory reset Starling 2

    Unsolved voxl-sdk
    3
    0 Votes
    3 Posts
    568 Views
    tomT
    @LR I would recommend upgrading to the newly released SDK 1.4.1 from downloads.modalai.com Simply, download, untar, and run ./install.sh It'll retain any important calibration files and will re-configure the drone based off the SKU
  • Debugging voxl-package

    Unsolved
    2
    0 Votes
    2 Posts
    2k Views
    Alex KushleyevA
    @arcj , I don't think we have tried it but i believe the approach you are looking for is described here : https://developers.redhat.com/blog/2015/04/28/remote-debugging-with-gdb If you are looking to use a GUI-based debugger front end, it would have to be compatible with gdb. If you try this, let us know if it works! Alex
  • Open-vins low quality not going into altitude

    Unsolved voxl-sdk
    1
    1 Votes
    1 Posts
    493 Views
    No one has replied
  • Voxl-Mavcam-Manager Multiple RTSP Stream Setup

    Unsolved voxl-mavcam voxl-streamer rtsp starling2 max voxl-sdk
    14
    0 Votes
    14 Posts
    5k Views
    E
    @brahim after looking at this some more I think it is valid to have multiple streams per camera. I guess the use case would be to have a high res stream and a low res stream that's separate or something like that. However I think people would still like to setup multiple cameras. I haven't tried this yet, but I think it could also be valid to spawn a manager per camera, and then stagger the component ids for each app. I think this might also fix the threading issue since each application would initialize separate pipe reads and wouldn't be blocked by each other? @Eric-Katzfey I'm using a different mavlink GCS that's not QGC, so I need to make voxl-mavcam-manager conform to the standard.
  • Custom Server in VOXL MPA

    Unsolved mpa
    13
    0 Votes
    13 Posts
    7k Views
    Jetson NanoJ
    @Alex-Kushleyev @Eric-Katzfey can you check it out and help with the code. I am also interested what kind of signal is send to the neopixel LEDs to turn it ON. And with addition to that what is the command to turn ON only blue lights.
  • streamer default h265

    Unsolved voxl-sdk
    21
    0 Votes
    21 Posts
    6k Views
    B
    @Alex-Kushleyev Thanks for letting me know! I'll have to give it a try
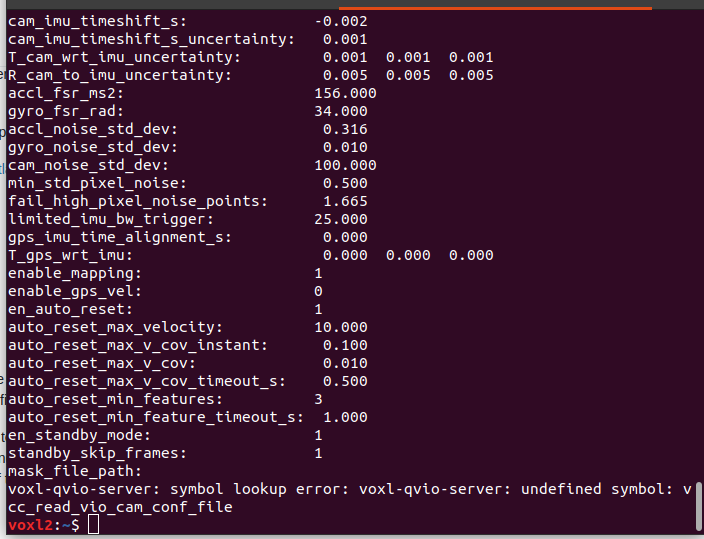
  • QVIO-server issues

    Unsolved mpa
    6
    1
    0 Votes
    6 Posts
    4k Views
    Jetson NanoJ
    @tom thank you for reverting , I sorted out the issue, the file name in the voxl-qvio-server was opencv_tracking_front_intrinsics.yml instead of opencv_tracking_intrinsics.yml and in the voxl-vision-hub the name was tracking_front which i renamed in tracking. After the above mentioned changed the voxl-qvio-server is working fine. thank you for the support.
  • Stuck installing ros-melodic-pcl-conversions

    Unsolved ros
    5
    0 Votes
    5 Posts
    3k Views
    T
    @VSK said in Stuck installing ros-melodic-pcl-conversions: configure python-twisted-core:all 17.9.0-2ubuntu0.3 <none> status half-configured python-twisted-core:all 17.9.0-2ubuntu0.3 Maybe that package got corrupted on the install. Can you try running sudo apt-get clean? If that doesn't work, you could also try removing both of the packages and do the install again. $ sudo apt remove python-twisted-core:all $ sudo apt remove ros-melodic-pcl-ros ros-melodic-pcl-conversions
  • Version control the Linux distro, ideas

    Unsolved voxl-sdk
    2
    0 Votes
    2 Posts
    788 Views
    Alex KushleyevA
    @Darshit-Desai , In short, the VOXL2 system image contains the main Linux OS that is built from open source components and it also contains open-source and closed-source components that are specific to Qualcomm hardware. Building the system image uses bitbake and a very long manifest which has a list of SW components, their exact version and source, as well as order in which the components should be built). you cannot use dd to back up and restore system partitions, as you may be able to do on a Raspberry Pi. Fastboot is the tool that is used to properly install the system partitions. voxl-suite is a collection of software that is installed on top of the base OS on VOXL2. For each SDK version, we also have a manifest of each component and version that should go into the SDK. Can you clarify which deb files you mean in its always annoying to install the deb files one by one and revving up the versions -- are you updating SDK or installing your some other deb files? It sounds like you may have per vehicle configuration (every set up is slightly different). You can differentiate the VOXL2 boards using the SoC serial number (cat /sys/devices/soc0/serial_number) and do your custom install based on the serial number. Basically you would have your own "manifest" of some type that may have common parts but also describe different settings for different boards (IP address, etc). You can maintain different bash files for each board and install them based on the serial number. Alex
  • Instruction to set a Static IP for wlan0 voxl2

    Unsolved
    3
    1 Votes
    3 Posts
    3k Views
    tomT
    @Judoor-0 Thanks for the contribution, this is very helpful!
  • Offboard mode and ROS2 with Rb5

    Unsolved ros
    3
    0 Votes
    3 Posts
    2k Views
    T
    @Zachary-Lowell-0 offboard mode: [image: 1737382725235-d5d4a98e-4bf0-4aa7-baee-522cb331b4a7-image.png] The drone does NOT arm from the ROS2 command but it can be armed with the RC 3)rb5:~$ voxl-inspect-services Scanning services... [image: 1737382905455-bea8dc77-6e7c-4635-b0b0-c7b9a5ec7676-image.png] 4)/usr/bin/voxl-px4-start [image: 1737383495210-466822e7-ff3f-4c08-a6c4-780b619665d0-image.png] Best wishes,
  • voxl-streamer disconnecting then reconnecting

    Unsolved voxl-sdk
    1
    0 Votes
    1 Posts
    396 Views
    No one has replied
  • /tof_depth image conversion problem

    Unsolved ros
    4
    0 Votes
    4 Posts
    3k Views
    J
    @Alex-Kushleyev thank you alex i'll try that