Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • USBC Port as Ethernet interface

    Unsolved rb5
    8
    0 Votes
    8 Posts
    2k Views
    Eric KatzfeyE
    @mrawding Also Apple A1277
  • SDK version 1.1.3 issues (video stream breaks, reboot issue)

    Unsolved rb5
    1
    0 Votes
    1 Posts
    609 Views
    No one has replied
  • How to set up a static IP in RB5

    Unsolved rb5
    17
    0 Votes
    17 Posts
    4k Views
    M
    If anyone else is interested - I found a way to enable static ip's for ethernet and wlan interfaces. You'll need to install a file like below under /etc/systemd/systetem/ and run the following commands: systemctl enable ipconfig.service systemctl disable dhcpcd.service [Unit] Description=A description for your custom service goes here Requires=systemd-networkd.service After=systemd-networkd-wait-online.service [Service] Type=simple ExecStartPre=/bin/sleep 10 ExecStart=/bin/systemctl restart systemd-networkd.service [Install] WantedBy=multi-user.target You'll also need to add this file under /etc/systemd/network/wlan0.network [Match] Name=wlan0 [Network] Address=192.168.0.169/24 #DHCP=yes Simply installing this service will allow most routers to keep the rb5 address the same when assigning IPs for a lease. Just comment #Address and uncomment DHCP to use dhcp. You will also need to make sure to add the gatway to the routing table: route add default gw $router_IP $network_interface this is best to be configured as a oneshot service where the service has the field Requires=ipconfig.service
  • QVIO not working

    Unsolved seeker
    6
    0 Votes
    6 Posts
    1k Views
    J
    Additionally, I am unable to view the pointcloud in RViz It connects and can show images but not spatial data: No tf data. Actual error: Fixed Frame [map] does not exist Maybe there is a misconfiguration of ros on the seeker?
  • RB5 Kit + SDK queries

    Unsolved rb5
    4
    0 Votes
    4 Posts
    982 Views
    ModeratorM
    For softap, there are references here on how to enable At some point more flexibility will be added for camera configurations. Right now the shipping configuration is all that is supported. There is already a tracking camera at 45°. You should be able to create a mount to point that straight down if you prefer. Only one active gstreamer instance for each camera can be running. The camera servers use gstreamer to get the camera data and publish that to a named pipe. So if an instance of a camera server is running, then a new gstreamer instance for that same camera can't be started. MAVROS is not pre-installed. That is planned in a future version of the SDK, likely one or two months away. We do have customers using it today though. Note in offboard mode the default behavior is a figure-8. See post here for the fix
  • How to use voxl-logger to sample hires camera?

    Unsolved m500
    3
    0 Votes
    3 Posts
    1k Views
    David SmythD
    +1 for this functionality if possible. Would it be possible to merge the color branch into dev/master for the next release? If speed is a problem I think it would be acceptable to limit this to lower resolutions as a starting point
  • Flight RB5 Questions.

    Unsolved rb5
    2
    0 Votes
    2 Posts
    477 Views
    Chad SweetC
    ModalAI is the only manufacturer of Qualcomm Flight RB5 boards We will release more pricing information soon. The VOA functionality creates the depth map and obstacle map on the CPU and passes that information to PX4 running on the DSP. Yes, there is USB expansion, datasheet has all of the details here The USB expansion through the modem carrier board uses JST-style connectors which are more vibration tolerant. The end UAV manufacturer can equip with a fan. HDMI input is not supported at this point
  • How to edit full-m0052.config file?

    Unsolved rb5
    11
    0 Votes
    11 Posts
    2k Views
    tomT
    @Djalma-Ribeiro Awesome thank you, just wanted to make sure your RB5 had the SDK loaded properly, which it does. It's not absolutely necessary to upgrade the SDK, if you do want to you can follow the steps here: https://docs.modalai.com/Qualcomm-Flight-RB5-sdk-installation/#how-to-upgrade One note, if you try to upgrade the SDK while PX4 is running it will fail. So in order to upgrade the SDK you would have to disable PX4 from starting systemctl disable rb5-px4-start and then reboot your drone before upgrading your SDK.
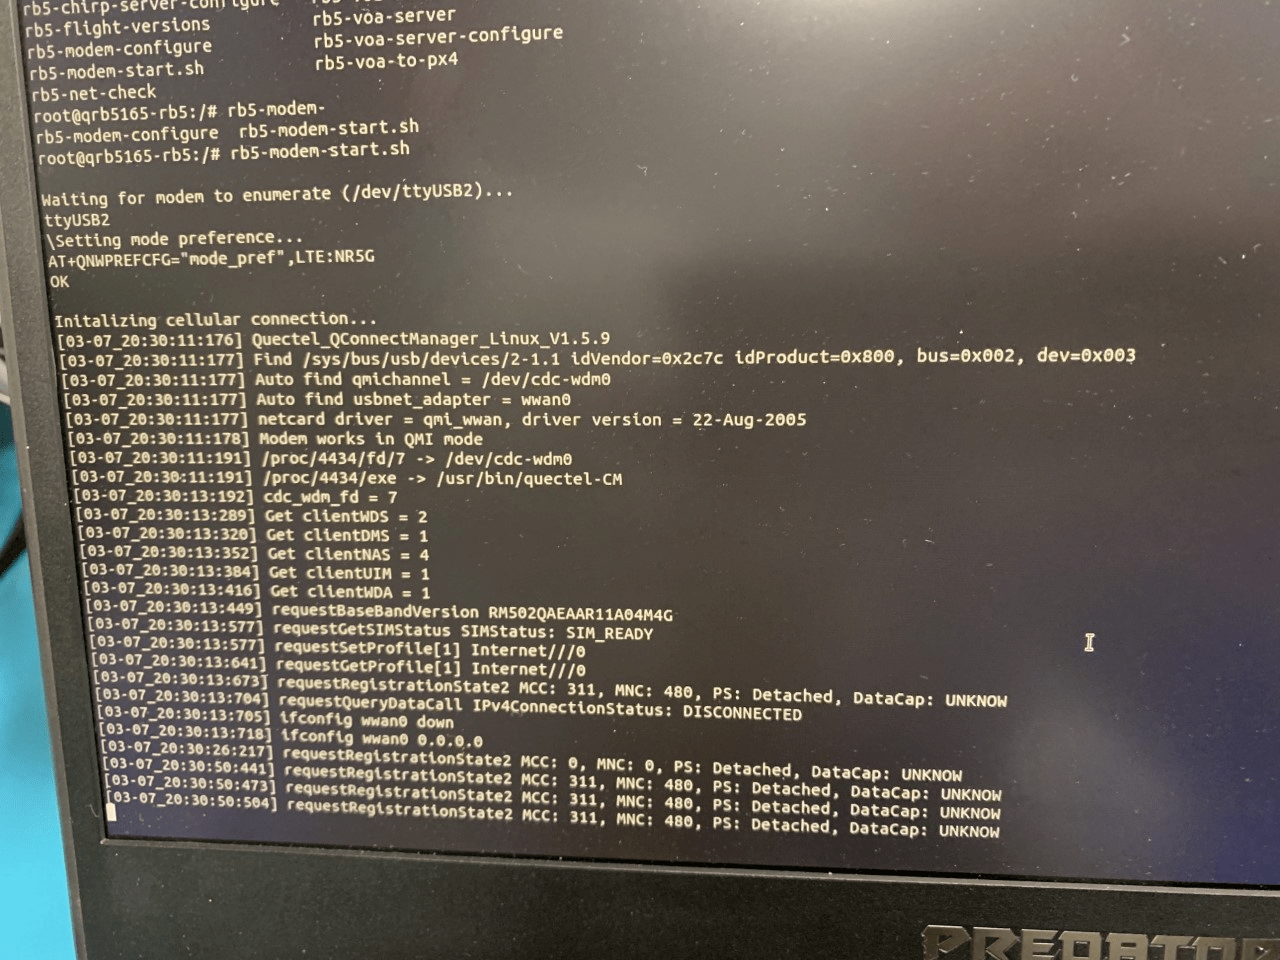
  • Cannot Connect to 5G network

    Unsolved rb5
    15
    1
    0 Votes
    15 Posts
    3k Views
    tomT
    @chris_macdonald Oops, my bad. It is on board at /usr/bin/set-mode-pref
  • This topic is deleted!

    1
    2
    0 Votes
    1 Posts
    8 Views
    No one has replied
  • Prop Guard

    Unsolved seeker
    1
    0 Votes
    1 Posts
    676 Views
    No one has replied
  • Streaming stopping after running once

    Unsolved rb5
    4
    0 Votes
    4 Posts
    1k Views
    U
    @Hector-Nevarez Thanks for the quick reply. If the camera server are disabled I guess VIO can not work?
  • Extrinsic camera/imu parameters

    Unsolved rb5
    2
    0 Votes
    2 Posts
    859 Views
    Chad SweetC
    [voxl-configure-extrinsics](https://docs.modalai.com/configure-extrinsics/![alt text](image url)) provides a tool for configuration, voxl-inspect-extrinsics provides a tool to view the current settings
  • Camera Calibration

    Unsolved rb5
    5
    0 Votes
    5 Posts
    2k Views
    U
    @Jeremy-Schmidt Ah you are right they are all here, I thought I erased everything when flashing the new image.
  • MAVROS integration & FCU URL

    Unsolved rb5
    5
    0 Votes
    5 Posts
    4k Views
    U
    Another update that could be useful to someone: I needed to have a high enough frequency on the local position feedback (ROS topic /mavros/local_position/pose) but I was only receiving at 1hz. Usual solution with most FCU is to set the parameter MAV_1_MODE to Onboard but this parameter is not available on the RB5. Instead I added the line mavlink stream -u 14558 -s LOCAL_POSITION_NED -r 100 in /etc/modalai/full-m0052.config to set the stream rate. The end of my file looks like that. # Configure a second mavlink instance for onboard messages (e.g. VIO and VOA) mavlink start -u 14556 -t 127.0.0.1 -n lo -m custom mavlink start -x -o 14540 -u 14558 -n lo sleep 1 mavlink stream -u 14557 -s HIGHRES_IMU -r 5 mavlink stream -u 14557 -s ATTITUDE -r 5 mavlink stream -u 14557 -s RC_CHANNELS -r 20 mavlink stream -u 14558 -s LOCAL_POSITION_NED -r 100 sleep 1 # Start up the IMU server to support VIO imu_server start And this way I managed to get a frequency of around 55hz on /mavros/local_position/pose.
  • QGroundControl USB connection for sensor calibration

    Unsolved rb5
    3
    0 Votes
    3 Posts
    1k Views
    U
    @umlr said in QGroundControl USB connection for sensor calibration: Performing sensor calibration over a WiFi connection is known to be unreliable. You should disconnect and perform calibration using a direct USB connection instead. Alright good to know that calibrating over WiFi is fine. Yes WiFi connection with QGroundControl worked pretty much out-of-the-box.
  • RB5 adb or wifi no longer communicating

    Unsolved rb5
    4
    0 Votes
    4 Posts
    1k Views
    tomT
    @MaxG Glad to hear that! Thanks for the update.
  • Nylock Nuts for Seeker Motors

    Unsolved seeker
    2
    0 Votes
    2 Posts
    740 Views
    J
    I am pretty sure these are m5 not m3.. I pulled an m5 nut out of a bag that I had, and it fit perfectly. The shaft is 3mm, which means its an m5 nut.
  • This topic is deleted!

    4
    0 Votes
    4 Posts
    25 Views
  • Use onboard vision system for stabilization and disable the GPS/compass?

    Unsolved seeker
    1
    0 Votes
    1 Posts
    753 Views
    No one has replied