Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Pre-arm check failed

    Unsolved m500
    7
    1
    0 Votes
    7 Posts
    3k Views
    yu zhangY
    @modaltb I see. It's good to know the story If 22027 is the default one, it will be all right. To be honest, I didn't touch the CBRK_IO_SAFETY before, and it's a bit weird why it was automatically modified for some reason. Actually, I was trying to refresh a re-compiled 1.11.3-0.2.3 with my modification (increasing GPS log rate). So, I guess it might reset the value to 0 by PX4 default. Anyways, thanks so much!
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    11 Views
    No one has replied
  • Question about voxl-dfs-server.conf and voxl-tflite-server.conf

    Unsolved m500
    4
    0 Votes
    4 Posts
    902 Views
    yu zhangY
    @Alex-Gardner All right, thanks so much for that
  • GPS sampling rate is limited

    Unsolved m500
    16
    0 Votes
    16 Posts
    3k Views
    yu zhangY
    @stevet All right, thanks so much for that, and I will have a try about it then
  • RB5 unable to connect to hotspot

    Unsolved rb5
    11
    0 Votes
    11 Posts
    2k Views
    tomT
    @justinGE This is good information, thanks for sharing!
  • Seeker UVC camera

    Unsolved seeker
    2
    0 Votes
    2 Posts
    897 Views
    tomT
    @Kris The LTE add-on board (M0030) has 2 JST ports for client USB devices
  • RB5 PPM rc input support

    Unsolved rb5
    4
    0 Votes
    4 Posts
    868 Views
    Eric KatzfeyE
    @joshuagaus Even with our new upcoming module we will not support PPM. It looks like there may be some other communication options on that receiver so you may want to review all the possibilities.
  • The angle of the tracking camera mount on m500

    Unsolved m500
    6
    0 Votes
    6 Posts
    1k Views
    yu zhangY
    @Alex-Gardner All right, thanks so much for double-checking
  • voxl-mapping position drifting

    Unsolved seeker
    4
    0 Votes
    4 Posts
    1k Views
    Steve TurnerS
    @Alex-Gardner Definitely interested in open VIO options. Would be awesome being able to use other techniques for picking out key points and even accelerate them on the hardware. Maybe QVIO already does that...
  • Limted flight speed in mission and position modes

    Unsolved m500
    4
    2
    0 Votes
    4 Posts
    885 Views
    yu zhangY
    Hi @Chad-Sweet thanks for that, and it seems it could work by setting a higher value of the maximum speed in QGC. I will test it again to see if it could work to achieve a fast speed in the mission mode
  • Availability and Maximum payload

    Unsolved rb5
    2
    0 Votes
    2 Posts
    483 Views
    Chad SweetC
    Yes, we ship within 10 business days. The payload capability is about 1kg
  • Vibration dampers for the Seeker

    Unsolved seeker
    3
    0 Votes
    3 Posts
    1k Views
    Sem AndewegS
    Thanks!!
  • VOXL streaming has at least 2-3s delay for default 640x480 using hires

    Unsolved m500
    5
    0 Votes
    5 Posts
    1k Views
    yu zhangY
    Hi @張為超 All right, thanks so much for that, and I will then have a look at it
  • 2 drones, simultaneous fly individual flight plan and telemetry logging

    Unsolved rb5
    3
    0 Votes
    3 Posts
    769 Views
    ?
    Reading your post again . . . It looks like you'll have to QGCs running, but using the same router. In the response above, I assumed a single GCS. On each drone, go to /etc/modalai. There should be a file qgc-ip.conf or something similar. You can set the IP of the target laptop, so the MAVLink gets routed properly. Let me know if that works.
  • webstore ordering issue

    Unsolved rb5
    2
    0 Votes
    2 Posts
    471 Views
    ModeratorM
    We don't believe there are any issues, but we just sent you an email in case.
  • replacement body parts for RB5

    Unsolved rb5
    2
    0 Votes
    2 Posts
    583 Views
    ?
    @MaxG we are currently low on stock of the replacement parts, but they can be found here on our web store. Please check back in the next week or two and those will be in stock. Replacement landing skids can be special ordered. Do you need the entire skid assembly or just the landing skid itself (black part)? Please send a picture to contact@modalai.com and we can get you the parts that you need!
  • Qualcomm flight RB5 system image on RB5 development kit from Thundercomm

    Unsolved rb5
    2
    0 Votes
    2 Posts
    489 Views
    Chad SweetC
    Hi Akash, we do not expect much of the Qualcomm Flight RB5 SDK to work on the RB5 dev kit without a significant amount of work.
  • Questions regarding RB5 5G drone

    Unsolved rb5
    27
    1
    0 Votes
    27 Posts
    8k Views
    M
    @RichieRich GPS unit is mounted by default (as it comes with RB5 5G drone), mast is locked in vertical postion. Turning EKF2_REQ_SACC to 0,75 provided no errors from GPS. Obstacle avoidance was also disabled, so we managed to fly. But I'm still a bit confused why the obstacle avoidance gives error, since the drone was placed on the ground (concrete pavement), no obstacles within few meters, while the minimum distance was set to only 1 m. But this is current setup that works: [image: 1649438004385-0de5d598-3401-4512-9e7b-3ef8202ef635-image.png] Many thanks for your help. We'll try to figure this out and provide info in a few days.
  • Reject position control

    Unsolved seeker
    4
    0 Votes
    4 Posts
    1k Views
    Sem AndewegS
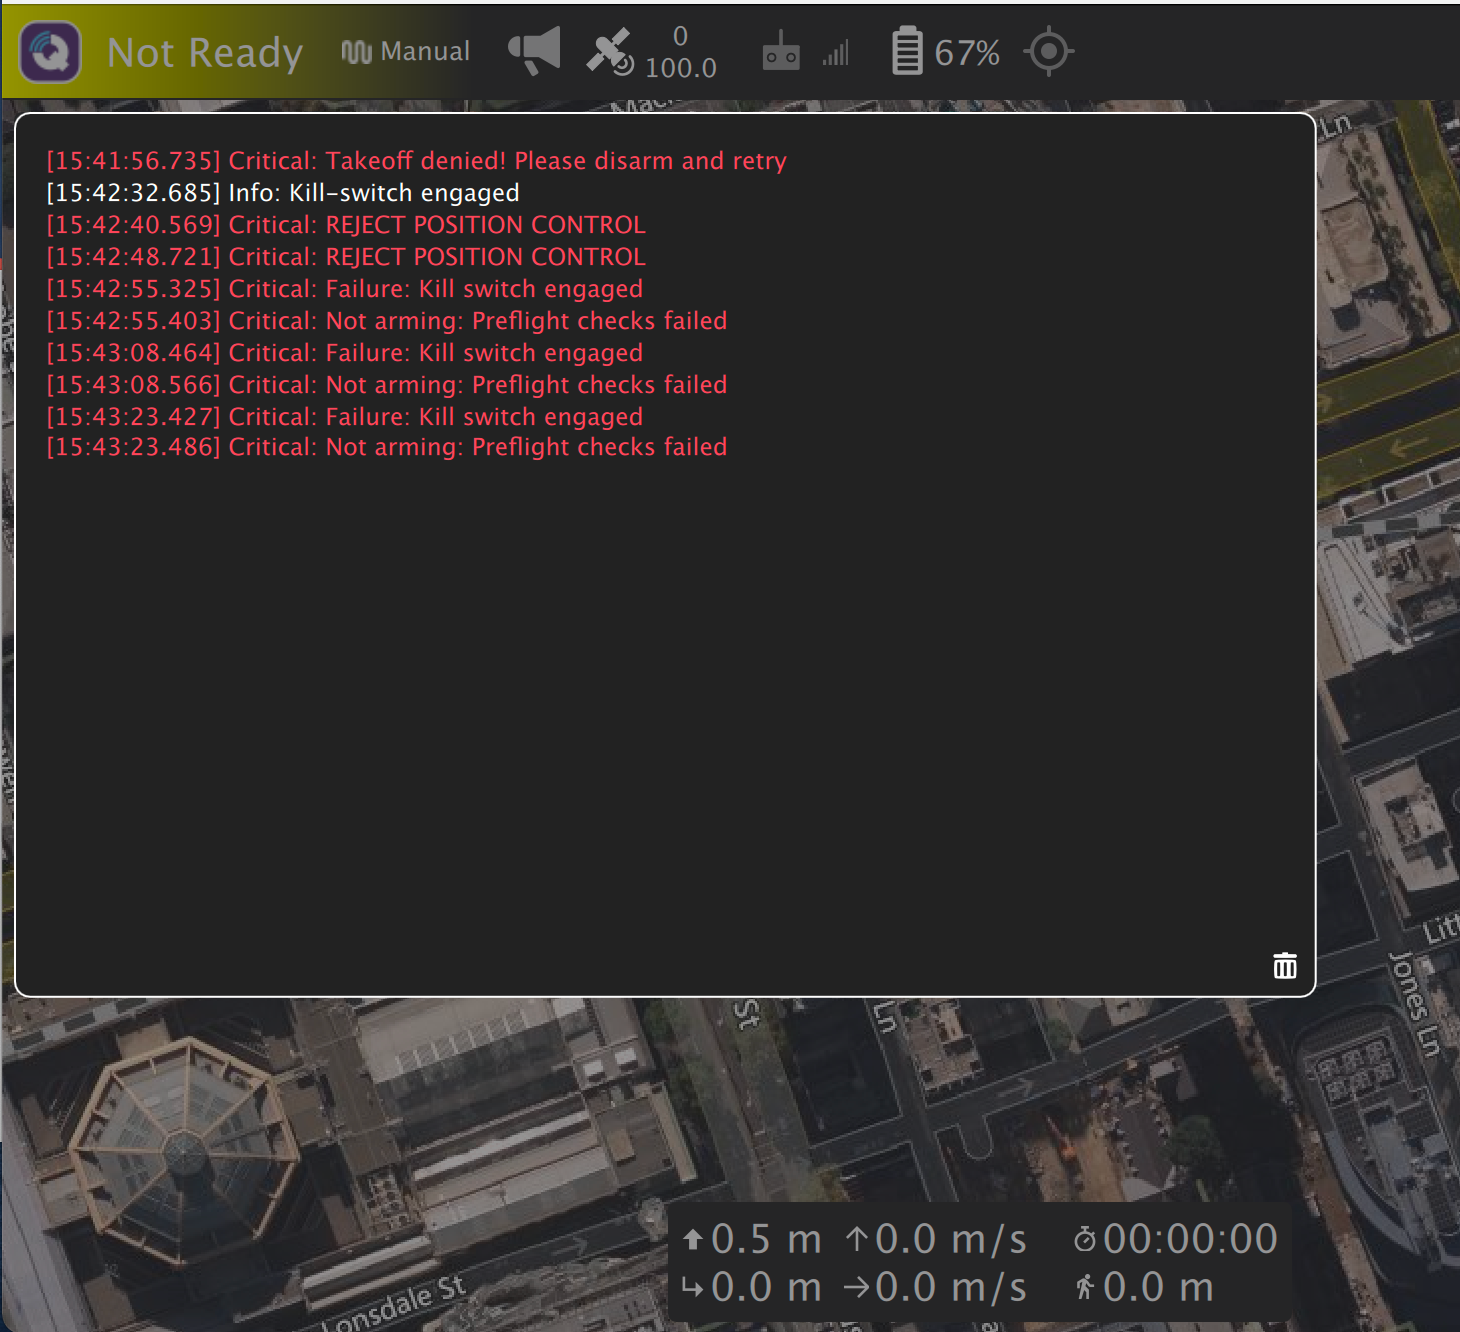
    Thank you for the response! I didn't have time to look into this yet. But there is more going on with the system I think. WIFI also doesn't work anymore. And after trying to solve the WIFI, the ADB of the VOXL stopped working. So we for now we are using a different VOXL. Something else we are running against is the message Reject position control, with working VOXL CAM systems installed on our drones. When we fly everything is super! When we land, after the drone has bumped into things while flying (drone is collision proof) or when heavy wind was pushing it. We cannot take off after landing, it will display Reject position control. Only when the we connect a laptop to the QGC, we can hear that the VOXL reboots and then the Reject position control is gone, and we can go fly again. But if we use QGC via the PX4 Telemetry port, this doesn't happen, and we need to unplug and replug the battery to be able to get the Reject position control message away again. We don't really know why this happens and how we can solve this. It would of course be great if the VOXL didn't need to reboot in order the drone can fly again in position mode. But it already would be helpful that the VOXL would reboot without having to have WIFI connection with QGC. Please help!
  • Controlling a servo with VOXL

    Unsolved m500
    9
    0 Votes
    9 Posts
    2k Views
    Alex KushleyevA
    Yes, chr is an issue most likely. Take a look at how uint8 from a binary representation is sent here : https://gitlab.com/voxl-public/voxl-sdk/core-libs/libapq8096-io/-/blob/master/lib/python/voxl_i2c_apm_v1.py#L48 you can do something similar (also example for hex). The data type needs to be some sort of an int. #values of configuration registers CTRLA (address 0x00) and CTRLB (address 0x01) CTRLA = np.uint8(int('0b01011000',2)) #offset calib every 128 conv, volt=Sense+; so sampling takes about 35ms (for both voltage and current together) CTRLB = np.uint8(int('0b00000100',2)) #addresses of registers for reading data REG_VRAW = int('0x1E',16) REG_IRAW = int('0x14',16) #write configuration to both LTC2946 devices p.slave_config(ID0) p.write(0,8,CTRLA) p.write(1,8,CTRLB) ... p.slave_config(ID0) vraw_batt = p.read(REG_VRAW,8,2) iraw_batt = p.read(REG_IRAW,8,2)