
2 drones, simultaneous fly individual flight plan and telemetry logging
-
Hi @MaxG ,
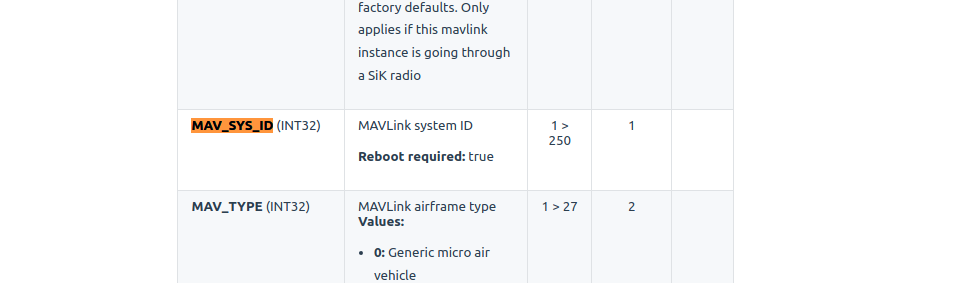
I believe you'll have to set the MAV_SYS_ID to a unique value for each drone. Make sure you have the latest QGC. I haven't used that feature in a while and I assume you should be able to choose which drone updates telemetry, but still be able to see both drones on the screen. Let me know if that works and if you had to update any other additional parameters, so others that come here can also do the same.
https://docs.px4.io/v1.12/en/advanced_config/parameter_reference.html -->
Thanks,
Rich -
Reading your post again . . .
It looks like you'll have to QGCs running, but using the same router. In the response above, I assumed a single GCS.
On each drone, go to /etc/modalai. There should be a file qgc-ip.conf or something similar. You can set the IP of the target laptop, so the MAVLink gets routed properly.
Let me know if that works.
Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login