Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • VOXL2 RC uart failure

    Unsolved
    5
    0 Votes
    5 Posts
    995 Views
    Maxwell SchaeferM
    Hi @tkddnjs825, In addition to Alex's question above, could you also please share which version of voxl-elrs is being used on each voxl2? The voxl-version command should list the versions of each installed package. Can you also please confirm that in the voxl-px4 configuration file on the voxl2 that is not able to communicate with the ELRS receiver that the RC type is set to CRSF_RAW, like this: RC=CRSF_RAW. Furthermore, if you could share the output of voxl-elrs --scan from the voxl which is unsuccessful that would be helpful. Thanks, Max
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    1 Views
    No one has replied
  • This topic is deleted!

    1
    1
    0 Votes
    1 Posts
    1 Views
    No one has replied
  • ROS2 MicroDDS-Agent Parameter Change in PX4

    Unsolved
    1
    0 Votes
    1 Posts
    351 Views
    No one has replied
  • NDAA Compliance for Cameras

    Unsolved
    2
    0 Votes
    2 Posts
    884 Views
    ModeratorM
    @Peter-Milani Hi Peter, it's not possible for us to answer comprehensively about NDAA compliance. We can answer country of origin questions though. Our M0107, M0161, M0166 for instance are built by ModalAI in the USA M0149 is built by a partner in Taiwan
  • Sentinel / Doodle possilities

    Unsolved
    2
    0 Votes
    2 Posts
    527 Views
    ModeratorM
    @Pete Starling 2 Max is probably easier to configure for this. You could mount the Doodle radio on the bottom. The M0151 is a good expansion board for this.
  • Voxl-mapper importing external generated tsdf and esdf files issue

    Unsolved
    1
    0 Votes
    1 Posts
    571 Views
    No one has replied
  • voxl 2 external rangefinder compatibility

    Unsolved
    7
    1 Votes
    7 Posts
    2k Views
    J
    @Gary-Holmgren Haha your way is a little more robust than mine. I just manually added the qshell start command to the extra commands section of the voxl-px4.conf file.
  • Holybro VL53L1X Lidar Support?

    Unsolved
    2
    2
    1 Votes
    2 Posts
    1k Views
    Gary HolmgrenG
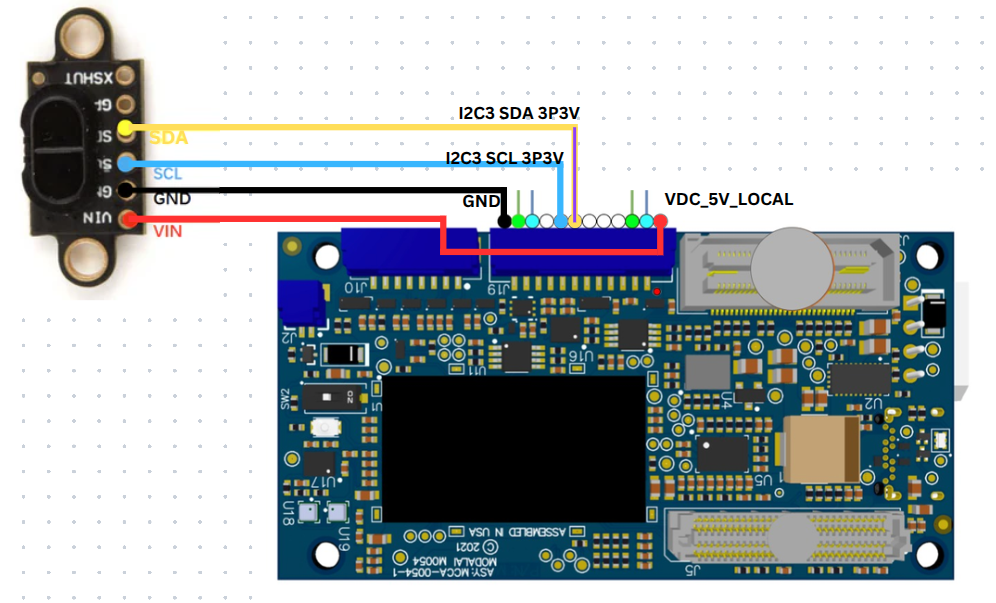
    @Gary-Holmgren Figured it out, I hope this helps others with a similar setup. I didn't notice before but in the usr/bin/voxl-px4-start script there is a comment: # qshell vl53l1x start -X -b 4 Which you can make or replace to change the DISTANCE_SENSOR condition to: if [ "$DISTANCE_SENSOR" == "VL53L1X" ]; then # Make sure to set the parameter SENS_EN_VL53L1X to 1 qshell vl53l1x start -X -b 4 # qshell lightware_laser_serial start -d 7 Then you can change the voxl-px4-conf to: DISTANCE_SENSOR=VL53L1X After setting the relevant distance sensor / EKF2 params in QGC you should be able to restart voxl-px4 and the distance sensor will appear!
  • This topic is deleted!

    1
    2
    0 Votes
    1 Posts
    1 Views
    No one has replied
  • Tflite Server Issue

    Unsolved
    4
    0 Votes
    4 Posts
    755 Views
    T
    Hi @Karl-pan. There was a big refactor done on voxl-tflite-server not too long ago. Would you be able to test this on the dev branch? Also please share your /etc/modalai/voxl-tflite-server.conf. I found a bug where the model path wasn't getting updated for custom models. I just made a PR to fix this, but you can manually edit it until that gets merged in. Lastly, I'm not getting any seg fault with my custom models so if you're able to share an example model that could help narrow it down to the way you're exporting it. Best, Ted
  • VOXL2-Mini J19 devices

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Alex KushleyevA
    @Gary-Holmgren , Our voxl-esc tools use a python wrapper around qrb5165-io library, which is pretty easy to use. The wrapper provides an api that is almost the same as the standard serial port class in python : https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/master/voxl-esc-tools/voxl_serial.py. The usage of this wrapper can be seen here : https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/master/voxl-esc-tools/voxl-esc-neopixel-test.py?ref_type=heads#L114 . You should use the port name such as /dev/slpi-uart-2 , which is a fake name (it does not exist in the Linux /dev/ folder) but the wrapper class will extract the port index at the end. Technically any name with -2 at the end will tell VoxlSerialPort class to use the DSP's uart port 2. You could write a service that uses a python3 script to comunicate with the serial port and expose the data via UDP using other python tools. The limitation of only one concurrent DSP uart port usage still applies here. Alex
  • ROS2 MicroDDS Communication with PX4 from External FC (FVc2)

    Unsolved
    4
    0 Votes
    4 Posts
    994 Views
    Gary HolmgrenG
    @Zachary-Lowell-0 Would definitely be a useful function. I am probably gonna stick with voxl2 running px4 for now since it simplifies things.
  • ROS2 errors on VOXL2

    Unsolved
    3
    0 Votes
    3 Posts
    788 Views
    Gary HolmgrenG
    @Zachary-Lowell-0 Yes this did the trick, thankyou!
  • mavsdk wont build for voxl2

    Unsolved
    2
    0 Votes
    2 Posts
    623 Views
    T
    Hi @Gary-Holmgren. This is likely because you're running the build script from an x86 system (docker requires that you build on the same architecture as the base image, in this case arm64). You can solve that by cloning the repo onto the voxl and running build.sh from there. Note: make sure your voxl has a wifi connection before running ./build.sh.
  • Request for QURT Compatibility for OSD Program

    Unsolved
    12
    0 Votes
    12 Posts
    3k Views
    JP DroneJ
    @Eric-Katzfey Thank you for your quick update. I was able to confirm that it is functioning properly. Really appreciate your support. Wishing you a wonderful New Year!
  • Starling 2 (VOXL 2) 3s batteries

    Unsolved
    4
    0 Votes
    4 Posts
    566 Views
    Andrii TytarenkoA
    @tom Thanks!
  • Starling drone shut down mid flight

    Unsolved
    30
    1 Votes
    30 Posts
    8k Views
    Alex KushleyevA
    @Shivam-Sehgal , does it look like the board is rebooting after 10 seconds of running with cameras enabled? also, what if you ssh into the board, does the SSH connection stay alive when the cameras are connecting? Also, how are you powering the drone for this test - battery or power supply? Alex
  • Camera Server Aborts

    Unsolved
    2
    0 Votes
    2 Posts
    644 Views
    Alex KushleyevA
    @Shivam-Sehgal , it seems you are using VOXL SDK that is more than one year old, please upgrade to the latest 1.3.5. If you are not able to upgrade, then please try the following: reduce the width/ height of hires camera large video stream to 3840x2160, if that does not help, reduce the FPS of hires camera to 25Hz disable snapshot if you are not using that feature try starting voxl-camera-server manually and assign upper cores 2-7 to the process, which helps with stability stop camera server running in the background (if applicable) : systemctl stop voxl-camera-server run camera server and assign cpu affinity using taskset : taskset -c 2-7 /usr/bin/voxl-camera-server Alex
  • GCS Primary IP when in Station Mode

    Unsolved
    4
    0 Votes
    4 Posts
    870 Views
    tomT
    @griffin Unless you have your network setup to manually cycle IP addresses every so often then your PC's IP address should stay the same. They're usually logged by mac address