
voxl-open-vins-server imu_to_cam RPY(deg) different output logs
-
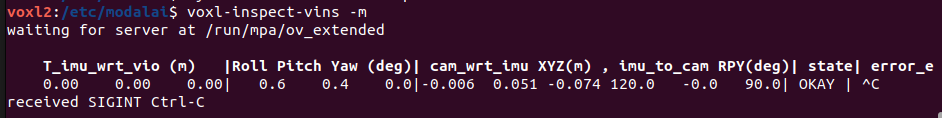
I am currently working with the VOXL 2 and attempting to run the voxl-open-vins-server alongside the voxl-feature-tracker. To configure the system, I set custom RPY (Roll, Pitch, Yaw) values for the drone in the extrinsics.conf file. However, when I attempt to log the values, the output does not match the expected results, and localization is not functioning properly.
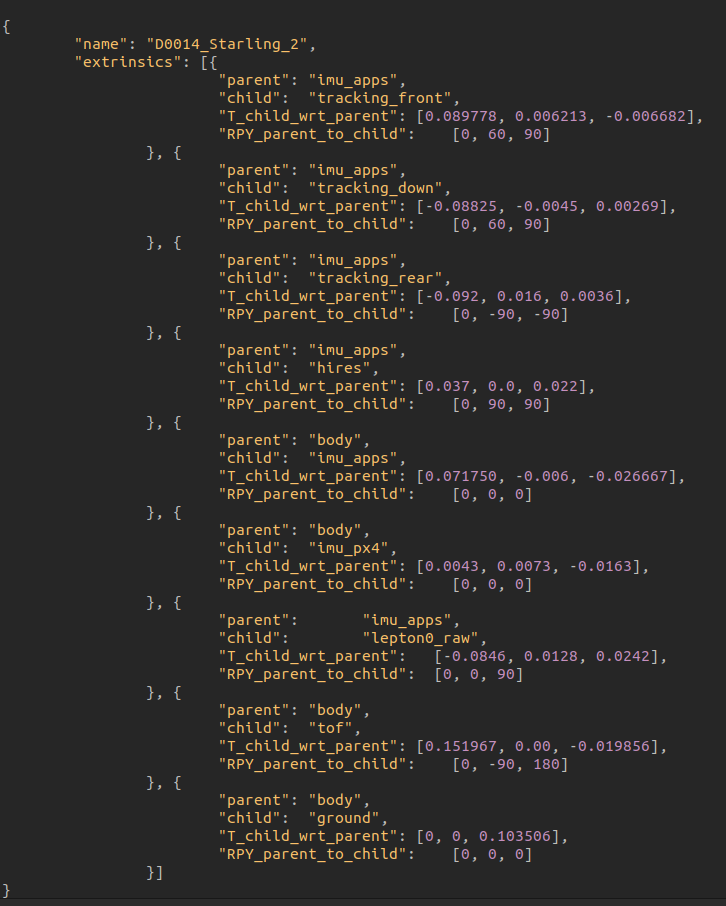
Here is the extrinsics.conf file with the custom settings I applied:
Here is the log output,
-
Unsure, if you have resolved this so I am going to attempt to help but I am going to need more information if possible. I am unsure how the setup is for the drone seems like you have one camera (Tracking_rear) pointed straight backwards and two cameras (Tracking_front, Tracking_down) facing forward at a 30 degree downward angle?
I am not sure that you are showing with the log output.
Have you tried hand testing using the commandvoxl-inspect-pose -land seeing how RPY and translational movement (moving the drone up, right, forward) are behaving for the local frame?


Reading along? Create a free ModalAI Forum account to join in.
With an account you can reply, ask your own question, get an email when a ModalAI engineer answers, and mark the reply that solved it. Your place in each thread is saved between visits.
Questions about VOXL, Flight Core, ESCs and ModalAI drones are answered here by the engineers who build them.
Register Login