Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • VOXL Deck Spacer Size

    Unsolved
    3
    0 Votes
    3 Posts
    539 Views
    L
    are you sure that this is the Vibration damper that you are using? cause your 3D cad model calls for a damper with different dimensions: [image: 1641735336418-b6107c8a-e568-4839-99d0-4387f6c68533-image.png] please advise which damper are you using in your Voxl flight deck.
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    7 Views
    No one has replied
  • VOXL rebooting PX4

    Unsolved
    2
    0 Votes
    2 Posts
    676 Views
    wilkinsafW
    It appears this happens when the sensors are not calibrated on the drone. voxl-vision-px4 picks up on sensor inconsistency and restarts PX4. So, calibrated the sensors. Looks better resolved
  • [Suggestion] Add fastboot device udev rule to "Setup ADB" tutorial

    Unsolved
    2
    1 Votes
    2 Posts
    549 Views
    modaltbM
    @omer-b thanks!! Added: [image: 1640270590811-5dc619fb-ca85-4b54-9d6a-e6e9c4567512-image.png]
  • VOXL FLIGHT with Arducopter (Ardupilot)

    Unsolved
    3
    0 Votes
    3 Posts
    542 Views
    R
    Thank you.
  • Hires Camera

    Unsolved
    1
    0 Votes
    1 Posts
    483 Views
    No one has replied
  • TOF Sensor Range

    Unsolved
    1
    0 Votes
    1 Posts
    522 Views
    No one has replied
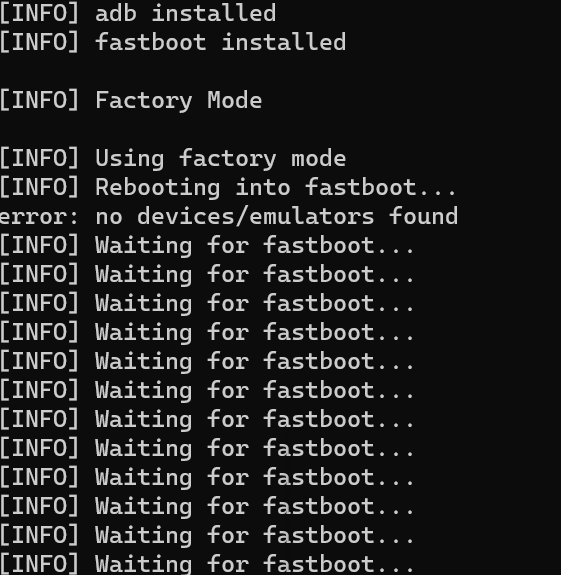
  • New image not installing waiting for fastboot

    Unsolved
    2
    1
    0 Votes
    2 Posts
    374 Views
    tomT
    @Shlok-Agarwal I assume you've taken a look at this page in our docs: https://docs.modalai.com/unbrick-voxl/ If not, give that a read through and it'll give you a bunch of good info. Were you able to ADB into the VOXL before you started the flashing process?
  • Setting up network interfaces

    Unsolved
    7
    1 Votes
    7 Posts
    2k Views
    Eric KatzfeyE
    @Nirge You should use voxl-wifi for wlan0.
  • Invalid local position

    Unsolved
    30
    0 Votes
    30 Posts
    11k Views
    A
    I found the QGC EKF2_AID_MASK parameter settings above (configuring to 280: Vision position fusion, vision yaw fusion, vision velocity fusion) to allow the seeker to enter position and off-board modes. Prior to configuring, QGC was receiving VIO but was still unable to enter position mode as referenced here To make the forum search engine happy: seeker position mode rejected
  • Change Pwm channel

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    modaltbM
    Alright! Thanks for the update, I'll likely use this post to get some updates to our docs, appreciate it!
  • Voxl-mapper instructions

    Unsolved
    2
    0 Votes
    2 Posts
    570 Views
    ?
    Hello @alarm_hq! Please see the updated readme on voxl-mapper's dev branch for an overview guide of this package. As for the timestamp too new error, this error typically arises when there is a VIO blowup, and one way to prevent this is by ensuring that the tracking camera is correctly calibrated pre-flight. Also, please see the overview guide for instructions on viewing, as RVIZ is no longer utilized!
  • This topic is deleted!

    2
    0 Votes
    2 Posts
    3 Views
  • Unable to run example TFlite model in emulator docker image

    Unsolved
    3
    0 Votes
    3 Posts
    551 Views
    Michael BarrowM
    Thanks, so what is the emulator for exactly? emulating native compilation? I am unclear of the emulator use case if it is not intended to emulate the voxl platform for application testing. Let me know, cheers!
  • Seeker replacement props

    Unsolved
    2
    0 Votes
    2 Posts
    609 Views
    ?
    Hey @alarm_hq! The props for the Seeker development drone can be found here.
  • How to: Seeker ESC calibration

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    James StrawsonJ
    @alarm_hq said in How to: Seeker ESC calibration: And if I've already made the "mistake" of reflashing px4 firmware, is the closed loop RPM control affected? The ModalAI ESCs used on Seeker have their own firmware and settings stored on the ESC itself, independent from PX4 so your ESC is fine after changing PX4 firmware.
  • Unstable Seeker after flashing

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    T
    Thanks Chad. We did the calibration again with a better calibration target, and this fixed the problem.
  • hires Camera for barcode

    Unsolved
    2
    0 Votes
    2 Posts
    488 Views
    Chad SweetC
    Have you looked at voxl-tag-detector?
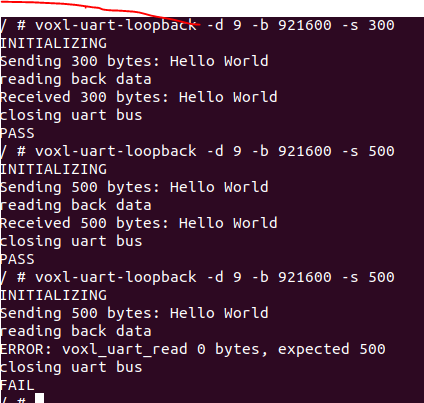
  • voxl-uart-loopback problems

    Unsolved
    2
    1
    0 Votes
    2 Posts
    519 Views
    Alex KushleyevA
    Hello, There were a few issues with the uart loopback example: the test buffer size was not handled properly (if test size is larger than HelloWorld strin the sleep time was not enough to allow the transfer to happen (the write function is non-blocking, it seems) I have made some fixes here: https://gitlab.com/voxl-public/core-libs/libvoxl_io/-/blob/dev/lib/apps/voxl-uart-loopback.c Now the behavior is as shown below.. please try it. ./voxl-uart-loopback -d 7 -b 9600 -s 20 INITIALIZING Sending 20 bytes: 0123456789:;<=>?@ABC Transfer should take ~20833us, sleeping for 25833us (+5000us overhead) Reading back data... Received 20 bytes: 0123456789:;<=>?@ABC closing uart bus PASS ./voxl-uart-loopback -d 7 -b 9600 -s 500 INITIALIZING Sending 500 bytes: 0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJ Transfer should take ~520833us, sleeping for 525833us (+5000us overhead) Reading back data... Received 500 bytes: 0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJ closing uart bus PASS
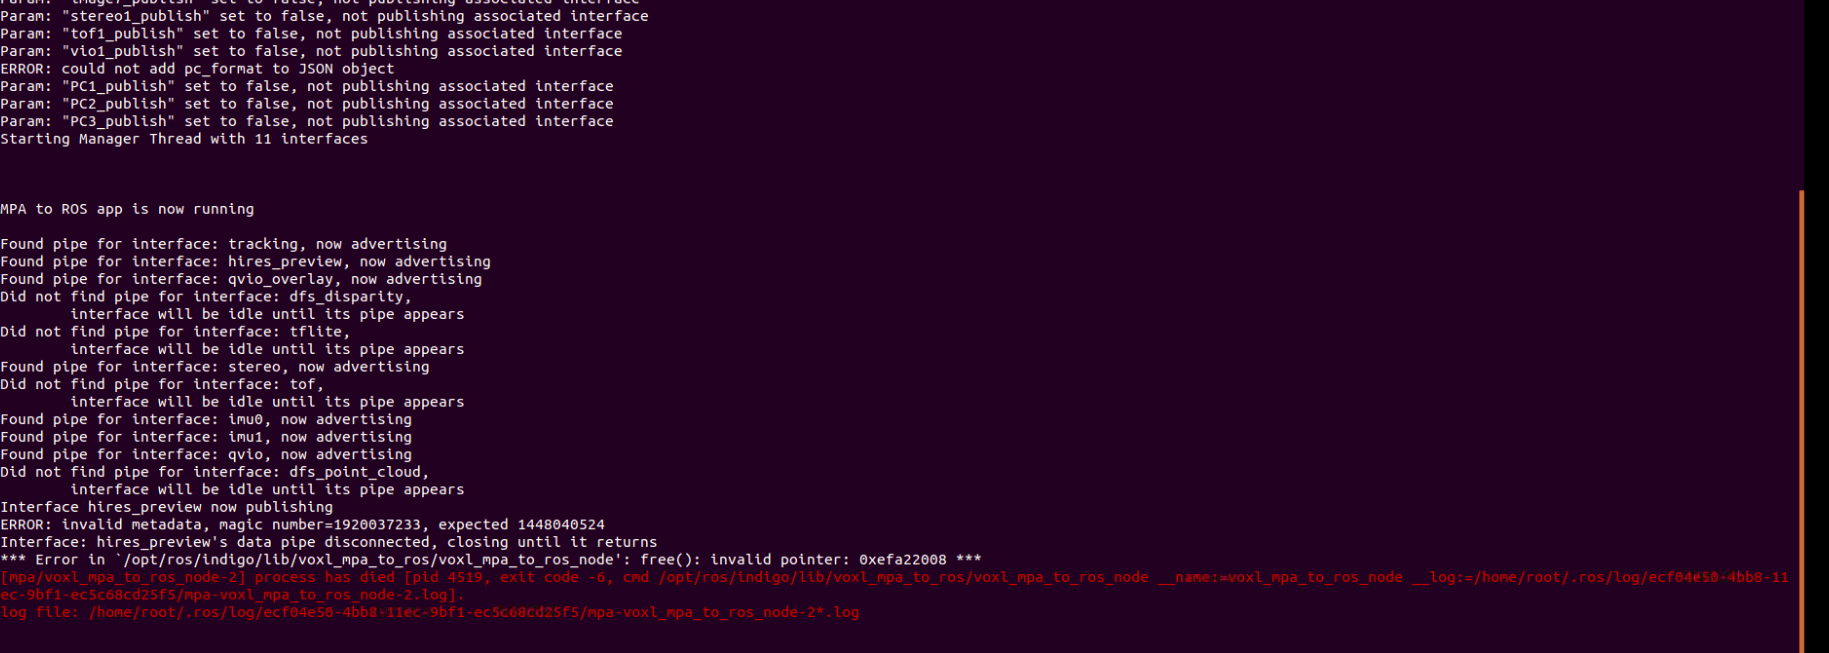
  • hires camera issue

    Unsolved
    2
    1
    0 Votes
    2 Posts
    482 Views
    ?
    Hi Prasobh, It looks like rosnode got an invalid metadata when reading from the hires camera pipe. This is an uncommon issue and should really only occur if the CPU is overloaded and starts throttling the client reading the camera images, eventually overflowing the camera pipe, thus getting out of sync. Additionally, it says that the data pipe disconnected, possibly indicating a problem with voxl-camera-server. If this occurs again, checking the logs with journalctl -u voxl-camera-server may provide some useful information as to what issue may have occurred on the hardware side.