Skip to content

VOXL 2 and VOXL 2 Mini

658 Topics 3.7k Posts

VOXL 2, VOXL 2 Mini and VOXL 2 IO: bring-up, connectors, power, cameras, system image and SDK installs on the current compute platform.

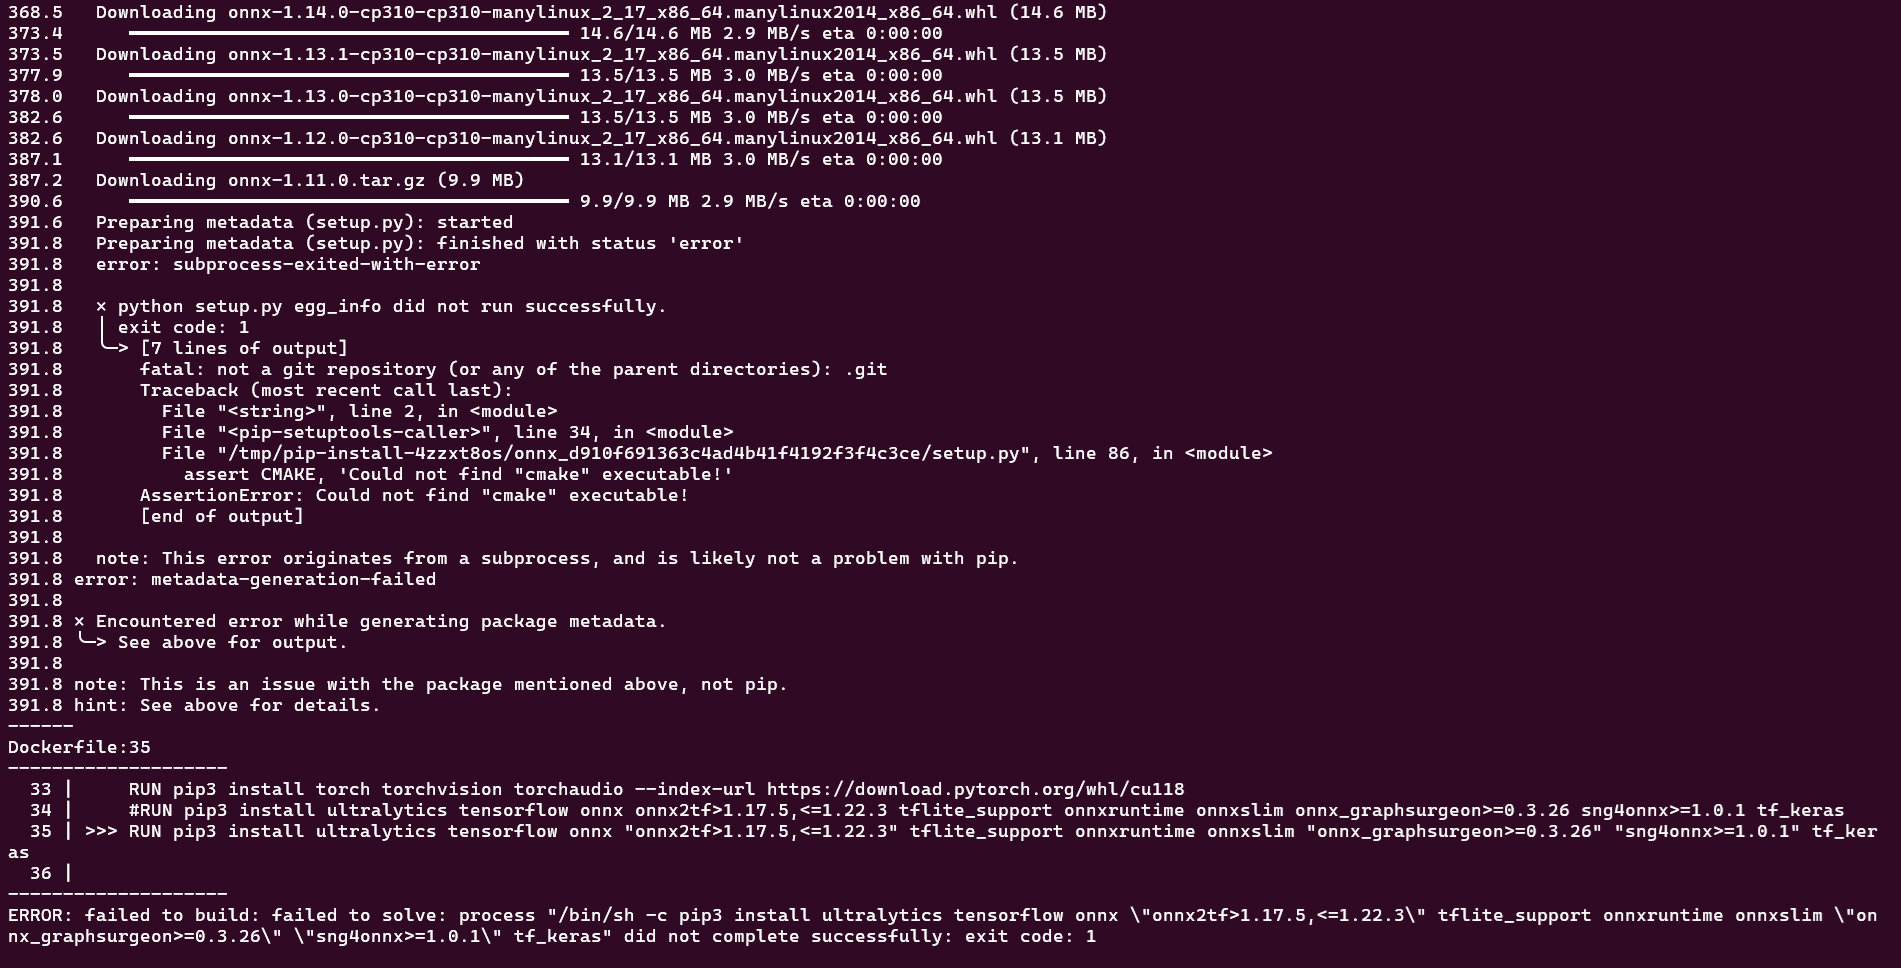
  • Issues building Yolov8 trainer

    Unsolved voxl-2-mini
    3
    1
    0 Votes
    3 Posts
    1k Views
    J
    @Robbie-McCue worked, thanks so much!
  • Unable to setup compass

    Unsolved voxl-2
    6
    0 Votes
    6 Posts
    973 Views
    K
    I have the same problem before — turns out the compass setup finally worked after I did a full sensor recalibration in QGroundControl and made sure the GPS/compass was facing the right direction. Worth a try if you haven’t done that yet! You can also try this tool for free. https://123compass.org/
  • Throttle Doesnt Work

    Unsolved voxl-2-mini
    7
    0 Votes
    7 Posts
    2k Views
    Eric KatzfeyE
    @jeremyrbrown5 Ah, yes, that'll do it.
  • What is the correct process to recover the voxl 2?

    Unsolved voxl-2
    8
    0 Votes
    8 Posts
    2k Views
    tomT
    @Dmytro-Stolbovyi Here is the updated link: https://docs.modalai.com/voxl2-unbricking/
  • Compatible Stereo Camera and live streaming components - NON GPS

    Unsolved voxl-2
    7
    0 Votes
    7 Posts
    925 Views
    N
    @Moderator Many thanks for your reply Our goal is to develop a drone capable of indoor/confined-space autonomous flight without GPS, using SLAM-based navigation. The system should perform 3D mapping, obstacle avoidance, and full-area path planning. We would like to confirm the correct set of components and the required algorithm stack. Planned Algorithm Stack: State Estimation: QVIO (Visual-Inertial Odometry) providing position and velocity to PX4/EKF2 via voxl-vision-hub. Mapping: voxl-mapper (TSDF/ESDF) using a depth source. Planning and Avoidance: voxl-mapper’s path planner or PX4 avoidance, using VIO as the pose source. Autopilot: PX4 running on VOXL2 via voxl-px4. Proposed Hardware: VOXL2 Autopilot – https://www.modalai.com/products/voxl-2?variant=39914779836467 VOXL2 Tracking Camera (Mono Global-Shutter) – required for QVIO (please confirm the correct part number). -- https://www.modalai.com/collections/image-sensors/products/msu-m0149-1 VOXL2 Compatible adapter https://www.modalai.com/products/mdk-m0076-1 VOXL2 Time-of-Flight (ToF) Depth Sensor – https://www.modalai.com/products/m0178?variant=48528287793456 VOXL2 Mini 40-Pin Connector ToF Adapter (MDK-M0172-1-00) – https://www.modalai.com/products/mdk-m0172-1-00 Questions: Please confirm if this set (VOXL2 + Tracking Camera + Camera adapter + ToF sensor + ToF adapter) is sufficient for robust indoor SLAM navigation using PX4. For the tracking camera, which exact ModalAI part number is recommended for QVIO on VOXL2? Are there any best-practice configurations for voxl-mapper when using ToF instead of stereo depth? Would you recommend any additional sensors for improved performance in larger or more complex indoor environments? Goal Summary: We want the drone to hold position, generate a 3D occupancy map, avoid obstacles, and autonomously plan paths throughout the flyable space—without any GPS input. Thank you in advance for your guidance and confirmation. Best regards, Nitin
  • WASP-200 LIDAR on Starling 2 Max

    Unsolved voxl-2
    4
    0 Votes
    4 Posts
    697 Views
    Eric KatzfeyE
    @adiprin1 On Ardupilot there is currently no way to use apps side UARTs (Some day we will add a method to use them). So, you would have to use one of the 3 UARTs attached to the DSP. If you removed the RC or the GPS and used that port then, theoretically, it could work. However, we have not tried that so can't make any guarantees. Also on PX4 you can use an apps side UART if there is one available on an add-on board. And, as you mention, you could use an SBUS RC on the VOXL 2 IO board and free up the standard RC UART.
  • NTP versus Systemd-timesyncd on the VOXL2

    Unsolved voxl-2
    4
    0 Votes
    4 Posts
    832 Views
    Alex KushleyevA
    @Aaron-Porter , perhaps systemd-timesyncd works together with systemd to correctly interpret the clock adjustments, so that run-time of systemd services is properly calculated. Alex
  • Optimizing DSP Load wr.t. IO

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    644 Views
    Eric KatzfeyE
    @Alex-Kushleyev The IMU is being configured with an 8K ODR so by increasing IMU_GYRO_RATEMAX you are reading the FIFO more often but reading less samples each time. So you are mainly increasing the overhead of context switching. Can you characterize how much the load increases just by increasing IMU_GYRO_RATEMAX and not doing any of the extra UART IO? Unfortunately we don't have a lot of control over the low level implementation of the IO drivers that are in the Qualcomm code. And there is no DMA that could help lower IO overhead. One idea would be to lower the ODR to 1K so that you are only reading one sample from the FIFO at each interrupt.
  • VOXL 2 blinking green and not connecting

    Unsolved voxl-2
    1
    0 Votes
    1 Posts
    309 Views
    No one has replied
  • QGC not loading proper

    Unsolved voxl-2
    8
    0 Votes
    8 Posts
    1k Views
    Jetson NanoJ
    @tom Thank you for the support.
  • Ethernet Dongle

    Unsolved voxl-2
    20
    0 Votes
    20 Posts
    4k Views
    tomT
    @Huynh-Gremsy No, there is no way to do that. There is no display output
  • Changing Time stamps from Monotonic to Real-Time

    Unsolved time imu camera voxl-2
    6
    0 Votes
    6 Posts
    2k Views
    Eric KatzfeyE
    @Aaron-Porter Most likely jump is due to NTP aligning the clock. The other device that is time stamping using real time clock really should move to monotonic.
  • Neopixel Integration with PX4

    Unsolved voxl-2-io
    3
    1 Votes
    3 Posts
    2k Views
    J
    @Alex-Kushleyev , Thank you for the clarification! We will change the service and see if it meets our needs. Regards, Jacob
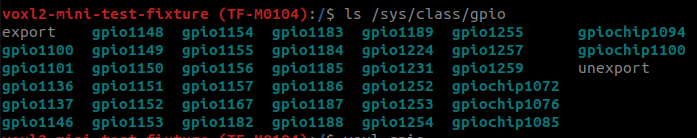
  • GPIO missing in /sys/class/gpio

    Unsolved voxl-2-mini
    6
    1
    0 Votes
    6 Posts
    2k Views
    Eric KatzfeyE
    @psafi Unfortunately, the Mavlink module is not available on the DSP side. We tried it in the past and there were a lot of issues so we only have it on the apps side. You are welcome to try to add it into the DSP side and see how it goes.
  • EIS merge

    Unsolved voxl-2
    32
    0 Votes
    32 Posts
    9k Views
    Alex KushleyevA
    @Federico-Wyrwal , please check the instructions for setting up EIS, specifically https://docs.modalai.com/camera-video/electronic-image-stabilization/#minimal-software-setup The latest drivers can be downloaded from here Please let me know if you have any other questions. Alex
  • Incomplete file in voxl-opencv

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    569 Views
    R
    @Alex-Kushleyev Thanks
  • Ubuntu 20.04 for Voxl 2 Mini

    Unsolved voxl-2-mini
    2
    0 Votes
    2 Posts
    430 Views
    tomT
    @detlefurig Yes that is something we're actively working on, probably a few months out at this point
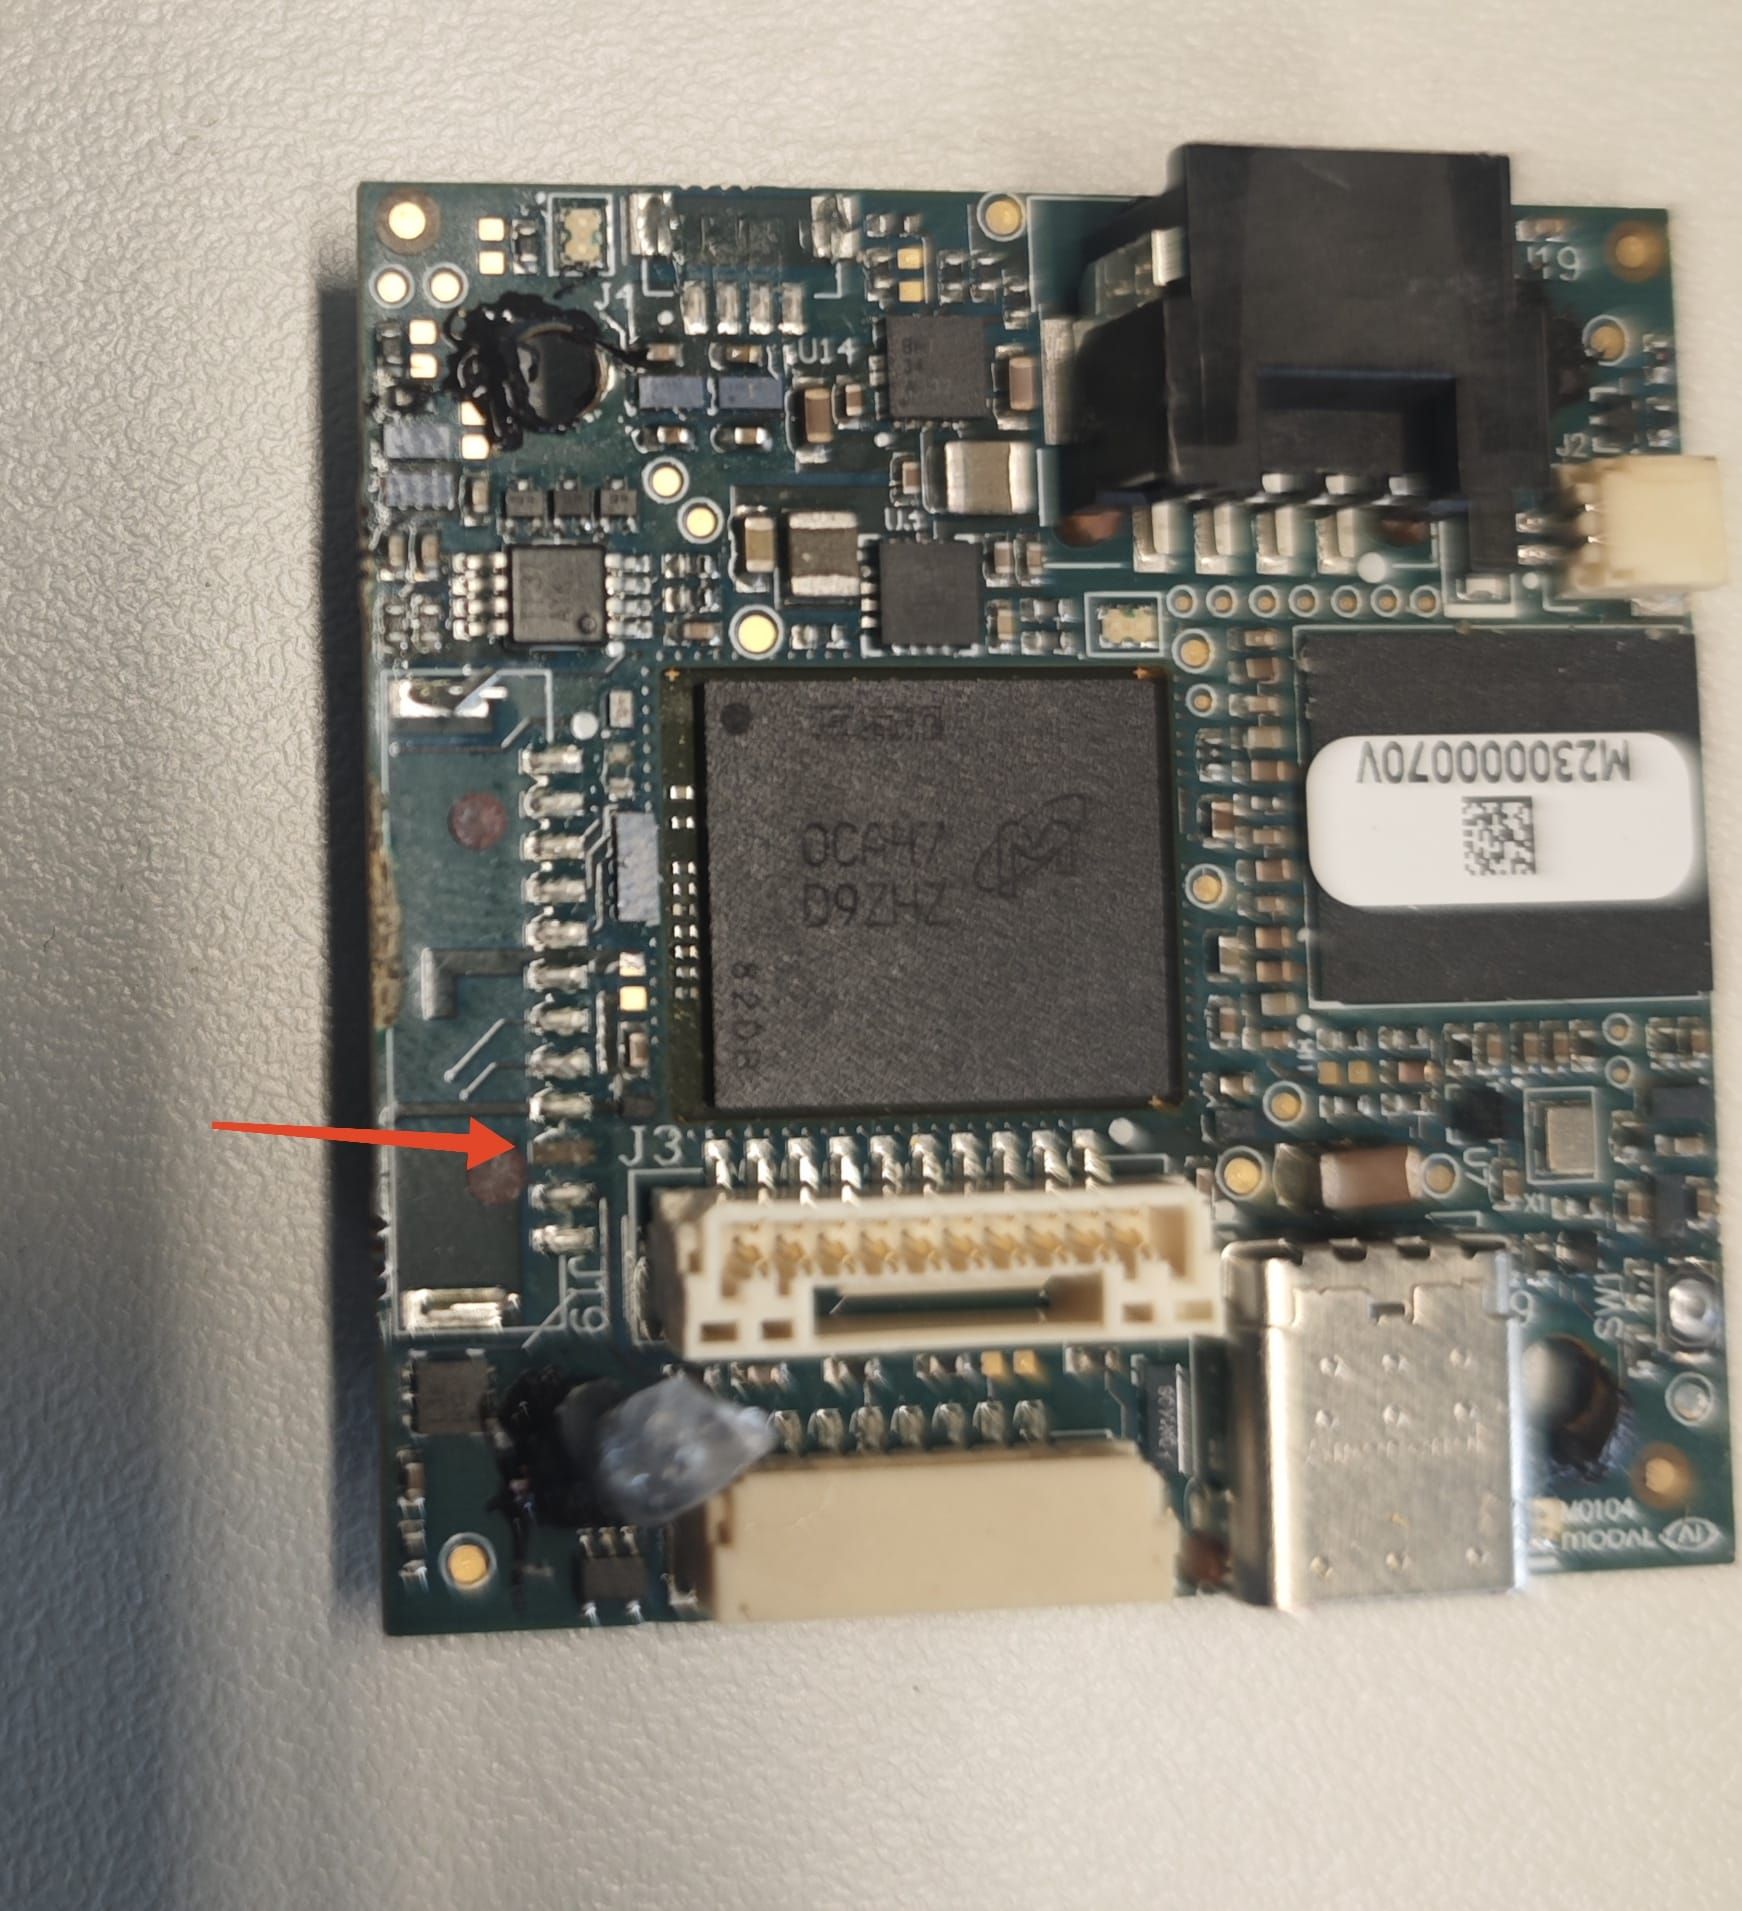
  • Tap UART TX (RC) pin signal elsewhere

    Unsolved voxl-2-mini
    3
    1
    0 Votes
    3 Posts
    572 Views
    VinnyV
    Hi @TomP Looking pretty grim... That specific signal is all buried at least 3-7 layers deep directly from that pad and it hits other BGA devices right in the pad.... no exposed traces, no exposed pins at all... You'll have to find a different UART port or some other plan B.... sorry.
  • Please review on required add-on's with VOXL2 for CAN, HDMI, S-BUS and PWM

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    652 Views
    H
    @J-B-Song Hello J.B Song, Did you connect HDMI via USB-C on VOXL2? Did you use this image [image: 1756439982349-7d1ec055-c0a2-497c-8c85-be95d56a1125-image.png] Hope your reply soon, thanks so much.
  • Lumenier RID & M10Q GPS Module compatibility

    Unsolved voxl-2-mini
    21
    0 Votes
    21 Posts
    5k Views
    P
    @Eric-Katzfey I did the systemctl stop and started service again. I guess rebooting the board earlier did not have the same effect. The compass calibration in Q is working now (no more "no mag found" error) which I guess it means the mag is working now and our gps is working too. here is the output of voxl-p4 -d by the way: INFO [qshell] Send cmd: 'lis3mdl start -R 10 -X -b 1' INFO [muorb] [uORB] Marking DeviceNode(qshell_req) as advertised in process_remote_topic INFO [muorb] [qshell] qshell gotten: lis3mdl start -R 10 -X -b 1 INFO [muorb] [qshell] arg0 = 'lis3mdl' INFO [muorb] [qshell] arg1 = 'start' INFO [muorb] [qshell] arg2 = '-R' INFO [muorb] [qshell] arg3 = '10' INFO [muorb] [qshell] arg4 = '-X' INFO [muorb] [qshell] arg5 = '-b' INFO [muorb] [qshell] arg6 = '1' INFO [muorb] [drivers__device] *** I2C Device ID 0x51e09 335369 INFO [muorb] [drivers__device] Set up I2C bus mutex for bus 1 INFO [muorb] lis3mdl #0 on I2C bus 1 INFO [muorb] (external) INFO [muorb] address 0x1E INFO [muorb] rotation 10 INFO [muorb] INFO [muorb] [qshell] Ok executing command: lis3mdl start -R 10 -X -b 1