Skip to content

VOXL 2 and VOXL 2 Mini

658 Topics 3.7k Posts

VOXL 2, VOXL 2 Mini and VOXL 2 IO: bring-up, connectors, power, cameras, system image and SDK installs on the current compute platform.

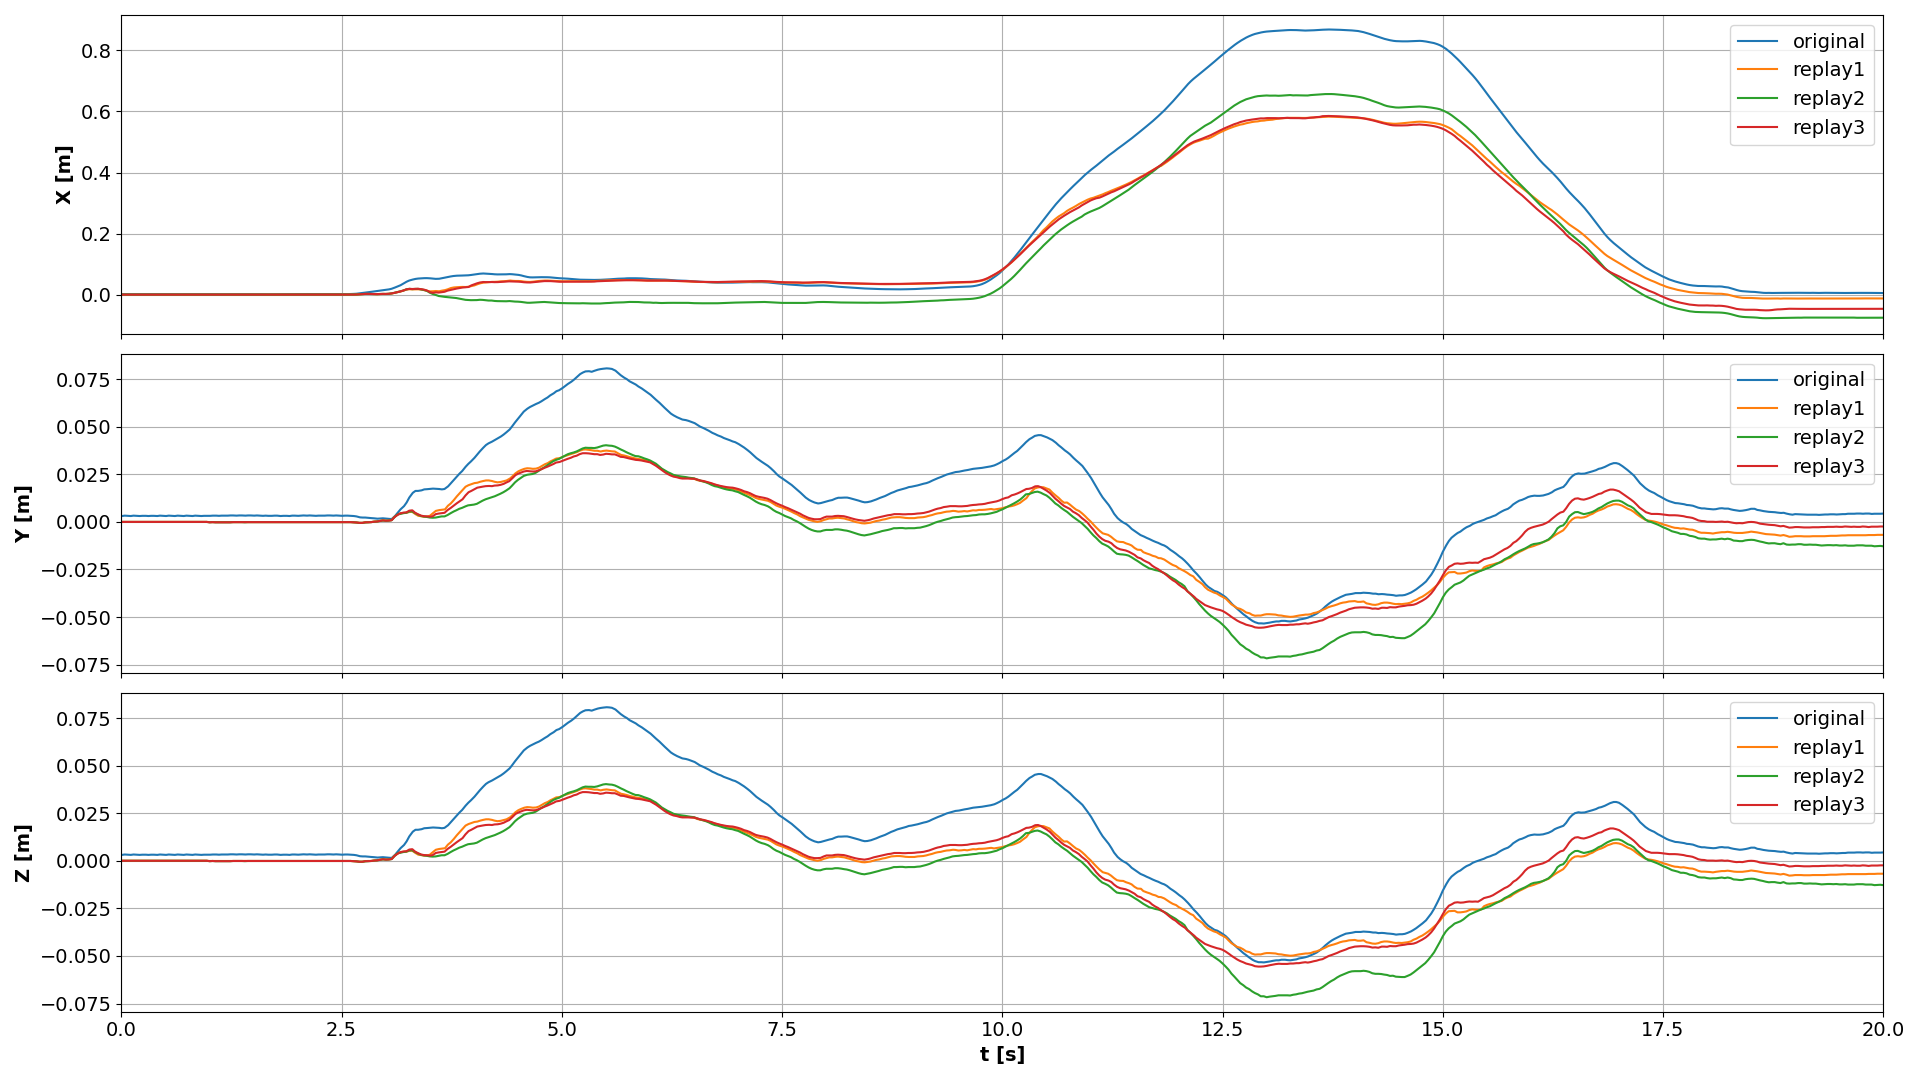
  • voxl-replay repeatability

    Unsolved voxl-2
    3
    1
    0 Votes
    3 Posts
    692 Views
    V
    Yes, those servers were disabled. The QVIO server was running. You can download the log here. please note the modified info.json file which was used to replay only the IMU and the camera data.
  • 0 Votes
    4 Posts
    2k Views
    P
    1,000,000 bps (1Mbps) seems low for a FHD stream. What bitrates did you try? Did you try increasing it to 10,000,000 or even 30,000,000 to see if that makes a difference? I'm running 1920x1080 @ 20 FPS with no major artifacts using this. The alternative would be either changing resolution or trying to switch to a different codec such as H265 or VP9 (which appear to be supported on the VOXL2 by just searching the gst-inspect-1.0 output), but that would require changes to the voxl-streamer source.
  • Connect to QgroundControl using usb

    Unsolved voxl-2
    1
    0 Votes
    1 Posts
    428 Views
    No one has replied
  • some general questions / issues with voxl2

    Unsolved voxl-2
    10
    0 Votes
    10 Posts
    2k Views
    James StrawsonJ
    Regarding voxl-configure-docker-support, I tried and was unable to replicate it causing VOXL not to boot. voxl-configure-docker-support isn't strictly necessary, it's just a handy tool to apt-install docker-ce from the internet and replace the official docker systemd service with one that we tweaked for VOXL. I did find that the optional docker-autorun service was not starting on boot, that is now fixed in voxl-docker-support v1.2.5 If you are still seeing voxl-configure-docker-support preventing voxl from booting I can look into it more if you provide a full copy/paste of the output from running that command. Perhaps something is different between our configurations.
  • Voxl-replay

    Unsolved voxl-2
    2
    0 Votes
    2 Posts
    524 Views
    Chad SweetC
    voxl-replay should be working on VOXL 2.
  • EIS Support

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    495 Views
    Cosmin StanC
    Understood. Thanks, Chad.
  • VOXL2 TOF release timeline

    Unsolved voxl-2
    4
    0 Votes
    4 Posts
    648 Views
    Chad SweetC
    Right now we just support QTY. 2 TOF on VOXL 2. We will look to add more in the future.
  • Cannot connect QGroundControl to internal PX4 (VOXL2)

    Unsolved voxl-2
    3
    0 Votes
    3 Posts
    714 Views
    M
    @Chad-Sweet I haven't tried. However, I manage to get it working by doing a factory reset configuration of the VOXL2. Don't know why it made a difference though.
  • How to install lider and optiocal sensors with voxl2?

    Unsolved voxl-2
    2
    0 Votes
    2 Posts
    386 Views
    Chad SweetC
    Yes, of course. VOXL 2 is a Debian Linux single board computer with tons of I/O. Check out the data sheets at https://docs.modalai.com/voxl-2 and there are many options for connectivity and a complete development environment for you to write code to build the capabilities required for your application
  • VOXL 2 Kits weight

    Unsolved weight volx2 grams mass voxl-2
    3
    1
    0 Votes
    3 Posts
    2k Views
    E
    [image: 1671029064348-whatsapp-image-2022-12-14-at-15.29.48.jpeg] Here is the weight in a balance with and without power module. [image: 1671029207466-whatsapp-image-2022-12-14-at-15.46.24.jpeg] For our application, we will change the huge 12AWG cables and XT60 connectors for short 18AWG cables and XT30 connectors. Eloi Vilalta
  • Setting up micrortps bridge on VOXL2/Sentinel

    Unsolved voxl-2
    15
    0 Votes
    15 Posts
    3k Views
    Kyungtaek Oh 0K
    Hi @Eric-Katzfey, We had some finds. Here's what we've understood so far: Two things are needed to make a voxl-px4 package using px4-firmware(voxl-dev) modalai_rb5-flight_default modalai_rb5-flight_qurt And each one needs the following different crsf_parse function modalai_rb5-flight_default needs crsf_parse(6 arguments) modalai_rb5-flight_qrut needs crsf_parse(8 arguments) Each px4-firmware has a different version of crsf_parse Branch: main has crsf_parse(6 arguments) Branch: voxl-dev has crsf_parse(8 arguments) Our goal was to build the voxl-px4 included MicroRTPS_bridge in px4-firmware(branch: voxl-dev), so we added the following two functions to crsf.cpp in px4-firmware. bool crsf_parse_buffer(uint16_t *values, uint16_t *num_values, uint16_t max_channels) as crsf_parse_buffer_6 bool crsf_parse(const uint64_t now, const uint8_t *frame, unsigned len, uint16_t *values, uint16_t *num_values, uint16_t max_channels) as crsf_parse_6 Then the build progressed to 89% and stopped with an error below. ERROR #1 [ 89%] Building CXX object src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/pwm.cpp.o /usr/local/workspace/px4-firmware/src/systemcmds/pwm/pwm.cpp: In function 'int pwm_main(int, char**)': /usr/local/workspace/px4-firmware/src/systemcmds/pwm/pwm.cpp:810:3: error: 'qurt_loop' was not declared in this scope 810 | qurt_loop = 320; | ^~~~~~~~~ compilation terminated due to -Wfatal-errors. make[3]: *** [src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/build.make:63: src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/pwm.cpp.o] Error 1 make[3]: Leaving directory '/usr/local/workspace/px4-firmware/build/modalai_rb5-flight_default' make[2]: *** [CMakeFiles/Makefile2:12085: src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/all] Error 2 make[2]: Leaving directory '/usr/local/workspace/px4-firmware/build/modalai_rb5-flight_default' make[1]: *** [Makefile:152: all] Error 2 make[1]: Leaving directory '/usr/local/workspace/px4-firmware/build/modalai_rb5-flight_default' make: *** [Makefile:222: modalai_rb5-flight_default] Error 2 We changed the int qurt_loop variable's scope to like this. Before [image: 1670957157167-32b86fac-1631-4048-b2ce-a29792ee533b-untitled.png] After [image: 1670957171221-f6a25f03-3c63-4f66-92e4-b3181adacef6-untitled-1.png] After that, an error occurred for the label for jump, and it was resolved by changing it as follows. ERROR #2 [ 89%] Building CXX object src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/pwm.cpp.o /usr/local/workspace/px4-firmware/src/systemcmds/pwm/pwm.cpp: In function 'int pwm_main(int, char**)': /usr/local/workspace/px4-firmware/src/systemcmds/pwm/pwm.cpp:864:1: error: jump to label 'err_out_no_test_2' 864 | err_out_no_test_2: | ^~~~~~~~~~~~~~~~~ compilation terminated due to -Wfatal-errors. make[3]: *** [src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/build.make:63: src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/pwm.cpp.o] Error 1 make[3]: Leaving directory '/usr/local/workspace/px4-firmware/build/modalai_rb5-flight_default' make[2]: *** [CMakeFiles/Makefile2:12085: src/systemcmds/pwm/CMakeFiles/systemcmds__pwm.dir/all] Error 2 make[2]: Leaving directory '/usr/local/workspace/px4-firmware/build/modalai_rb5-flight_default' make[1]: *** [Makefile:152: all] Error 2 make[1]: Leaving directory '/usr/local/workspace/px4-firmware/build/modalai_rb5-flight_default' So we changed the goto command to "return 0" instead of using err_out_no_test_2 label. After that, the build.sh worked and the make_packages.sh also worked.(in the voxl-px4) However, it did not run with the following error on voxl2. ERROR #3 voxl2:~$ voxl-px4 Found DSP signature file /usr/bin/voxl-px4: line 42: /usr/bin/px4: cannot execute binary file: Exec format error Based on the above results, we think the voxl-px4 with microRTPS_bridge can be built by changing modalai_rb5-flight_default and modalai_rb5-flight_qurt to use the same crsf_parse. So if you think our thinking is correct, can you give us some guidance? If it is not possible in px4-firmware(branch: voxl-dev), can we build voxl-px4(included micrortps_bridge) using another branch? Any advice would be appreciated.
  • Connection to QGC/ Vision not running

    Unsolved voxl-2
    2
    2
    0 Votes
    2 Posts
    648 Views
    M
    MPA Config took care of it.
  • VOXL2 bricked

    Unsolved voxl-2
    13
    0 Votes
    13 Posts
    2k Views
    M
    Hi @tom, Thank you for your help, I got it going and is now back to a usable state!
  • USB to TTL cable connection

    Unsolved voxl-2
    4
    0 Votes
    4 Posts
    789 Views
    M
    This was very helpful, thank you!
  • VOXL2 flight deck - m500 fit

    Unsolved voxl-2
    6
    -1 Votes
    6 Posts
    1k Views
    Adrian HidalgoA
    @JoeC gotcha. If you could email us at: contact@modalai.com we can get started
  • VOXL2 to USB A 3.1 J3 Breakout Board

    voxl-2
    2
    0 Votes
    2 Posts
    373 Views
    VinnyV
    @Moderator Pin 8 is not needed. The USB on Voxl/Voxl2 J13/J3 is always a HOST. Previous gen designs used this for OTG selection, so we manage this directly on Voxl2. For all intents and purposes, pin 8 is a "dead pin" and should be N.C. (no connect). Let us know if you have any other questions. Thanks
  • TBS Crossfire on VOXL 2 IO

    Unsolved voxl-2-io
    4
    0 Votes
    4 Posts
    1k Views
    modaltbM
    Hi @Roy-Wood , Natively, the RC and PX4IO drivers are looking at UART on J19. The ESC driver natively looks to J18 (E in the diagram). We've not tried RC on that UART and it's not "easily" configurable through a PX4 param, although I'm pretty sure modifying code could get it going... let me know if you are opening the hood up to the code base and I can point ya towards areas.
  • Can we use QUP3 I2C bus on J19?

    Unsolved voxl-2
    5
    0 Votes
    5 Posts
    702 Views
    ?
    Thanks alot @Chad-Sweet for guidance. I will look into rangefinder server for further integration.
  • No messages from PX4

    Unsolved voxl-2
    2
    0 Votes
    2 Posts
    678 Views
    James StrawsonJ
    Have you used an oscilloscope to probe the line from the flight controller to VOXL2 to make sure the flight controller is sending data at the correct baudrate? Also note that the logic level of that UART connector on M0125 is 3.3V, I'm not sure if that matches the expected logic level of the port you are using on the CubeOrange. Also note PX4 requires some serial port configuration. We normally use mavlink channel 1 with the Telem2 port on our flight core set to 921600 and 'onboard' mode. This translates to the following px4 param settings, note that yours will most likely be different due to using a different flight controller in a different configuration. MAV_1_CONFIG 102 MAV_1_FORWARD 0 MAV_1_MODE 2 MAV_1_RATE 0 SER_TEL2_BAUD 921600
  • ADFS (Adaptive data fusion system) support on VOXL2

    Unsolved voxl-2
    1
    0 Votes
    1 Posts
    301 Views
    No one has replied