Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Indoor path navigation

    Unsolved
    2
    0 Votes
    2 Posts
    466 Views
    Steve TurnerS
    One of the Modal team can probably chime in on this... but I'll throw out a few thoughts. It would definitely be feasible with the Seeker drone, but would require some programming knowhow to leverage the mapping software Modal has out of the box. You could walk the drone around the space manually once to build the first map and then from there on have a path with waypoints around the space for it to fly the Insta360 around to capture updates of construction. Alternatively you could use one of the VOXL cameras to capture.
  • Hello, I bought voxl this time.

    Unsolved
    2
    0 Votes
    2 Posts
    411 Views
    modaltbM
    Hi @마페링 , Double checking, do you have a VOXL Flight and not a VOXL? For the USB connection, what port are you using? The ADB connection is to talk to Linux (not PX4) and to talk to PX4 over USB you will want to use the J1006 connector. Thanks!
  • Implementing PX4 avoidance in mission mode using the voxl and QGC

    Unsolved
    20
    0 Votes
    20 Posts
    4k Views
    J DataJ
    @modalab Hello, can you help me to resolve this problem?
  • Unable to configure RB5 from Qgroundcontrol

    Unsolved
    7
    0 Votes
    7 Posts
    786 Views
    Eric KatzfeyE
    @prjana Can you arm the drone? Obviously with appropriate safety precautions as this can be an extremely dangerous thing to do if you aren't very careful! But arming the drone will cause the motors to spin.
  • PX4 mavlink flight modes

    Unsolved
    2
    0 Votes
    2 Posts
    831 Views
    Cliff WongC
    Mavlink messages for setting flight mode use the MAVLINK_MSG_ID_SET_MODE message type (same as APM). Modes are defined in the uOrb layer under the vehicle_status.msg fie, which C headers are auto-generated at build time. The auto-generated file is under the build directory as vehicle_status.h via the NAVIGATION_STATE_* variables. And example of using modes in runtime code are in the mavlink_messages.cpp file (search for vehicle_status_s::NAVIGATION_STATE_AUTO_MISSION) and modes are processed in the Commander.cpp file. Both files under the src/modules directory of PX4.
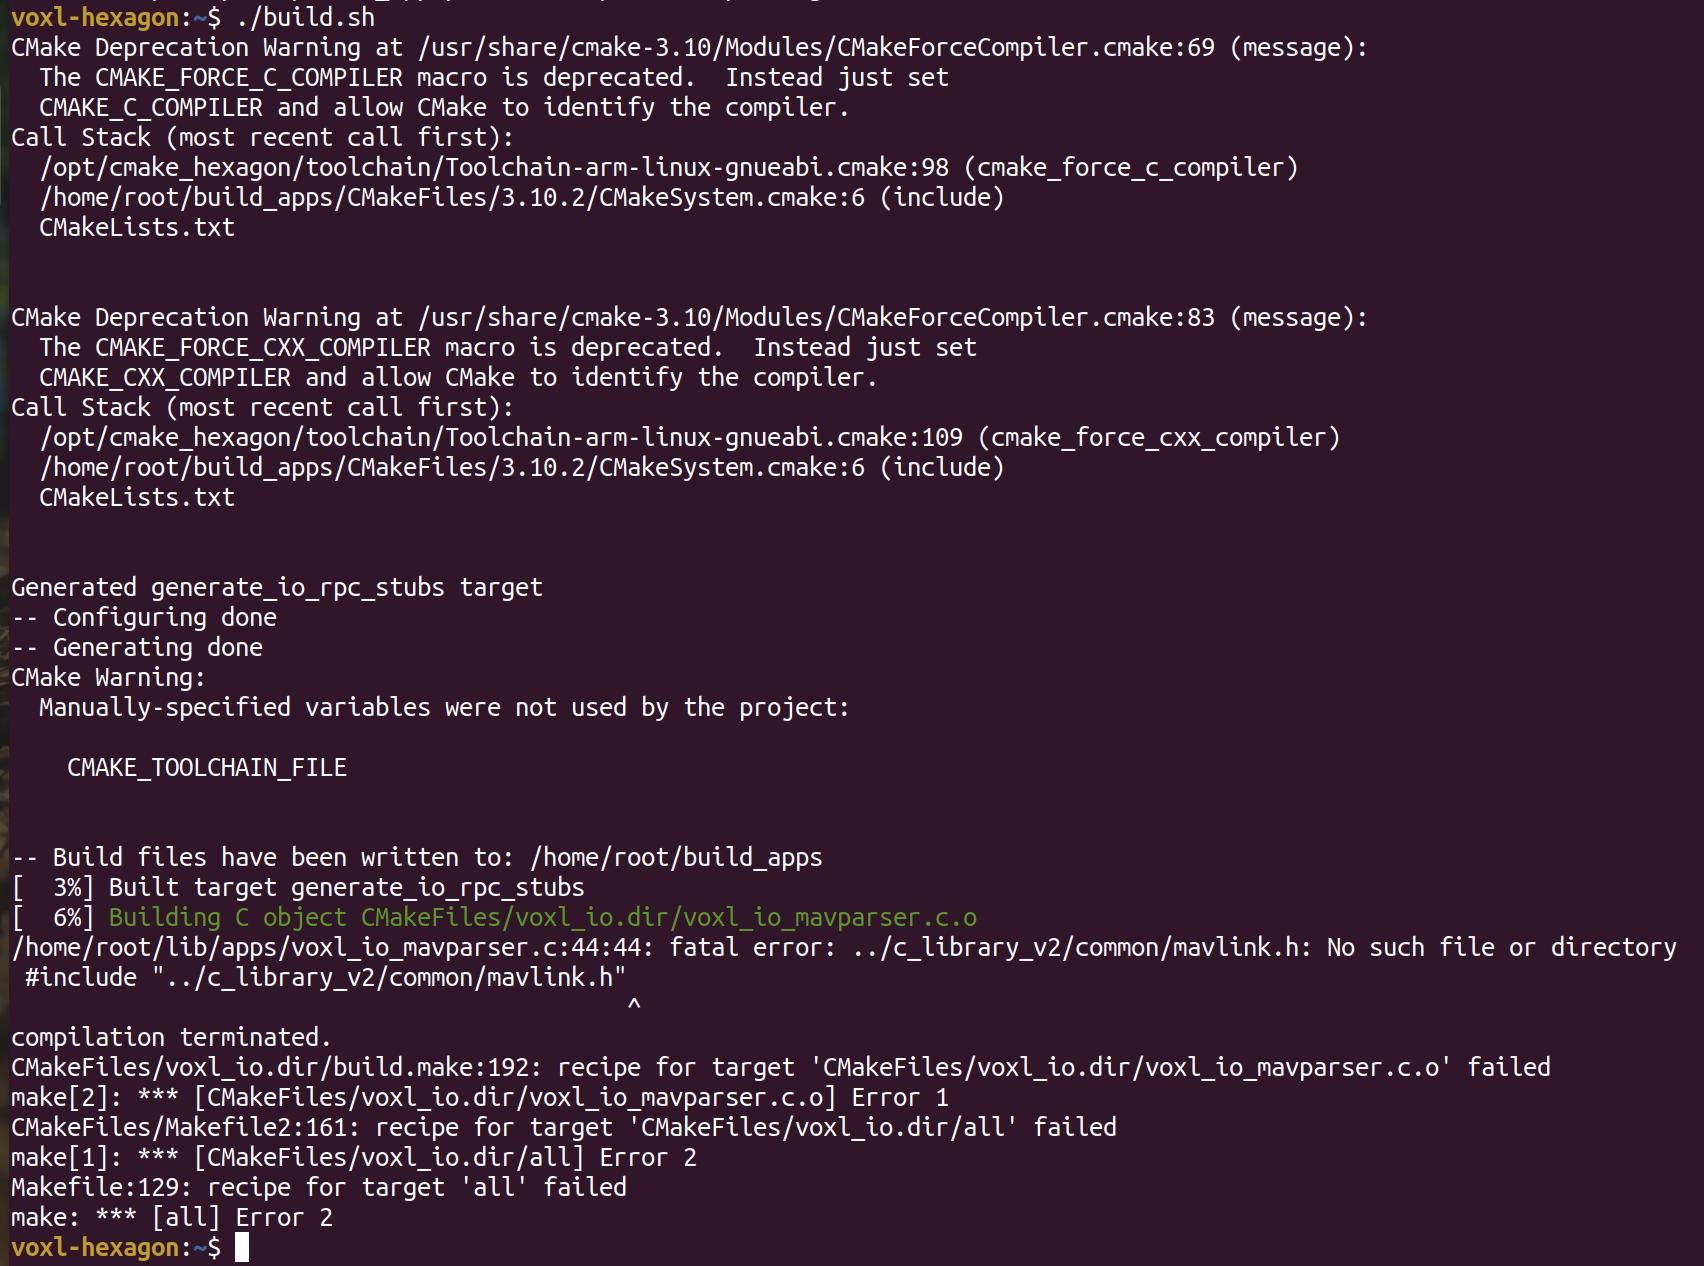
  • Voxl-hexagon build.sh

    Unsolved
    6
    1
    0 Votes
    6 Posts
    1k Views
    SHofmeesterS
    @Eric-Katzfey Thank you for your help. I followed your steps and it worked immediately. I am now also able to generate the ipk-package and push it to the VOXL. When I use adb shell, the file appears in home/root/ipk. I tried a few things, but I still have some questions: How can I run the i2c related files from "libapq8096-io/lib/python" on the VOXL, for example voxl_i2c_scan.py? Can I also make my own python scripts and run them?
  • Running customized software in emulators

    Unsolved
    2
    0 Votes
    2 Posts
    460 Views
    Eric KatzfeyE
    @Daniel-Lin ModalAI does not have any plans to produce hardware emulation at this point. However, I don't think buggy code will ruin an m500 (assuming you aren't flying, of course). We develop all of our hardware device drivers directly on target without any issue. For added safety, please remove the propellers before doing any such development.
  • Questions regarding the VOXL m500

    Unsolved
    4
    0 Votes
    4 Posts
    597 Views
    Eric KatzfeyE
    @Remco-Roelofs You can find more information about our Microhard and Doodle Labs support here: https://docs.modalai.com/microhard-modems/ and here: https://www.modalai.com/collections/accessories/products/voxl-microhard-modem-usb-hub. I would urge you to work with Microhard and Doodle Labs directly to verify that their products can do what you need.
  • Arming Issues with Controller

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    R
    Any updates on this?
  • How to enable LVDS data streaming on VOXL m500?

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    yu zhangY
    @Eric-Katzfey Thanks for reminding me about this So, I may have to switch to using the J8 in different scenarios.
  • Unable to send mav commands by voxl-mapper

    Unsolved
    3
    0 Votes
    3 Posts
    696 Views
    JP DroneJ
    @Matt-Turi Thank you for your quick response. After updating to v0.0.5, it worked!
  • Stabilized Flight Mode

    Unsolved
    4
    0 Votes
    4 Posts
    865 Views
    A
    @tom After playing around with CP_DIST, it seems any value > 0 causes position mode to no longer want to allow x/y translation. From what I understand, any value < 0 disables object avoidance. Is this true? As far as I'm aware, my settings should be in parity with Modal provided guidance in regards to seeker setup with additional configurations overridden to support voxl-mapper. Thanks for the stabilized advice @mohammednaveed, I've gone as far to replace manual mode with this setting.
  • VOA bug

    Unsolved
    1
    1
    0 Votes
    1 Posts
    280 Views
    No one has replied
  • Replacement motors for m500

    Unsolved
    2
    0 Votes
    2 Posts
    660 Views
    Jeremy SchmidtJ
    @Todd-Humphreys Hi Todd, I believe they are replacing them with almost identical motors but with a slightly higher KV value. If you can source those then they would be a drop in replacement. If you're interested in something else, then here's some that I've tested before. The only thing is you'd need to solder the 3 male 2mm bullet connectors onto each motor. Otherwise they're drop in replacements. https://usa.banggood.com/Racerstar-Racing-Edition-2216-BR2216-810KV-2-4S-Brushless-Motor-For-350-380-400-450-RC-Drone-FPV-Racing-p-1083206.html?utm_source=googleshopping&utm_medium=cpc_organic&gmcCountry=US&utm_content=minha&utm_campaign=minha-usg-pc&currency=USD&cur_warehouse=CN&createTmp=1&ID=521309&utm_source=googleshopping&utm_medium=cpc_bgcs&utm_content=sandra&utm_campaign=sandra-SSC-usg-sku-1019-xp-cvrcart-11sale-21&ad_id=554267045258&gclid=CjwKCAiAjoeRBhAJEiwAYY3nDF7t6brTndAN6m0qocX3YTDihgCK1dw6y2-u2YtW9OWuC_Xq_bipZxoCnv8QAvD_BwE
  • USB Carrier Board with pddl900

    Unsolved
    4
    0 Votes
    4 Posts
    487 Views
    A
    @Chad-Sweet I can confirm that we can communicate with the pddl900 inserted into the ModalAI USB Carrier board...thanks!
  • Reject Auto Mission

    Unsolved
    4
    0 Votes
    4 Posts
    532 Views
    ?
    @Nathan-Sullivan Awesome, great to hear! Yeah, that's a sneaky one that's gotten me a few times Thanks, Rich
  • GPS Denied Environment with VIO

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    K
    @Chad-Sweet Thanks for your reply. I am currently running firmware FCv1 - v1.11.3-0.2.3 from that link. I downloaded the image and then uploaded it through QGC as a custom firmware. Thanks, Karl
  • VOXL VIO frame rate change

    Unsolved
    8
    1
    0 Votes
    8 Posts
    1k Views
    yu zhangY
    @Alex-Gardner all right, thanks for that
  • voxl-cross installation document missing

    Unsolved
    2
    1
    0 Votes
    2 Posts
    600 Views
    ?
    voxl-cross 1.7 is a build containing some new gcc toolchains for projects that are not yet on stable. The cross image is meant to be able to be easily built by any user, hence why it was built and installed when you installed the docker image. We've just pushed that image to the downloads page should you need to download it from there. As for the docker image docs, you are correct they are out of date right now, we're planning to update them soon and have been delaying doing so because we've been making changes to them.
  • How to make system backup

    Unsolved
    2
    0 Votes
    2 Posts
    596 Views
    ?
    If you've made specific changes to specific config file you'll need to back them up manually either to a host pc or the data partition, otherwise the data partition will be saved which contains the camera calibration files and the factory settings for the config files which can be restored on a new system with voxl-configure-mpa --factory-reset