Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • m500 for enabling gimbal

    Unsolved
    7
    2
    0 Votes
    7 Posts
    1k Views
    yu zhangY
    @modaltb All right, I see. It does sound tough. Instead, I think I may have a chance to only enable the stabilization by manually pre-set a fixed angle for the gimbal. If so, I don't need to connect to VOXL-flight, and I could just need to think about a separate power supply for the gimbal, right?
  • Reading data from J13 - Expansion B2B connection on m500

    Unsolved
    3
    1
    0 Votes
    3 Posts
    668 Views
    yu zhangY
    @Chad-Sweet Thanks, I see. I had the debug board, but it may not be able to work for special expansion. Anyways, I will think about that.
  • Spektrum receiver not connecting

    Unsolved
    2
    0 Votes
    2 Posts
    816 Views
    J
    @Jimk_Aero Please ignore the previous question. I just needed to reboot the Flight Core and all is OK.
  • work without gps?

    Unsolved
    2
    0 Votes
    2 Posts
    410 Views
    Chad SweetC
    ModalAI does not produce fixed wing aircraft, but it is possible to use our technology for fixed wing aircraft. We do not have any documentation or direct references as of now though.
  • Making a custom mount for voxl flight deck

    Unsolved
    3
    0 Votes
    3 Posts
    708 Views
    M
    Hi @Chad-Sweet Thank you so much! Will have try it out first on the flight deck. Thanks & Regards, Mohammed Naveed
  • Trying to make my own custom tflite model for voxl-tflite-server

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    Steve AriasS
    @Matt-Turi I wanted to try the resnet architecture as the accuracy/speed ratio is a bit better than the mobilenet architecture. But it's not a hard requirement, so I'll just use the mobilenet architectures. Thanks!
  • Recommend SDcard

    Unsolved
    1
    0 Votes
    1 Posts
    469 Views
    No one has replied
  • QGC obstacle display bug?

    Unsolved
    5
    1
    0 Votes
    5 Posts
    925 Views
    H
    @Chad-Sweet said in QGC obstacle display bug?: Hi, we have not actually used QGC to debug collision prevention ourselves. The tools we use to debug collision prevention can be found on our docs here If you find anything related to QGC integration, a follow-up would be appreciated! Thanks. Will probably report this to the QGC dev team as an issue
  • VOXL m500 Technical Documents

    Unsolved
    2
    0 Votes
    2 Posts
    382 Views
    Chad SweetC
    For GPS flight, the m500 performance is similar to most PX4 GPS Flight. The performance is subject to standard GPS position accuracy, which is generally ~1.0 to 1.5m accurate. For VIO flight, in a reasonably environment the typical accuracy is 1.0 to 1.5% drift over distance traveled.
  • VOXL connection to QGC failed in virtual Ubuntu

    Unsolved
    2
    0 Votes
    2 Posts
    509 Views
    No one has replied
  • m500 using extended RB5 landing gear

    Unsolved
    4
    2
    0 Votes
    4 Posts
    818 Views
    yu zhangY
    @modalab , I would try to add a gimbal with a camera or other sensors attached on the m500. So, simply extending the brittle tubing on the landing gear legs is quite unsafe for a gimbal set. I think the extended landing gear on RB5 is the best option for the gimbal purpose. So, will you make the extended landing gear available in the upcoming release? If so, it would be much better to add an installation video for both RB5 and m500.
  • pddl1800

    Unsolved
    2
    0 Votes
    2 Posts
    387 Views
    Chad SweetC
    The pDDL1800 is used for US DOD integrations and is not authorized for use without understanding proper regulations. Generally, if you are not integrating with a US DOD platform, you should not use pDDL1800. We can refund if this was purchased in error.
  • ArduPilot (I want to force the issue :) )

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    modaltbM
    Hi @mohammednaveed , With no warranty claimed, it should work, although integration with VOXL via voxl-vision-px4 hasn't been validated by us yet at all, so consider it 'stand alone'. We have not used Ardupilot over here yet so there's no support at all from us at this time unfortunately. That said, kudos to the guys over there helped out and did the port! https://github.com/ArduPilot/ardupilot/tree/master/libraries/AP_HAL_ChibiOS/hwdef/modalai_fc-v1
  • Working with Yocto

    Unsolved
    3
    0 Votes
    3 Posts
    687 Views
    omer bO
    Well, that's unfortunate. Thank you.
  • m500 estimated flying paths

    Unsolved
    5
    2
    0 Votes
    5 Posts
    939 Views
    yu zhangY
    @Eric-Katzfey Thanks, I am looking for this one
  • 0 Votes
    4 Posts
    932 Views
    modaltbM
    @relevinsky said in voxl flight connects to LTE,receives static IP and didn't connects to QC (my PC) with static IP as well: commercial LTE modem with static IP as well Oops, Tom pointed out commercial LTE modem with static IP as well, never mind!
  • Drone Flipped

    Unsolved
    1
    1
    0 Votes
    1 Posts
    463 Views
    No one has replied
  • voxl-configure-qvio creates a broken /etc/modalai/voxl-qvio-server.conf

    Unsolved
    3
    0 Votes
    3 Posts
    832 Views
    ?
    Can you post the contents of the file that's broken? (/etc/modalai/voxl-qvio-server.conf). Running voxl-configure-qvio and wiping the config file should generate a valid file for qvio to read. Additionally, can you post the output of voxl-versionto show the version of your software packages.
  • Having trouble taking off

    Unsolved
    3
    0 Votes
    3 Posts
    884 Views
    G
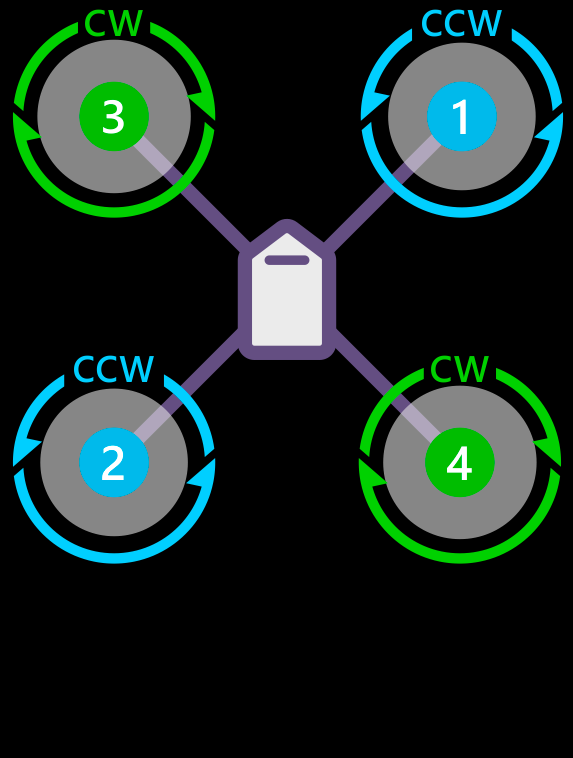
    @modaltb Sorry for the very late reply but have been quite busy. Yeah we have been running the VOXL Flight Deck and we made sure that all required services are running. Yesterday we did a test flight again and we were able to get the correct x,y,z data and I set the drone to fly in position mode. Upon trying to takeoff the drone quickly flipped over and destroyed two of the propellers. (Before when I posted the original message the drone wouldn't takeoff at all and just spin the motors but now it actually tried to takeoff) I believe I know what the problem is but I want to confirm with you. I changed the motor spin direction and propellers to make sure they align with the image you posted and with the M500 documentation. After the crash I realized that in QGroundcontrol that when using the motor testing function it didn't align with the picture. For example spinning up motor 2 using QGroundControl would actually spin the physical motor 3 labelled on the diagram. Spinning motor 3 on QGroundControl would then spin the physical motor 2 labelled on the diagram. So on the drone physically all 4 motors are technically spinning in the correct direction. The problem is the mapping from physical drone to PX4/QGroundControl since they are mapped in different positions. Would you be so kind as to confirm that when you go into QGroundControl and test the motors that when you throttle up motor 2 the back left motor spins and that the motor positions labels 1,2,3,4 on QGroundControl correspond to the diagram you posted. If this is true can the change be done in software or do I need to take apart the drone and change the ESC servo wire positions on the breakout board.
  • TOF Obstacle Avoidance

    Unsolved
    9
    1 Votes
    9 Posts
    2k Views
    wilkinsafW
    @ptaylor1234 Not sure if you ever found the information, but PX4 avoidance information is listed here: https://docs.px4.io/v1.9.0/en/computer_vision/obstacle_avoidance.html