Skip to content
  • Getting the ulogs

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    13
    0 Votes
    13 Posts
    2k Views
    tomT
    @Noe-Medrano scp is a basic linux utility so you should be able to find solid documentation on it's usage, but you can do the following to download a single file: scp root@VOXL2_IP:/data/px4/log/FILE_NAME HOST_PC_DIRECTORY
  • 0 Votes
    10 Posts
    1k Views
    VinnyV
    Hi @Aks, That makes architectural sense to try out! Let us know how it works!
  • Noisy output from TOF sensor

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    662 Views
    A
    I am facing the same issue. How can I account for this noise? Are there any parameters to tune to filter the sensor output on the voxl2 side? @Anubhav did you solve this issue?
  • Buffering in UART return

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    0 Votes
    4 Posts
    601 Views
    Alex KushleyevA
    Hello @MartinP , I believe here is what is happening in your case: Your sensor (Lidar) is sending data continuously without any breaks (360 degree lidar?). Maybe the Lidar processes each measurement and sends it out right away, so perhaps there are small breaks between the data measurements The hardware UART buffer size in VOXL2 is set to 2048 (based on the data chunk size you get) You are using the High Speed uart port (HS in the ttyHS1), which uses DMA to transfer data to cpu (one cpu interrupt per buffer) Typically, the DMA-based UART hardware decides when to send the data to CPU when one of several conditions is met: there is a long enough break in the data stream that can be considered end of "packet" or the current data buffer is full (2048 in this case) Since it looks like the data from Lidar is coming without long breaks, I see several possible solutions: If possible, configure the Lidar to have a break between each scan (but you would need to know the minimum break size for UART hardware to trigger a rx interrupt to CPU) reduce the rx buffer size for UART (probably somewhere in the Device Tree) However, it would be helpful to understand what the data transmission from Lidar looks like. Also, please note that increasing the baud rate of the communication will probably not help. Significantly increasing the baud rate may result in potentially rx interrupt triggering on each measurement, which would not be very good for the CPU.
  • Opencl cannot find devices

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    5
    0 Votes
    5 Posts
    1k Views
    D
    I tried adding the .so file to the hellocl example, and got the following error: /usr/lib/gcc-cross/aarch64-linux-gnu/7/../../../../aarch64-linux-gnu/bin/ld: warning: libcutils.so.0, needed by /usr/lib/../lib/libOpenCL.so, not found (try using -rpath or -rpath-link) /usr/lib/../lib/libOpenCL.so: undefined reference to `property_get' and when adding it to our OpenCV application, OpenCV still cannot find any OpenCL devices. I suspect OpenCV needs to be recompiled with the .so file in the docker image. This issue is not immediately pressing, so if you intend to update the voxl-cross image I can wait for that instead of trying to create a fix.
  • Mavlink-Server Verification

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    6
    0 Votes
    6 Posts
    1k Views
    Raza RizviR
    @McMason Can you please guide me on how to solve this issue? I am having a similar problem with the Sentinel drone, when I run the voxl-mavlink-server -r command, there is no main loop being triggered. Hence, I am also unable to see the drone connected to the QGround controller.
  • Temporary failure resolving

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    2
    0 Votes
    2 Posts
    314 Views
    wilkinsafW
    I resolved this by doing 1 of 2 things Powercycle Add nameserver 8.8.8.8 to /etc/resolv.conf These are only temporary fixes, but get the job done so I can keep developing
  • gst-interpipe not getting installed

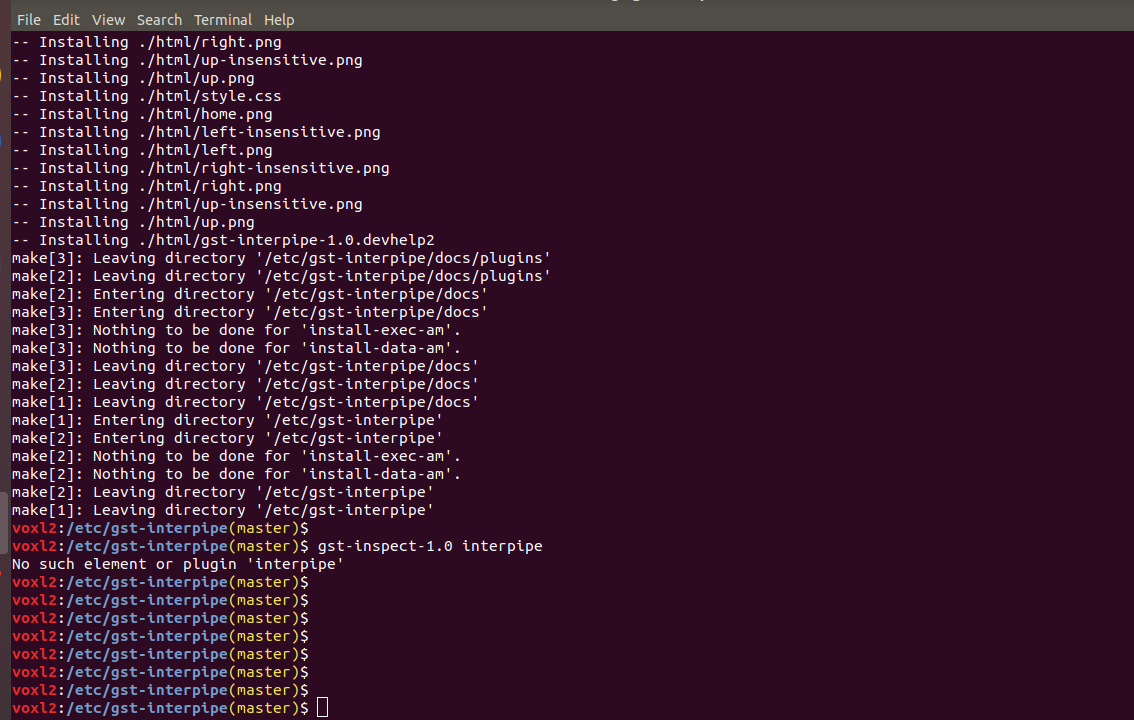
    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    2
    0 Votes
    3 Posts
    627 Views
    Vaibhav UsapkarV
    Thanks for the response. It worked !!
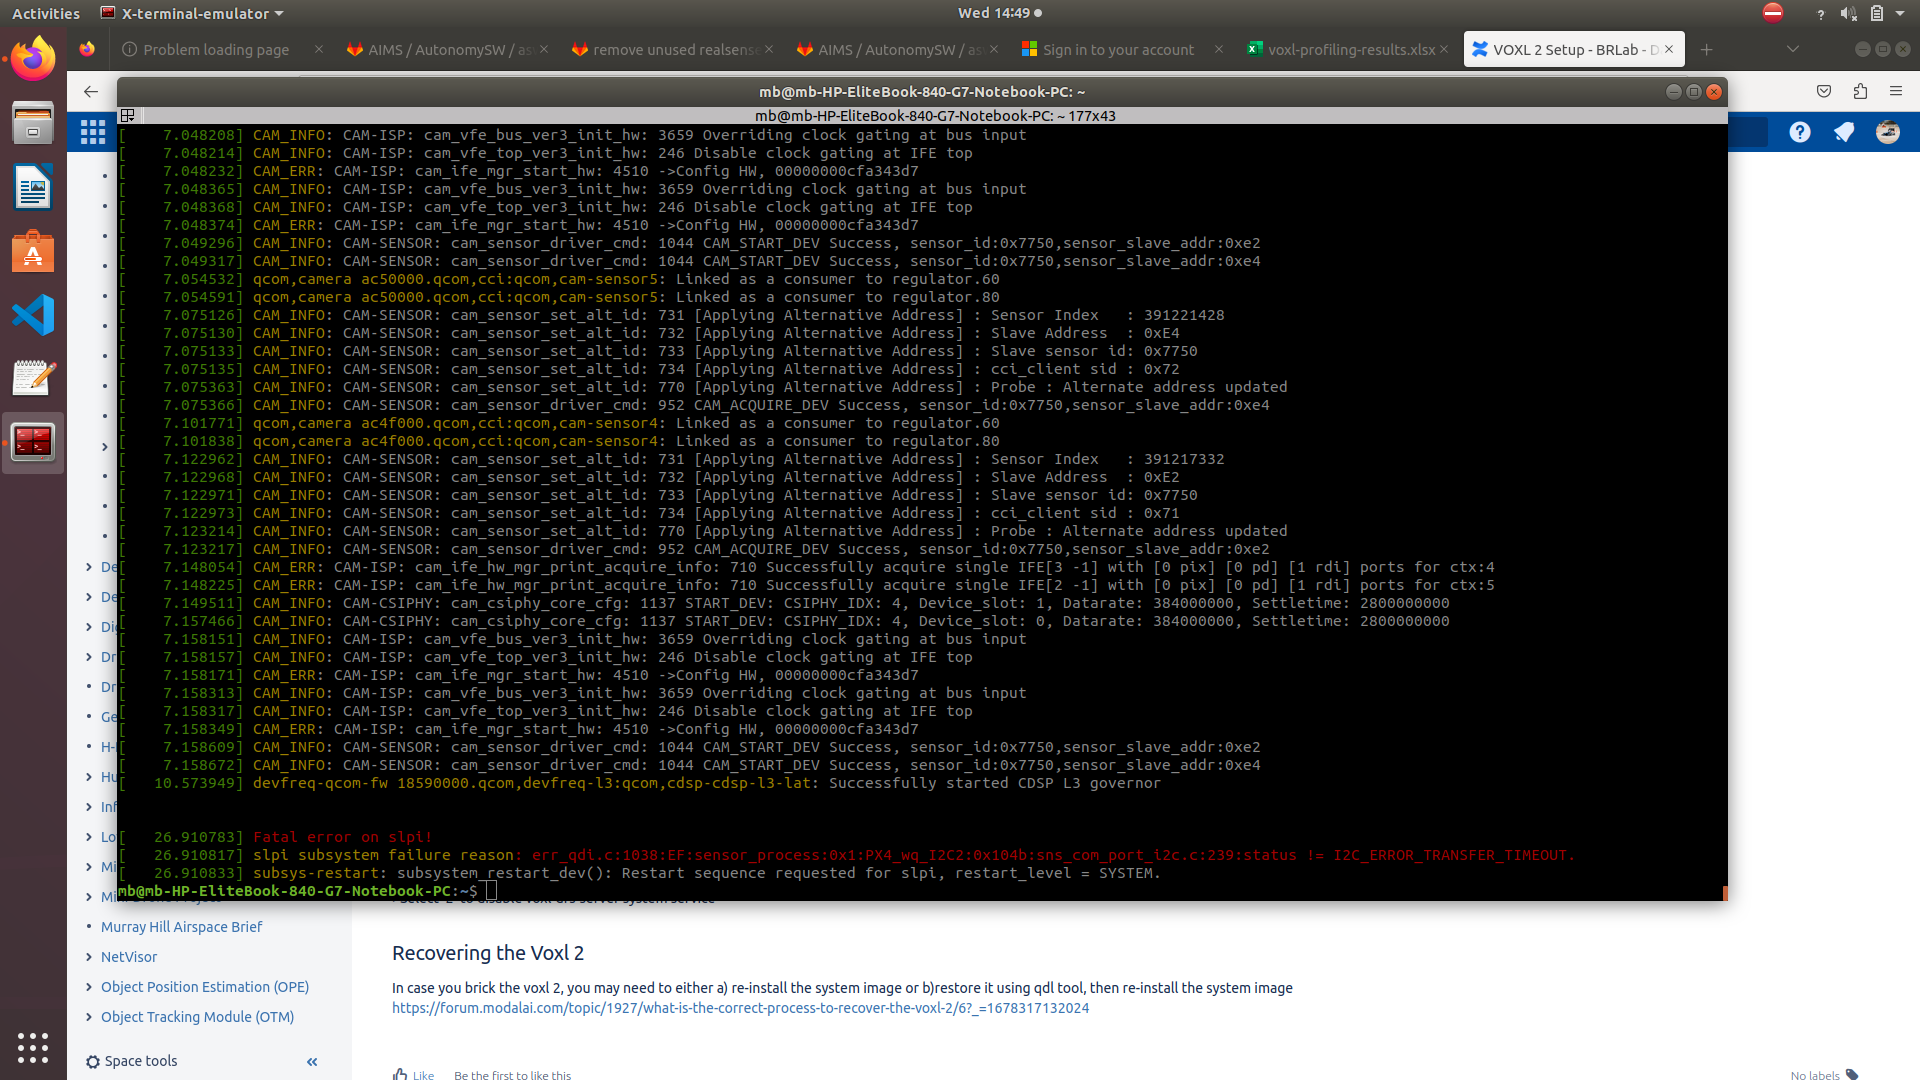
  • Fatal SLPI error causing system restart on Voxl 2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    10
    1
    0 Votes
    10 Posts
    2k Views
    tomT
    @m1baldwin With that platform release PX4 crashing causes ADB to crash as well, so that's one possibility. (This is fixed in future releases) If it was a camera issue, that would be low level device tree code causing the crash
  • VOXL 2 Spektrum RC Issue

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    868 Views
    Taylor PresleyT
    @Eric-Katzfey I've been stuck on travel for the past month but happy to report that your solution worked! input_rc is publishing and I was able to calibrate in QGC.
  • FastCV example for Voxl2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    0 Votes
    4 Posts
    710 Views
    Chad SweetC
    Outstanding!
  • PX4 1.14 update

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    6
    0 Votes
    6 Posts
    1k Views
    Eric KatzfeyE
    @mzahana VIO will definitely be supported. I don't think we are currently using the dds client in any of our applications but there's no reason why it wouldn't work on our platform.
  • voxl2 not coming out of fastboot

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    2
    0 Votes
    2 Posts
    629 Views
    ?
    @Chad-Sweet We would be doing RMA for this VOXL2 chip since it is not in recoverable stage from our tests.
  • What is the correct process to recover the voxl 2?

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    8
    0 Votes
    8 Posts
    2k Views
    tomT
    @Dmytro-Stolbovyi Here is the updated link: https://docs.modalai.com/voxl2-unbricking/
  • 0 Votes
    3 Posts
    714 Views
    M
    Thanks! this is helpful confirmation
  • 0 Votes
    6 Posts
    1k Views
    A
    Hi @modaltb, We were making a mistake of connecting the mavros with the UART which is being used by mavlink server, hence creating the traffic in communication. Now we are connecting mavros with VVPX4 and it's working fine. Thanks.
  • VOXL2 QVIO recover during flight after failure

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    739 Views
    Tamas Pal 0T
    A small observation from my side. While we are flying the quad indoors with compass disabled and using a external optical sensors (in both cases) the qvio recovers itself even after force restarting it using terminal, but the same does not recovers itself outside. For both the cases the exposure and gain of tracking cam was in auto. Can you tell us what might be the issue
  • Changing VOXL2 DSP PX4 Orientation

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    11
    0 Votes
    11 Posts
    2k Views
    Eric KatzfeyE
    @Abdullah01 Leave SENS_BOARD_ROT as the default value. You are specifying the rotation of the board by giving the IMU driver the -R 4 option.
  • Connecting voxl2io UART port to voxl ESC V2?

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    0 Votes
    4 Posts
    577 Views
    modaltbM
    Hi @Aks , Out of the box no, but if you are recompiling SW yourself than it's likely doable, but we have not tested this. voxl-px4 utilizes the DSP for it's IO on VOXL2, do the UARTs aren't exposed to Ubuntu like a normal UART (/dev/ttyHX). Instead it's a little deep in voxl-px4 at this time. The current production release is a 1.12 based branch, called voxl-dev-1.12. For example, the QUP2 port is defined here for the ESC: https://github.com/modalai/px4-firmware/blob/voxl-dev-1.12/src/drivers/uart_esc/modalai_esc/modalai_esc.cpp#L42 And QUP7 is defined to be used by px4io here: https://github.com/modalai/px4-firmware/blob/voxl-dev-1.12/platforms/qurt/src/px4/generic/generic/px4io_serial/px4io_serial.cpp#L67 For reference, I used my own graphic to remember the QUP indicies, here: https://docs.modalai.com/voxl-px4-developer-guide/ specifically: https://docs.modalai.com/images/voxl2/m0054-px4-block-diagram-0.4.png Although we haven't tried this, you may be able to recompile with updates here to the QUP index and get things going that way.