Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Need helps on RC setup for Sentinel/VOXL2

    Unsolved sentinel
    5
    0 Votes
    5 Posts
    804 Views
    Eric KatzfeyE
    @Neil-Huang Yes, if TBS side doesn't use 250000 then that line would need to be changed.
  • Drone does not switch to Position mode indoors

    Unsolved seeker
    10
    0 Votes
    10 Posts
    2k Views
    Umut JohnU
    OMG! The protective cap on the camera You're right! Just saw it minutes before checking it here. There was no cap on the first drone; it was probably dropped or something, so I did not even feel the need to look for it. Thank you, Adrian; sorry for the trouble. Case closed!
  • How to put custom tflite model and visualize results in voxl-portal in voxl m500

    Unsolved m500
    2
    0 Votes
    2 Posts
    489 Views
    Chad SweetC
    We don't have a guide on our own, but Google should have plenty of guides and examples You'll need to add your own post processing function in this area of the code Here is Google's guide on how to postprocess tflite data https://www.tensorflow.org/lite/inference_with_metadata/lite_support
  • Additional camera and USB interface

    Unsolved sentinel
    8
    0 Votes
    8 Posts
    2k Views
    A
    @Chad-Sweet Ok, thank you for clarifying!
  • External Sensors and Cameras -

    Unsolved sentinel
    4
    0 Votes
    4 Posts
    874 Views
    Chad SweetC
    The VOXL 2 Connector Specification is here: https://docs.modalai.com/voxl2-connectors/
  • Quectel Modem issues

    Unsolved sentinel
    10
    0 Votes
    10 Posts
    3k Views
    tomT
    @JustinDev23 Definitely. See here: https://www.modalai.com/pages/rma
  • Sentinel power range

    Unsolved sentinel
    5
    0 Votes
    5 Posts
    1k Views
    Adrian HidalgoA
    @martygp95, Yes, powering the Sentinel with a 4S is fine. Just be sure NOT TO FLY with it. The tuning for the drone was done around the 3S and if you attempt to fly with the 4S, then there could be detrimental flight-performance. The APM on the Sentinel can handle 2S-6S [2 cell (6.4V min, 7.4V nom, 8.4V max) 6 cell ( 19.2V min, 22.2V nom, 25.2V max)]. You can find info about the APM here Hope that helps
  • Integration of range finding sensor with m500

    Unsolved m500
    1
    0 Votes
    1 Posts
    545 Views
    No one has replied
  • Sentinel take off in a sloping position

    Unsolved sentinel
    3
    1
    0 Votes
    3 Posts
    950 Views
    Alex KushleyevA
    Hello, Can you please check the vehicle's attitude (roll, pitch, yaw) when it is sitting flat, right before take-off? You can look at PX4 logs or live using GCS. If the IMU is not calibrated properly, and the vehicle thinks that it is tilted, it will try to compensate for it by tilting in opposite direction, so it can appear as if one of the motors is not able to spin faster, when in fact the flight controller could be commanding it to spin slowly. This is just one reason why this could be happening, so it is worth checking.
  • Many problems related to the cameras

    Unsolved seeker
    6
    0 Votes
    6 Posts
    2k Views
    D
    The tracking camera calibration worked flawlessly after using the seeker in softAP mode, disabling the dfs-server and using the correct checkboard. Stereo camera calibration was much harder, and after many attempts there was always a failure in the exstrinsics calibration. We configured /etc/modalai/extrinsics.conf following this guide https://docs.modalai.com/configure-extrinsics/ . We tried manual control with Position flight mode and it worked fine. After we tried two simple autonomous flights with mavsdk inside docker, mainly using the set_position_ned() method. http://mavsdk-python-docs.s3-website.eu-central-1.amazonaws.com/plugins/offboard.html#mavsdk.offboard.Offboard.set_position_ned First mission: arm the drone, take off 1m from the ground, move forward 1.8m and then land. This one ended pretty badly, with a drone crash. Mission was not followed at all. The environment was an office sufficiently illuminated, and the Seeker drone started from the position where it was turned on. Second mission (simpler): arm the drone, take off 1m from the ground, land. In this one the drone took off around 2.5m from the ground, and then landed with relatively high speed, hitting the ground. I don't know if it can be an issue but in both tests dfs-server was disabled.
  • Sentinel vs m500

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    730 Views
    Chad SweetC
    The VOXL 2 found on the Sentinel has 4x more computing power than the VOXL 1 found on m500. We do not know anything about UAV Toolbox or how to support it
  • Battery Charger for Sentinel

    sentinel
    2
    0 Votes
    2 Posts
    846 Views
    ModeratorM
    Any Hobby LiPo charger should work fine. The following supports 1S to 6S and from the picture it looks to come with an XT60 connector as well https://www.amazon.com/Charger-Battery-Balance-Discharger-Adapter/dp/B07R18YNZQ/
  • M500 ToF Sensor Integration

    Unsolved m500
    1
    0 Votes
    1 Posts
    631 Views
    No one has replied
  • QGroundControl Autoconnect when on same network with VOXL SDK

    Unsolved rb5
    4
    0 Votes
    4 Posts
    1k Views
    Eric KatzfeyE
    @Sam-Kiley When on public 3G / 4G / 5G networks we use a VPN and assign fixed addresses to each system component with our VPN configuration. You should be able to do a similar thing with your 5G private network. Does your private network have a connection to the Internet or is it self contained? I don't know anything about 5G private networks but I'd be surprised if it didn't have a way to assign the same IP address to a device on the network so that you effectively have a static IP. Earlier versions of the RB5 SDK set the MAV_BROADCAST parameter in PX4 to 1 and PX4 would then use the network broadcast address to send out it's initial messages. Any QGC instance running on the network will receive that broadcast and respond so that you get automatic connection. However, this can be problematic if there are more than one instance of QGC running since you may connect to an instance that you don't want. Also, some wireless networks do not support broadcast.
  • TX16S Binding Problems

    Unsolved sentinel
    4
    0 Votes
    4 Posts
    6k Views
    madswampM
    Fixed the problem already, had to disable channel mapping in the configurations of the protocol in the controller. Thank you.
  • Avionics power

    Unsolved seeker
    2
    0 Votes
    2 Posts
    1k Views
    VinnyV
    @g-ferrando You can safely ignore that message. PX4 doesn't have any filters on the power rail of the ADC so it flags any bit of noise on the 5V power rail. We've taken steps to improve that on FCv2. On both FCv1, and FCv2, our hardware can operate much lower than that default PX4 warning. If you use our power module and get reports that way of system voltage and current using the I2C bus, you can trust those numbers. Hope that helps.
  • Hires camera rotation

    Unsolved seeker
    2
    2
    0 Votes
    2 Posts
    1k Views
    Alex KushleyevA
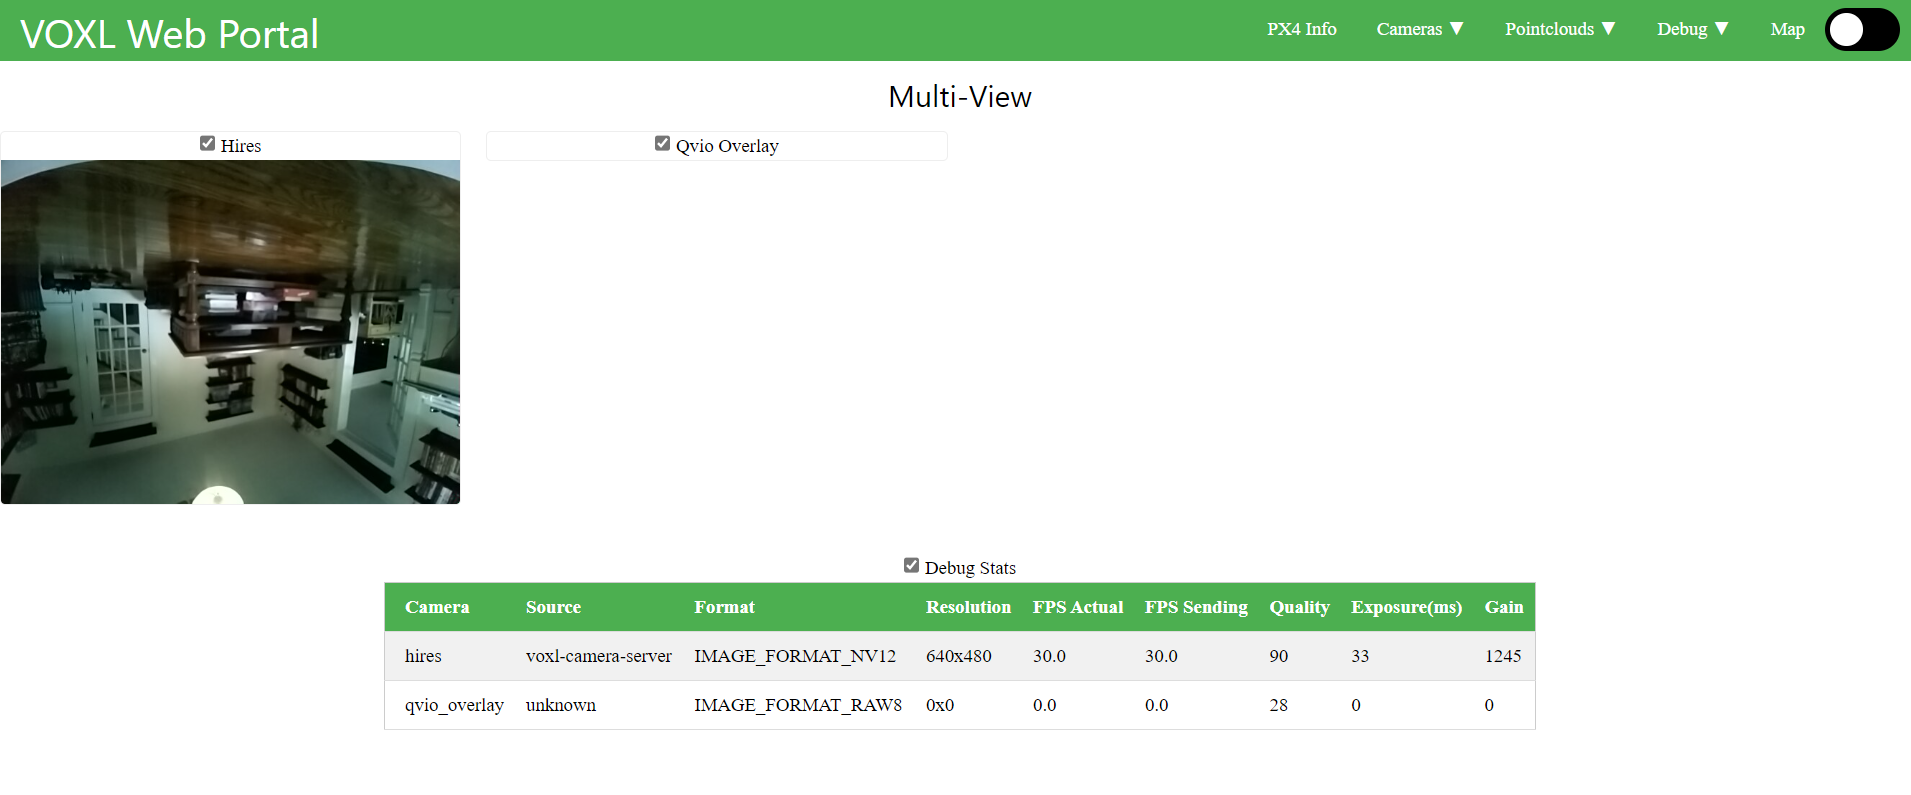
    Hello @JustinDev23 , Rotating Hires camera is not an option in the configuration menu, however you can still do this pretty easily. When you run voxl-configure-cameras, based on your use case, the script writes an appropriate configuration file to /system/etc/camera/camera_config.xml. In that file, you will see entries for all the cameras expected for the particular use case. Since you have already enabled the hires camera (IMX214), you already have an entry for it in camera_config.xml, so if you find it, you should see something like this <SensorName>imx214_rot180</SensorName> . What this does it tells the camera framework to load a dynamic library /usr/lib/libmmcamera_imx214_rot180.so - our default is the rotated version. To remove the rotation, you simply change the entry to <SensorName>imx214</SensorName>, which will in turn use /usr/lib/libmmcamera_imx214.so library after you reboot and the image should be right side up. Please remember that running voxl-configure-cameras again will overwrite the camera_config.xml that you may edit. Hope this helps! Alex
  • VOXL 1 PX4 firmware question

    Unsolved m500
    4
    0 Votes
    4 Posts
    535 Views
    Chad SweetC
    flight Core v1 is what is found on VOXL Flight
  • Am I missing prop washers

    Unsolved sentinel
    4
    0 Votes
    4 Posts
    2k Views
    Adrian HidalgoA
    @A-Evans You're welcome, glad I could be of assistance. You do have to tighten the nuts well, but not white knuckle tight. You will feel it tighten and then give it an extra little after that. We have been trying to source any of the nuts but they are all out-of-stock. You can check any hobby store or Amazon. If you're trying to get the lock nuts, look for the aluminium ones. There's a lot of steel ones available. You're looking for M6's
  • Running MAVSDK directly on M500 and Python update

    Unsolved m500
    7
    0 Votes
    7 Posts
    2k Views
    Steve SagerS
    @Chad-Sweet said in Running MAVSDK directly on M500 and Python update: The Docker is 64-bit, so the code that runs inside is usually faster than the code that runs outside of the Docker Oh, that's interesting, thanks for the insight. I'll share with the others, and let you know how it all goes.