Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • m500 using extended RB5 landing gear

    Unsolved
    4
    2
    0 Votes
    4 Posts
    866 Views
    yu zhangY
    @modalab , I would try to add a gimbal with a camera or other sensors attached on the m500. So, simply extending the brittle tubing on the landing gear legs is quite unsafe for a gimbal set. I think the extended landing gear on RB5 is the best option for the gimbal purpose. So, will you make the extended landing gear available in the upcoming release? If so, it would be much better to add an installation video for both RB5 and m500.
  • pddl1800

    Unsolved
    2
    0 Votes
    2 Posts
    418 Views
    Chad SweetC
    The pDDL1800 is used for US DOD integrations and is not authorized for use without understanding proper regulations. Generally, if you are not integrating with a US DOD platform, you should not use pDDL1800. We can refund if this was purchased in error.
  • ArduPilot (I want to force the issue :) )

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    modaltbM
    Hi @mohammednaveed , With no warranty claimed, it should work, although integration with VOXL via voxl-vision-px4 hasn't been validated by us yet at all, so consider it 'stand alone'. We have not used Ardupilot over here yet so there's no support at all from us at this time unfortunately. That said, kudos to the guys over there helped out and did the port! https://github.com/ArduPilot/ardupilot/tree/master/libraries/AP_HAL_ChibiOS/hwdef/modalai_fc-v1
  • Working with Yocto

    Unsolved
    3
    0 Votes
    3 Posts
    727 Views
    omer bO
    Well, that's unfortunate. Thank you.
  • m500 estimated flying paths

    Unsolved
    5
    2
    0 Votes
    5 Posts
    1k Views
    yu zhangY
    @Eric-Katzfey Thanks, I am looking for this one
  • 0 Votes
    4 Posts
    963 Views
    modaltbM
    @relevinsky said in voxl flight connects to LTE,receives static IP and didn't connects to QC (my PC) with static IP as well: commercial LTE modem with static IP as well Oops, Tom pointed out commercial LTE modem with static IP as well, never mind!
  • Drone Flipped

    Unsolved
    1
    1
    0 Votes
    1 Posts
    487 Views
    No one has replied
  • voxl-configure-qvio creates a broken /etc/modalai/voxl-qvio-server.conf

    Unsolved
    3
    0 Votes
    3 Posts
    870 Views
    ?
    Can you post the contents of the file that's broken? (/etc/modalai/voxl-qvio-server.conf). Running voxl-configure-qvio and wiping the config file should generate a valid file for qvio to read. Additionally, can you post the output of voxl-versionto show the version of your software packages.
  • Having trouble taking off

    Unsolved
    3
    0 Votes
    3 Posts
    929 Views
    G
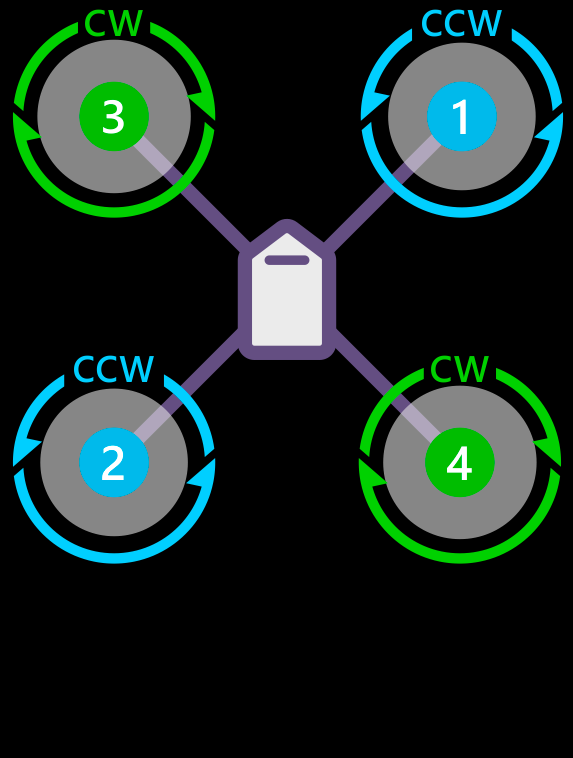
    @modaltb Sorry for the very late reply but have been quite busy. Yeah we have been running the VOXL Flight Deck and we made sure that all required services are running. Yesterday we did a test flight again and we were able to get the correct x,y,z data and I set the drone to fly in position mode. Upon trying to takeoff the drone quickly flipped over and destroyed two of the propellers. (Before when I posted the original message the drone wouldn't takeoff at all and just spin the motors but now it actually tried to takeoff) I believe I know what the problem is but I want to confirm with you. I changed the motor spin direction and propellers to make sure they align with the image you posted and with the M500 documentation. After the crash I realized that in QGroundcontrol that when using the motor testing function it didn't align with the picture. For example spinning up motor 2 using QGroundControl would actually spin the physical motor 3 labelled on the diagram. Spinning motor 3 on QGroundControl would then spin the physical motor 2 labelled on the diagram. So on the drone physically all 4 motors are technically spinning in the correct direction. The problem is the mapping from physical drone to PX4/QGroundControl since they are mapped in different positions. Would you be so kind as to confirm that when you go into QGroundControl and test the motors that when you throttle up motor 2 the back left motor spins and that the motor positions labels 1,2,3,4 on QGroundControl correspond to the diagram you posted. If this is true can the change be done in software or do I need to take apart the drone and change the ESC servo wire positions on the breakout board.
  • TOF Obstacle Avoidance

    Unsolved
    9
    1 Votes
    9 Posts
    2k Views
    wilkinsafW
    @ptaylor1234 Not sure if you ever found the information, but PX4 avoidance information is listed here: https://docs.px4.io/v1.9.0/en/computer_vision/obstacle_avoidance.html
  • Error using Voxl-tflite-server on Firmware 3.1.0

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    Philemon BennerP
    Thank you for your Answer we upgraded the Firmware to the newest Version and now it's working properly.
  • Voxl Pytorch Support

    Unsolved
    5
    0 Votes
    5 Posts
    772 Views
    Philemon BennerP
    Thank you for your Answer yeah i will definitely look into using Tensorflow Lite
  • Is VOXL LTE server or client?

    Unsolved
    4
    0 Votes
    4 Posts
    844 Views
    Eric KatzfeyE
    @relevinsky That is not the way LTE works. You connect to a commercial network. If you need static IPs then you need to contact your service provider and find out how to get them. That is why we use a VPN when using LTE. See https://docs.modalai.com/voxl-vpn/ for more explanation.
  • Voxl M500 Drone Model for JMavSim Simulation?

    Unsolved
    2
    0 Votes
    2 Posts
    460 Views
    Eric KatzfeyE
    @fsherman No, there is not. But out of curiosity, what would you do with such a model?
  • Speed between waypoints in MAVSDK

    Unsolved
    3
    0 Votes
    3 Posts
    1k Views
    tomT
    @jbruell94 http://mavsdk-python-docs.s3-website.eu-central-1.amazonaws.com/plugins/mission.html#mavsdk.mission.MissionItem
  • VOXLFlight LTE modem

    Unsolved
    6
    0 Votes
    6 Posts
    788 Views
    Eric KatzfeyE
    @relevinsky What do you mean by LTE server / client? LTE is a cellular technology that will provide your Voxl flight with Internet access.
  • Unable to calibrate ESCs

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    M
    Please have a look at the Ulogs 3s Flight Ulog 4s Flight Ulog Is there anything else i should a keep an eye for? Thanks & Regards, Mohammed Naveed
  • Overlay of obstacle during collision prevention

    Unsolved
    1
    1
    0 Votes
    1 Posts
    577 Views
    No one has replied
  • m500 without VOXL

    Unsolved
    2
    0 Votes
    2 Posts
    399 Views
    Chad SweetC
    Our VOXL platform is ModalAI's core business, so that is where we focus our support. The m500 uses VOXL Flight. You can find all of the supported connectors to VOXL Flight here. From those connections there are many ways one might connect a secondary platform.
  • voxl-portal build failed on m1 max macbook pro

    Unsolved
    3
    0 Votes
    3 Posts
    790 Views
    yu zhangY
    @Eric-Katzfey Thanks for the information, and I will have a try then