Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • ROS2 topic data not visible on remote computer (VOXL2, SDK 1.1)

    Unsolved
    5
    0 Votes
    5 Posts
    2k Views
    Zachary Lowell 0Z
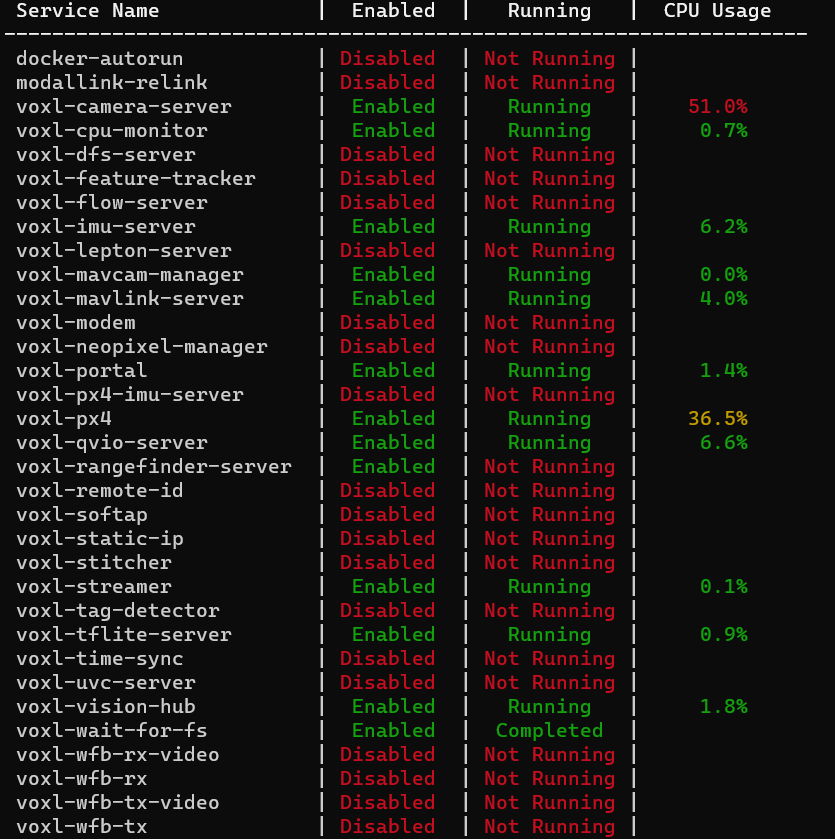
    @Isaac-Stephan-Remy I need you to still explain how you are sending data from the voxl2 to the parent computer - just because they are on the same wifi network doesn't mean that when you launch the ros2 node on the voxl2, and then run a ros2 topic list on your parent computer it will see those topics. There needs to be somewhere on your rpi or parent computer where you are probing the voxl2's ros2 instance whether you have sockets opened up, etc. Can you confirm that the voxl2 instance of ros2 is locally publishing - aka adb shell into another terminal instance of the voxl2 while the voxl-mpa-to-ros2 is actively running and try doing a ros2 echo TOPIC to see if it streams just fine locally - if it isnt, then that is your issue right there. Which topics are you actively trying to listen to as well? Do you have all the required services running? AKA voxl-imu-server, voxl-qvio-server, voxl-camera-server, etc. Can you post a screenshot of voxl-inspect-services Zach
  • Updated M500 with m10 heading issues

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    wilkinsafW
    @tom After 8 hours of grueling coding: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/merge_requests/11
  • ADB no longer working, docker-daemon no longer on the VOXL-2 services page

    Unsolved
    5
    1
    0 Votes
    5 Posts
    984 Views
    Stefan AmundarainS
    @Alex-Kushleyev all is working now. Not sure what has changed but we are all set. Thank you for your help Alex! Stefan
  • 4K Hires Camera crashes camera server

    Unsolved
    21
    2
    0 Votes
    21 Posts
    5k Views
    Alex KushleyevA
    @riteshsharma you are welcome. If the current approach initializes and works fine (is able to allocate all the buffers), the performance should be stable. I am a bit surprised so many buffers are needed for the encoder, there is probably some other settings in our software to change that... However since it is actually working with 11 buffers, maybe there is no need for me to test / fix that. If you do encounter any other issues, let me know..
  • Installing RTK GPS On Sentinel

    Unsolved
    10
    0 Votes
    10 Posts
    2k Views
    S
    @SMRazaRizvi Actually connecting my RTK-GPS to the configuration described here: https://docs.modalai.com/voxl2-guides-onboard-offboard-sensors/#external-gps-mag--gnss was not giving me RTK corrections so I am now using the J9 connector on the 5G modem, and that works fine in giving me GPS Coordinates and receiving RTK Connections. But another problem that I am facing is Compass Sensor 0 missing. Do you think there's some setting of the default compass that PX4 was picking up with the M8N GPS that came with the drone? Where can I configure the compass?
  • Voxl2 Mini i2c

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    Eric KatzfeyE
    @tiralonghipol No, only within px4
  • Probing Intel Realsense LIDAR with voxl-mapper

    Unsolved
    11
    0 Votes
    11 Posts
    3k Views
    wilkinsafW
    @K-Stute I wish, but it is not.
  • Flying multiple RB5s

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    T
    @Moderator I have followed the build instructions and got the voxl-mavlink-server built. I'm currently testing it with different ports (other than 14550). Thank you for your support.
  • Clarification on voxl and PX4 Integration for state estimation

    Unsolved
    3
    1 Votes
    3 Posts
    1k Views
    ModeratorM
    @aashry VIO and EKF2 are separate, concurrent state estimations. You can see where voxl-vision-hub sends the VIO data to PX4's EKF2 here: https://gitlab.com/voxl-public/voxl-sdk/services/voxl-vision-hub/-/blob/master/src/vio_manager.c?ref_type=heads#L395 I'm not sure what mavros uses, but here is the mpa-to-ros code to publish VIO data https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-to-ros/-/blob/master/catkin_ws/src/src/interfaces/vio_interface.cpp?ref_type=heads#L151
  • Streaming Stereo Camera

    Unsolved
    21
    0 Votes
    21 Posts
    6k Views
    ModeratorM
    Typically hires is the only pipe with encoding enabled by default, but in this case tracking is being used. Can you make sure encoding is enabled for the tracking camera in voxl-camera-server.conf ? Or, can you just see if hires_enc is working in QGC first? That's what we ship by default on a fresh install hires_enc to QGC should by enabled by default.
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    1 Views
    No one has replied
  • voxl-vision-px4 not showing up

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Eric KatzfeyE
    @Kris On seeker PX4 runs on flight core, a separate board, not on voxl. So no, you shouldn't see voxl-px4 running on voxl. And voxl-px4-imu-server is a service specific to RB5 platforms so it isn't applicable to seeker.
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    4 Views
    No one has replied
  • Best quality for the Mapping and Planning

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    P
    @Alex-Kushleyev Thank you for the information.
  • Using Intel RealSense D455 over USB-Port on voxl2

    Unsolved
    1
    0 Votes
    1 Posts
    443 Views
    No one has replied
  • VOXL mpa_to_ros1 cmake prefix path

    Unsolved
    3
    0 Votes
    3 Posts
    620 Views
    Darshit DesaiD
    @Moderator I had to explicitly change the system variable CMAKE_PREFIX_PATH every time to /opt/ros/melodic only to build the nodes. Building a new voxl package might break things and I don't want to do that.
  • PCIe Card Porting

    Unsolved
    2
    1
    0 Votes
    2 Posts
    381 Views
    ModeratorM
    @andrea_seock We are not supporting the PCIe interface, it is currently disabled
  • VOXL2 I2C error

    Unsolved
    2
    0 Votes
    2 Posts
    708 Views
    Alex KushleyevA
    @czarsimon , can you please clarify where you have your device plugged in (based on the connector definitions here : https://docs.modalai.com/voxl2-connectors/)
  • voxl-dfs-server: stereo pointcloud coordinate frame

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    James StrawsonJ
    Hi Eric, The stereo camera pair intrinsics and extrinsics are saved to /data/modalai/opencv_stereo_intrinsics.yaml and /data/modalai/opencv_stereo_extrinsics.yaml We then use the following opencv calls to generate the rectification maps for each left and right image cv::Mat R1, P1, R2, P2; cv::Mat map11, map12, map21, map22; cv::Mat Q; // Output 4×4 disparity-to-depth mapping matrix, to be used later double alpha = -1; // default scaling, similar to our "zoom" parameter cv::stereoRectify(M1, D1, M2, D2, img_size, R, T, R1, R2, P1, P2, Q, cv::CALIB_ZERO_DISPARITY, alpha, img_size); // make sure this uses CV_32_FC2 map format so we can read it and convert to our own // MCV undistortion map format, map12 and 22 are empty/unused!! cv::initUndistortRectifyMap(M1, D1, R1, P1, img_size, CV_32FC2, map11, map12); cv::initUndistortRectifyMap(M2, D2, R2, P2, img_size, CV_32FC2, map21, map22); Those maps then get converted into a format that can be used by the Qualcomm hardware acceleration blocks for image dewarping, but the fundamental matrices and undistortion coefficients stay the same. I think the above lines is what you are after. You are correct that the disparity map is centered about the left camera, I believe this is typical in OpenCV land too. Note that we do not do a precise calibration between the Stereo and Hires Cameras from the factory, depending on how precise you need to alignment to be you may need to use a tool like Kalibr to do that.
  • VOXL 2 /data mount error

    Unsolved
    7
    0 Votes
    7 Posts
    2k Views
    tomT
    @czarsimon Interesting, I've never seen it get stuck during flashing like that. Can you try forcing it into fastboot with the button (https://docs.modalai.com/voxl2-voxl2-mini-system-image/#force-voxl-2-into-fastboot) and then using ./install.sh -w