Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Unstablr Baro in Voxl 2 mini

    Unsolved
    14
    0 Votes
    14 Posts
    2k Views
    Alex KushleyevA
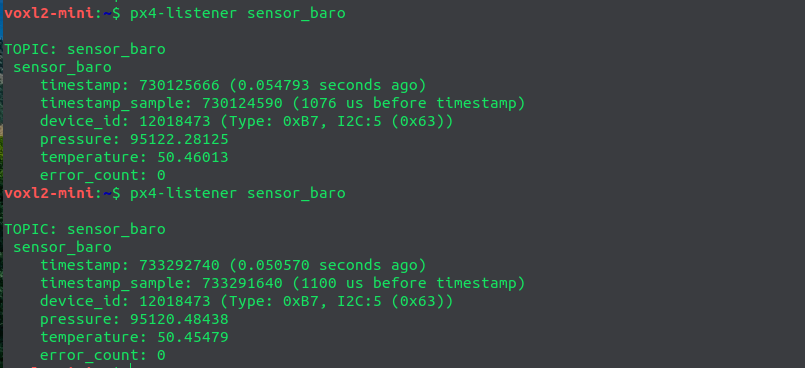
    We have added support of the following barometers to voxl-dev branch of px4-firmware repo and you should be able to pick up the change tomorrow in the latest nightly build: bmp280 bmp388 ms5611 http://voxl-packages.modalai.com/dists/qrb5165/dev/binary-arm64/ (look for voxl-px4 and check build date). the new barometers can be enabled connected to J19 (px4 i2c port 1, so -b 1) and modifying voxl-px4-start script: qshell bmp280 start -X -b 1 qshell bmp388 start -X -b 1 qshell ms5611 start -X -b 1 You should disable the onboard barometer icp101xx, otherwise there may be a conflict where two barometers are publishing under the same instance (at least when viewed with px4-listener). We will investigate this issue. Alex
  • starling 2 RMA

    Unsolved
    4
    0 Votes
    4 Posts
    711 Views
    tomT
    @Viktor-Gal If you've already removed the board then sending in just the board as an RMA is fine
  • Starling 2 VIO - how many cameras used?

    Unsolved
    12
    0 Votes
    12 Posts
    2k Views
    S
    @tom thank you. I've been looking through the code. I'd like to test masking areas of non-interest in my tracking cameras. From the voxl-open-vins-server.conf file and from common.h image_data struct it seems like this feature exists, but I cannot find where I can put the masks, or define where they are. Do you know if this is implemented already? Maybe I'm looking in the wrong place?
  • Doodle labs Nimble radio

    Unsolved
    3
    0 Votes
    3 Posts
    723 Views
    tomT
    @david-moro We have not used that specific radio before, only the nano and mini
  • Starling 2 max information

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    ModeratorM
    The Starling 2 and Starling 2 Max will be supported for the foreseeable future. The Sentinel is less popular, so it is likely to be deprecated in 2025 but is currently marked as "Active Production" on its website Dash speed, or burst speed, is the airframes capability when full throttle is applied for a short period of time. Batteries are typically able to discharge more current when first applied, but not for a sustained period of time.
  • Camera not recognized

    Unsolved
    3
    3
    0 Votes
    3 Posts
    768 Views
    VinnyV
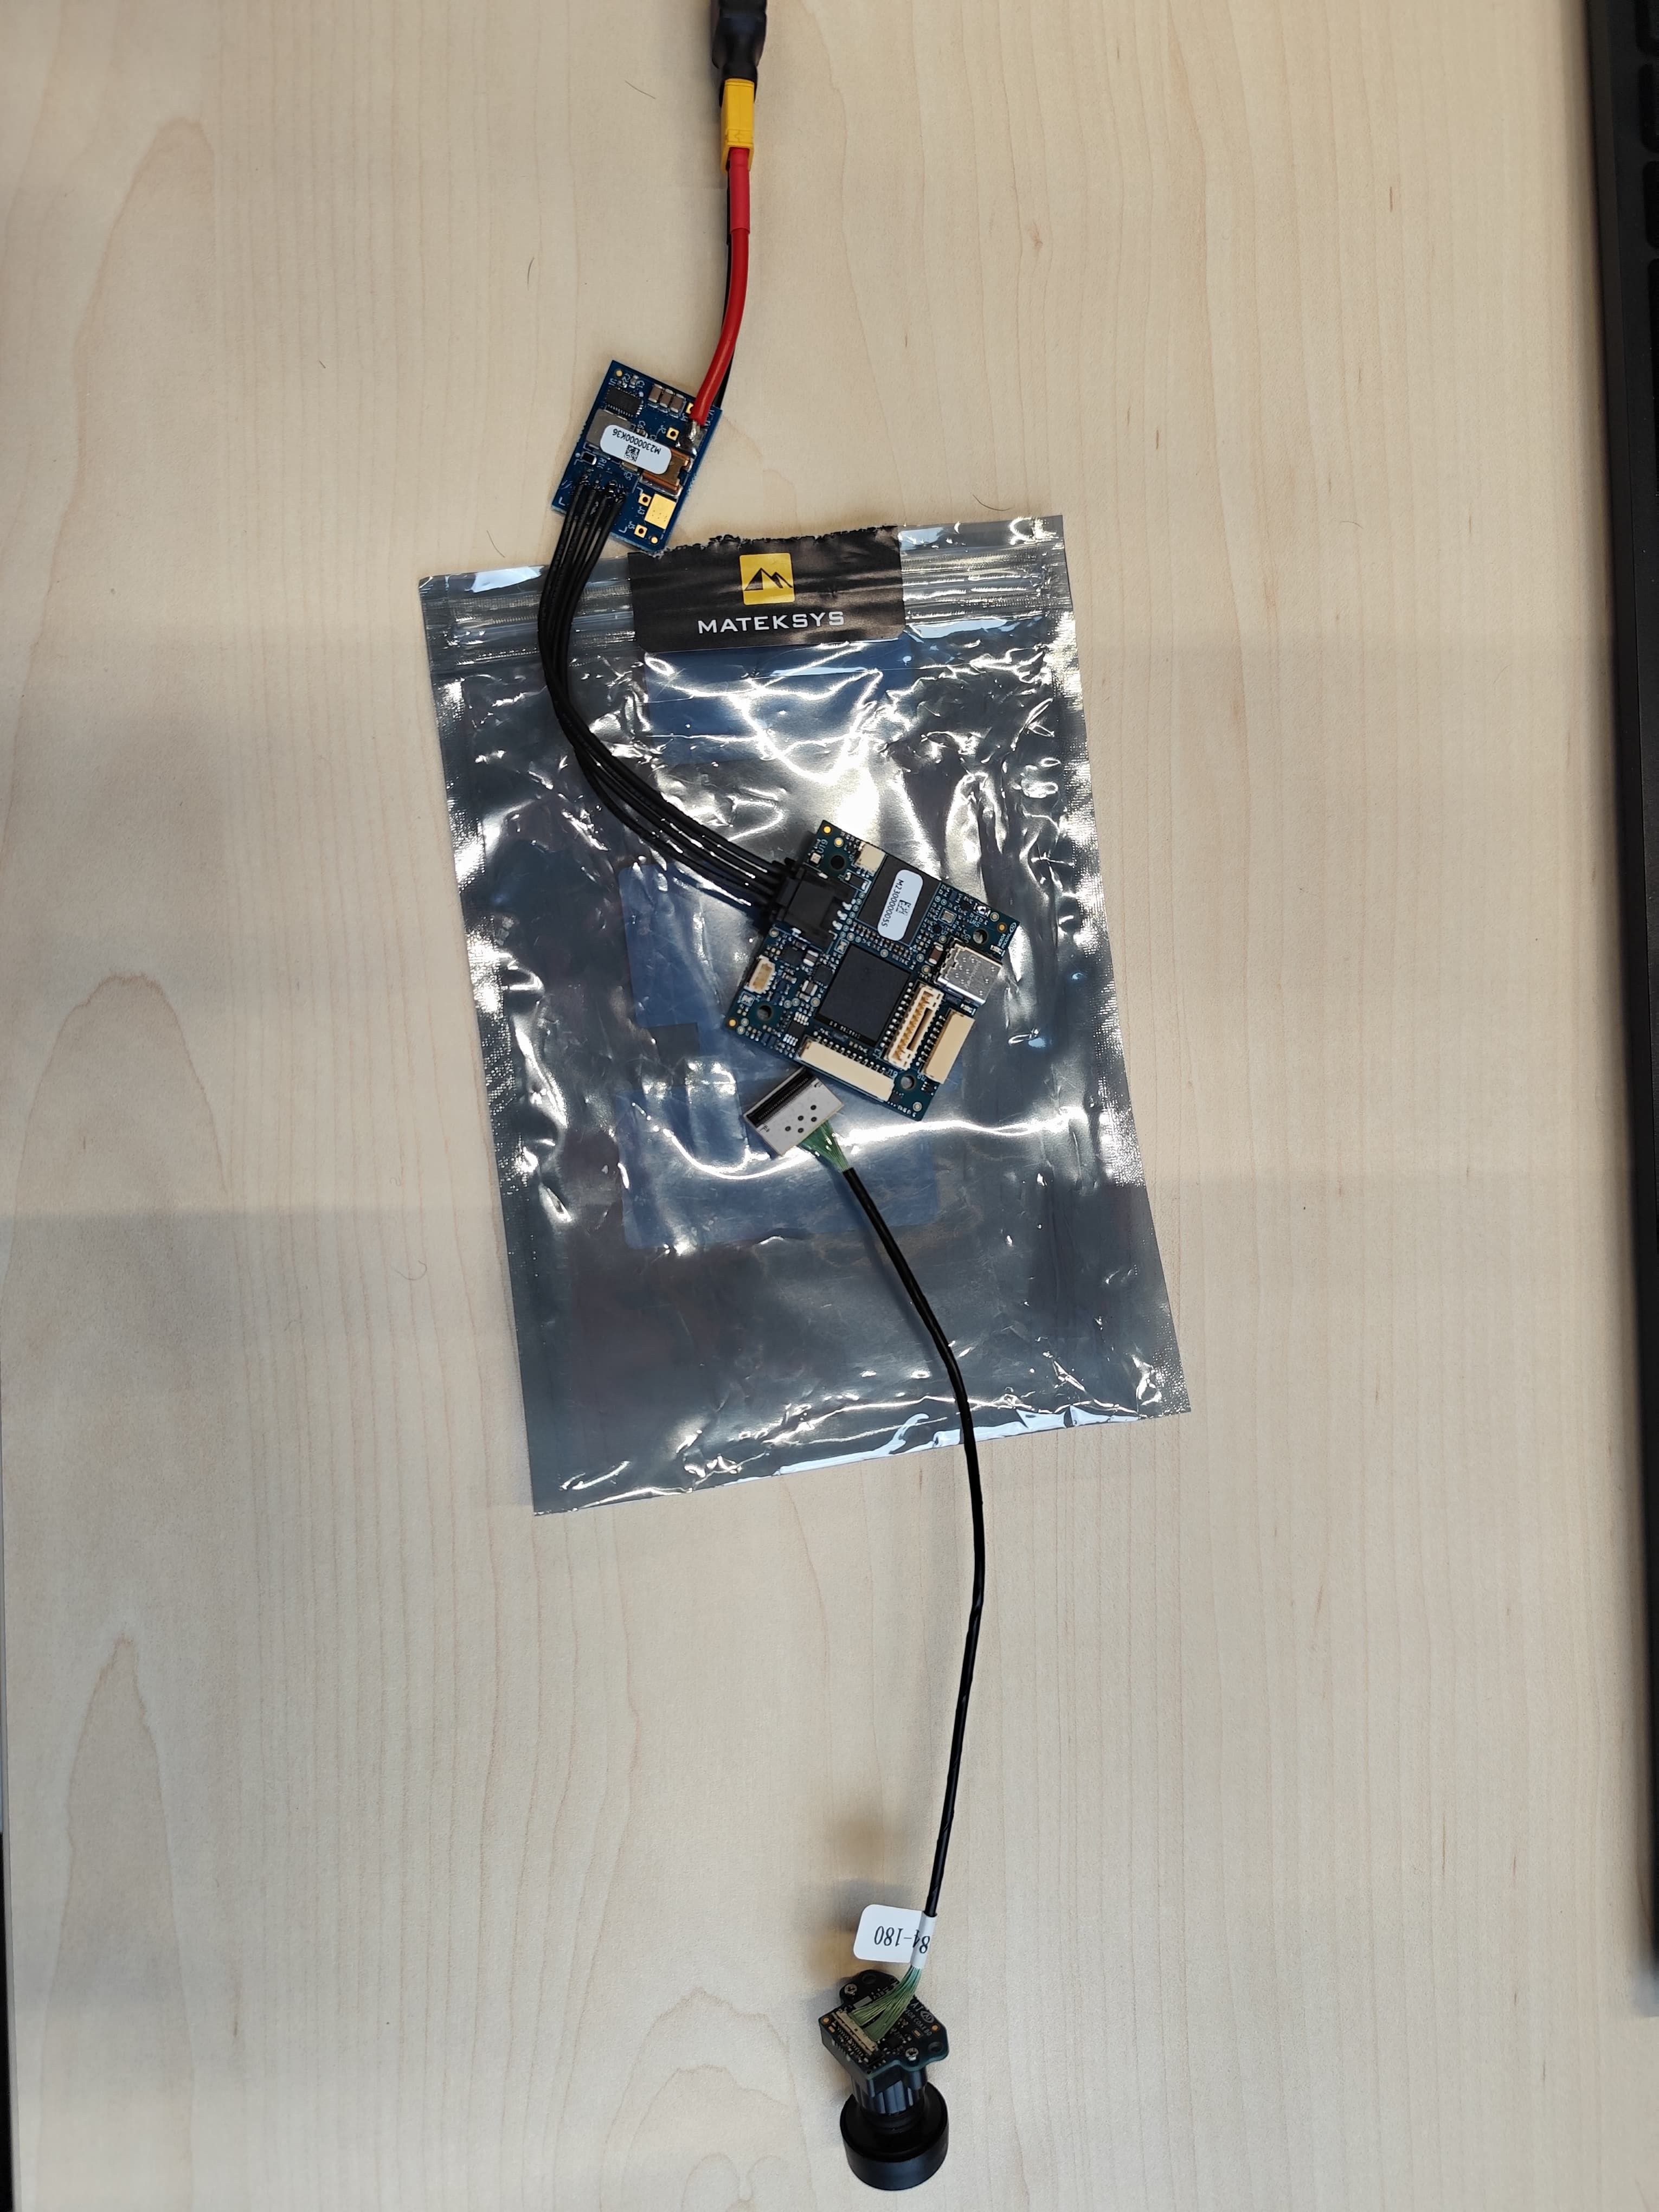
    HI @TomP Please remove all products off of the ESD static bags. This bags are only used for unpowered storage/shipping when outside of a controlled ESD Work Area. This site has a few good books you can try to pick up so your team is well prepared for ESD handling: https://www.techni-tool.com/category/Static-Protection/ESD-Training-And-Awareness-Materials
  • FPV ESC PWM Signal Control

    Unsolved
    2
    0 Votes
    2 Posts
    593 Views
    Alex KushleyevA
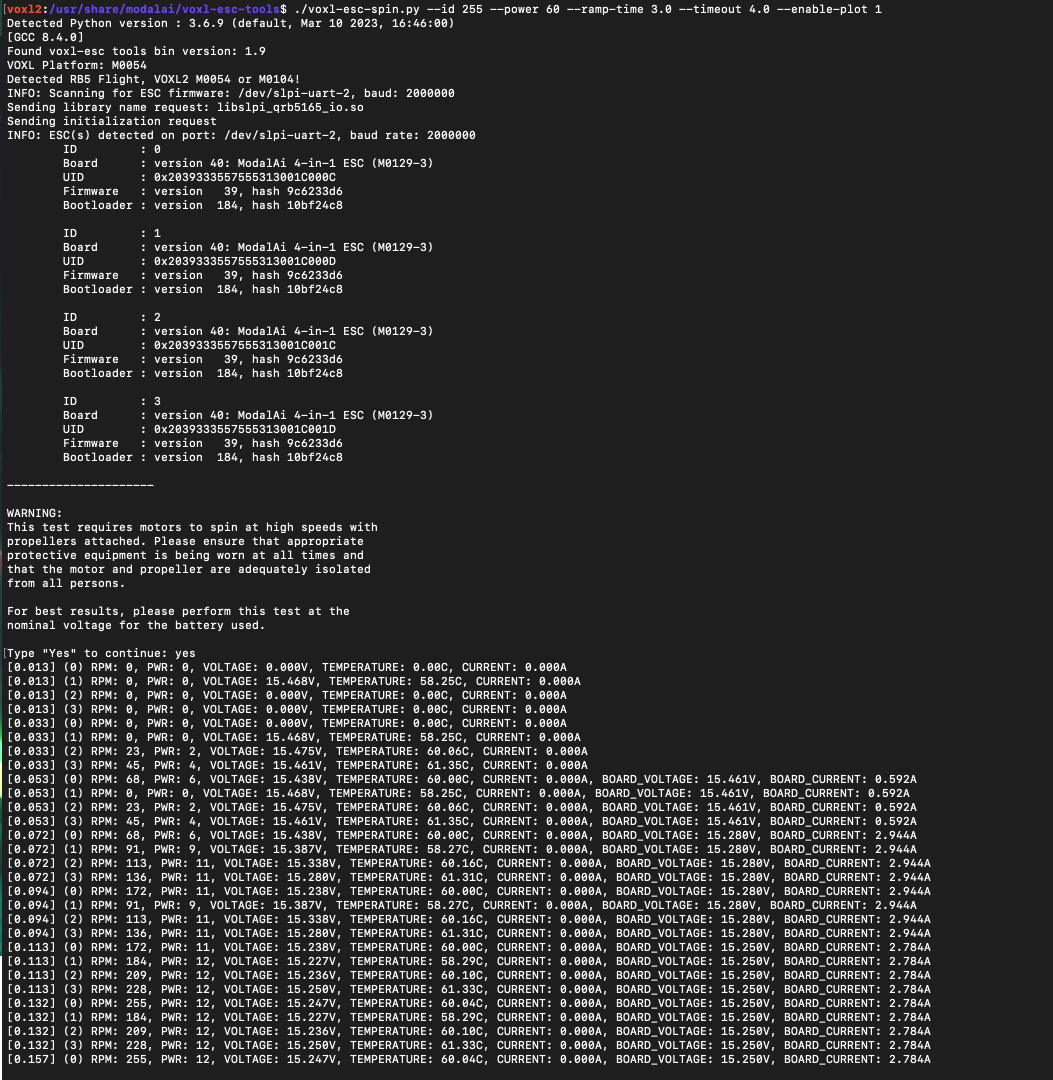
    @Jeremy-Frederick , the FPV ESC currently supports two pwm outputs, it can be tested using the following test script: https://docs.modalai.com/voxl-fpv-esc-datasheet/#pwm-inputs--outputs (docs) https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/dev/voxl-esc-tools/voxl-esc-pwm.py (test script) make sure ESC firmware is 39.18 or later, as specified in documentation The python script tells you which ESC boards support pwm output: # PWM support on ModalAi ESCs: # M0049, M0117, M0134, M0129 : IDs 0, 1, 2, 3 # M0138: IDs 0, 3 only # All boards use pin A2 for PWM output by changing the --id argument between 0 and 3 you should be able to use this test script to control PWM outputs of the two test points of M0138 ESC . Please be careful soldering to the test points as they are small and avoid pulling on the wires (use strain relief). We are also working on enabling a 3rd pwm output on the output that is currently used for the Neopixel LED (this output is also pwm capable). In terms of integration, standalone testing can be done using this python script, but sending pwm commands have to go through PX4, and we are working on integration. You can use the following tool which will send a message to PX4, which will get forwarded to the ESC: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-mpa-tools/-/blob/sdk-1.3.4/tools/voxl-send-esc-pwm-cmd.c . Note that this tool has been moved to another repo after sdk 1.3.4 , but you should be able to use this tool to control pwm from voxl2 command line while the px4 is running and talking to the ESC. The new repo for the tools is here : https://gitlab.com/voxl-public/voxl-sdk/services/voxl-io-server/-/tree/dev/tools and I believe it should be doing the same thing, although i have not personally confirmed it yet. Try it out! Long term, we do plan to provide the support for this (this is not a temporary feature), so we are working on cleaning up the tools for that. Alex
  • Barometer was not working perfectly (Temperature raises)

    Unsolved
    5
    3
    0 Votes
    5 Posts
    2k Views
    Alex KushleyevA
    regarding external baro, please see response here : https://forum.modalai.com/topic/3996/unstablr-baro-in-voxl-2-mini
  • Looking for Help Understanding the GPIO mapping on the QRB5165

    Unsolved
    11
    0 Votes
    11 Posts
    2k Views
    Eric KatzfeyE
    @Jeremy-Frederick Those aux channels are implemented differently when getting manual control messages from QGC. The only one that is mapped is aux1 that comes from the "buttons" field of the corresponding MANUAL CONTROL Mavlink message.
  • Changing video resolution of voxl-streamer

    Unsolved
    2
    0 Votes
    2 Posts
    580 Views
    Alex KushleyevA
    @groupo , can you please provide some more details: are you using voxl-streamer to stream an h264 / h265 encoded stream (generated by voxl-camera-server) or is voxl-streamer consuming raw frames (raw8 or yuv) and encoding them to h264 / h265? If the input to voxl-streamer is not encoded, then voxl-streamer will encode them (using hardware video encoder) voxl-streamer is not set up to resize the image, so the image size is defined by the source that is providing the images or encoded video stream (most likely voxl-camera-server). you can modify your /etc/modalai/voxl-camera-server.conf to change the resolution of the stream that you are feeding into voxl-streamer (such as preview, small_video, large_video, etc) and that should automatically be reflected in the resolution that voxl-streamer outputs. Feel free to provide more specific details about which exact stream (name) you are feeding into voxl-streamaer or let me know if you have any other questions. Alex
  • Imagery collected on ModalAI drones

    Unsolved
    2
    0 Votes
    2 Posts
    452 Views
    Alex KushleyevA
    @paul-foley , we do not have a repository for images. My suggestions would be: try using training sets from other sources (as you have been trying), but I don't have a specific reference in order to better match the 3rd party datasets to your use case, you should try to do the following: transform the 3rd party images to make them look more similar to what you are looking for (crop, zoom, resize, adjust color, etc). This can be automated transform the images collected on Starling to some standard, for example you can perform fisheye un-distortion to make them look more like the images taken from non-fisheye cameras from your training set, similarly adjust color if needed (white balance). In general, if you can somehow standardize your images, and convert the 3rd party images to the same standard, you can greatly benefit from the large data sets that you could find online. The only down side that when running the model online, you will need to transform your images in real time, but that should not be a big deal. If you need to, I can help you with some GPU-based examples to do image transformation very quickly, but you should first make sure that this approach will work for you first (and optimize later ) I hope this helps.. Alex
  • MavRos with drone won't do takeoff

    Unsolved
    3
    1
    0 Votes
    3 Posts
    887 Views
    Kiazoa JoaoK
    @Daniel-Ryu same here. Please let me know if you figured it out.
  • 0 Votes
    2 Posts
    502 Views
    ModeratorM
    @anghung said in How to use the USB Type-C interface on the board's ADB shell as a regular USB interface?: he USB Type-C interface on the board's ADB shell as a regula That is a USB OTG interface which will negotiate automatically with its peer device
  • ADB not working. No devices detected

    Unsolved
    18
    2
    0 Votes
    18 Posts
    4k Views
    Kiazoa JoaoK
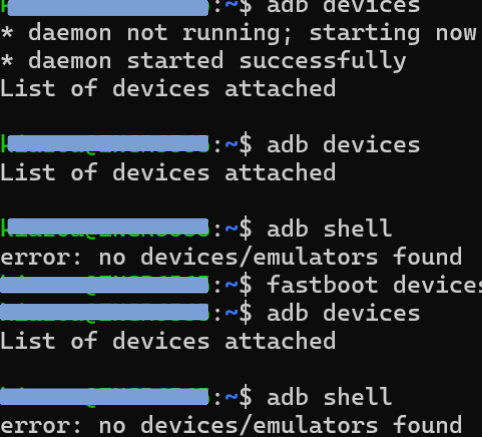
    @jonathanrblazer I am glad it worked out for you. yes, I've been running the docker inside the VirtualBox, but you can also run it outside the VM, just use your wifi and "ssh root@ip". Always "commit" any changes you make inside the docker; otherwise, you'll have to re-download your packages over and over again. I also had a lot of issues with communication. The docker container wouldn't communicate with the drone. If you're trying to run MAVROS, follow these steps here https://docs.modalai.com/mavros-0_9/
  • Connection betweeen M0178 adapter board and M0173 front end adapter

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    VinnyV
    Hi @Jetson-Nano Yes, sorry for not following up. We have a small batch tested and in inventory now. I think our team may not have it up yet in Shopify, so you can always reach out directly asking for a quote using our contact form. I alerted the team your request may be in-bound. https://www.modalai.com/pages/contact-us
  • TFLITE Server

    Unsolved
    3
    0 Votes
    3 Posts
    679 Views
    Zachary Lowell 0Z
    No - tflite server runs only tflite on the GPU - you can try leveraging the Qualcomm Nueral SDK to get onnx working on the Adreno GPU, but that is a very large lift.
  • Amprius Silicon Anode Charge instruction and Discharge curve

    Unsolved
    1
    0 Votes
    1 Posts
    11k Views
    No one has replied
  • GPU "hello world"

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    Alex KushleyevA
    @jamesbowman , so the difference in compilation is just adding of -L /usr/lib or something else? I believe this is redundant, as this path should already be in the library path.. Hmm
  • Starling 2 Max Drone drifting off

    Unsolved
    7
    8
    0 Votes
    7 Posts
    1k Views
    V
    @Eric-Katzfey Thank you for your response. For Manual mode, I recalibrated the level horizon, accel, compass, and gyro. However, during the RC calibration, I noticed a small shift in the yaw when all the sticks are in their neutral positions. I’m unsure if this is contributing to the issue. I attempted to recalibrate it several times, but the yaw does not reset to the 0 position. Please find the attached screenshot for your reference: [image: 1732209517950-ca3710fa-d00c-4444-b9cf-2fe8d267f7f4-image-resized.png] . As you suggested, I tried flying in Altitude Hold mode, and the drone drifted in the direction where the yaw was shifted. Is there a way to fix the yaw offset?
  • Starling 2 Max Not Arming

    Unsolved
    5
    1
    0 Votes
    5 Posts
    2k Views
    V
    @Eric-Katzfey Nevermind, I found the issue. In the voxl-px4.conf file, the RC value was somehow updated to SPEKTRUM. After changing the RC value back to GHST, the issue was resolved. Thank you so much for your support!