Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Change Pwm channel

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    modaltbM
    Alright! Thanks for the update, I'll likely use this post to get some updates to our docs, appreciate it!
  • Voxl-mapper instructions

    Unsolved
    2
    0 Votes
    2 Posts
    596 Views
    ?
    Hello @alarm_hq! Please see the updated readme on voxl-mapper's dev branch for an overview guide of this package. As for the timestamp too new error, this error typically arises when there is a VIO blowup, and one way to prevent this is by ensuring that the tracking camera is correctly calibrated pre-flight. Also, please see the overview guide for instructions on viewing, as RVIZ is no longer utilized!
  • This topic is deleted!

    2
    0 Votes
    2 Posts
    3 Views
  • Unable to run example TFlite model in emulator docker image

    Unsolved
    3
    0 Votes
    3 Posts
    595 Views
    Michael BarrowM
    Thanks, so what is the emulator for exactly? emulating native compilation? I am unclear of the emulator use case if it is not intended to emulate the voxl platform for application testing. Let me know, cheers!
  • Seeker replacement props

    Unsolved
    2
    0 Votes
    2 Posts
    647 Views
    ?
    Hey @alarm_hq! The props for the Seeker development drone can be found here.
  • How to: Seeker ESC calibration

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    James StrawsonJ
    @alarm_hq said in How to: Seeker ESC calibration: And if I've already made the "mistake" of reflashing px4 firmware, is the closed loop RPM control affected? The ModalAI ESCs used on Seeker have their own firmware and settings stored on the ESC itself, independent from PX4 so your ESC is fine after changing PX4 firmware.
  • Unstable Seeker after flashing

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    T
    Thanks Chad. We did the calibration again with a better calibration target, and this fixed the problem.
  • hires Camera for barcode

    Unsolved
    2
    0 Votes
    2 Posts
    517 Views
    Chad SweetC
    Have you looked at voxl-tag-detector?
  • voxl-uart-loopback problems

    Unsolved
    2
    1
    0 Votes
    2 Posts
    538 Views
    Alex KushleyevA
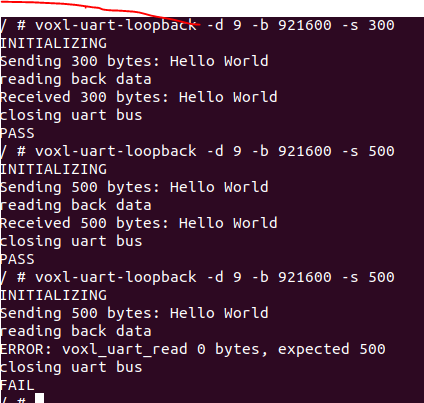
    Hello, There were a few issues with the uart loopback example: the test buffer size was not handled properly (if test size is larger than HelloWorld strin the sleep time was not enough to allow the transfer to happen (the write function is non-blocking, it seems) I have made some fixes here: https://gitlab.com/voxl-public/core-libs/libvoxl_io/-/blob/dev/lib/apps/voxl-uart-loopback.c Now the behavior is as shown below.. please try it. ./voxl-uart-loopback -d 7 -b 9600 -s 20 INITIALIZING Sending 20 bytes: 0123456789:;<=>?@ABC Transfer should take ~20833us, sleeping for 25833us (+5000us overhead) Reading back data... Received 20 bytes: 0123456789:;<=>?@ABC closing uart bus PASS ./voxl-uart-loopback -d 7 -b 9600 -s 500 INITIALIZING Sending 500 bytes: 0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJ Transfer should take ~520833us, sleeping for 525833us (+5000us overhead) Reading back data... Received 500 bytes: 0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJKLMNOPQRSTUVWXYZ0123456789:;<=>?@ABCDEFGHIJ closing uart bus PASS
  • hires camera issue

    Unsolved
    2
    1
    0 Votes
    2 Posts
    510 Views
    ?
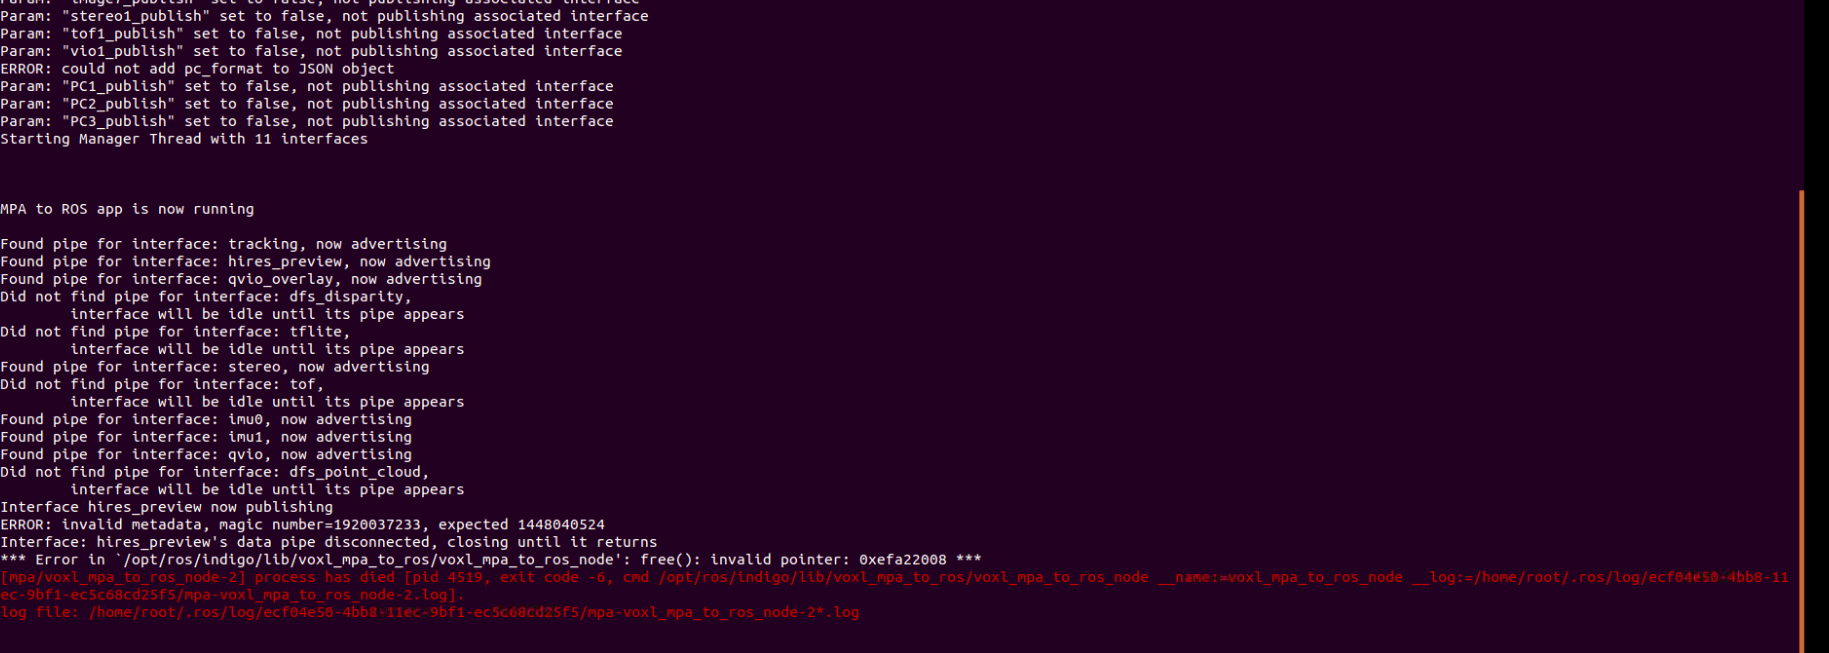
    Hi Prasobh, It looks like rosnode got an invalid metadata when reading from the hires camera pipe. This is an uncommon issue and should really only occur if the CPU is overloaded and starts throttling the client reading the camera images, eventually overflowing the camera pipe, thus getting out of sync. Additionally, it says that the data pipe disconnected, possibly indicating a problem with voxl-camera-server. If this occurs again, checking the logs with journalctl -u voxl-camera-server may provide some useful information as to what issue may have occurred on the hardware side.
  • Dual Camera Adapter

    Unsolved
    2
    0 Votes
    2 Posts
    676 Views
    Chad SweetC
    That cable was posted as a mistake, it is now deleted. You can stream any sensor connected to QGC. This doc here articulates all of the possible connections
  • USB to Ethernet Adapter

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    tomT
    Interesting, can you post a picture of the hardware setup you are attempting to use that isn’t working?
  • is it possible to run the VIO processing offboard, rather than on the VOXL Cam?

    Unsolved
    2
    0 Votes
    2 Posts
    503 Views
    Chad SweetC
    The VOXL platforms are all open, with the code available at https://code.modalai.com . This enables our customers to modify however they see fit. The qvio server that ships takes ~33% of one CPU core (out of 4 cores). So it might not be a worthwhile exercise to move that to the could. If you were processing a much larger state estimate, like a full keyframe SLAM, then that processing could be done on a server. It might be hard to close the control loops in flight if you are trying to fly with it. As an outer loop though, it should work fine.
  • OpenVpn don't launch on boot

    Unsolved
    5
    2
    0 Votes
    5 Posts
    960 Views
    tomT
    Also, ensure you aren't connecting to your VPN with the same key on a different machine.
  • Is it possible to use the VOXL CAM with a second companion computer?

    Unsolved
    4
    0 Votes
    4 Posts
    779 Views
    M
    Thanks @modaltb , I appreciate your feedback. I think the usb-to-ethernet can make sense at least for proof-of-concept. @Chad-Sweet Yes, I am aware there is already a companion computer on the VOXL Cam. In my current work, I've already got an autonomy stack implemented on-top of a custom px4 drone platform with the upboard as the companion. My first interest is to add the VOXL Cam purely as a "tracking module" to replace something like the intel t265, and integrate the odometry out of it into my existing software. This would give me a way to evaluate the VOXL Cam in the use-cases I am exploring with a drone/autonomy configuration that is known to work. From there, depending on how well it works, I might consider replacing the upboard with the VOXL Cam, but that would not be the first thing I would do, as I would have quite a bit of software to re-work/port edit: It's good the VOXL can already run ros; I figure I could use voxl_mpa_to_ros to pass the VIO data over ROS from the VOXL to the Upboard in this PoC just to get started easily.
  • Comparison between VOXL Cam and RB5 Companion Computer

    Unsolved
    1
    0 Votes
    1 Posts
    311 Views
    No one has replied
  • OPEN-VINS compile error

    Unsolved
    3
    0 Votes
    3 Posts
    958 Views
    R
    Hi @Chad-Sweet, even though this is not public (yet?), I setup a docker running open-vins. It runs without problems but I keep getting fast divergent behavior. Do you happen to have a launch file / parameter settings for open-vins with good parameter estimates for the flight-deck platform? I am not sure if my I set the extrinsics correct. I thought it must be simply the inverse of the output of voxl-inspect-extrinsics as open-vins expect a T_C0toI matrix: <rosparam param="cam0_wh">[640, 480]</rosparam> <param name="cam0_is_fisheye" type="bool" value="true" /> <rosparam param="cam0_k">[277.207560, 277.285144, 335.460288, 218.329580]</rosparam> <rosparam param="cam0_d">[-0.002486, 0.006832, -0.006556, 0.001300]</rosparam> <rosparam param="T_C0toI"> [ 0.0, 1.0, 0.0, -0.015, -0.70711, 0.0, 0.70711, 0.00283, 0.70711, 0.0, 0.70711, -0.0212, 0.0, 0.0, 0.0, 1.0 ] </rosparam> Another possible reason would be badly calibrated imu noise values. A reference file would be really helpful. Thanks!
  • Modifying VOXL Portal

    Unsolved
    4
    0 Votes
    4 Posts
    669 Views
    wilkinsafW
    @Matt-Turi @Chad-Sweet Sweeeettt. Thanks guys
  • 98% Packet Loss between QGC & Vehicle

    Unsolved
    13
    0 Votes
    13 Posts
    3k Views
    tomT
    @Chuck-Bokath Great to hear that you're making progress. As for developing your new program you can use the voxl-emulator docker image: https://docs.modalai.com/voxl-emulator/ in order to compile programs for VOXL on an Ubuntu machine. Here is a good doc on MPA https://docs.modalai.com/voxl-sdk/#what-is-modal-pipe-architecture-mpa
  • Docker Pull is not working for my own hosted image

    Unsolved
    2
    0 Votes
    2 Posts
    689 Views
    modaltbM
    Hi @Aldo-Castro-Freire , The docker on target is somewhat old (see this post) and there's a chance there's compatibility issues going on with docker hub. We've tested with google cloud registry and had success but haven't tried docker hub.