Skip to content
  • follow-up: wlan0 mac address

    Unsolved Development Drones rb5
    2
    0 Votes
    2 Posts
    741 Views
    tomT
    @mbahrami You can try that same solution, just substitute "wlan0" instead of "eth0"
  • qvio error: IMU_MISSING STALLED

    Unsolved Development Drones rb5
    8
    10
    1 Votes
    8 Posts
    2k Views
    S
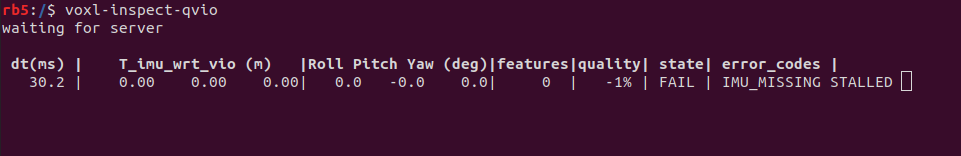
    @tom thanks tom! with voxl-configure-sku -w I assumed the option to select is 6) px4-autonomy-dev-kit i then ran voxl-configure-mpa saw a few errors but the qvio is working now with no errors. Sabri
  • gimbal integration

    Unsolved Development Drones rb5
    2
    0 Votes
    2 Posts
    732 Views
    B
    Where can I find TELEM 1 port in RB5 drone?
  • 0 Votes
    2 Posts
    1k Views
    tomT
    @doe43john77 You're right, that isn't the case. That doc is a bit outdated (we're going through a massive overhaul of the docs at the moment that will be live in a few weeks) As long as both devices are connected to the same VPN it would work just fine. So you absolutely could have your host machine connected to the internet via. wifi / ethernet as long as it then connects to said VPN
  • Qualcomm Flight RB5 5G Camera Setup

    Unsolved General Questions rb5 camera rb5-sdk
    11
    0 Votes
    11 Posts
    3k Views
    D
    @tom Ah. This is a simple config file change. Thank you!
  • voxl-camera-server only finds 5 out of 6 cameras

    Unsolved Development Drones rb5
    10
    0 Votes
    10 Posts
    2k Views
    tomT
    @Martin-Brandt Starting the RMA process is probably the best option as opening it up yourself risks damaging other components
  • QGroundControl Autoconnect when on same network with VOXL SDK

    Unsolved Development Drones rb5
    4
    0 Votes
    4 Posts
    1k Views
    Eric KatzfeyE
    @Sam-Kiley When on public 3G / 4G / 5G networks we use a VPN and assign fixed addresses to each system component with our VPN configuration. You should be able to do a similar thing with your 5G private network. Does your private network have a connection to the Internet or is it self contained? I don't know anything about 5G private networks but I'd be surprised if it didn't have a way to assign the same IP address to a device on the network so that you effectively have a static IP. Earlier versions of the RB5 SDK set the MAV_BROADCAST parameter in PX4 to 1 and PX4 would then use the network broadcast address to send out it's initial messages. Any QGC instance running on the network will receive that broadcast and respond so that you get automatic connection. However, this can be problematic if there are more than one instance of QGC running since you may connect to an instance that you don't want. Also, some wireless networks do not support broadcast.
  • Basic Qualcomm Flight RB5 5G Drone Development Kit

    Unsolved Development Drones rb5
    4
    0 Votes
    4 Posts
    737 Views
    Chad SweetC
    @rpaston The Sentinel and QC Flight RB5 are drones for software development - they are a reference so ultimately so you can build your own drones from our components. From your questions, it looks like you are looking for a more complete system. We need a 3-axis gimbal with 4K/8K camera, IR and laser rangefinder for testing. Which gimbal with 4K/8K cameras, IR and laser rangefinders are supported. Any suggestions? No We need precision landing on a moving base station (RTH) in wind. Does the platform have Dynamic RTH? No What is the IPxx rating? None Is the SDK open source? Yes, see https://code.modalai.com (based on Pixhawk/Python) and would it be compatible with Autel, Parrot or Aurelia? The flight controller is PX4 It would not be compatible with Autel, Parrot or Aurelia
  • USB3 streaming slower then expected

    Unsolved Development Drones rb5
    15
    0 Votes
    15 Posts
    2k Views
    Eric KatzfeyE
    @chinkey I ran a few tests yesterday. I used the speedtest-cli application with a USB dongle. In the first test I connected a USB 2.0 Ethernet dongle to my laptop and got around 90 Mbps. I then connected that dongle to the RB5 USB port and also got about 90 Mbps. I then tried a USB 3.0 Ethernet dongle. On the laptop I saw about 520 Mbps but was only able to achieve about 250 Mbps on RB5. So I think that's pretty similar to what you were seeing. It's unclear at this time why there is such a difference.
  • Technical Questions on RB5

    Unsolved Development Drones rb5
    6
    0 Votes
    6 Posts
    983 Views
    Eric KatzfeyE
    @adrianpang With regards to ArduPilot, VOXL2 is currently only able to run a version of PX4 on target. If you need ArduPilot you will have to use an external flight controller and connect it to VOXL2 with UART. We hope to have an implementation of ArduPilot that runs directly on VOXL2 in the future but there is no firm date on when this would be available.
  • 5G testing capabilities

    Unsolved Development Drones rb5
    2
    0 Votes
    2 Posts
    604 Views
    Eric KatzfeyE
    @JoshRebello This is the 5G module we are using: https://www.modalai.com/collections/modems/products/quectel-rm502q-ae. This also works well with our Sentinel drone which uses our VOXL 2 board instead of the RB5 board and has better capabilities. https://www.modalai.com/pages/sentinel. Even though it doesn't have 5G in it's name it uses the same 5G modem as the RB5 based drone.
  • Issues with Takeoff RB5 full throttle when armed.

    Unsolved Development Drones rb5
    2
    0 Votes
    2 Posts
    666 Views
    Chad SweetC
    Hi Daniel, can you please clarify "Note: We have recently updated the firmware to VOXL 2 and the default RB5 firmware worked fine."? The VOXL 2 platform image will not work properly on RB5 Flight. You need to use specific RB5 Flight software. The VOXL SDK works on both platforms, but there are low-level differences in the system image and specifically PX4 is configured differently between RB5 Flight and VOXL 2. See this page for how to load the RB5 Flight platform image https://docs.modalai.com/Qualcomm-Flight-RB5-voxl-sdk-upgrade-guide/
  • wwan0 carrier lost

    Unsolved Development Drones rb5
    4
    0 Votes
    4 Posts
    811 Views
    N
    Hi @tom ! Thank you for your response, the issue was solved by deactivating this service. Thank you so much
  • reverting back to RB5 SDK and flight image

    Unsolved Development Drones rb5
    6
    1
    0 Votes
    6 Posts
    1k Views
    tomT
    @Sam-Kiley We don't use the RB5 SDK anymore so haven't had experience with that specific version of quectel-CM is quite some time. We have a lot of customers using 5G via. voxl-modem on the latest VOXL SDK without issues.
  • Improving VIO accuracy

    Unsolved Development Drones rb5
    2
    4
    0 Votes
    2 Posts
    745 Views
    ?
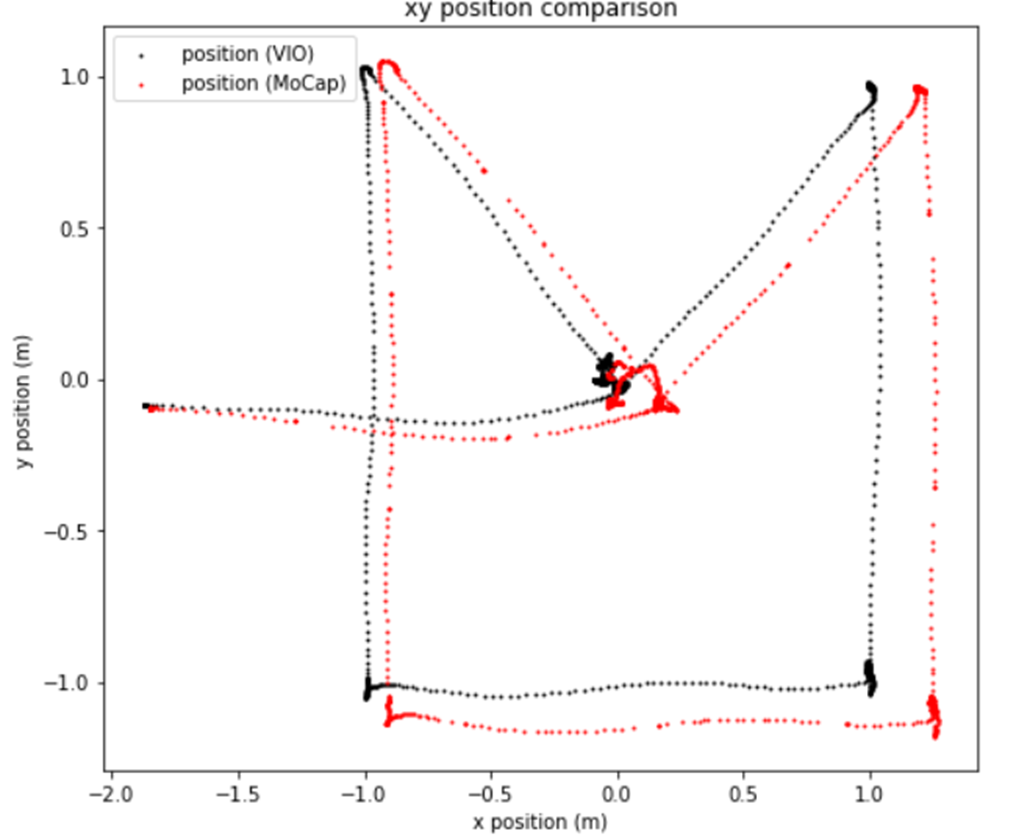
    Hi, This is all down to the VIO algorithm. You'd be able to make major tweaks if you're postprocessing the data after, like detecting a reset and continuing from the last valid position (we do this in vvpx4), but changing the px4 params or other fusion techniques that only use the same sensors as the initial vio algorithm will likely not yield any improvements. As for improving the vio algorithm itself, the QVIO's mvVISLAM package is proprietary code(even to us, we don't have the source) that we usually quote at 2% error over distance, which seems to match the test you've run here (you've flown a bit under 10 meters and it looks like you've drifted ~0.15-0.2 meters. We've been working on and experimenting with other algorithms internally, but don't have a hard date on when these will be fully tested/published. It's worth mentioning that most of our experimentation with these is to attempt to open-source our solution and add support for other features (like multiple cameras) but that generally the 2% error is considered very good especially in real-world environments. The 2 main things you can do out of the box to ensure that your VIO is working as best it can are ensuring that it has accurate camera and imu calibrations, and that your extrinsics file is accurate.
  • 0 Votes
    7 Posts
    2k Views
    ?
    Everything looks good, gave it a glance and a quick test, it's been merged to our dev and staging branches in v0.4.2 and will be in the next release, thanks!
  • Qualcomm RB5 Drone cant be turned on

    Unsolved Development Drones rb5
    4
    0 Votes
    4 Posts
    878 Views
    VinnyV
    Hi @Alejandro-M It's highly likely the ESC or Power Module board was irreversibly damaged from this configuration (normal lab wall power supplies cannot power a drone without near certainty of failure). If there is a short on the +5V_DCIN to GND, you can easily observe that, but the other failure mode could be an open circuit which will not show up on a DMM easily. Your best course of action may be an RMA with us so we can explore the drone and find the failure(s) and offer you replacement options to get this platform back up and running. https://www.modalai.com/pages/rma
  • issue with voxl streamer not reconnecting

    Unsolved Development Drones rb5
    5
    0 Votes
    5 Posts
    1k Views
    S
    Discussion moved to https://forum.modalai.com/topic/1647/voxl-streamer-does-not-handle-teardown-request-signal-correctly/4
  • Why does QRB5 switch from Position mode to Hold mode?

    Unsolved Development Drones rb5
    2
    1
    0 Votes
    2 Posts
    754 Views
    K
    Actually, I realized that the Hold mode can be switched back to Position mode once I move sticks more than 30%. However, the switching from Position to Hold mode was too fast (i.e., within 1 second), so whatever changes during that time was discarded and after moving 30% of sticks in order to switch from Hold to Position, the Altitude is either too high or too low for the next move. Do you know which parameters postpone the process of switching from Position to Hold mode? Thank you.
  • FAA registration of RB5 Flight

    Development Drones rb5
    2
    0 Votes
    2 Posts
    522 Views
    Chad SweetC
    You can register the drone here: https://faadronezone-access.faa.gov/#/