Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • EM9291

    Unsolved
    2
    0 Votes
    2 Posts
    439 Views
    tomT
    @bendraper We use Google Fi data SIMs for all of our testing
  • DSP - unable to load unsigned PD

    Unsolved
    2
    0 Votes
    2 Posts
    791 Views
    Dong LiuD
    @paynej Hi, I know this is very old topic. Did you manage to find a solution (or reason) yet?
  • Docker MAVSDK

    Unsolved
    9
    3
    0 Votes
    9 Posts
    2k Views
    Kiazoa JoaoK
    @Mohammad-Goli I had a really hard time building it. This is basically what I did: [image: 1737588525707-mavsdk.png] I had to manually build it. After that, I just followed the instructions and this is what I got, but I found an error at the end. [image: 1737588622237-mavsdk2.png] I had to use this command to be able to import the image: cat /data/tmp/voxl-mavsdk:v1.2.tar.gz | docker import - voxl-mavsdk:v1.2 But now I can't run it. Hopefully, someone on here can help with this.
  • Connecting Teensy to VOXL 2

    Unsolved voxl2
    3
    0 Votes
    3 Posts
    2k Views
    Eric KatzfeyE
    @bkim1301 I would start by connecting the VOXL 2 UART 7 to a PC with a serial to USB cable. Make sure you can communicate back and forth using that setup and then do the same with the Teensy before connecting the Teensy and the VOXL 2 together. It's often very helpful to use an oscilloscope on the rx / tx lines to verify that there is actually data flowing.
  • Unable to see rostopics published by mpatoros2 foxy in my humble docker container

    Unsolved
    4
    1
    0 Votes
    4 Posts
    1k Views
    Darshit DesaiD
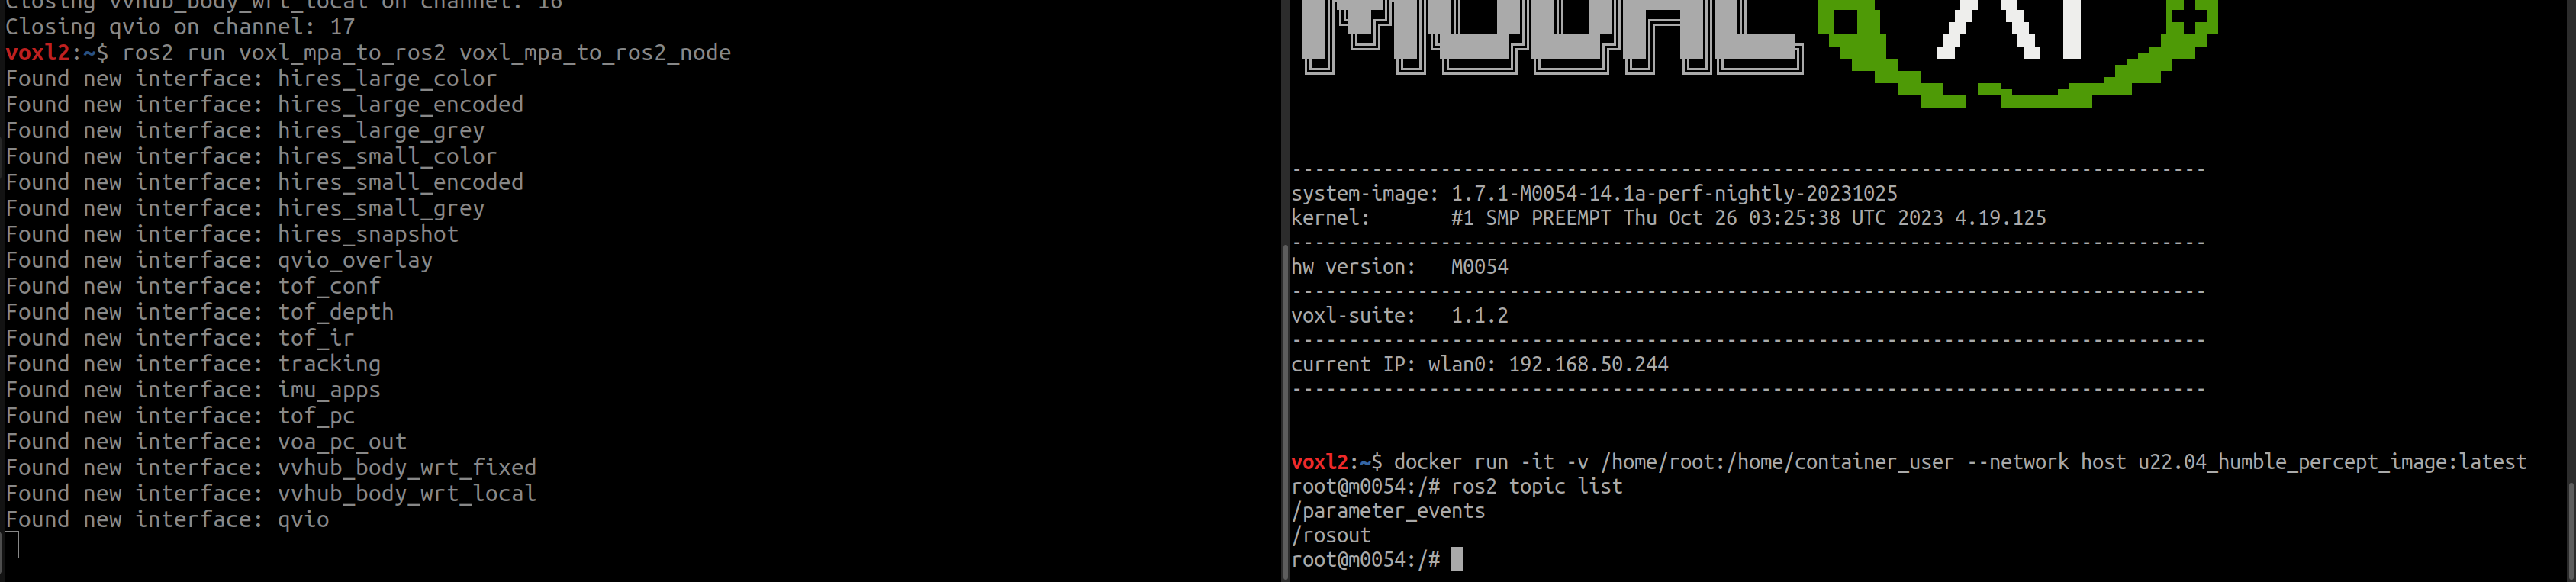
    @Zachary-Lowell-0 I am not sure how I resolved this, but as far as I remember there was px4_msgs versioning issue where I wasn't using either the correct ones or something
  • How to enable Turtle Mode

    Unsolved
    12
    0 Votes
    12 Posts
    2k Views
    Eric KatzfeyE
    @Jetson-Nano Instead of listening to the input_rc topic with the listener function you can now monitor the RC_CHANNELS Mavlink message from the FC v2.
  • voxl-open-vins-server imu_to_cam RPY(deg) different output logs

    Unsolved
    2
    2
    0 Votes
    2 Posts
    559 Views
    Aaron PorterA
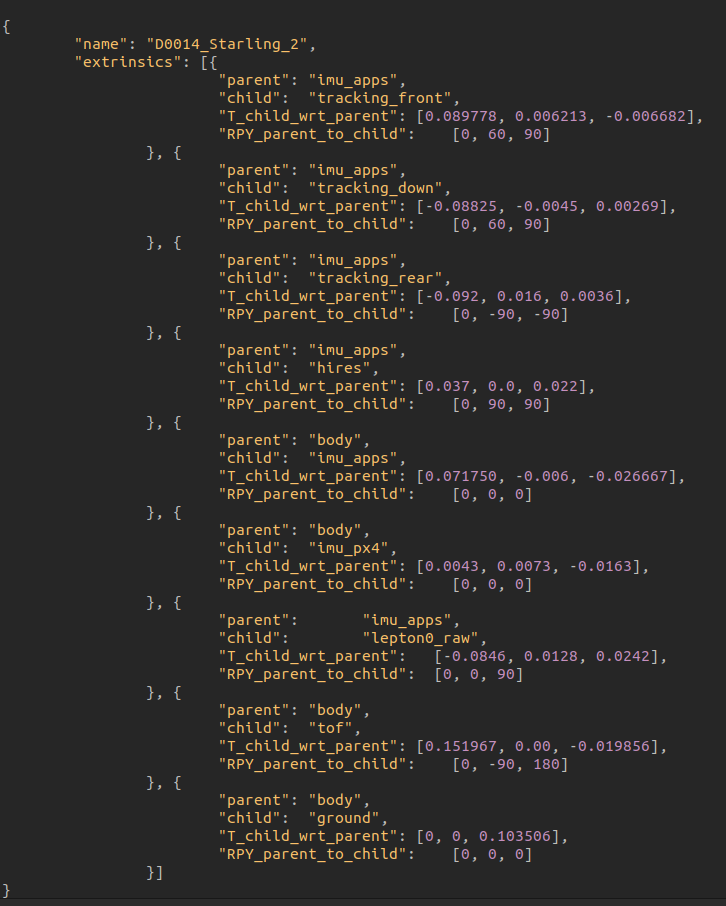
    Unsure, if you have resolved this so I am going to attempt to help but I am going to need more information if possible. I am unsure how the setup is for the drone seems like you have one camera (Tracking_rear) pointed straight backwards and two cameras (Tracking_front, Tracking_down) facing forward at a 30 degree downward angle? I am not sure that you are showing with the log output. Have you tried hand testing using the command voxl-inspect-pose -l and seeing how RPY and translational movement (moving the drone up, right, forward) are behaving for the local frame?
  • Setting up Joystick Button to Activate AUX1 For Turtle Mode

    Unsolved
    4
    0 Votes
    4 Posts
    1k Views
    Jetson NanoJ
    @Jacob-Camarillo @wilkinsaf Hi guys, I tested turtle mode out with internal FC and it is working. Now I have updated the system with Flight core V2 external FC, and I would like to achieve the same with this configuration. could you help me out here. Since we can not use px4-listener anymore. I am bit confused with what approach to go take.
  • Creating image of current state

    Unsolved
    2
    0 Votes
    2 Posts
    483 Views
    tomT
    @Kessie Not exactly, but the important data to retain lives in /data/ or /data/modalai The SDK flash will attempt to retain this partition, but in certain cases it requires a wipe. I would take note of /data/modalai/sku.txt as well as pull off any calibration files in /data/modalai, you can see if you have any onboard currently by running voxl-check-calibration If you have this data saved you'll have no issue getting back to your previous state, I can help guide you through it if you run into any issues.
  • Unbricking a VOXL 2 - Pass but no ADB?

    Unsolved
    15
    0 Votes
    15 Posts
    3k Views
    tomT
    @czarsimon When you run through the QDL process how long does it take for the flash to finish? seconds? minutes? Also, are you able to ADB onto functional devices on this machine? Want to rule it weird permission issues
  • latest yolov5 and tflite too many detection boxes.

    Unsolved
    1
    1
    0 Votes
    1 Posts
    452 Views
    No one has replied
  • Best way to automate Starling drone using MAVLINK

    Unsolved
    4
    0 Votes
    4 Posts
    906 Views
    Eric KatzfeyE
    @Jia-Wan Yes, you should be able to do your testing with SITL before trying it on Starling.
  • VOXL IO & ELRS Compatibility on VOXL 2

    Unsolved
    1
    0 Votes
    1 Posts
    430 Views
    No one has replied
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    2 Views
    No one has replied
  • figure 8

    Unsolved
    3
    0 Votes
    3 Posts
    690 Views
    Kiazoa JoaoK
    @Eric-Katzfey Thank you so much
  • About Starling 2 Max Outdoor GPS-denied Development Drone in windy environments

    Unsolved
    2
    0 Votes
    2 Posts
    470 Views
    tomT
    @jedeloya Can tolerate wind gusts of 15 m/s https://docs.modalai.com/starling-2-max-datasheet/
  • Inquiry About ModalAI Flight Controller Compatibility for Heavy-Lift Drone

    Unsolved
    4
    0 Votes
    4 Posts
    820 Views
    Eric KatzfeyE
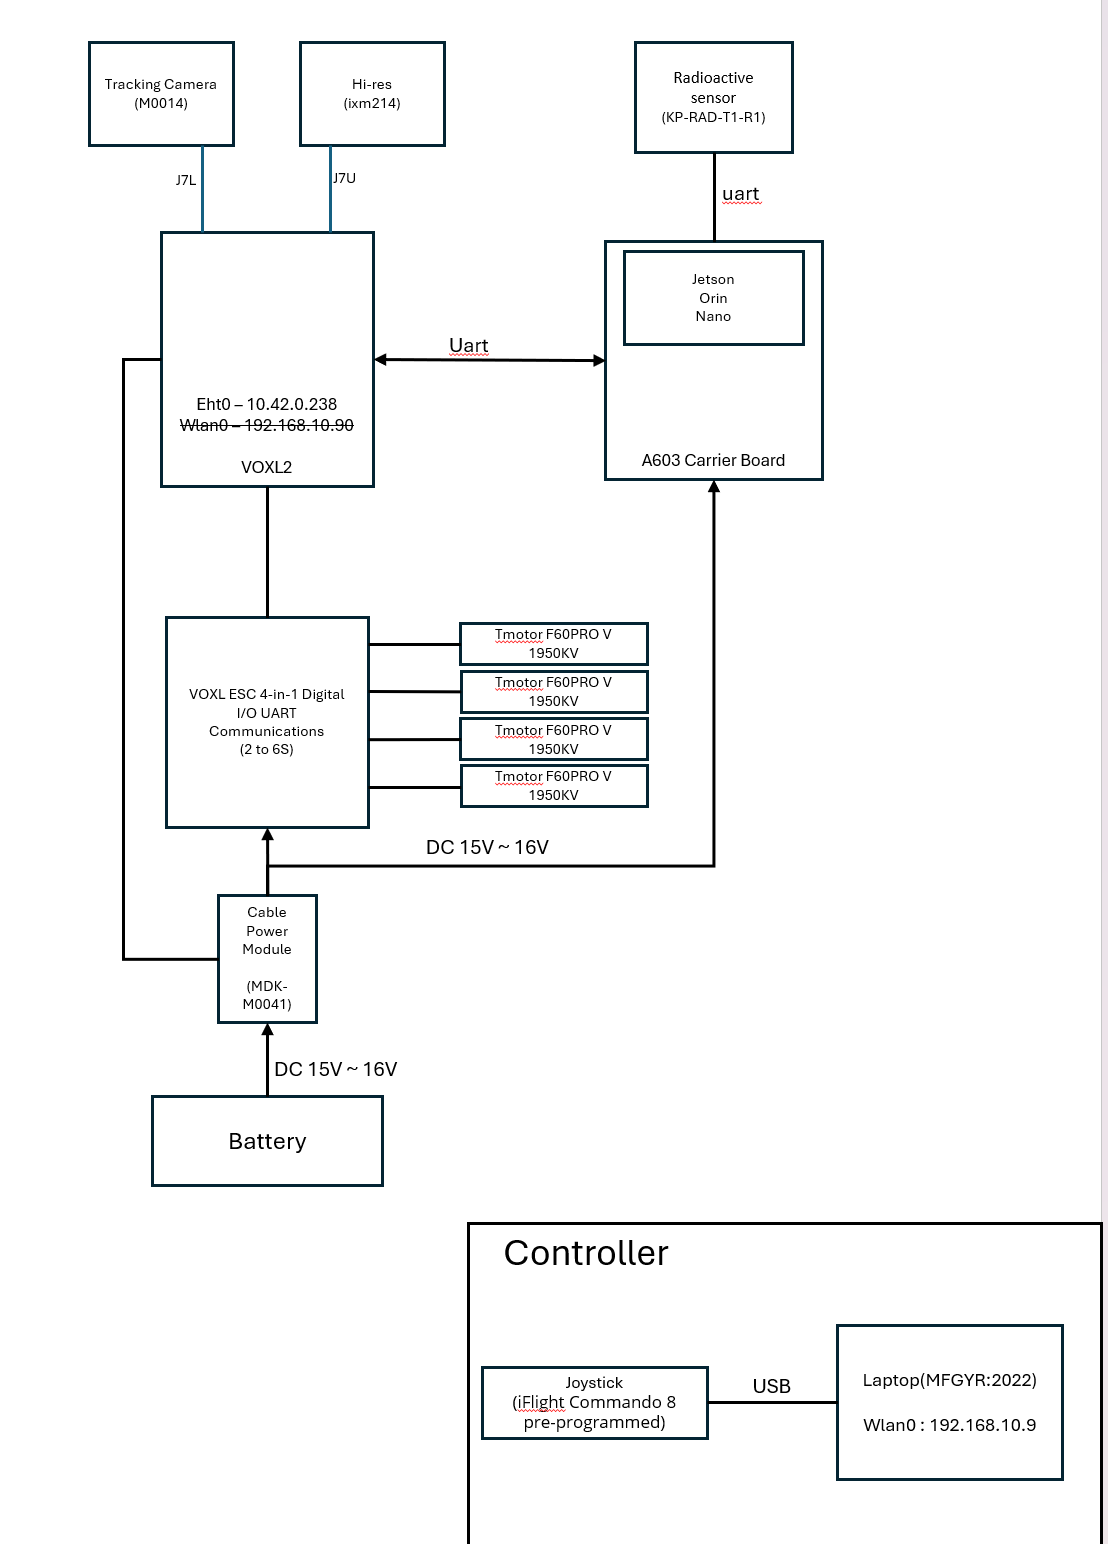
    @Mouhamed-Ndoye What is the interface to control these propulsion units? Is it standard PWM? VOXL does not have a flight controller integrated, it is only a companion computer. But VOXL 2 and VOXL 2 mini support either PX4 or ArduPilot. They, however, do not have any PWM outputs. You would need to use our VOXL 2 Digital IO expander board (https://www.modalai.com/products/voxl2-io?variant=40610514206771) in addition to the VOXL 2 to get that added capability.
  • voxl2 to jetson uart

    Unsolved
    6
    1
    0 Votes
    6 Posts
    1k Views
    Alex KushleyevA
    @tkddnjs825 , since you already have M0062, you should be able to use it. As you already identified, J9 on M0062 has /dev/ttyHS2 Linux UART device. You can also find more information here : https://docs.modalai.com/voxl2-external-flight-controller/ regarding configuring mavlink server. It looks like you are doing the right things here. However, the use case for "autopilot_uart_bus" maybe different from what you need - in your case your autopilot (px4) is actually on VOXL2 and the uart connection is for the path to GCS. You may need to modify mavlink server depending on what you want to pass on this UART connection.. This goes beyond my knowledge of mavlink server - please try to see if you can get it to work, otherwise post a follow up question with details of what you would need to be sent using the UART connection. Alex
  • DSP Uart Application

    Unsolved voxl2 slpi dsp uart
    7
    0 Votes
    7 Posts
    2k Views
    Alex KushleyevA
    Hi @scosgrove, Thanks for the details. On the DSP there is a dedicated HW block for each UART (similar for the UARTs connected to the application processor). All the UARTs supported on DSP have hardware FIFOs. Since you asked about the size: DSP UART2 has 64-byte low level FIFO on RX DSP UART6, 7 have 128-byte low level FIFO on RX When fifo is close to filling up, there is an ISR that triggers on the DSP which transfers the data from FIFO to other memory, and then the data propagates to the user. I wonder if there is some issue when fifo is read while another byte is incoming into fifo at the same time. Which uart port are you using for this test? I can do some testing with bursts of 70-250 byte packets. In the past we have tested continuous data transfers of several KB but not at high rates. Also, what baud rate are you using now? Alex
  • Modalai Server Client Issue

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    Alex KushleyevA
    Agreed! thanks for noticing, Tom. Definitely should be tested on a recent SDK.. Alex