Skip to content

ESCs, Sensors and Accessories

413 Topics 2.4k Posts

ESCs, image sensors, ToF and tracking cameras, Microhard and cellular modems, power modules, GPS and other add-on boards.

  • voxl io server

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    Alex KushleyevA
    Hi @qubotics-admin , Our understanding is that the voxl2_io driver should present itself as a generic PWM output (up to 8 channels) and you should be able to map any function you need to it. Although we have not explicitly tested every function. Can you please clarify which version of voxl-px4 you are using and elaborate on the "limited options" that you have for selecting the PWM function (what are you expecting to be able to set and what are the options). Alex
  • MDK-M0048-2-01 change to MDK-M0048-2-01

    Unsolved microhard
    2
    0 Votes
    2 Posts
    2k Views
    VinnyV
    Hi @austin-c yeah, and it will not. There are dozens of changes between the two boards. It's just easier and cheaper to order the correct version. We have no documents showing how to convert it is simply not doable for the cost and risk and time. Not the news you wanted, but please trust me on that one.
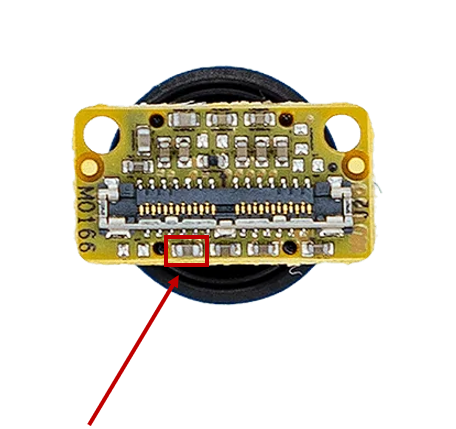
  • AR0144 Camera capacitor came off

    Unsolved
    3
    1
    0 Votes
    3 Posts
    2k Views
    D
    @Alex-Kushleyev alright, thanks for the help!
  • Data Sheet Missing MSU-M0039-1-01

    Unsolved
    1
    0 Votes
    1 Posts
    776 Views
    No one has replied
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    19 Views
    No one has replied
  • Boson vs Boson+ Compatibility

    Unsolved image-sensor
    2
    0 Votes
    2 Posts
    952 Views
    Alex KushleyevA
    @cbay , As long as the Boson / Boson+ 640 (or 320) supports MIPI output, it should work. We believe that some Boson models do NOT have MIPI support (HW limitation) but all Boson+ do have MIPI support. Please check with your vendor to make sure MIPI output is supported. Also, did you actually mean M0187, or something else? M0187 is an adapter for a Flir Lepton : https://docs.modalai.com/M0187/ Alex
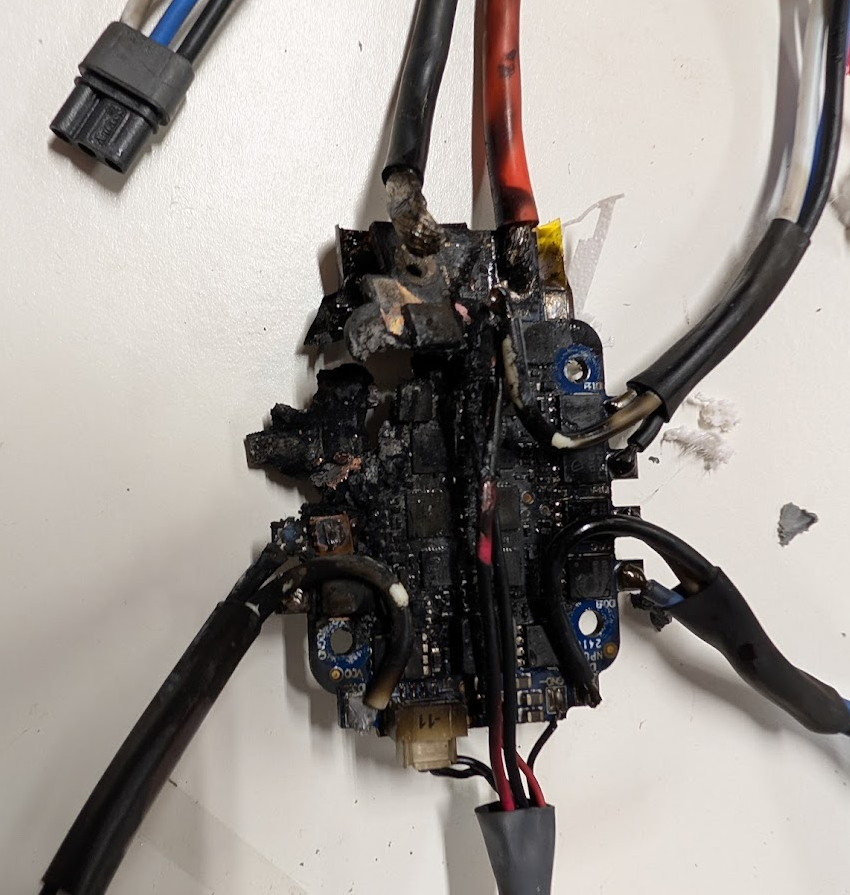
  • Diagnosing ESC fire on m0138

    Unsolved esc
    4
    1
    0 Votes
    4 Posts
    2k Views
    Alex KushleyevA
    Hi @Martin-Lukac , Thank you for the update. I am glad to see that your new tests went fine. As I mentioned before, i was quite surprised to see the ESC fail in such a way, which may suggest some kind of anomaly. I will provide a longer answer soon, but for now some quick notes: non-zero kp / ki parameters will speed up the ESC's RPM response. I will provide some examples you can test whether the ESC closed-loop controller is stable using voxl-esc tools, using step inputs, etc. if unstable, lower Kp. Then lower Ki to avoid slow overshoots. Ki will definitely not contribute to high frequency oscillations. assuming the ESC closed loop response is stable, if the Flight Controller is commanding noisy RPMs, the ESC with aggressive tuning (high kp) will try to track the noisy rpm commands, resulting in motor and ESC heating up. there are generally two main sources of oscillations: unstable attitude controller or vibrations / noisy gyro unstable attitude controller : characterized by lower frequency oscillations (in the range of 10-30Hz, depending on your frame, motors, etc) vibrations can result from drone frame twisting at the frequency of motor RPM, or loose flight controller board / IMU, if flight board is shock mounted, the connected wires can potentially carry vibrations or cause the board to flex due to the wires vibrating / moving (very quickly). These vibrations will be at the frequency of motor RPM. aggressive (high) values of ESC kp will amplify these vibrations, so you can end up in a situation when the ESC's closed loop RPM controller is feeding back and contributing to higher oscillations. by analyzing the gyro logs (will need to enable high rate logging), using FFT you can determine if your frame is mechanically unstable / noisy or the attitude controller is unstable. if you set kp and ki to 0, you still have the advantage of calibrated (and voltage-compensated) RPM control. However, the control will only have feed-forward term. So behavior will be close to response of a traditional ESC with added calibrated feed-forward rpm control with voltage compensation. regarding whether you need a bigger ESC.. it depends on the maximum total current that you plan to pull. The M0138 ESC has been tested with similar motor / prop combo (3110 motor, 900kV with a 10x4.5 tri-blade) . During bench testing, each motor could pull close to 40A at 6S, however in practice you are never going to have all 4 motors spinning at absolute maximum rpm (then you will not have any control margin for attitude). We have tested full punch-out flights for 100+ Amps for over a minute and the ESC was perfectly fine (airflow required for cooling). The mosfets on M0138 are rated for 100A+ continuous (each), so 40A continuous an issue. It will come down to the total current draw and cooling. For high power applications like this, you should definitely start at lighter loads and try to push the ESC to the limit. You will also need to worry about power connector(s) if you are drawing 100A+ continuously (battery connector may melt). px4 params: the min and max rpm params in px4 should match the min and max in your esc params. the px4 params do not override the limits in the esc params - the ESC will cap the incoming rpm commands if they are outside of the ESC params limits. Also, if you have incorrect px4 rpm limits, the thrust calculation in px4 will be incorrectly scaled from 0 to 100%, so you definitely want to get those rpm limits to be in sync between the ESC and px4. Also, you can use our custom version of flight-review to display additional data specific to our ESC (rpm commands, actual rpms, esc temps, etc) : https://github.com/modalai/px4-flight-review (you can run it locally in docker). Alex
  • Color Tracking Camera w/ Global Shutter

    Unsolved image-sensor
    6
    0 Votes
    6 Posts
    2k Views
    J
    @Alex-Kushleyev , thank you for the insights! I will try the basic version and see if it suits our industrial solution on field. If it fits I ask for the full version. Regards, Jacob
  • How do I purchase the Flir Boson 320 thermal camera?

    Unsolved image-sensor
    3
    0 Votes
    3 Posts
    1k Views
    J
    @Moderator Thank you for your reply.
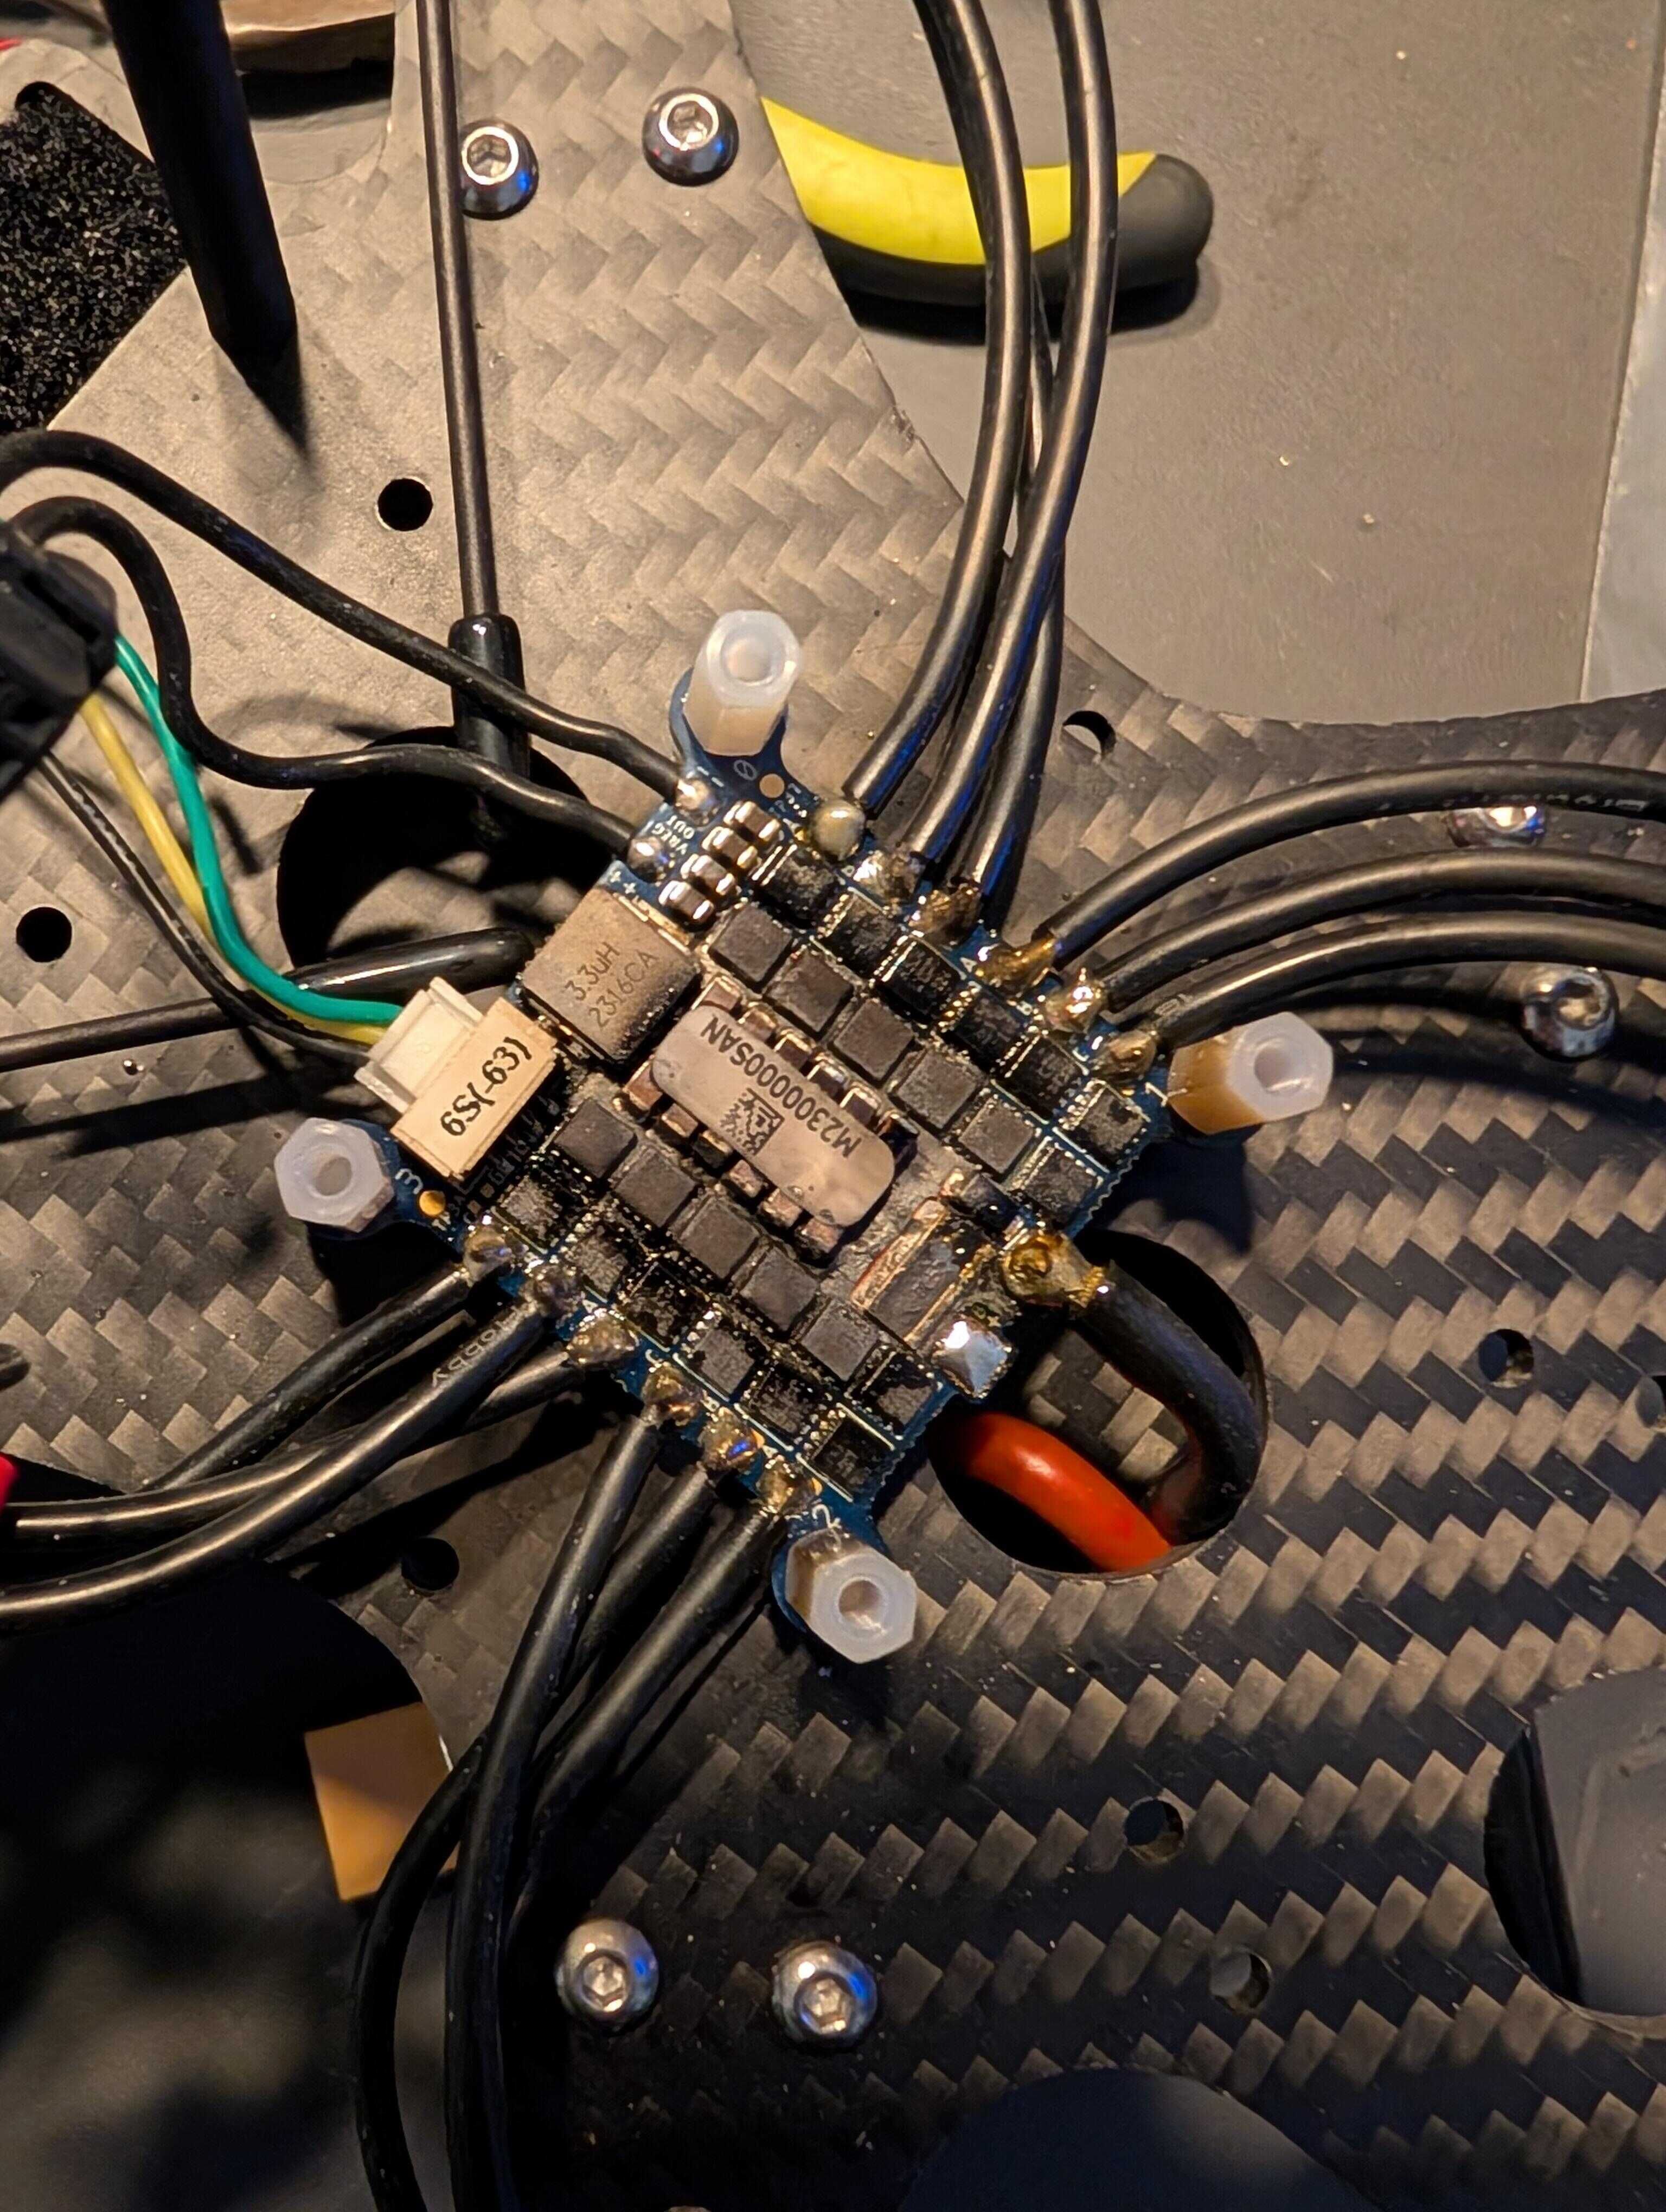
  • VOXL ESC 4 in 1 Fire

    Unsolved esc
    4
    1
    0 Votes
    4 Posts
    2k Views
    Alex KushleyevA
    @awagner , I think the main issue that started the failure mode was the spin-up type was set to 0 in params, which I do see that you got from the seeker_v1 xml file you mentioned. It is not your fault. The non-sinusoidal spinup is not as reliable and it is mostly not used any more. I will look at removing the old param files that use that option. Let me explain the reasoning behind using a larger ESC, especially during initial testing: the larger (FPV) ESC can handle much larger currents and dissipate a lot more heat, so it can handle much larger glitches, which could arise from mis-configuration during initial testing the ESC firmware does have some timeouts for protection, which generally do prevent fatal issues like this, but if the glitch results in enough current to quickly burn out a mosfet, the ESC cannot recover. The larger ESC (with larger mosfets and larger thermal mass will take longer to burn out, so the ESC's timeout / glitch detector should save it) larger motors in general have larger stall current, which would result in large current if there is some glitch during start-up. based on the numbers that you provided for the motor spec calculator (3.75A hover / 17A max), it should be possible to tune the mini ESC to work, however there are still some things to consider: may need to add more bypass capacitance to handle larger current transients if the motor is stalled (due to impact, etc), there is still a bit higher risk of ESC burning out due to stall detection being a bit too late. As for the xml to use as a starting point.. You can start with this one: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/master/voxl-esc-params/D0020/m0138_3110_900kv_gemfan_10x4.5_tri.xml This is tuned for a 6S application 3110-size 900kV motor with a 10x4.5 tri-blade motor (pretty powerful configuration). You will need to update: voltage (6s to 4s) motor params (kv, rpm curve, etc) you can set the timing advance and sense advance from 20 to 0 (your application is likely not aggressive enough to require tweaking that), although you can do some bench testing to determine if you encounter de-syncs during large rpm transitions : https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-esc/-/blob/master/voxl-esc-tools/doc/low_kv_motor_tuning.md you may need to adjust the spinup power / latch power -- generally keep it between 70-100 (7-10%) but when i tune this, i also usually find the minimum spin-up power that is able to reliably spin up the motor and then add a 10% extra (so 70->80). You can set spin-up power to a higher value in sinusoidal spin-up mode and it will produce a lot more torque, but will also consume more current. I usually try to limit a per motor spin-up current to 1-2 amps as a rule of thumb. for a fixed prop (not folding), your spin-up time can be anywhere between 500-1000ms, you can experiment. If you see the motor skipping during spinup and re-starting, you can increase either spin-up time or spinup power. may want to re-enable start-up beeps (disabled in this config) you can set kp (proportional gain) to 50 first (softer), then bump up to 100 or so, as you build confidence. higher kp will result in snappier response (faster than traditional ESCs without rpm control) but will also draw more current during transitions. (with M0138, you should not need to add more bulk capacitance to ESC power). With correctly tuned sinusoidal spin-up procedure, it should work pretty much 100% of the time (spin up on the first try every time). If you are seeing some inconsistent spin-up behavior, then it is possible there is some parameter issue and it needs to be investigated. When you get your M0138, i suggest updating the params per my notes above and doing some bench testing using voxl-esc tools where you just spin up and stop motors many times in a row and make sure the spin-up is reliable. Please let me know if you have any other questions! Alex
  • Compatible ToF sensor setup with VOXL2 Mini

    Unsolved
    18
    0 Votes
    18 Posts
    9k Views
    Alex KushleyevA
    @Sarika-Sharma , The preview width and height parameters are always in the camera config file, so if you added them, they are duplicates (and will be ignored). Please read through this thread as it has pretty detailed explanation how to configure the correct tof sensor (old or new) for a custom configuration. Camera-server-config-helper is indeed helpful. If you use it correctly, you should not have to manually modify the resolution in the config file. If you still cannot get this to work, please let me know what cameras you have plugged in (and which camera ports) on your voxl 2 mini. Alex
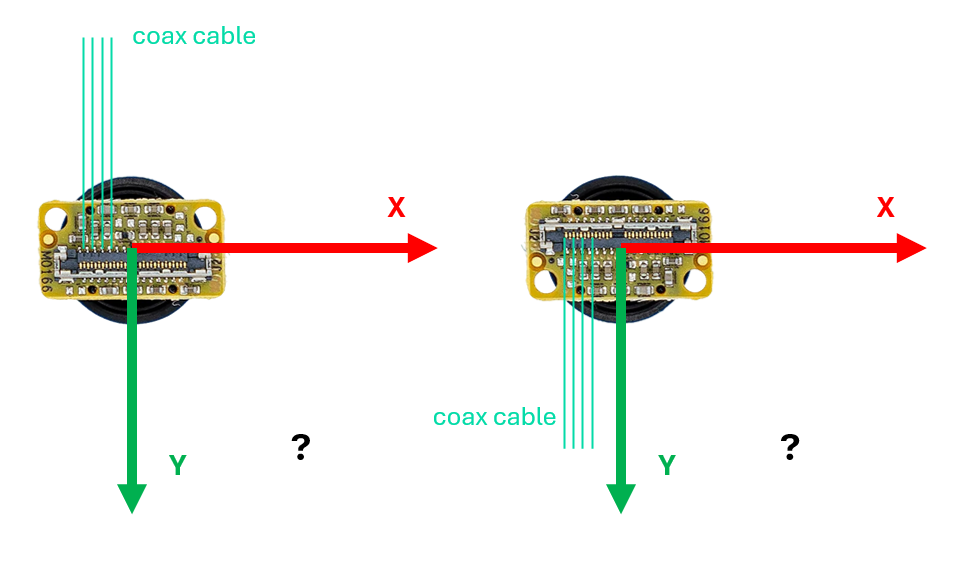
  • Coordinate system in AR0144 Tracking Camera

    Unsolved image-sensor
    3
    1
    0 Votes
    3 Posts
    1k Views
    D
    @Alex-Kushleyev Thanks for the help !
  • VOXL Mini 4 in 1 ESC query

    Unsolved esc
    10
    0 Votes
    10 Posts
    5k Views
    A
    @Alex-Kushleyev Thanks for detailed information and analysis. I am going ahead with further testing with this ESC as per your suggestion. I have changed my propulsion system as follows: Emax Eco II seroes 2306 2400kv motor, propeller Gemfan 5177 and 15000 mah 4S battery. Here is my file with ESC calibration : https://drive.google.com/file/d/1uzbx9MGwF1EvRqJx6tXBqqc-j3XZSgu_/view?usp=sharing All the motor directions are checked and they are correct as per airframe reference. My UAV is able to takeoff a bit but at around 0.5 meters it again decreases its altitude and then after scratching the surface is flipping over. Here is the logs : https://review.px4.io/plot_app?log=08691d7d-887d-41d8-b00d-d543febeea59 Can you spot is my ESC configuration wrong or anything I am missing in PX4 configuration? This flip happened twice in a row and all motor direction are verified to be correct since UAV is able to takeoff. Also any advantage of RPM vs PWM control in VOXL ESC PX4 parameter setup? Also my voxl2 is unpside down so I have set ROLL_180 in Autopilot orientation, but is this creating some problem anywhere is unknown since I can see yaw reset EKF2 estimator flag set as soon as I takeoff.
  • Meaning of esc_state for M0129 Mini 4-in-1 ESC

    Unsolved esc
    2
    0 Votes
    2 Posts
    2k Views
    Eric KatzfeyE
    @schew The ESC states are as follows: 0: idle / not spinning or trying to spin 1: spinning up 2,3: unused 4: very brief transition between spin-up and full back-emf sensing mode (user's commands are not yet executing) 5: back-emf sensing mode (rpm or power control based on user's command) If there is any issue that causes ESC to think it's stalled or communication timed out, it will go through state 0 and then to 1 if non-zero commands are sent via UART. The typical start-up sequence is basically 0->1->4->5 and should stay at 5 until you send a zero command or stop sending commands.
  • VOXL2 IMX664 support

    Unsolved image-sensor
    3
    0 Votes
    3 Posts
    1k Views
    N
    Hello @Alex-Kushleyev , Thank you for your quick response! I thought this might be the case, but I still wanted to confirm. I appreciate your help with the matter.
  • GPS for Starling2

    Unsolved
    5
    0 Votes
    5 Posts
    3k Views
    Nitin Varma VegesnaN
    @Zachary-Lowell-0 thanks.
  • External pwm ESC questions

    Unsolved esc
    3
    0 Votes
    3 Posts
    2k Views
    Alex KushleyevA
    @mkriesel , a few tips.. I suspect FETtec ESC is using a pretty accurate xtal or accurate RC oscillator, so you should not need to calibrate the ESC You can check the current calibration by using QGC to control the individual motors to see at which command they start up and make sure that is very close to the same (typically around 1000us or a bit more) Additionally, you can spin up each motor with propeller at certain % power, lets say 20% or 30% and using an optical tachometer (RPM meter) to measure the speed of each motor Those are some sanity checks you can do without being able to calibrate and without having any ESC telemetry. Regarding the ESC PWM range, the procedure is documented for VOXL2 IO board : https://docs.modalai.com/voxl2-io-user-guide/#how-to-perform-esc-calibration -- please go over that and make sure you did it correctly. Alex
  • 0 Votes
    3 Posts
    2k Views
    Eric KatzfeyE
    @박지현 Unfortunately, for Ardupilot, our ESCs are only supported with UART interface when using the VOXL 2 / VOXL 2 mini as the flight controller. When using Flight Core v2 that is not supported.
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    4 Views
    No one has replied
  • EM9291 eSIM profile

    Unsolved cellular
    1
    0 Votes
    1 Posts
    570 Views
    No one has replied