Skip to content
  • ROS2 support

    Unsolved VOXL SDK and Software ros
    2
    2 Votes
    2 Posts
    1k Views
    T
    @atilla-bleda At least for VOXL Flight drones (I haven't used VOXL2), the voxl-mpa-to-ros bridge is based on ROS indigo, which means that you're going to have to implement a ROS bridge to go from your ROS2 to their ROS1 if you want to use mpatoros. That said, if you are accessing the MPA named pipes directly (or if you want to update their voxl-mpa-to-ros, which they've provided source code to), you won't need the ROS bridge and can use ROS2 directly. You can run MAVROS within ROS2 (it communicates over UDP to Mavlink). So really you just need a replacement for mpatoros or design your system to not depend on any of the MPA stuff. To run ROS2 on the drones themselves, you'll have to do a docker pull ros and setup a docker image that includes ROS2. Then either use a combination of network traffic (MAVROS via UDP) and the -v flag in docker (to import the MPA pipes) to try to get around using any ROS1 infrastructure provided by modalAI. In the worst case scenario, you may have to update the voxl-mpa-to-ros bridge. We don't use ROS2 because it's still buggy, but we did throw away the roskinetic image that ModalAI suggests using and rolled our own rosnoetic docker image, and life is much sweeter.
  • 0 Votes
    2 Posts
    1k Views
    TjarkT
    @ModalAI could you answer this question?
  • 0 Votes
    4 Posts
    2k Views
    A
    @tpavlic Thank you, glad it helped!
  • voxl_mpa_to_ros

    Unsolved VOXL SDK and Software ros
    7
    0 Votes
    7 Posts
    2k Views
    wilkinsafW
    @hedd apologies as I was OOO for a few days. Feel free to send me an email at andrew.wilkins@ascendengineer.com I would like to better understand what you are attempting to accomplish. It should not matter what VOXL version you are on.
  • 0 Votes
    5 Posts
    2k Views
    Tamas Pal 0T
    @Chad-Sweet @modaltb what should be the fcu url for the updated mavlink server for mavros connection? Please help me to fix this
  • MAVROS/C++ tutorial

    Unsolved VOXL SDK and Software ros
    2
    1 Votes
    2 Posts
    2k Views
    T
    Apologies. I actually have the simulator running on ROS1 Melodic.
  • 0 Votes
    1 Posts
    742 Views
    No one has replied
  • 0 Votes
    4 Posts
    2k Views
    Tamas Pal 0T
    @modaltb Any suggestion ?
  • What are my options for ROS support on VOXL?

    Unsolved VOXL SDK and Software ros
    10
    0 Votes
    10 Posts
    3k Views
    Ed SutterE
    @Alex-Gardner Ok, thanks much for running that. Since it built clean for you, that made it clear that there was something bad about my environment (the whole reason I'm down this rabbit hole!). Anyway, my typical configuration is to ssh into my Linux machine from a W10 box using Cygwin/SSH. Apparently something in the build.sh script doesn't like that; hence my failures. When I build directly through the console of that Linux machine the build completes successfully. Sorry for the confusion, and thanks to all for the responses.
  • 0 Votes
    3 Posts
    2k Views
    R
    Thanks for the answer, yes I already looked into the code. I was just wondering why the servers timestamp differs from the system timestamp. But then I will change the node accordingly.
  • Subscribe to voxl_mpa_to_ros topics

    Unsolved General Questions ros
    5
    0 Votes
    5 Posts
    2k Views
    ?
    @Isabella-Yu, If there is no tflite_data pipe, you may be using a version of voxl-tflite-server that does not have the ai_detection_t added yet. This feature was added in v0.2.0, so make sure you are using the latest available version!
  • ROS support for VOXL2

    Unsolved VOXL SDK and Software ros
    3
    0 Votes
    3 Posts
    2k Views
    Jeff DelauneJ
    Thank you Alex!
  • m500 ROS 2 Support

    Unsolved VOXL SDK and Software ros
    5
    1 Votes
    5 Posts
    1k Views
    Alex KushleyevA
    I just tried this real quick on VOXL1 and indeed there is an issue related to pty on PC: docker pull arm64v8/ros:rolling-ros-core docker image save arm64v8/ros:rolling-ros-core | gzip > rolling-ros-core-arm64v8.tar.gz adb push rolling-ros-core-arm64v8.tar.gz /data/ on VOXL1: adb shell cd /data docker load < rolling-ros-core-arm64v8.tar.gz cd /home/root mkdir ros2 cd ros2 docker run -it --rm --privileged -v `pwd`:/home/user -w /home/user arm64v8/ros:rolling-ros-core #now inside docker container apt-get update apt install python3-colcon-common-extensions then follow example to set up a demo project : https://roboticsbackend.com/ros2-launch-file-example/ run (inside docker container) colcon build Error: stdout_descriptor, stdout = pty.openpty() File "/usr/lib/python3.10/pty.py", line 34, in openpty master_fd, slave_name = _open_terminal() File "/usr/lib/python3.10/pty.py", line 64, in _open_terminal raise OSError('out of pty devices') OSError: out of pty devices --- Failed <<< my_robot_bringup [0.21s, exited with code 1] Summary: 0 packages finished [3.72s] 1 package failed: my_robot_bringup 1 package had stderr output: my_robot_bringup out of pty device After doing a quick search, cannot figure it out. It is probably related to very old docker version on VOXL1.. Not sure if anything can be done..
  • ToF sensor

    Unsolved General Questions ros tof
    29
    1
    0 Votes
    29 Posts
    9k Views
    modaltbM
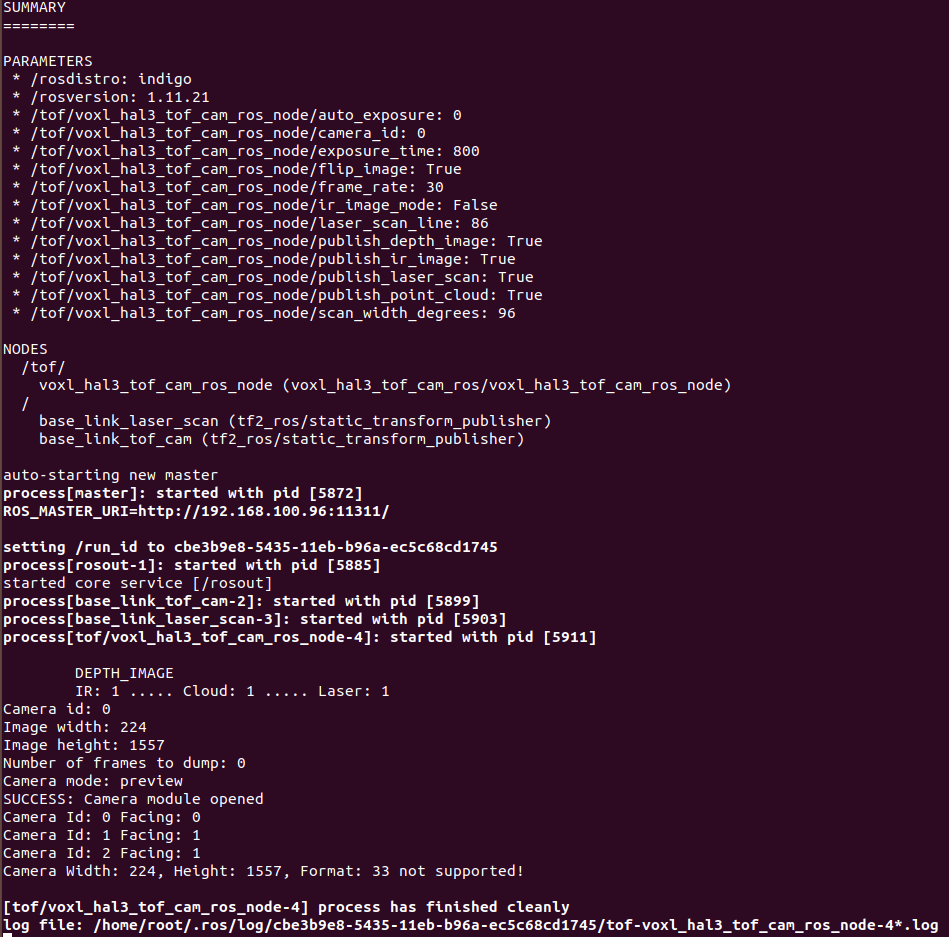
    Hi @gauravshukla914 , Thanks for the help with this. We've released a new beta version of the voxl-hal3-tof-cam-ros that supports auto detection of ToF and defaults the persist.camera.modalai.tof setting properly. It will be in out next voxl-suite release, but is available from our dev channel here if you are interested in using this link The updated readme is here. Thanks!
  • Failed to start Stereo Camera Nodelet

    Unsolved General Questions ros camera
    12
    0 Votes
    12 Posts
    3k Views
    K
    nothing else has changed.