Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • GPS not working

    Unsolved sentinel
    49
    1
    0 Votes
    49 Posts
    31k Views
    Eric KatzfeyE
    @Captain-7th Please check the new forum post where you ask all these questions again.
  • Starling HITL no serial port data or connection made

    Unsolved starling
    4
    0 Votes
    4 Posts
    911 Views
    Eric KatzfeyE
    @JoeAR_21 I would just buy something like this: https://www.adafruit.com/product/954?gad_source=1&gclid=CjwKCAjwyo60BhBiEiwAHmVLJQuZ-9b9QJJtpK_PN6k5qN0jQMigyLn_nbWc5deXCZ8ZnSInlYXwrhoCxZAQAvD_BwE
  • Considerate VIO drift (z-axis) in Starling V2.

    Unsolved starling
    7
    2
    0 Votes
    7 Posts
    3k Views
    James StrawsonJ
    @Jetson-Nano In SDK 1.2.0 we did start pushing the default config of voxl-mapper a big harder with smaller voxl sizes, longer ray lengths, and double the UI update rate to better complement the newer TOF sensors on the Starling 2. Part of this update was also to lock some of the heavier parts of the mapper processing to cores 4,5,6 to make sure VIO wasn't affected too much. However, if you are still seeing a difference in VIO performance between mapper being on and off then there may still be some optimization to be done. Just to confirm you are seeing worse VIO performance when mapper is enabled, correct? If so, please try increasing the voxl_size parameter in /etc/modalai/voxl-mapper.conf from the default 0.1 to 0.25, and set the cpu into performance mode on bootup by changing the normal_cpu_mode field to "performance" in /etc/modalai/voxl-cpu-monitor.conf. The map will be very course and ugly with such a big voxel size but I'm just curious if the power cpu use helps resolve the issue. For reference, here is the commit history for voxl-mapper showing the recent tweaks for SDK 1.2 and newer that turn up some of the knobs.
  • Starling 2 doesn't detect camera after flashing new SDK

    Unsolved starling
    4
    3
    0 Votes
    4 Posts
    914 Views
    tomT
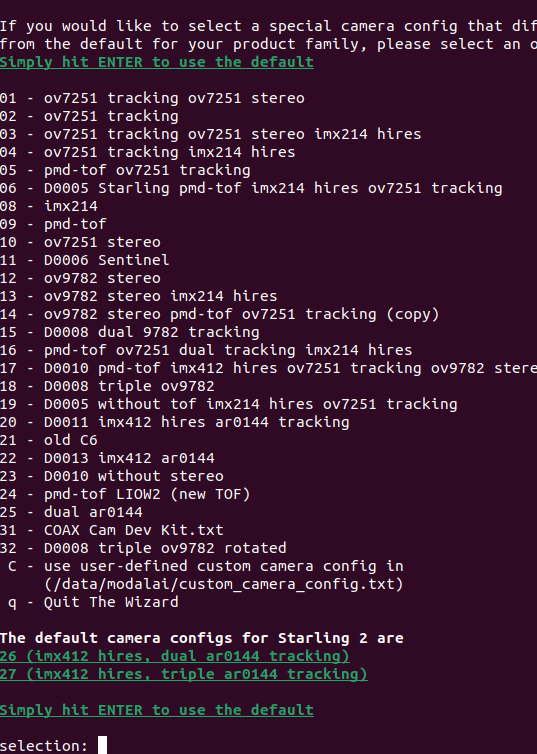
    @Judoor-0 Yep exactly, if the drone is already in fastboot before running the flashing script it can't identify which board it is (M0054-1, M0054-2, M0104-1) so it has to give you all options. This time since it has ADB access it can be smarter and just ask you the possible options it knows are supported for your hardware
  • Native Barometer and GPS height estimation bad

    Unsolved px4-dev-kit
    5
    0 Votes
    5 Posts
    2k Views
    VinnyV
    HI @Jeffrey-Mao Another consideration for baro is active airflow. We typically provide a "cap" on our baros in our drones or flight-decks to ensure it is not exposed to sunlight (as Eric stated) but also active airflow which can show up like air pressure noise. Our 3D models repository has a 3D file of this cap, in this case for FlightCore to give you an example: https://storage.googleapis.com/modalai_public/modal_drawings/Flight_Core_Barometer_Cap.STEP Hope this helps.
  • 0 Votes
    1 Posts
    801 Views
    No one has replied
  • voxl-mapper setting

    Unsolved starling
    1
    3
    0 Votes
    1 Posts
    498 Views
    No one has replied
  • External API to interact with voxl-mapper

    Unsolved starling
    1
    0 Votes
    1 Posts
    346 Views
    No one has replied
  • Flir Lepton on Starling 2

    starling
    2
    0 Votes
    2 Posts
    706 Views
    ModeratorM
    The Flir Lepton feature is still in development. Please check future release notes in VOXL SDK for updates on availability.
  • Collision Prevention not working with external FC

    Unsolved starling
    1
    0 Votes
    1 Posts
    447 Views
    No one has replied
  • Plan to a point

    Unsolved starling
    1
    0 Votes
    1 Posts
    403 Views
    No one has replied
  • Binding of Ghost Atto controller

    Unsolved starling
    2
    0 Votes
    2 Posts
    479 Views
    tomT
    @Stefano-Accolla https://docs.modalai.com/orqa-ghost/
  • Quectel 5G Modem seg faults

    Unsolved sentinel
    7
    0 Votes
    7 Posts
    1k Views
    P
    @tom Well that's embarrassing, corrected and attached, n78 SA. Thank you.
  • check-calibration "Detected Missing Calibration Files"

    Unsolved starling
    3
    1
    0 Votes
    3 Posts
    711 Views
    tomT
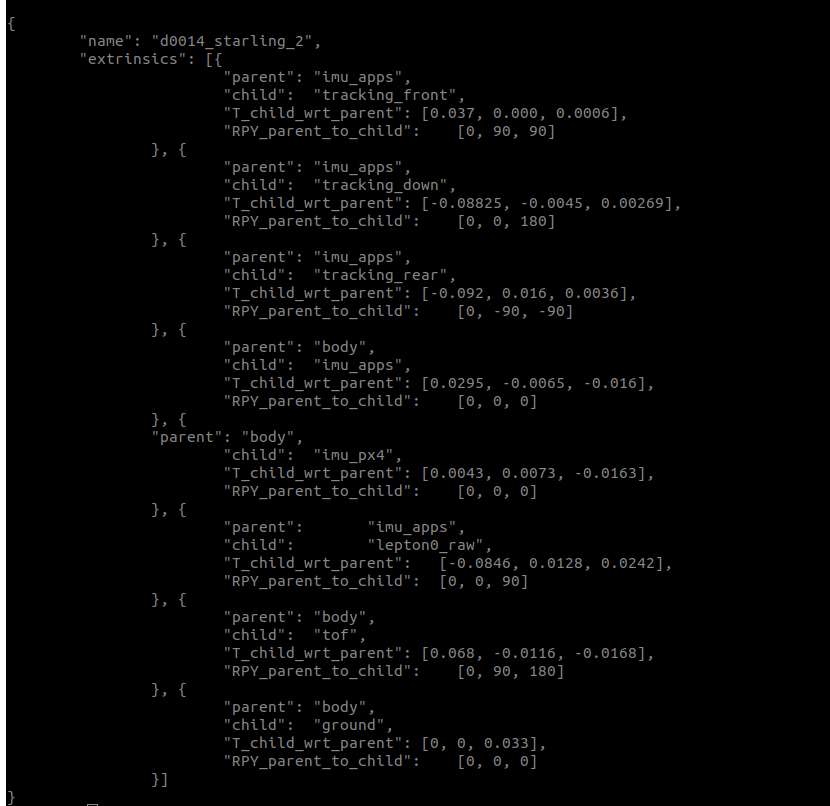
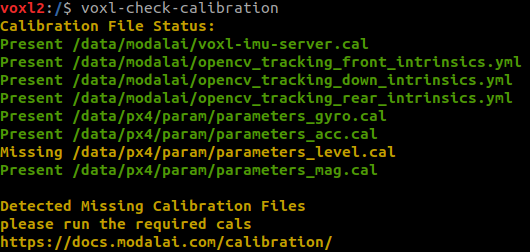
    @Stefano-Accolla Not a major issue, you'll just have to calibrate horizon via QGroundControl: https://docs.px4.io/main/en/config/level_horizon_calibration.html As for the Ghost Atto, please open a separate thread for that
  • Outdoor navigation problem

    Unsolved rb5
    22
    0 Votes
    22 Posts
    7k Views
    Amin BassiriA
    @Eric-Katzfey ok, Thanks, we tested GPS M10 and the problem solved.
  • "Serial Port Closed!" and other HITL Errors

    Unsolved starling
    17
    8
    0 Votes
    17 Posts
    4k Views
    L
    @Eric-Katzfey Issue is mostly resolved. There were two main errors to fix. The first was that the cable that I was using needed to have its RX and TX wires swapped as Vinny pointed out. The second was that Docker Desktop needed to be uninstalled and replaced with only the core Docker CE Engine. After doing this, the HITL seems to be up and running on the alternate Linux computer I tested with. On the original computer, the "Serial port closed error" is no longer present although there does seem to be a graphics issue when attempting to run the Gazebo image with graphics. [image: 1718148966860-8d0e6ab0-9969-4fb4-853c-4879b46992bf-image.png] Once this is fixed I think it should be all ready to perform simulations.
  • M500 Magnetometer Issues

    Unsolved m500
    7
    0 Votes
    7 Posts
    2k Views
    Eric KatzfeyE
    @spitkowsky For others who are seeing similar issues, the magnetometer rotation isn't being specified correctly in the newer SDK. The rotation should be set to the value 10. If you are seeing these issues try setting the CAL_MAG0_ROT parameter to 10.
  • M500 VOXL connectivity issues

    Unsolved m500
    13
    0 Votes
    13 Posts
    3k Views
    VinnyV
    @tom @spitkowsky I'm wondering if this may be a HW issue on the VOXL board. Possible the USB or the USB VBUS control is now no longer working correctly, thus not allowing the MH modem USB hub to enumerate (eth0 never seems to be detected, implying a USB hub path issue, but on the VOXL side since the MH HW is known good on another system). https://docs.modalai.com/expansion-design-guide/#modalai-usb-hub-example This may be cause for an RMA.
  • m500 is not connecting to QGC or my DX6e controller

    Unsolved m500
    17
    1
    0 Votes
    17 Posts
    3k Views
    S
    Thank you for the info! After messing with it some more, I think it might have to do with the batteries I am using. Because the drone is currently turned on and my laptop is connected to the drone's wifi, but it is no longer connecting to QGC, even with a micro USB connection too. The battery I am using is a "14.8V, 45C, 4S1P, 3300, 4 Cell battery". And it will only read on the QGC when it is around 30-50%. Any ideas what I should try next?
  • Can't arm the Sentinel Drone.

    Unsolved sentinel
    6
    0 Votes
    6 Posts
    1k Views
    Eric KatzfeyE
    @Emon_dey said in Can't arm the Sentinel Drone.: Horizontal gps error is too high What happens if you set the parameter EKF2_GPS_CHECK to 1?