Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Libvoxl_io with mavlink

    Unsolved
    15
    1
    0 Votes
    15 Posts
    3k Views
    SHofmeesterS
    Hi @Alex-Gardner, We switched from using voxl-cross and using adjusted .sh files from voxl-vision-px4, to placing our script inside libvoxl_io and adjusting the install_deps and CMakeLists.txt file. Then we can use the 32bit compilers from libvoxl_io, instead of the 64bit compiler from voxl-vision-px4 (we are not really using voxl-vision-px4 as a whole, we just copied some files for dependencies en building). We added the libraries to install-deps, except modal-cv (because we don't need it) and that works. (Libvoxl_io is not among the installed libraries, because we placed our script inside libvoxl_io itself) [image: 1659351485197-3a3c4a0b-8e8f-427e-8390-7a8881e8d6eb-image.png] But when we try to build it, it raises the following error: [image: 1659351624836-f847627f-65ab-4918-909b-42cc143e89a8-image.png] In /usr/include there is a file called modal_pipe_common.h, but the error remains. [image: 1659351796921-8f0338fa-b256-4fe8-b463-ef6d68f1c691-image.png] I also don't understand why the path in the error is: usr/include/c_library_v2/../modal_pipe_server.h, and not: usr/include/modal_pipe_server.h Is placing our script inside libvoxl_io like this the right path? How can we fix the error?
  • APMv3 Schematic?

    Unsolved
    3
    0 Votes
    3 Posts
    705 Views
    Steve TurnerS
    Thanks Vinny -- we'll keep an eye out for the email!
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    2 Views
    No one has replied
  • USB3 port on RB5

    Unsolved
    2
    0 Votes
    2 Posts
    495 Views
    ?
    Hey @andyh, We have a USB3 cable with a 10 pin connector that is compatible with the 5G modem carrier board listed here.
  • VOXL Flight Deck Kit Power Supply...

    Unsolved
    6
    0 Votes
    6 Posts
    687 Views
    Ed SutterE
    Got it, thanks to both. Sorry for the paranoia!
  • Install voxl sdk on RB5

    Unsolved
    4
    0 Votes
    4 Posts
    827 Views
    Dong LiuD
    @Chad-Sweet Thank you!
  • Running GPS on voxl2

    Unsolved
    2
    0 Votes
    2 Posts
    872 Views
    Eric KatzfeyE
    @Zachary-Lowell Yes, it is in voxl-px4.config. The gps start line has a -d parameter to specify the serial port. But J19 is the standard place to attach GPS so you can stick with what is already there. But please note that Holybro made changes to the pixhawk 4 GPS unit a few months ago and VOXL 2 only works with the newer updated version. If you have an older unit it will not work.
  • Connecting an external sensor to VOXL

    Unsolved
    3
    0 Votes
    3 Posts
    520 Views
    Niket ShahN
    Thank you so much for the response Chad!
  • Error in sending trajectory to voxl-vision-px4

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    H
    @Matthew-Booker will do that, thank you!!
  • Warning PX4 disconnected from UART

    Unsolved
    11
    0 Votes
    11 Posts
    3k Views
    J
    @modaltb Hi there! May I ask how the loopback test is conducted? How do you get the github file to run on VOXL? Thank you!
  • Position Mode Rejected

    Unsolved position-mode uart px4 ekf2
    2
    0 Votes
    2 Posts
    2k Views
    James StrawsonJ
    Which version of PX4 are you running on the Pixhawk and do you have a magnetometer connected? EKF2 is generally unhappy about about starting without a magnetometer in PX4 1.11 so we patched the PX4 firmware for Flight Core to get around this. In PX4 1.12 and newer the following PX4 parameter can be set to allow EKF2 to allow position mode without a GPS/Mag ## disable mag SYS_HAS_MAG 0 EKF2_MAG_TYPE 5
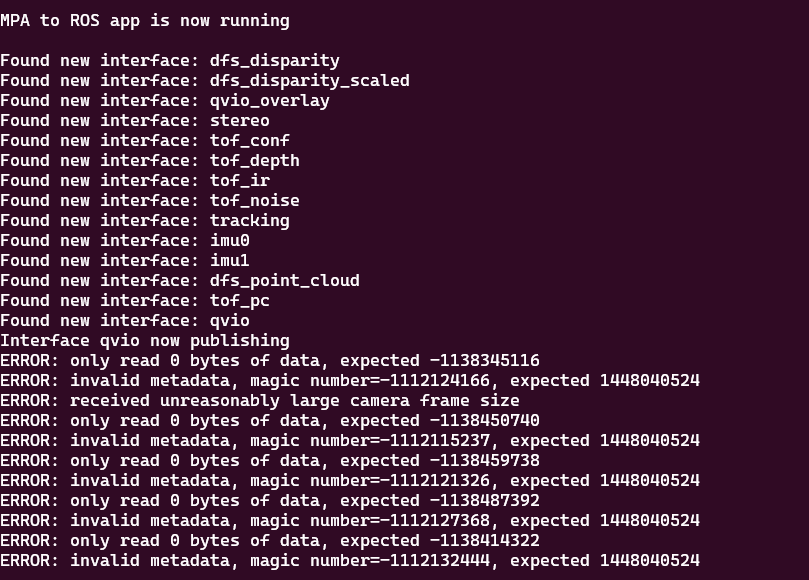
  • ERROR: received unreasonably large camera frame size

    Unsolved
    3
    1
    0 Votes
    3 Posts
    736 Views
    H
    @Chad-Sweet No, I didn't try changing any code Should I try reinstalling voxl-mpa-to-ros ?
  • timestamps for ros messages in voxl_mpa_to_ros_node

    Unsolved time ros voxl-mpa-tools
    3
    0 Votes
    3 Posts
    2k Views
    R
    Thanks for the answer, yes I already looked into the code. I was just wondering why the servers timestamp differs from the system timestamp. But then I will change the node accordingly.
  • Running voxl-reset-qvio in mid-flight

    Unsolved
    4
    0 Votes
    4 Posts
    611 Views
    H
    That depends I guess. If I merely use the drone for indoor navigation purely by tele-oportation (as opposed to waypoint navigation) then I'm guessing resetting qvio mid flight while moving (and causing a shift in the origin of the reference frame) wouldn't really matter. Unless I'm mistaken, PX4 uses a velocity controller while moving in Position flight mode. Only when it is stationary does PX4 uses it's position controller (and velocity controller) and that's when a reset of the reference frame origin will really screw things up. Would love to hear from the devs though
  • ROS2-PX4 Bridge on RB5 Drone

    Unsolved
    2
    0 Votes
    2 Posts
    440 Views
    tomT
    @hs775 The instructions here: https://docs.modalai.com/voxl2-px4-build-guide/ are meant to be run on your PC, not the drone.
  • Subscribe to voxl_mpa_to_ros topics

    Unsolved ros
    5
    0 Votes
    5 Posts
    2k Views
    ?
    @Isabella-Yu, If there is no tflite_data pipe, you may be using a version of voxl-tflite-server that does not have the ai_detection_t added yet. This feature was added in v0.2.0, so make sure you are using the latest available version!
  • voxl-vision-px4 not working

    Unsolved
    4
    2
    0 Votes
    4 Posts
    897 Views
    SHofmeesterS
    Hi @Alex-Gardner, We resolved the issue using this forumpost: https://forum.modalai.com/topic/1050/position-flight-is-not-available-after-firmware-update?_=1658251944919 Thanks for the help
  • PX4 UART Warning

    Unsolved
    4
    0 Votes
    4 Posts
    891 Views
    Steve TurnerS
    @DarkKnightCH to followup on this -- a reflash of the VOXL Flight Core solved the problem for me. It was in an unresponsive state and I was unable to change parameters or talk to the Flight Core until I reflashed the current release of firmware from ModalAI.
  • voxl-tflite-server abort

    Unsolved
    11
    0 Votes
    11 Posts
    2k Views
    Isabella YuI
    @Matt-Turi Yep, turns out switching to wall power fixed it. My battery power was too low. Thanks!
  • ALTİTUDE MODE

    Unsolved
    1
    0 Votes
    1 Posts
    543 Views
    No one has replied