Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Micro DDS Failure

    Unsolved
    1
    0 Votes
    1 Posts
    444 Views
    No one has replied
  • IMX214 min exposure time

    Unsolved
    5
    0 Votes
    5 Posts
    986 Views
    Alex KushleyevA
    @stephengerdts , in majority of cameras, the exposure time of the whole frame is set as a multiple of a specific number, let's call it T0. T0 is the minimum exposure of the whole frame and you can set any other exposure values, which will get rounded to a multiple of T0 ( K*T0 ). This T0 number is actually exactly equal to something called the Line Readout Time, which is the time it takes for the camera hardware to sample, process and send out a single line of pixels. This may be a little confusing, but if you think about how rolling shutter camera works, it "reads out" one line at a time (it cannot store the whole image in memory, so exposure and read out of each line are staggered). Please take a look at this link that shows how exposure time relates to readout time : https://www.researchgate.net/figure/Timing-diagram-of-the-CMOS-sensor-array-shown-in-Fig-2-The-readout-times-of-the_fig2_3328923 I believe that in order to simplify the exposure timing logic, the cameras then use the readout time as a unit of increment for the exposure time. So, the minimum exposure time reported by the voxl-camera-server is the minimum exposure time for the whole frame, which is also equal to the readout time of a single line In case of IMX214, the line readout time is 10.449us which is also the increment for adjusting exposure. The logic inside the camera framework will take the desired exposure time from the user / voxl-camera-server and then set the correct integer number of exposure in terms of "lines" (not microseconds) in order to achieve the correct exposure duration in units of time. Alex
  • Imu_apps Gyro Error on VOXL2

    Unsolved
    9
    2
    0 Votes
    9 Posts
    2k Views
    modaltbM
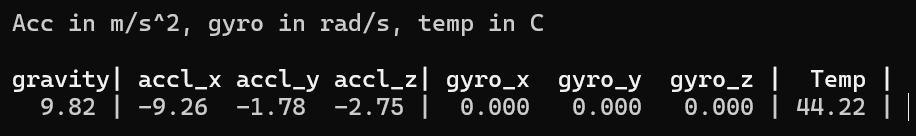
    OK all shipped ok. Above looks good with flat on table test results... Here's factory test data which shows OK: [image: 1721926383343-0a21b33e-3335-48ba-b756-2a84a9b9f6f9-image.png] 2024-05-03T22:01:18.648Z -- {"desc": "IMU1 - APPS PROC - OK", "GYRO_X": 1.001, "GYRO_Y": 0.998, "GYRO_Z": 0.994, "ACCL_X": 0.99, "ACCL_Y": 0.987, "ACCL_Z": 0.957, "FAILURES": []} 2024-05-03T22:01:19.361Z -- {"desc": "IMU0 - SLPI ACCEL - OK", "ACCL_X": 0.11492, "ACCL_Y": 0.20016, "ACCL_Z": 9.89428, "FAILURES": ""} 2024-05-03T22:01:19.960Z -- {"desc": "IMU0 - SLPI GYRO - OK", "GYRO_X": 0.02435, "GYRO_Y": 0.03108, "GYRO_Z": 0.00174, "FAILURES": ""} If it passes flat on table I think things are OK and it's a result of expecting certain tests to run in this flat orientation during factory test.
  • Accedently replaced ./bash with adb push command

    Unsolved
    2
    0 Votes
    2 Posts
    391 Views
    tomT
    @QuiroJ6427 I'd recommend just downloading the latest SDK from downloads.modalai.com and installing it. The latest for M500 should be SDK 1.2.0. 0.9 is quite old at this point so this will be a nice upgrade regardless
  • MSU-M0107 IMX412 I2C address selection

    Unsolved
    1
    1
    0 Votes
    1 Posts
    450 Views
    No one has replied
  • Companion computer to VOXL 2 over UART

    Unsolved
    2
    0 Votes
    2 Posts
    730 Views
    tomT
    @jonathankampia You could run UART based comms like an external flight controller on that UART: https://docs.modalai.com/voxl2-external-flight-controller/ but no you couldn't connect a USB device there
  • Mismatching measures between VIO and Mavor local pose

    Unsolved
    1
    0 Votes
    1 Posts
    462 Views
    No one has replied
  • Voxl2: how to enable PCIe?

    Unsolved
    3
    0 Votes
    3 Posts
    627 Views
    J
    @modaltb Thanks for the response, Travis. My manager told me in the mean time, he is in contact with you regarding that topic already via mail. I think we'll focus on that, instead of having 2 communication channels
  • VOXL1 and 2 Environmental Testing Documents

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    J
    @Vinny That's really helpful information, thank you!
  • TOF rate only 5 or 15

    Unsolved
    2
    0 Votes
    2 Posts
    502 Views
    tomT
    @jameskuesel Support for more framerates was added in voxl-camera-server v1.9.3 Here is the commit it was added: https://gitlab.com/voxl-public/voxl-sdk/services/voxl-camera-server/-/commit/9a3f042ad607b968d452303dd108ced3cf2c4328 I recommend you update to the latest SDK
  • obstacle avoidance

    Unsolved
    9
    0 Votes
    9 Posts
    2k Views
    James StrawsonJ
    @rogerli vibration and lead to the lenses rotating. I often use a dab of hot-glue to hold the lens in place after focusing. On the new Starling 2 and Starling 2 Max drones we now use a clamping ring around the entire camera and lens assembly to lock them in place.
  • VOXL Mapper

    Unsolved
    2
    0 Votes
    2 Posts
    458 Views
    tomT
    @Prasanth-Kumar-Duba What hardware are you using? VOXL 1? VOXL 2? I'm guessing VOXL 1 based on the opkg reference. You can install voxl-mapper by doing the following: adb shell opkg install voxl-mapper
  • voxl-configure-vision-px4 does not exist

    Unsolved
    4
    0 Votes
    4 Posts
    566 Views
    tomT
    @Scott-Lobdell That would be great, thank you.
  • Flight core v2 ardupilot

    Unsolved
    3
    0 Votes
    3 Posts
    1k Views
    Andrew TridgellA
    see https://forum.modalai.com/topic/3640/ardupilot-on-voxl2
  • Vision Hub Issue

    Unsolved
    6
    0 Votes
    6 Posts
    2k Views
    James StrawsonJ
    @Kris I found and fixed a bug in voxl-camera-server that seems to be the culprit. I flashed my seeker with SDK1.2.0 and sideloaded the following voxl-camera-server with the bugfix to re-enable ingestion of TOF data into voxl-vision-hub http://voxl-packages.modalai.com/dists/apq8096/dev/binary-arm64/voxl-camera-server_1.9.7_202407111658.ipk Note VOA simply does not work in the default PX4 acceleration-based position mode so MPC_POS_MODE needs to be set to 0 (velocity control) as done by the voa_enable px4 param helper file here: https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-px4-params/-/blob/dev/params/v1.14/voa_helpers/voa_enable_indoor.params?ref_type=heads
  • VOXL 2 Mini support for image sensor

    Unsolved
    4
    0 Votes
    4 Posts
    984 Views
    modaltbM
    @Memmed-Shamurov we have draw.io based drawings here if you want to try to mock something up for review, we can take a look: https://gitlab.com/voxl-public/support/drawings VOXL2 Mini based drawings here: https://gitlab.com/voxl-public/support/drawings/-/tree/master/M0104
  • VOXL 2 mini support for flir boson

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    modaltbM
    @Memmed-Shamurov it claims USB Video Support so it 'should' work although we've not tried this exact one.
  • VOXL2 takeoff and land script

    Unsolved
    2
    0 Votes
    2 Posts
    594 Views
    ModeratorM
    @Gary-Holmgren Check out the AprilTag Relocalization page Basically, every time an AprilTag is viewed, the position is updated to reflect that tag as an anchor. So, it's not precision landing as much as position refinement. You then land at the desired position which should be more accurate due to the position refinement with the fiducial marker We haven't looked at the MAVSDK in a while, is there a specific error you're running into?
  • VOXL2 WIFI KIT mismatch

    Unsolved
    7
    1
    0 Votes
    7 Posts
    1k Views
    VinnyV
    Great @jacob-yaacubov. Sorry for the issue overall, but glad we made it right.
  • HITL setup for VOXL2 + Flight Core V2 Help

    Unsolved
    2
    0 Votes
    2 Posts
    535 Views
    ModeratorM
    @Gary-Holmgren Hi Gary, we have not thought to try that setup as HITL is typically used to develop the lower level flight controller. What are you trying to achieve?