Skip to content
  • How to record high resolution camera frames/videos?

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    7
    0 Votes
    7 Posts
    2k Views
    A
    @afdrus instead of rebooting, you can restart the server with: systemctl restart voxl-camera-server
  • Extra LEDs and Buzzer control from VOXL 2 J3/J5

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    6
    0 Votes
    6 Posts
    1k Views
    R
    Hi @Vinny , Thanks for your information, I already know current GPIO status.
  • 0 Votes
    3 Posts
    734 Views
    D
    @Chad-Sweet Understood and thanks.
  • ModalAI uORB topic file handle location

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    12
    0 Votes
    12 Posts
    3k Views
    D
    @Eric-Katzfey Thanks again Eric. Looks like that was the part I was missing. I'll take a look.
  • Could MicroSD card support in VOXL2 system image?

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    5
    0 Votes
    5 Posts
    971 Views
    D
    @Vinny Thanks for your comments. Actually we have sent the block diagram to Chad for review. Once we have done the schematic, we will send to ModalAI for review.
  • ADB Connecting Issue with VOXL2 Board

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    35
    0 Votes
    35 Posts
    8k Views
    VinnyV
    Hi @dlee Can you please double check SW2. From that photo you posted, it seems as if it may stay be in the "ON" position, which would keep it in "EDL" mode and show up as "QUSB_BULK..." instead of an ADB debug device. Please be sure to follow this step carefully when performing QDL updates: https://docs.modalai.com/voxl2-qdl/ [image: 1676437032805-e7393327-f780-48b8-8b20-4c18a36639ff-image.png] We do not have many HW failures on Voxl2 in the field from routine use, so to have one so soon is surprising. However, if you are confident you are following all instructions and still wish to RMA it, we'll test it again to check for all basic functionality and debug the root cause of the failure, if any, and prompt you for further actions. Thanks!
  • Tflight server multiple model

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    736 Views
    Tamas Pal 0T
    @Matt-Turi Thanks !!
  • 0 Votes
    2 Posts
    694 Views
    modaltbM
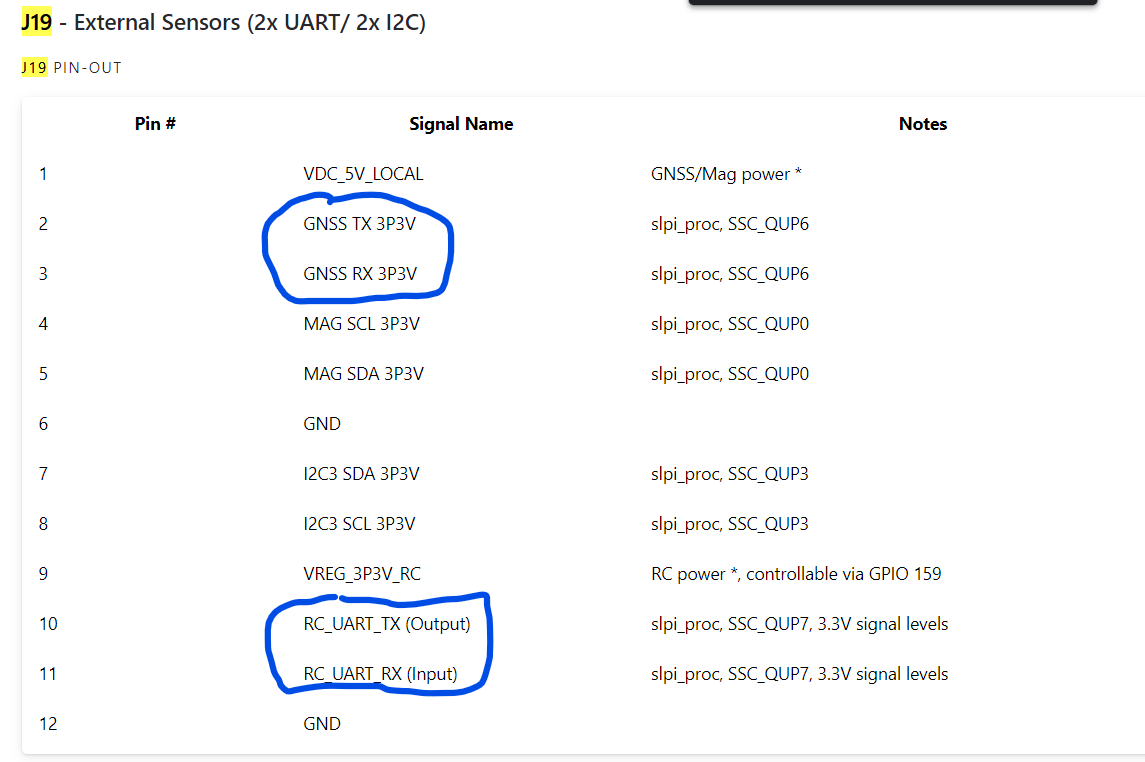
    Hi Dan, We haven't tried this yet, and we don't have a pre-built solution that we can reference, but it should be doable. PX4 on VOXL2 is setup mainly to use the DSP UART right now, which are setup for an ESC and a GNSS (GPS) unit. In theory, the gimbal driver would just need to use one of these ports, but I have a hunch there's some coding involved, and it would take over one of the two UART ports above which might not be OK for you. We aren't doing this yet, but there are UARTs on the applications processor side that could be used via an add-on board for this use case likely. So, to sum it up, doable, but not out of the box from our docs at this point.
  • IMX412 and OV9782 not detected by VOXL2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    0 Votes
    4 Posts
    546 Views
    modaltbM
    Hi @Aks , please refer to other thread where I have some info, thanks!
  • Microhard support

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    21
    0 Votes
    21 Posts
    6k Views
    VinnyV
    Hi @Chase-Riley Your best bet might be to start a new thread, that will help ensure you get more eyes on it for the best person on our side to help you along! Thanks!
  • 0 Votes
    7 Posts
    1k Views
    D
    @modaltb Thanks for your info.
  • 0 Votes
    3 Posts
    438 Views
    wilkinsafW
    Resolved
  • GPS module setup on VOXL2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    2
    2
    0 Votes
    2 Posts
    470 Views
    Chad SweetC
    It is likely that driver is not supported. You may need to add it to the VOXL 2 PX4 build if you want to use the integrated flight controller. It may be easier to use an external flight controller if you want to use a broader set of inputs https://docs.modalai.com/voxl-px4-developer-guide/
  • Error while running voxl-vision-px4 on voxl2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    3
    0 Votes
    3 Posts
    656 Views
    A
    @James-Strawson I am having the same error while transitioning from staging to stable branch. The voxl-vision-px4 is enabled but I am not able to make it run again
  • DFS for obstacle avoidance

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    1
    1 Votes
    1 Posts
    470 Views
    No one has replied
  • No option for dual TOF sensor on voxl2

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    9
    0 Votes
    9 Posts
    2k Views
    A
    Because on my voxl2 it seems that neither this configuration nor the 2TOF2 configuration is possible... [image: 1680703429182-screenshot-from-2023-04-05-16-02-47.png]
  • VOXL2 Opencv with Opencl

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    4
    1 Votes
    4 Posts
    1k Views
    M
    On this note. Does anyone know what happened to the hellocl repo? The link on the Build Applications for VOXL, VOXL 2 and RB5 Flight page in the docs does not lead anywhere anymore.
  • ToF sensor and VOA

    Unsolved VOXL 2 and VOXL 2 Mini voxl-2
    9
    2
    0 Votes
    9 Posts
    2k Views
    S
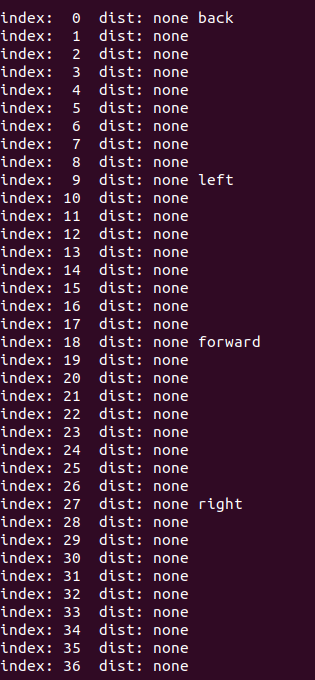
    @James-Strawson Hii , I am also getting the same issue . Kindly look at the following details . I have defined tof in my extrinsics.conf file as given below: parent: body child: tof T_child_wrt_parent: 0.070 0.024 -0.029 RPY_parent_to_child: 0.0 90.0 90.0 R_child_to_parent: 0.000 -0.000 1.000 1.000 0.000 -0.000 -0.000 1.000 0.000 when i run voxl-vision-hub -s i got the following slice 0 dist none back slice 1 dist none slice 2 dist none slice 3 dist none slice 4 dist none slice 5 dist none slice 6 dist none slice 7 dist none slice 8 dist none slice 9 dist none left slice 10 dist none slice 11 dist none slice 12 dist none slice 13 dist none slice 14 dist none slice 15 dist none slice 16 dist none slice 17 dist none slice 18 dist none forward slice 19 dist none slice 20 dist none slice 21 dist none slice 22 dist none slice 23 dist none slice 24 dist none slice 25 dist none slice 26 dist none slice 27 dist none right slice 28 dist none and in my vision-hub-conf file i have the folloeing set up: "en_vio": true, "vio_pipe": "qvio", "secondary_vio_pipe": "ov", "vfc_vio_pipe": "ov", "en_reset_vio_if_initialized_inverted": true, "vio_warmup_s": 3, "send_odom_while_failed": true, "horizon_cal_tolerance": 0.5, "en_hitl": false, "offboard_mode": "figure_eight", "follow_tag_id": 0, "figure_eight_move_home": true, "robot_radius": 0.300000011920929, "collision_sampling_dt": 0.1, "max_lookahead_distance": 1, "backtrack_seconds": 60, "backtrack_rc_chan": 8, "backtrack_rc_thresh": 1500, "wps_move_home": true, "wps_stride": 0, "wps_timeout": 0, "wps_damp": 1, "wps_vfc_mission": true, "wps_vfc_mission_loop": false, "wps_vfc_mission_to_ramp": 25, "wps_vfc_mission_to_kp": 0.10000000149011612, "wps_vfc_mission_cruise_speed": 1, "en_tag_fixed_frame": false, "fixed_frame_filter_len": 5, "en_transform_mavlink_pos_setpoints_from_fixed_frame": false, "vfc_rate": 100, "vfc_rc_chan_min": 980, "vfc_rc_chan_max": 2020, "vfc_thrust_ch": 3, "vfc_roll_ch": 1, "vfc_pitch_ch": 2, "vfc_yaw_ch": 4, "vfc_submode_ch": 6, "vfc_alt_mode_rc_min": 0, "vfc_alt_mode_rc_max": 0, "vfc_flow_mode_rc_min": 0, "vfc_flow_mode_rc_max": 0, "vfc_hybrid_flow_mode_rc_min": 0, "vfc_hybrid_flow_mode_rc_max": 0, "vfc_position_mode_rc_min": 0, "vfc_position_mode_rc_max": 2100, "vfc_traj_mode_rc_min": 0, "vfc_traj_mode_rc_max": 0, "vfc_yaw_deadband": 30, "vfc_vxy_deadband": 50, "vfc_vz_deadband": 150, "vfc_min_thrust": 0, "vfc_max_thrust": 0.800000011920929, "vfc_tilt_max": 0.43599998950958252, "vfc_yaw_rate_max": 3, "vfc_thrust_hover": 0.5, "vfc_vz_max": 1, "vfc_kp_z": 5.2899999618530273, "vfc_kd_z": 5.9800000190734863, "vfc_vxy_max": 3, "vfc_kp_xy": 0.63999998569488525, "vfc_kd_xy": 2.559999942779541, "vfc_kp_z_vio": 5.2899999618530273, "vfc_kd_z_vio": 5.9800000190734863, "vfc_kp_xy_vio": 3.2400000095367432, "vfc_kd_xy_vio": 3.9600000381469727, "vfc_w_filt_xy_vio": 10, "vfc_w_filt_xy_flow": 3, "vfc_vel_ff_factor_vio": 0.899999976158142, "vfc_xy_acc_limit_vio": 2.5, "vfc_max_z_delta": 3, "vfc_att_transition_time": 0.5, "vfc_stick_move_threshold": 30, "vfc_flow_transition_time": 1, "vfc_q_min": 10, "vfc_points_min": 7, "vfc_en_submode_announcement": 1, "vfc_disable_fallback": false, "vfc_traj_csv": "/data/voxl-vision-hub/traj.csv", "en_voa": true, "voa_upper_bound_m": -0.15000000596046448, "voa_lower_bound_m": 0.15000000596046448, "voa_memory_s": 1, "voa_max_pc_per_fusion": 100, "voa_pie_max_dist_m": 20, "voa_pie_min_dist_m": 0.25, "voa_pie_under_trim_m": 1, "voa_pie_threshold": 3, "voa_send_rate_hz": 20, "voa_pie_slices": 36, "voa_pie_bin_depth_m": 0.15000000596046448, "voa_inputs": [{ "enabled": false, "type": "point_cloud", "input_pipe": "dfs_point_cloud", "frame": "stereo_l", "max_depth": 8, "min_depth": 0.300000011920929, "cell_size": 0.079999998211860657, "threshold": 4, "x_fov_deg": 68, "y_fov_deg": 56, "conf_cutoff": 0 }, { "enabled": false, "type": "point_cloud", "input_pipe": "stereo_front_pc", "frame": "stereo_front_l", "max_depth": 8, "min_depth": 0.300000011920929, "cell_size": 0.079999998211860657, "threshold": 4, "x_fov_deg": 68, "y_fov_deg": 56, "conf_cutoff": 0 }, { "enabled": false, "type": "point_cloud", "input_pipe": "stereo_rear_pc", "frame": "stereo_rear_l", "max_depth": 8, "min_depth": 0.300000011920929, "cell_size": 0.079999998211860657, "threshold": 4, "x_fov_deg": 68, "y_fov_deg": 56, "conf_cutoff": 0 }, { "enabled": true, "type": "tof", "input_pipe": "tof", "frame": "tof", "max_depth": 6, "min_depth": 0.15000000596046448, "cell_size": 0.079999998211860657, "threshold": 3, "x_fov_deg": 106.5, "y_fov_deg": 85.0999984741211, "conf_cutoff": 125 }, { "enabled": false, "type": "rangefinder", "input_pipe": "rangefinders", "frame": "body", "max_depth": 8, "min_depth": 0.300000011920929, "cell_size": 0.079999998211860657, "threshold": 4, "x_fov_deg": 68, "y_fov_deg": 56, "conf_cutoff": 0 }], "voa_voa_memory_s": 1 } [image: 1768559497610-screenshot-from-2026-01-16-16-01-23.png]
  • 0 Votes
    2 Posts
    536 Views
    Tamas Pal 0T
    @Chad-Sweet any suggestion?