Skip to content
  • Controller not recognized in QGC

    Unsolved Development Drones m500
    13
    0 Votes
    13 Posts
    4k Views
    Evan DE
    @Eric-Katzfey Reinstalling px4 solved my problem, thanks for your help!
  • 0 Votes
    4 Posts
    2k Views
    VinnyV
    Hi @Ivan-Gambit Good questions. M0078 Tech Docs Reference: https://docs.modalai.com/usb-epxansion-with-fastboot-v2-datasheet/ Yes, if you have a Voxl or Voxl-Flight in an M500, you will need the M0078 PCB to expose the USB host port from J13. You will not use the provided MCBL-00009 in the M0078 kit. Yes, Voxl or Voxl-Flight J13 port was not designed with Doodle in mind, so you are best to use a splice direct from the power cable. The way to do this is as follows: Use the D+/D- and GND from the M0078 4-pin JST "J3" to the Doodle USB D+/D- and one GND [image: 1706645581587-af2cb12a-9843-46f2-b691-8db5c063c365-image.png] use the 5VDC and a GND from the Power Module to the Doodle 5V input and GND. In your case, you can remove the jumper from M0078 "J2" since you are not using any VBUS from the M0078 USB connector. If you remove the jumper on M0078 J2, that allows you to use a simple 4-pin JST to JST cable to the Doodle such as https://docs.modalai.com/cable-datasheets/#mcbl-00015 , or convert it to a breakout cable to connect to the Doodle (Sorry I do not know how to advise further since I am not familiar with the socketed versions) Note: Yes, we have that jumper on M0078 to provide an easy way to access the 5V from the power module, but we did also not design that jumper and the traces with Doodle in mind. It was more for devices needing 1A of USB VBUS, not 2A+ that Doodle requires. You can try it, but you may have limited range at the highest power modes, and most of our cables that you would then use are also 1A limited, so problems like voltage droops/sags may occur with that approach. The key thing in all of this is to make sure you have a common GND, and the return current for USB will go where it needs and the return current for the 5V will follow it's associated GND return path. Also make sure you do not short VBUS to the 5VDC of your splice if you use that jumper J2. Might be best to just leave it off, but since those pins are "HOT" maybe add a bit of Kapton over them to protect against inadvertent shorts. If you are hesitant to make splices in the power feed for Voxl, you can see if one of our pre-spliced power cables we offer can give you a jump start, such as: https://docs.modalai.com/cable-datasheets/#mcbl-00211 and then remove the JST to provide what you need on the Doodle side. But, if you need all 4 wires for the I2C port on Voxl, you can start with an MCBL-00001 and then just move contacts from one cable to another.... https://docs.modalai.com/cable-datasheets/#mcbl-00001 There really are a lot of ways to do this (sorry if it's info overload). I'm happy to review your final solution. If you want some extra support we can email you if you want to share more non-public drawings or such. Just let us know! But, if you are willing to share your setup and pics, it would be faster and you'd be helping others in the same situation Thanks!
  • 0 Votes
    2 Posts
    2k Views
    Kiazoa JoaoK
    @tpavlic did you find the CAD files?
  • 0 Votes
    1 Posts
    403 Views
    No one has replied
  • 0 Votes
    4 Posts
    2k Views
    A
    @tpavlic Thank you, glad it helped!
  • 0 Votes
    2 Posts
    467 Views
    Chad SweetC
    We don't have a guide on our own, but Google should have plenty of guides and examples You'll need to add your own post processing function in this area of the code Here is Google's guide on how to postprocess tflite data https://www.tensorflow.org/lite/inference_with_metadata/lite_support
  • Integration of range finding sensor with m500

    Unsolved Development Drones m500
    1
    0 Votes
    1 Posts
    526 Views
    No one has replied
  • Cannot upgrade from Graupner to Spektrum

    Unsolved Development Drones m500
    3
    0 Votes
    3 Posts
    831 Views
    T
    @mkwan FYI, when we were switching from Spektrum to Graupner, we discovered this setting in the PX4 (accessible via QGC): RC_INPUT_PROTO To go from Spektrum to Graupner HoTT, we had to set that to "SBUS". There is a Spektrum-specific setting. Once we made that change, then QGC started acknowledging that we had a radio connected. That said, all of our FCv2 boards (which were the ones mistakenly sent with Spektrum although we ordered Graupner) had some problem in the UART connection between the PX4 and the VOXL, and so voxl-mavlink-server reported that there was no UART connection. We are about to RMA the VOXL Flight's to modalAI for them to investigate this UART problem. However, assuming that your PX4-to-VOXL connection is good, I think that the RC_INPUT_PROTO setting above should fix the problem you're having getting the Spektrum radios connected to QGC.
  • M500 ToF Sensor Integration

    Unsolved Development Drones m500
    1
    0 Votes
    1 Posts
    614 Views
    No one has replied
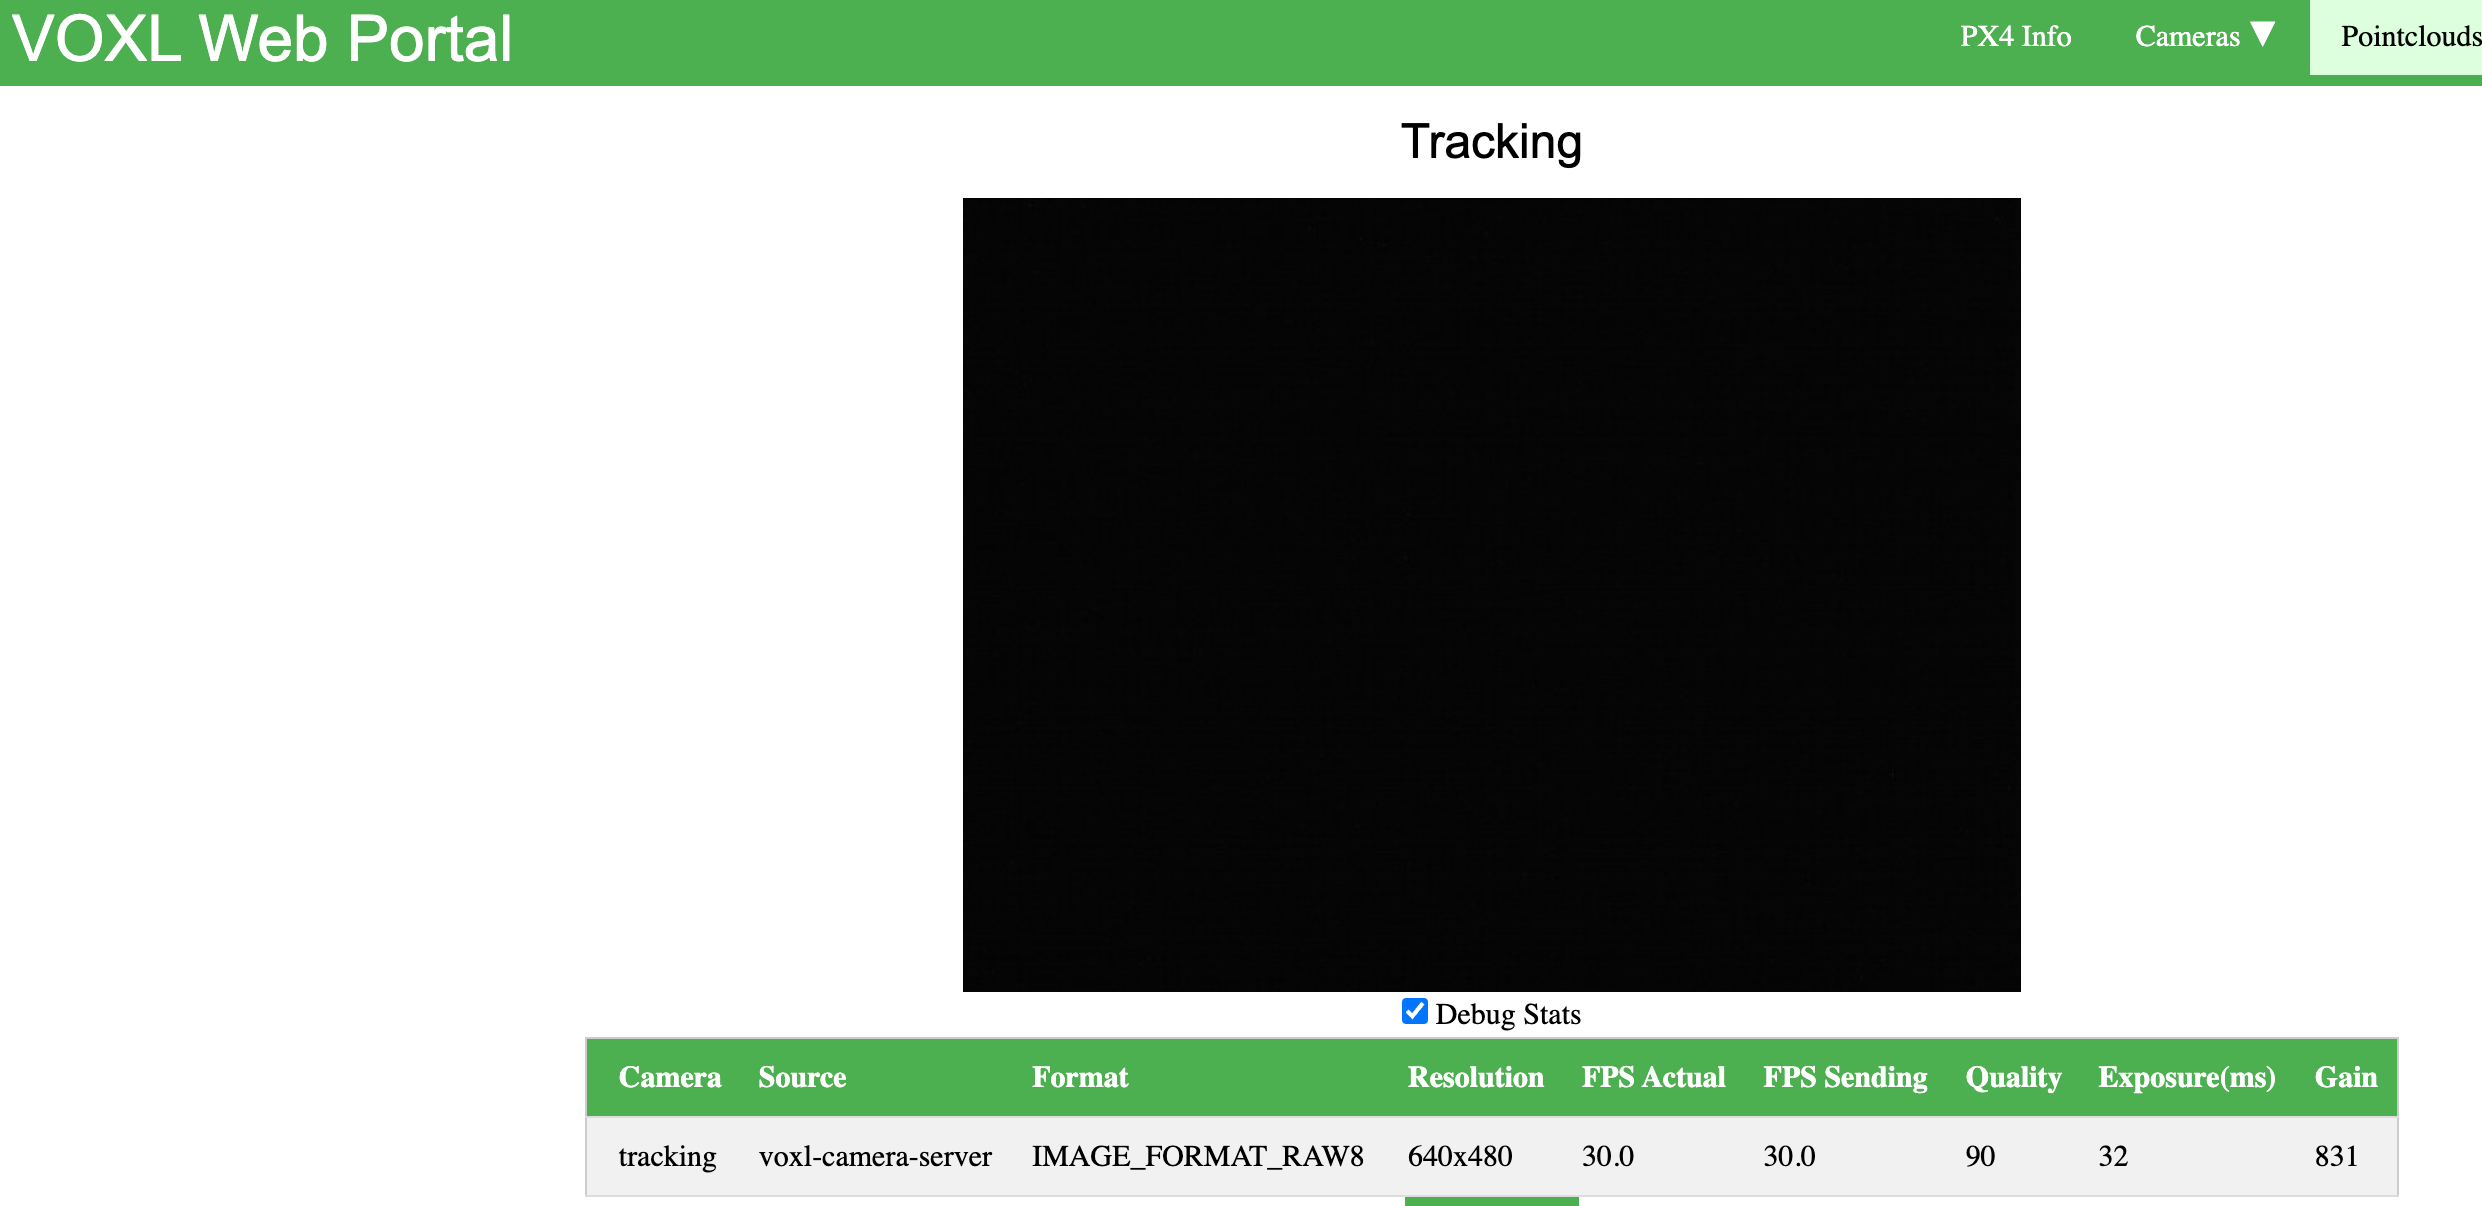
  • Tracking Camera Black Frames

    Unsolved Development Drones m500
    9
    1
    0 Votes
    9 Posts
    2k Views
    J
    @Chad-Sweet Thanks. So it sounds like a full re-flash is probably the best check to re-install base software (I'm not aware of any modifications, but came onto the project after it started) and check that connection. If the issue persists with both units, kick off an RMA? Appreciate all your help.
  • VOXL 1 PX4 firmware question

    Unsolved Development Drones m500
    4
    0 Votes
    4 Posts
    507 Views
    Chad SweetC
    flight Core v1 is what is found on VOXL Flight
  • Running MAVSDK directly on M500 and Python update

    Unsolved Development Drones m500
    7
    0 Votes
    7 Posts
    2k Views
    Steve SagerS
    @Chad-Sweet said in Running MAVSDK directly on M500 and Python update: The Docker is 64-bit, so the code that runs inside is usually faster than the code that runs outside of the Docker Oh, that's interesting, thanks for the insight. I'll share with the others, and let you know how it all goes.
  • QGC shows me a gps error with my m500 drone and M8N gps

    Unsolved Development Drones m500
    4
    0 Votes
    4 Posts
    550 Views
    Chad SweetC
    You need to be outdoors, with clear visibility to the sky, to receive GPS
  • How to send MAVSDK commands from Raspberry Pi AI to the M500

    Unsolved Development Drones m500
    2
    0 Votes
    2 Posts
    760 Views
    Chad SweetC
    Please review the External UDP Mavlink Connection documentation
  • VIO flying configuration

    Unsolved Development Drones m500
    2
    0 Votes
    2 Posts
    592 Views
    ?
    Hi, It looks like the data on that documentation page was erroneously copied over from a different platform, I'll update it shortly but in the future for QVIO needs this docs page is more actively maintained by the software team. For reference the commands in the voxl sdk for doing the things you asked about are voxl-inspect-qvio and voxl-configure-qvio. These are the standard formats for the commands in our SDK, so you can tab out voxl-inspect- or voxl-configure- to see all of the other things you can inspect or configure.
  • Landing Gear Stud Size, and Motor Temperature

    Unsolved Development Drones m500
    4
    0 Votes
    4 Posts
    1k Views
    Steve SagerS
    Our team would greatly appreciate feedback about the motor over heating issue. Both our aircraft (two M500 platforms) have this issue. The high temperature has caused a failure and we are requesting guidance on understanding why the aircraft has this heating issue. Would a calibration of the system help fix an issue like this?
  • Out of space for docker load -i

    Unsolved Development Drones m500
    6
    0 Votes
    6 Posts
    3k Views
    Syed OmairS
    @tpavlic heyyy... i do agree that using roskinetic and xenial is kind of a dumb thing... could you help me with something ? are you using the m500 drone with voxl 1 here to do the "docker pull ros:noetic-robot" command? if you are i do get an error saying Error: Status 410 trying to pull repository library/ros: "<html>\r\n<head><title>410 Gone</title></head>\r\n<body>\r\n<center><h1>410 Gone</h1></center>\r\n<hr><center>openresty</center>\r\n</body>\r\n</html>\r\n" i really kind of want to use the higher versions of python and a more recent ubuntu distribution. any tips or suggestions ?
  • VOXL m500 crash

    Unsolved Development Drones m500
    5
    0 Votes
    5 Posts
    1k Views
    G
    Hello, This is third time I do this, because the questions I did are a very important issue and my company and I want to solve what happened during the flight. So if you have any answer to the questions I did 27 days ago please respond them. Gonzalo
  • VOXL m500, mpa-to-ros not publishing tflite-data topic

    Unsolved Development Drones m500
    4
    0 Votes
    4 Posts
    897 Views
    ?
    This functionality was added to voxl-mpa-to-ros in v0.2.2 and it seems you have some very old software on this drone. I recommend upgrading to the latest sdk by downloading and flashing the VOXL Platform 0.9 release from https://developer.modalai.com/
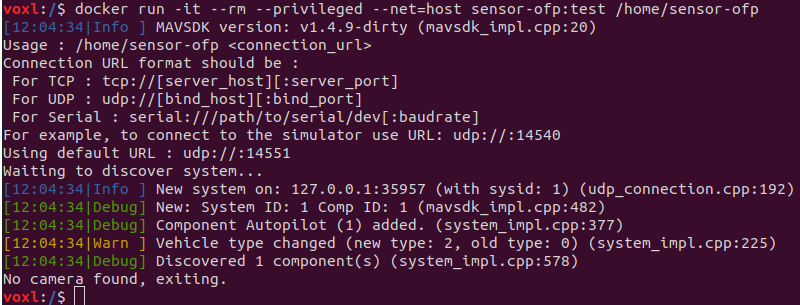
  • Docker MAVSDK cannot find camera

    Unsolved Development Drones m500
    14
    1
    0 Votes
    14 Posts
    2k Views
    tomT
    https://docs.modalai.com/voxl-logger/ I would try out the "-k" option