Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Yaw Estimate Error

    Unsolved starling
    4
    0 Votes
    4 Posts
    525 Views
    Nitin Varma VegesnaN
    @lhermosillo It was 15 with/without the GPS.
  • Integrating lidar sensor

    Unsolved starling
    14
    0 Votes
    14 Posts
    2k Views
    lhermosilloL
    @Muqing-Cao Did you get this working? I was able to get state estimation with the Mid360 through MAVROS, but am now thinking about getting some LiDAR and camera vision fusion for a more robust approach.
  • 0 Votes
    1 Posts
    213 Views
    No one has replied
  • Repair

    Unsolved starling
    2
    2
    0 Votes
    2 Posts
    326 Views
    Nitin Varma VegesnaN
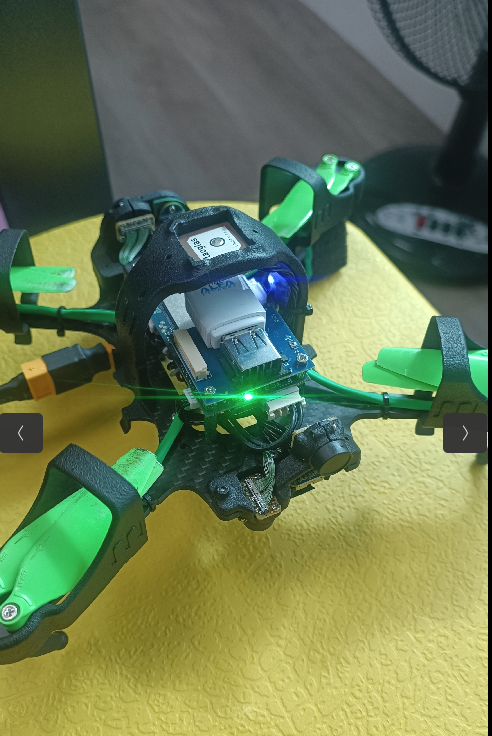
    @Nitin-Varma-Vegesna said in Repair: My Starling 2 drone crashed, and a good amount of damage was done. The PCB board was cracked, and the GPS mount was broken, and I was wondering whether I should submit a Repair Merchandise Authorization, and generally how long does the entire process take from submit an RMA to receiving the drone back? I submitted an RMA form, but I would still like to know how long the entire process takes generally please?
  • 0 Votes
    1 Posts
    1k Views
    No one has replied
  • Setup ModalAI as a vendor

    Unsolved
    1
    0 Votes
    1 Posts
    1k Views
    No one has replied
  • Starling V1 - cannot use RC and GPS

    Unsolved starling
    7
    0 Votes
    7 Posts
    839 Views
    Eric KatzfeyE
    @colombe-ai I'm not sure how much we're going to be able to help to get this going but I'd start with that magnetometer. Put an oscilloscope in the lines and see if you see any activity.
  • How to adjust focus on HIRES Camera for Starling 2?

    Unsolved starling
    2
    0 Votes
    2 Posts
    325 Views
    Alex KushleyevA
    Hello @newdroneflyer , In order to adjust focus of the hires camera, you need to do the following: loosen the screw that holds the lens and prevents it from turning. this will allow the lens to turn within the assembly turn the lens using the lens focus tool (should have come with your Starling 2), it is a black plastic tool that goes around the rim of the lens and allows you to turn the lens. after focusing, tighten the screw that was loosened in step 1. [image: 1768501077911-starling2_hires_focus_steps.png] Here is the picture of the focus tool, it has two sizes - one for hires camera, one for tracking camera (if needed). You should have received one with the Starling2 (in an envelope, probably different packaging). [image: 1768505172374-starling2_focus_tool.jpg] Alex
  • 0 Votes
    1 Posts
    175 Views
    No one has replied
  • Starling 2 C26 config lepton ?

    Unsolved starling
    2
    0 Votes
    2 Posts
    327 Views
    Alex KushleyevA
    Hi @JoonaR, Yes, the Starling 2 drones are shipped with the lepton adapter (M0187), but Lepton sensor itself is not included. https://docs.modalai.com/M0187/ Alex [image: 1768357442694-0cb77fc6-242f-4477-a15d-3c89f43d8f69-image.png]
  • CANT ACCESS CAMERA

    Unsolved fpv
    8
    5
    0 Votes
    8 Posts
    4k Views
    Alex KushleyevA
    @taiwohazeez , Once thing i noticed is that you don't have en_misp set to 1 for the tracking_front camera. I don't think this is the reason for the failure, but it should be set to 1. Meanwhile, please try to identify which camera is causing the issue by disabling cameras and testing camera server ( you can set enabled flag to 0, so that this camera is not started. Also, when you installed SDK 1.6.2, did you run voxl-configure-cameras and which option did you select for the camera configuration? Alex
  • Camera Calibration

    Unsolved fpv
    6
    1
    0 Votes
    6 Posts
    3k Views
    Alex KushleyevA
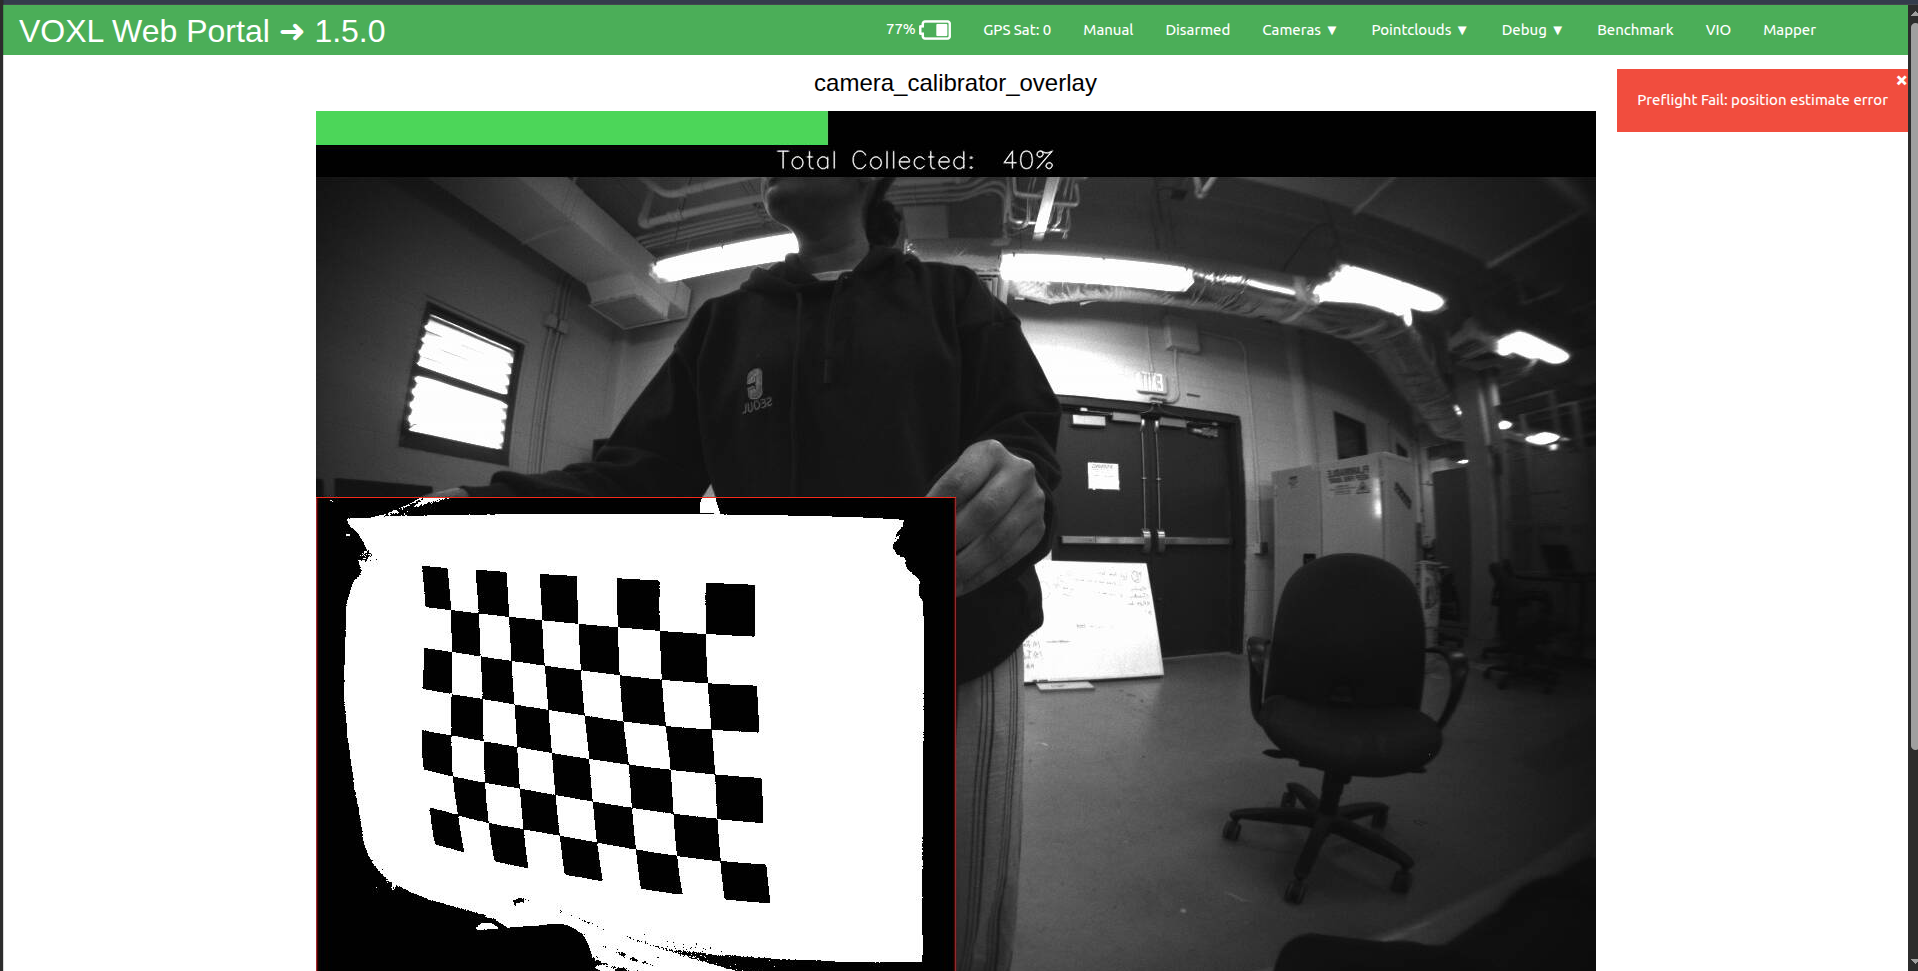
    @taiwohazeez , It is possible, as the output suggests that the motion blur is causing the issue. You can override the auto exposure algorithm and reduce the exposure down to 5ms or so to help with this. There are two ways of doing this: using voxl-portal : open the regular camera view for your tracking camera, click a small check box in the bottom left corner to enable the advanced control panel. This will allow you to set the exposure and gain, you can try to set the gain to the max (should be 1600 (16x) for AR0144) and then play around with exposure to have the lowest exposure that still makes the checker board clear. After you are done changing the manual exposure, you can run the calibrator and switch the voxl-portal to the calibrator output. please note that until you touch the sliders for exposure and gain, they will not correspond to the current values that are being used by auto-exposure algorithm. from command line you can send a command to camera server: voxl-send-command tracking_front set_exp_gain 5.0 1600 (this would set exposure to 5.0ms and gain to 1600 ISO (16x)) Please note that the manual exposure settings / mode will persist until you reboot the camera server. Alex
  • Bricked VOXL2 on Starling 2 Max

    Unsolved starling
    3
    2
    0 Votes
    3 Posts
    488 Views
    R
    @Alex-Kushleyev This unit was sent in on RMA 796.
  • MEETING WITH MODALAI TECHNICAL TEAM AND MY ADVISOR

    Unsolved fpv
    6
    0 Votes
    6 Posts
    3k Views
    T
    @Moderator Thank you for the link. But he says he needs to get on a call with the technical team. It's a year already and I still don't know much about the drones (which may be from my end, I don't know), but he wants to handle this himself this time around and get all necessary information on a single call sometime early in January 2026. Kindly let me know if this is possible, and how to go about it. Thanks
  • Help with drone familiarization

    Unsolved fpv
    5
    0 Votes
    5 Posts
    3k Views
    T
    @tom This is the output voxl2:/$ voxl-version ──────────────────────────────────────────────────────────────────────────────── system-image: 1.8.06-M0054-14.1a-perf kernel: #1 SMP PREEMPT Wed Oct 22 04:13:18 UTC 2025 4.19.125 ──────────────────────────────────────────────────────────────────────────────── hw platform: M0054 mach.var: 1.0.1 SKU: MRB-D0014-4-V1-C27-T9-M0-X0 ──────────────────────────────────────────────────────────────────────────────── voxl-suite: 1.6.2 ──────────────────────────────────────────────────────────────────────────────── Packages: Repo: http://voxl-packages.modalai.com/ ./dists/qrb5165/sdk-1.6/binary-arm64/ Last Updated: 2025-12-25 03:58:02 List: libfc-sensor 1.0.8 libmodal-cv 0.6.0 libmodal-exposure 0.1.4 libmodal-flow 1.0.3 libmodal-journal 0.2.7 libmodal-json 0.4.8 libmodal-pipe 2.14.8 libqrb5165-io 0.5.0 libvoxl-cci-direct 0.3.3 libvoxl-codec 0.0.1 libvoxl-cutils 0.1.6 modalai-slpi 1.2.2 mv-voxl 0.1-r0 qrb5165-bind 0.1-r0 qrb5165-dfs-server 0.2.0 qrb5165-imu-server 1.2.3 qrb5165-mini-tof-server 0.2.2 qrb5165-rangefinder-server 0.1.6 qrb5165-slpi-test-sig 01-r0 qrb5165-system-tweaks 0.3.11 qrb5165-tflite 2.17.2 voxl-bind-spektrum 0.1.1 voxl-camera-calibration 0.6.1 voxl-camera-server 2.2.17 voxl-ceres-solver 2:2.0.0-2 voxl-configurator 1.0.10 voxl-cpu-monitor 0.7.4 voxl-docker-support 1.3.1 voxl-elrs 0.4.14 voxl-esc 1.5.7 voxl-feature-tracker 0.5.2 voxl-flow-server 0.3.6 voxl-gphoto2-server 0.0.10 voxl-io-server 0.0.6 voxl-jpeg-turbo 2.1.3-7 voxl-lepton-server 1.3.3 voxl-lepton-tracker 0.0.4 voxl-libgeographic 1.0.0 voxl-libgphoto2 0.0.4 voxl-libuvc 1.0.7 voxl-logger 0.6.0 voxl-mavcam-manager 0.6.0 voxl-mavlink 0.1.6 voxl-mavlink-server 1.4.12 voxl-microdds-agent 3.0.0-0 voxl-modem 1.2.2 voxl-mongoose 7.19.0 voxl-mpa-to-ros 0.3.9 voxl-mpa-to-ros2 0.0.7 voxl-mpa-tools 1.5.5 voxl-open-vins-server 0.5.7 voxl-opencv 4.5.5-3 voxl-osd 0.2.1 voxl-portal 0.8.4 voxl-px4 1.14.0-2.0.124 voxl-px4-params 0.8.11 voxl-qvio-server 1.2.2 voxl-remote-id 0.0.9 voxl-reset-slpi 0.0.1 voxl-ros2-foxy 0.0.1 voxl-state-estimator 0.0.5 voxl-streamer 0.8.0 voxl-suite 1.6.2 voxl-tag-detector 0.0.5 voxl-tflite-server 0.5.0 voxl-utils 1.4.9 voxl-uvc-server 0.1.7 voxl-vision-hub 1.9.19 voxl-vtx 1.7.6 voxl-wavemux 0.0.3 voxl2-io 0.0.3 voxl2-security-hardening-utls 1.0-r0 voxl2-system-image 1.8.06-r0 voxl2-wlan 1.0-r0 ──────────────────────────────────────────────────────────────────────────────── voxl2:/$
  • Robotic simulation for Starling-2 Drone

    Unsolved starling
    1
    0 Votes
    1 Posts
    287 Views
    No one has replied
  • Shipping to Texas Starling 2 Max with 5G

    Unsolved starling
    2
    0 Votes
    2 Posts
    325 Views
    ModeratorM
    @colombe-ai currently 30 business days is quoted on the website: https://www.modalai.com/products/starling-2-max It typically should ship more quickly than that though, likely 2-3 weeks There is no overnight shipping option as all of the drones are built to order
  • Starling 2 Max Accessories and Cables

    Unsolved starling
    2
    0 Votes
    2 Posts
    330 Views
    ModeratorM
    @colombe-ai You can find the batteries here: https://www.modalai.com/products/m10000538 Any 2S LiIon hobby charger will work. Something like this is all you need: https://www.amazon.com/ISDT-608PD-Battery-Charger-Discharger/dp/B0CM9BFQSX Handheld transmitter depends on the configuration of the drone. You can order the drone with a pre-bound charger ready to fly from the website. The main debugging cable is a standard USB-C cable
  • Starling 2 Max with 5G capability

    Unsolved starling
    1
    0 Votes
    1 Posts
    321 Views
    No one has replied
  • Starling2 :One motor fails when changing power from AC/DC adapter to battery

    Unsolved starling
    4
    6
    0 Votes
    4 Posts
    469 Views
    Alex KushleyevA
    Hello @HsinSWT , When i see results like this, i would say there is probably 90% chance that the motor is bad. Unfortunately, there is a chance that the ESC is bad as well, and there is no good way to check the ESC without a known good motor (however the ESC failure is unlikely). As I mentioned in the previous post, if you had a milli-ohm meter, you could test the motor winding resistance to confirm whether the motor is good or bad. A tool like that measures resistance with high precision (similar to a regular Ohm meter). However, if you don't have one, it may not be worth buying it.. You will not be able to measure the winding resistance of these motors correctly with a regular Ohm meter. However, you will be able to detect a complete open circuit (which could be the case, maybe worth trying). If testing resistance using a regular Ohm meter, any two connections between the 3 motor phases will read 0 ohm (or close to that). If a wire is broken, then you can detect it. The Starling 2 motor (3000kV) has around 0.360 - 0.370 Ohm phase-to-phase winding resistance. In order to confirm that the ESC is working properly, you could temporarily connect one of the working motors to the ESC Channel 0 and do the same spin test (using voxl-esc tools), just to confirm that the ESC Channel 0 is working fine. In order to fix the issue, you could order a new motor and replace it yourself (will be a lot cheaper): https://www.modalai.com/products/starling-2-replacement-parts?variant=49707605393712 You could also send the whole drone back for repair (https://www.modalai.com/rma) Alex