Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Can you use the Seeker VOXL Cam portion and put on another frame?

    Unsolved seeker
    1
    0 Votes
    1 Posts
    642 Views
    No one has replied
  • Radio frequency regulatory information of m500

    Unsolved wifi m500 frequency japan documentation
    1
    0 Votes
    1 Posts
    1k Views
    No one has replied
  • Gimbal mechanism along with camera

    Unsolved m500
    2
    0 Votes
    2 Posts
    547 Views
    Chad SweetC
    We do not have any recommended or supported gimbal solutions at this time, sorry. We have had a difficult time finding one that is readily available. Some folks have had luck with Tarot gimbals though, you could try that.
  • What is the maximum thrust that one rotor can generate?

    Unsolved m500
    2
    0 Votes
    2 Posts
    645 Views
    Chad SweetC
    sorry for the slow reply. We have a bunch of data from our dyno bench here
  • RB5 3rd part ESC support

    Unsolved rb5
    2
    0 Votes
    2 Posts
    845 Views
    modaltbM
    Hi @benjamin-linne, Supporting more ESCs in the future is definitely on the roadmap, but no hard timelines to provide. In general, the current ESC is interfaced with a UART based driver, eg. here: https://github.com/modalai/px4-firmware/blob/v1.2.x-modalai-rb5-flight-alpha/src/drivers/uart_esc/modalai_esc/modalai_esc_serial.cpp#L50 This UART itself actually resides in the DSP, so it's customizable but we need to get a bit more docs up for this to make it achievable for others!
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    13 Views
    No one has replied
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    9 Views
    No one has replied
  • m500 Autonomous Flight

    m500
    4
    0 Votes
    4 Posts
    645 Views
    tomT
    @Developer-Evaluation Exactly. If you're using an alternate data link for motor control such as LTE or Microhard the RC radio is purely for safety purposes.
  • Unable to connect to QGroundControl

    Unsolved rb5
    5
    0 Votes
    5 Posts
    3k Views
    ?
    Hi @Francesco-Jacomel, We are having a hard time reproducing your issue on our end. Here are the steps we took in order to connect to QGroundControl (Mobile - iPhone) Version 4.0.10 Setup wifi on RB5 by modifying the /data/misc/wifi/wpa_supplicant.conf with our wifi, rebooting the RB5, and connecting our mobile device to the same network which we had setup on the RB5 Open QGroundControl on our mobile device and wait for a connection Following these steps we were able to successfully connect. If these steps were also taken on your end then we think there may be a UDP broadcasting conflict that is causing the issue. We can troubleshoot this by having you make some modifications to your full-m0052.config file on target. You'll want to disable MAV_BROADCAST as well as add your Iphone's IP in the /etc/modalai/full-m0052.config file on target. Configure this file in the appropriate section so it looks as follows: # This is needed for altitude and position hold modes flight_mode_manager start # Add this line to disable MAV_BROADCAST param set MAV_BROADCAST 0 # Edit this line to add your phones IP mavlink start -x -u 14557 -r 40000 -t <Iphone IP> mavlink start -u 14556 -t 127.0.0.1 -n lo -m custom sleep 1 mavlink stream -u 14557 -s HIGHRES_IMU -r 5 mavlink stream -u 14557 -s ATTITUDE -r 5 mavlink stream -u 14557 -s RC_CHANNELS -r 20 sleep 1 Make sure to fill in the IP with your mobile phones IP. On an IPhone you can get the IP by going to settings>Wi-Fi and clicking the info button on your network. After configuring these parameters reboot your RB5 and open the QGC application on the mobile phone and see if the issue is still present. Thank you for being patient with us. If needed, we can also arrange a phone call to try and further troubleshoot this issue.
  • Building Tensorflow Lite From Source w/ NNAPI

    Unsolved android nnapi snpe tensorflow rb5
    7
    0 Votes
    7 Posts
    4k Views
    S
    @modaltb Excellent! Happy to help if you need it. Don't hesitate to reach out to myself or @mrawding
  • Camera server crashes with any use of stereo cameras.

    Unsolved m500
    2
    1 Votes
    2 Posts
    571 Views
    ?
    This issue pops up from time to time and it is, without fail, a hardware issue. Can you check not just the connectors for your stereo cameras but also the cables themselves. They can develop kinks or get scratched and expose the traces if they go through any number of unfriendly environments, which will regularly lead to hal3 being unable to see the device.
  • Can RB5 drone be setup as hotspot?

    Unsolved rb5
    2
    0 Votes
    2 Posts
    816 Views
    Chad SweetC
    In theory, yes. It would require setting up the proper routing tables in Linux. Should be standard Linux configurations, though we have not tried it. If you get it to work, please report back here!
  • GPS LED Not Lighting Up

    m500
    1
    0 Votes
    1 Posts
    508 Views
    No one has replied
  • Can I control the drone through 5G (No Spektrum Transmitter) ?

    Unsolved rb5
    6
    0 Votes
    6 Posts
    2k Views
    Francesco JacomelF
    @tom said in Can I control the drone through 5G (No Spektrum Transmitter) ?: /etc/systemd/system/rb5-net-check.service Thank you @tom ! It worked!
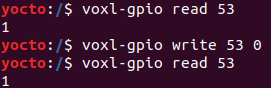
  • voxl-gpio not working as expected

    Unsolved m500
    3
    1
    0 Votes
    3 Posts
    933 Views
    M
    Great, thanks for the info. I suspected something along those lines.
  • Autonomous Inspection Demo with Voxl m500

    Unsolved m500
    3
    3 Votes
    3 Posts
    1k Views
    tomT
    @PawelJ Thanks for sharing! Great work!
  • Does the RB5 run the same software as the VOXL Cam module?

    Unsolved rb5
    2
    0 Votes
    2 Posts
    845 Views
    Chad SweetC
    That is correct. They are the same binaries with target-specific integration software around them.
  • Timeline for voxl-like services

    Unsolved rb5
    2
    0 Votes
    2 Posts
    838 Views
    ?
    We are currently working on this, there's no definite timeline but it's one of the main projects we're currently working on. Note that there will be no port of the voxl-docker project since rb5 is an ubuntu platform (so you can install docker normally with the standard ubuntu process)
  • EVT Camera Driver Example Software

    Unsolved rb5
    4
    0 Votes
    4 Posts
    1k Views
    modaltbM
    Hi @mrawding , The current early release on the EVT hardware relies on gstreamer.... for example: cd /data/misc/camera rm * gst-launch-1.0 -e qtiqmmfsrc camera=0 name=tracker ! video/x-h264,format=NV12,width=640,height=480,framerate=30/1 ! queue ! h264parse ! avdec_h264 ! videoconvert ! pngenc ! multifilesink enable-last-sample=false location="/data/misc/camera/cam0_img_%d_.png" This will save images to the path specified. We're actively working on getting the same interfacing as VOXL up on this ;). Next few weeks should have some good PUBLIC REPO updates.
  • m500 Loses Position Data after incident

    Unsolved m500
    3
    0 Votes
    3 Posts
    839 Views
    modaltbM
    Hi @jsearlePSU_ARL , I wouldn't expect battery affecting the measurement, but possibly vehicle response (although not at 34%). The default params are setup for 4s as well. When batteries get low, 'power' gets low, and thus response, so the oomph to move to desired location, but not the sensors ability to measure (that power source is from the VOXL power module output, not tied to the motors power per-se).