Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • TBS Crossfire Nano Receiver

    Unsolved
    1
    0 Votes
    1 Posts
    357 Views
    No one has replied
  • Power module V3 output specifications

    Unsolved
    2
    0 Votes
    2 Posts
    623 Views
    modaltbM
    Hi @mohammednaveed , The revB (which is basically what we've been shipping for 2 years) is rated at 5V with 6A output, datasheet. The snapdragon based designs have some decent inrush current requirements on bootup, hence this need.
  • VOXL Working Lighting Conditions

    Unsolved
    2
    0 Votes
    2 Posts
    499 Views
    Steve TurnerS
    @cer5517 Here's another forum post talking about low-light conditions. https://forum.modalai.com/topic/589/flying-in-poorly-lit-conditions/3 TLDR is you need enough features for QVIO to pick points out for VIO. So you either need a diffuse light source that can illuminate features or some other low-light sensor that you would need to integrate with QVIO.
  • QGC battery alert everytime

    Unsolved
    2
    1
    0 Votes
    2 Posts
    563 Views
    Chad SweetC
    Hi Gaurav, please refer to QGroundControl's documentation on the battery monitoring setup here
  • Recommended Lepton Board

    Unsolved
    3
    0 Votes
    3 Posts
    425 Views
    wilkinsafW
    Thanks Eric!
  • Pin-out for MCBL-00009 ?

    1
    0 Votes
    1 Posts
    288 Views
    No one has replied
  • connection to management in modalai

    Unsolved
    1
    0 Votes
    1 Posts
    482 Views
    No one has replied
  • QGC GPS Speed Error

    Unsolved rb5 gps
    6
    0 Votes
    6 Posts
    2k Views
    Steve TurnerS
    I have not flown the RB5 and I am still new to using PX4, but on a similar platform I recommend checking parameters in QGC and look for EKF2_Aid_Mask. You can toggle to: [image: 1648613903566-5fcf07a0-841e-4751-a38a-affff3b935f5-image.png] Which should disable GPS inputs and allow you to fly indoors. Just remember to set it back to use GPS when you want to fly outdoors. As Modal mentions, take appropriate safety precautions whens flying indoors even with VIO enabled.
  • VIO and GLOBAL_POSITION_INT

    Unsolved
    11
    1
    0 Votes
    11 Posts
    2k Views
    ?
    Great to hear. I forgot about the ToF. Chad beat me to the punch here. Glad that helped!
  • Suggestions for performing VIO

    Unsolved
    3
    0 Votes
    3 Posts
    843 Views
    Steve TurnerS
    Cliff, Apologies for hijacking this thread slightly, but in another one I was interested in this transition mechanism. It looks like the responsible code to monitor GNSS signals and perform the transition is here: https://github.com/modalai/px4-firmware/pull/1/files#diff-4086bdb716e4bb6c6668a2d61f8c87ef3f15caf4c7d7032595c7ec28a4cffdc7R106 Are these changes merged into the official build of v1.11.3-0.2.3 on the ModalAI site at?: https://storage.googleapis.com/modalai_public/flightcore-releases/v1.11.3-0.2.3-modalai_fc-v1_default.px4 I haven't seen the firmware ever "flip" the EKF2 mask, but perhaps there is another parameter I need to set to enable the GNSS quality monitoring. I'll poke around a bit more, just wanted to make sure I was on the right track with the above changeset. Thanks much for any insight! Steve
  • Indoor path navigation

    Unsolved
    2
    0 Votes
    2 Posts
    502 Views
    Steve TurnerS
    One of the Modal team can probably chime in on this... but I'll throw out a few thoughts. It would definitely be feasible with the Seeker drone, but would require some programming knowhow to leverage the mapping software Modal has out of the box. You could walk the drone around the space manually once to build the first map and then from there on have a path with waypoints around the space for it to fly the Insta360 around to capture updates of construction. Alternatively you could use one of the VOXL cameras to capture.
  • Hello, I bought voxl this time.

    Unsolved
    2
    0 Votes
    2 Posts
    434 Views
    modaltbM
    Hi @마페링 , Double checking, do you have a VOXL Flight and not a VOXL? For the USB connection, what port are you using? The ADB connection is to talk to Linux (not PX4) and to talk to PX4 over USB you will want to use the J1006 connector. Thanks!
  • Implementing PX4 avoidance in mission mode using the voxl and QGC

    Unsolved
    20
    0 Votes
    20 Posts
    5k Views
    J DataJ
    @modalab Hello, can you help me to resolve this problem?
  • Unable to configure RB5 from Qgroundcontrol

    Unsolved
    7
    0 Votes
    7 Posts
    853 Views
    Eric KatzfeyE
    @prjana Can you arm the drone? Obviously with appropriate safety precautions as this can be an extremely dangerous thing to do if you aren't very careful! But arming the drone will cause the motors to spin.
  • PX4 mavlink flight modes

    Unsolved
    2
    0 Votes
    2 Posts
    873 Views
    Cliff WongC
    Mavlink messages for setting flight mode use the MAVLINK_MSG_ID_SET_MODE message type (same as APM). Modes are defined in the uOrb layer under the vehicle_status.msg fie, which C headers are auto-generated at build time. The auto-generated file is under the build directory as vehicle_status.h via the NAVIGATION_STATE_* variables. And example of using modes in runtime code are in the mavlink_messages.cpp file (search for vehicle_status_s::NAVIGATION_STATE_AUTO_MISSION) and modes are processed in the Commander.cpp file. Both files under the src/modules directory of PX4.
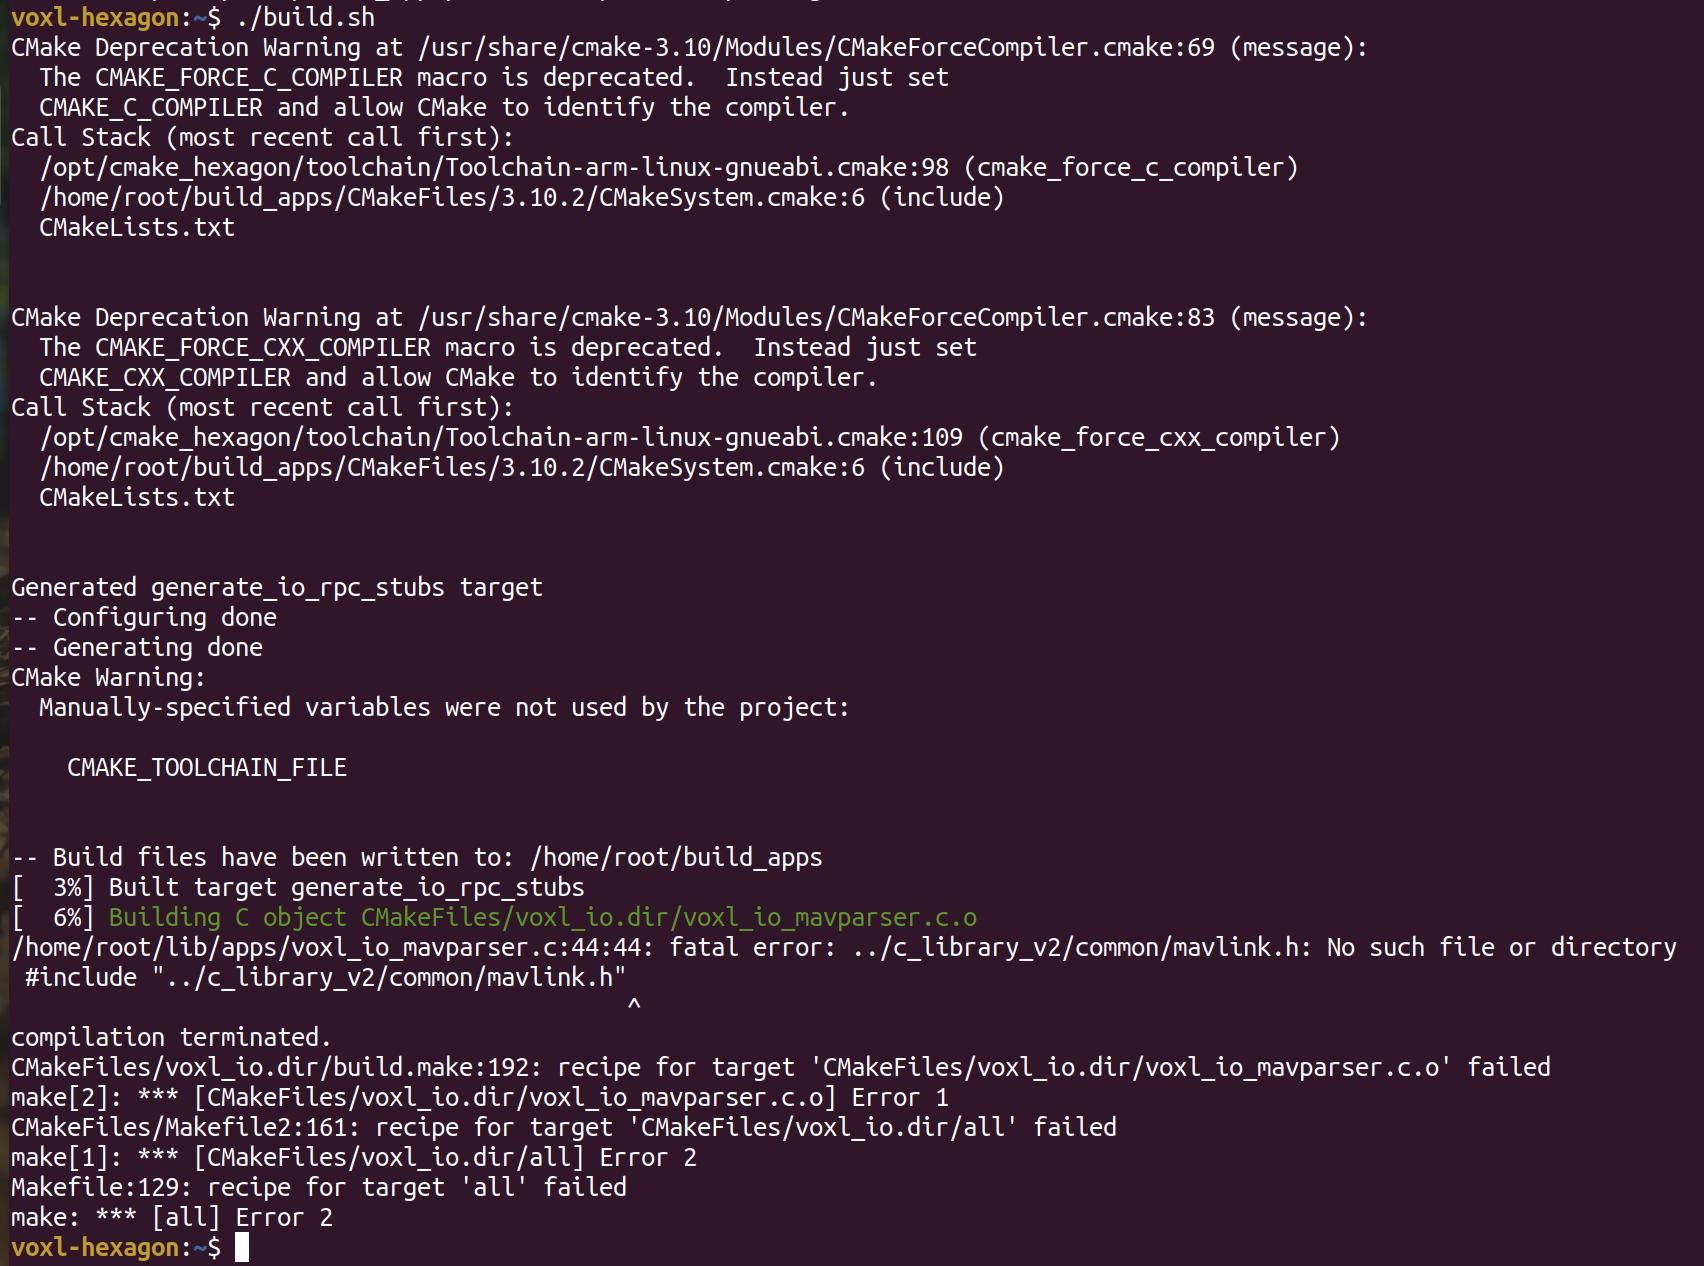
  • Voxl-hexagon build.sh

    Unsolved
    6
    1
    0 Votes
    6 Posts
    1k Views
    SHofmeesterS
    @Eric-Katzfey Thank you for your help. I followed your steps and it worked immediately. I am now also able to generate the ipk-package and push it to the VOXL. When I use adb shell, the file appears in home/root/ipk. I tried a few things, but I still have some questions: How can I run the i2c related files from "libapq8096-io/lib/python" on the VOXL, for example voxl_i2c_scan.py? Can I also make my own python scripts and run them?
  • Running customized software in emulators

    Unsolved
    2
    0 Votes
    2 Posts
    504 Views
    Eric KatzfeyE
    @Daniel-Lin ModalAI does not have any plans to produce hardware emulation at this point. However, I don't think buggy code will ruin an m500 (assuming you aren't flying, of course). We develop all of our hardware device drivers directly on target without any issue. For added safety, please remove the propellers before doing any such development.
  • Questions regarding the VOXL m500

    Unsolved
    4
    0 Votes
    4 Posts
    656 Views
    Eric KatzfeyE
    @Remco-Roelofs You can find more information about our Microhard and Doodle Labs support here: https://docs.modalai.com/microhard-modems/ and here: https://www.modalai.com/collections/accessories/products/voxl-microhard-modem-usb-hub. I would urge you to work with Microhard and Doodle Labs directly to verify that their products can do what you need.
  • Arming Issues with Controller

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    R
    Any updates on this?
  • How to enable LVDS data streaming on VOXL m500?

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    yu zhangY
    @Eric-Katzfey Thanks for reminding me about this So, I may have to switch to using the J8 in different scenarios.