Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • VOXL2 - Tracking Sensor M0014 and cameras data capturing

    Unsolved
    2
    0 Votes
    2 Posts
    346 Views
    Chad SweetC
    You should be using docs.modalai.com , the beta-docs are only published for specific, pre-release components. You cannot plug image sensors in where ever you like. You need to follow a supported configuration here: https://docs.modalai.com/voxl2-camera-configs/
  • 0 Votes
    5 Posts
    1k Views
    D
    Hi Chad, Thanks. One more question: Once new features are necessary during development or feasibility check, how to get ModalAI direct support? by contract or only through ModalAI forum? Best Regards, Dan
  • Voxl-docker creates unsable HAL3 binary file

    Unsolved
    4
    0 Votes
    4 Posts
    487 Views
    Chad SweetC
    thanks for the suggestion, note added to hellocamera
  • QGROUND CONTROL shows not ready and some errors

    Unsolved
    2
    1
    0 Votes
    2 Posts
    424 Views
    Chad SweetC
    Hi Jose, there's really not enough information for us to help here. What flight controller are you using? how are you connected? What did you change to get it into this state? that error implies you do not have GPS connected, or it is not outside to receive position information
  • voxl-feature-tracker with TOF error

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    Chad SweetC
    You need to calibrate the thermal camera to generate the intrinsic. There is no off the shelf way to do this. You will need to create a to-scale checkerboard that the sensor can see
  • Apriltag Relocalization with GPS?

    Unsolved
    2
    0 Votes
    2 Posts
    742 Views
    Cliff WongC
    Modules such as Precision Landing in PX4 perform a indirect correction using relative camera coordinates translated to the global frame upon identification if the "tag/marker". I suggest you take a look into the Precision Landing module of px4 as an example in solving your problem. Of course that is using the IR markers available out there. Now we have internally modified that module for april tags in the landing case as well that will be available shortly. This method corrects the drone relative to actual ground truth (i..e the ARtag/IRTag), but does not correct the Global Frame position itself as its used as a relative offset to correct its setpoint position. That offset could be used to correct the global frame position itself (doesn't necessarily exist in PX4), but then again it would be better to transmit the actual GPS position of the tag to account for the curvature of the Earth, etc... and then calculate a proper offset.
  • Voxl PX4 firmware not working

    Unsolved
    3
    0 Votes
    3 Posts
    566 Views
    yashas katteY
    I tried the link you provided,the ECS is not intalising and ardupilots firmware and voxl is not able to communicate with the px4. Also stats provided in voxl portal about px4 there is not available. Is it possible we meet on a call on any meeting platform, So that we can solve this issue easily? Thank you
  • High-Resolution + TOF + Stereo on VOXL?

    Unsolved
    3
    0 Votes
    3 Posts
    751 Views
    C
    Hi @Alex-Gardner I'm trying to accomplish the same thing as the OP but I'm running into some problems (my thread: https://forum.modalai.com/topic/1703/non-standard-camera-configuration-on-voxl-running-4-0-0-0-9-4). When connecting the stereo to J3 and hires to J4 voxl-camera-server -l outputs only two cameras which are the stereo, it does not recognize hires unless its on J2 but that has its own slew of problems which I've gone into more detail in my thread. Any help with this would be appreciated.
  • vrpn_client_ros, How to install on VOXL-Flight?

    Unsolved
    2
    0 Votes
    2 Posts
    567 Views
    Chad SweetC
    We don't have any experience with that package, sorry.
  • MDK-M0117-1-01

    Unsolved
    4
    0 Votes
    4 Posts
    926 Views
    VinnyV
    @Suvasis-Mukherjee said in MDK-M0117-1-01: I see D0-A,B, C which one corresponds to which pin mentioned above in the documentation pasted above? Hi Suvasis, Can you please clarify what you are referring to... I do not know what "D0-A,B,C" is to help you with this question. Thanks!!
  • Voxl m500 temperature durability

    Unsolved
    6
    0 Votes
    6 Posts
    764 Views
    VinnyV
    @TasnimBas Glad we can help. Our team says this: "The injection molded plastics from the S500 frame are advertised as being glass-fiber reinforced nylon", so not sure if that helps you, but we do not have a material spec sheet to get the temp coefficients you are after. Maybe that description can get you close!
  • voxl2 and ROS

    Unsolved
    2
    0 Votes
    2 Posts
    544 Views
    Chad SweetC
    No, but there should be no difference to any other Debian system. I think if you Google it, you should find what you are looking for. From Google, I found this result which looks promising https://docs.ros.org/en/dashing/Installation/DDS-Implementations.html Obviously, we have not tried this
  • motor for VOXL® 2 AI & 5G Development Drone - Sentinel

    Unsolved
    3
    0 Votes
    3 Posts
    731 Views
    Suvasis MukherjeeS
    thank you.
  • Unable to connect to host PC using adb shell & SSH

    Unsolved
    19
    1
    0 Votes
    19 Posts
    3k Views
    Mohammad Saeid AnwarM
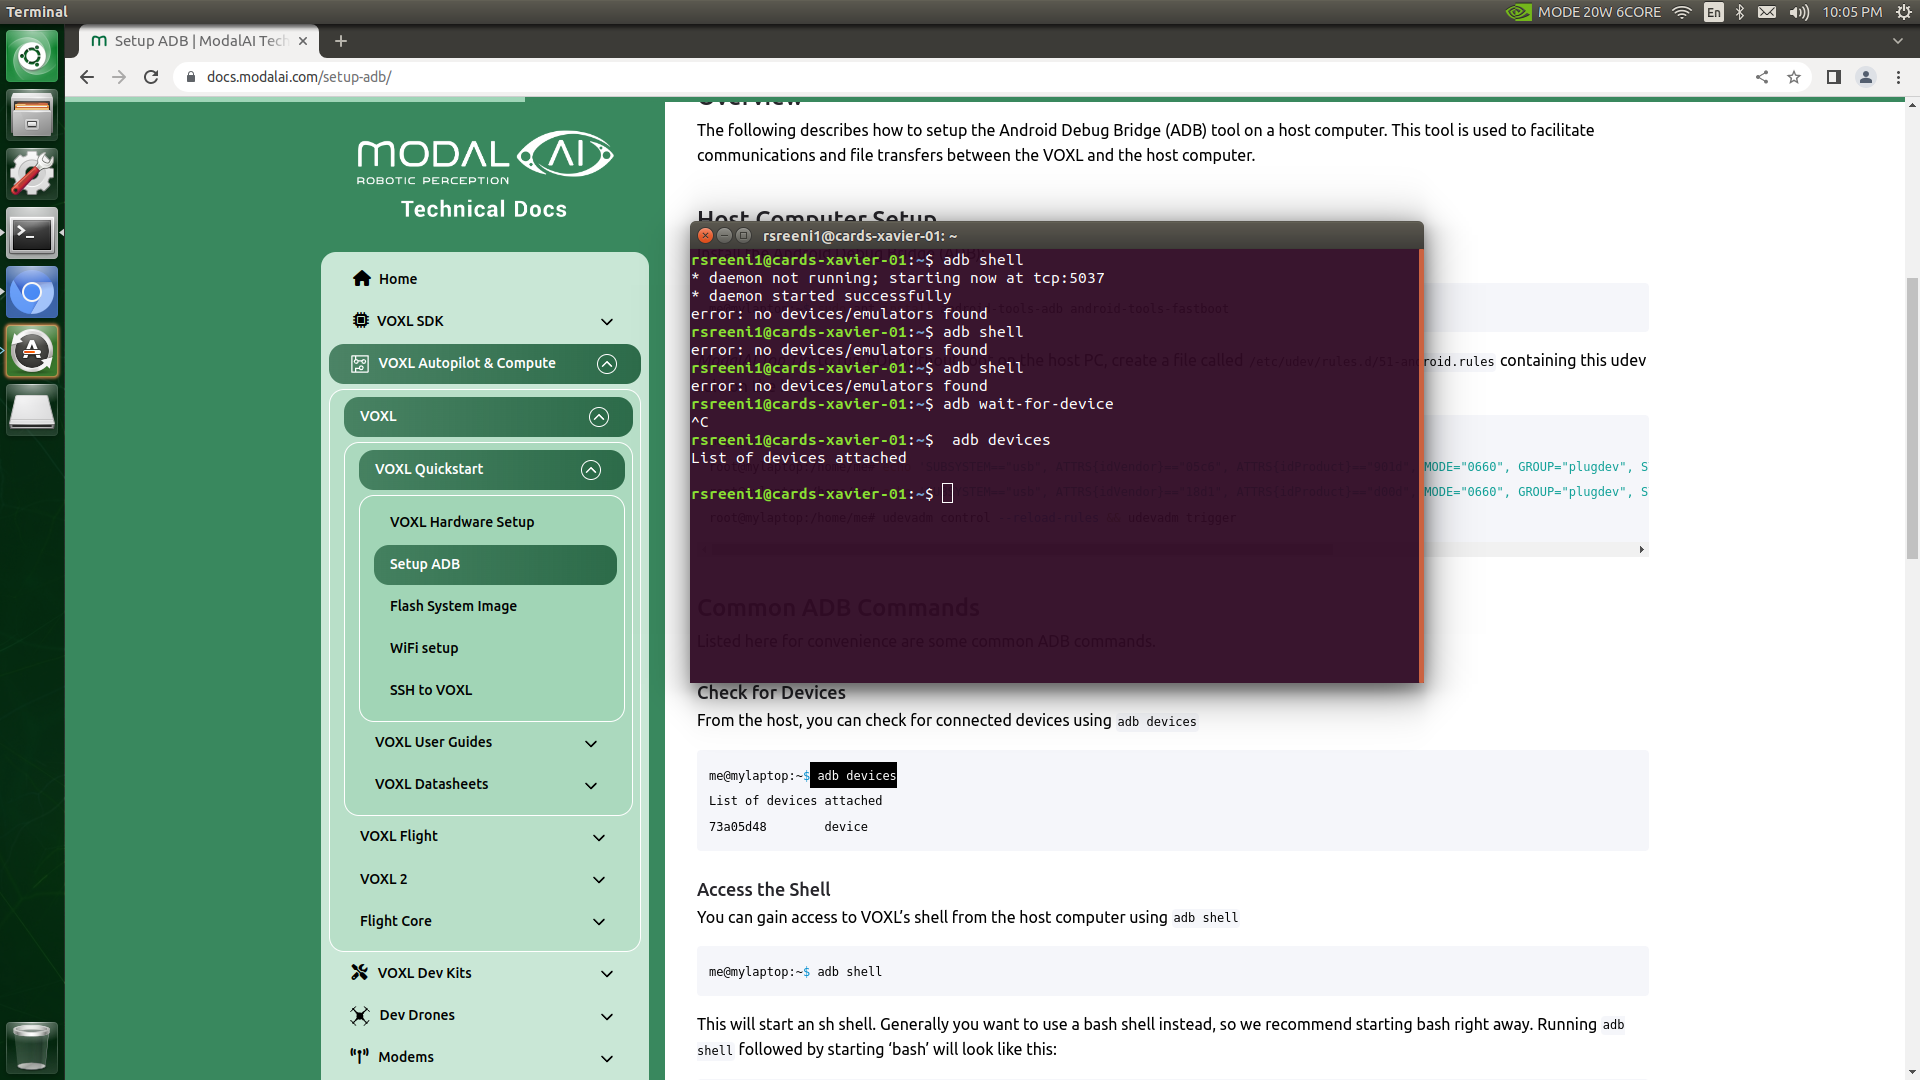
    No. I don't have any other voxl. Yes, it's properly installed. I had previously worked with the same ADB installation. Suddenly, it stopped responding. I also tried with two other machines with proper ADB installations. It showed the same problem (no device found).
  • Seems things have changed with voxl-camera stuff...

    Unsolved
    15
    0 Votes
    15 Posts
    3k Views
    Ed SutterE
    @Chad-Sweet I'm not familiar with a "ci script", I've just been referring to the README.md file at the top of each of the project repositories. Most of the projects do include a install_build_deps.sh step, but that wasn't in voxl-streamer's README.md, so I didn't realize I had to run it. No worries; although, it's probably a good idea that the README.md be updated to include that.
  • Voxl 2 DFS Server

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    B
    @Chad-Sweet That seems to have done the trick! Thanks
  • Does VOXL2 support docker autorun?

    Unsolved
    3
    0 Votes
    3 Posts
    714 Views
    Daniel RyuD
    @Alex-Gardner Perfect, thanks!
  • Executing custom opencv c++ code

    Unsolved
    2
    0 Votes
    2 Posts
    640 Views
    ?
    Hi, You'll want to make your own project that builds a package that can be deployed to a voxl. Our projects generally follow a four-script system. install_build_deps.sh The script that install the build dependencies of a project. If you're writing an opencv process for voxl you'll probably need voxl-opencv and libmodal-pipe at the very least to get your code to work. (If you haven't already, check out our docs on our pipe architecture to see how to grab camera frames in userspace). build.sh The script that actually builds the codebase that you're using, will set up a cmake toolchain to make sure that you're building with the right architecture/gcc version and put all of the build files in a build directory for packaging. make_package.sh The script that bundles all of the built files, as well as any config/other files that your project will use into a standard debian or opkg package (opkg for voxl1 or debian for voxl2/rb5) All three of those scripts should be run inside of the voxl-cross docker image that we've built as our primary build environment; it has all of the toolchains that you may need baked in, as well as the correct gcc versions for our different platforms. deploy.sh This script deploys the package that you've built to voxl and installs it, oputting any binaries that you've generated in the correct location where you can run them from the command line. This script is usually run outside of the docker image since the image does not have adb installed by default, but can be run inside of the image if you're deploying over ssh instead of adb. Finally, Since you're building an opencv project, I'd strongly recommend that you look at our voxl-camera-calibration package. This is a very good example of how to use libmodal-pipe to get camera images, and then pass them off to opencv (in this case the calibration routines) for processing. The project also have fully flushed out versions of all of the aforementioned scripts that you can copy into your project as a good starting point.
  • voxl 2 flight deck with esc v2 few questions

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    bensusanaB
    @modaltb please if you can give me some info it will be much appreciate
  • HITL with voxl 2

    Unsolved
    24
    0 Votes
    24 Posts
    7k Views
    Tamas Pal 0T
    @Taylor-Presley Right. Some cables work some don't.