Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • OV7251 vs. OV9782 sensor

    Unsolved
    3
    0 Votes
    3 Posts
    662 Views
    E
    @Chad-Sweet thanks. Is there also a datasheet doc for M0113?
  • Information on creating a custom expansion PCB

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    Chad SweetC
    You can find the document here https://docs.modalai.com/expansion-design-guide/
  • VOXL2 GPIO Pin Layout

    Unsolved
    1
    0 Votes
    1 Posts
    351 Views
    No one has replied
  • VOXL2 ESC calibration using VOXL2 IO board and m500 frame

    Unsolved
    3
    0 Votes
    3 Posts
    760 Views
    J
    @Chad-Sweet Hey Chad! Yes 100% I'm open to the PC tools to get it done as well. I suppose I'm a bit uncertain about the hardware pipeline in this case. I'll want to have the traditional m500 ESC and motor, so I'll need to generate the PWM calibration curve somehow and generate the correct parameters. Should I use a surrogate m500 VOXL1 board to just get the values and run with those? -Joe
  • April Tag Relocalization with External Fight Controller

    Unsolved
    3
    0 Votes
    3 Posts
    791 Views
    A
    To conclude this post in the hope to help someone else who's having the same problem, I found this reply on another question in this forum which dates back to 2021. I guess the Relocalization still works only in Offboard and NOT in Mission. The same applies for an external flight controller e.g. in Ardupilot it works in Guided Mode and NOT in Auto.
  • voxl-camera-server sudendly crash m500

    Unsolved
    1
    3
    1 Votes
    1 Posts
    444 Views
    No one has replied
  • Starling 2 Inverted Yaw and Pitch

    Unsolved
    2
    -1 Votes
    2 Posts
    851 Views
    James StrawsonJ
    @Kashish-Garg-0 Yes, everything in the aerospace industry including PX4 and ardupilot use the standard NED coordinate frame with Z pointing down. A significant portion of the code in MAVROS seems to be flipping the direction of the Y and Z axis back and forth when converting from mavlink to ros topics. I suggest using the vvhub_body_wrt_local pipe instead of the qvio pipe as the qvio data is centered around the imu whereas voxl-vision-hub transforms this to be centered around the body (COG) and corrects for gravity alignment. You can inspect the local pose on VOXL natively with voxl-inspect-pose vvhub_body_wrt_local OR voxl-inspect-pose --local Note this pipe was called vvpx4_body_wrt_local in SDK0.9 and older. I don't think ROS libraries like TF2 care which way gravity points. A transform is a transform, you can have it oriented however you prefer when you do your math. You should only need to change coordinate frames for the sake of visualization if RVIS doesn't let you define a default orientation or rotate the ground plane around in the UI.
  • RB5 Flight Replacement ESC version?

    Unsolved
    2
    0 Votes
    2 Posts
    582 Views
    tomT
    @Sam-Kiley You'll want the standard M0117
  • This topic is deleted!

    2
    0 Votes
    2 Posts
    9 Views
  • My m500 doesn't connect to qground control

    Unsolved
    9
    3
    0 Votes
    9 Posts
    1k Views
    José QuintanillaJ
    @tom Thanks, I will try it
  • VIO "Q" (quality) metric and distant features

    Unsolved
    2
    0 Votes
    2 Posts
    559 Views
    Chad SweetC
    The code where quality is computed can be found here: https://gitlab.com/voxl-public/voxl-sdk/services/voxl-qvio-server/-/blob/master/server/quality.h
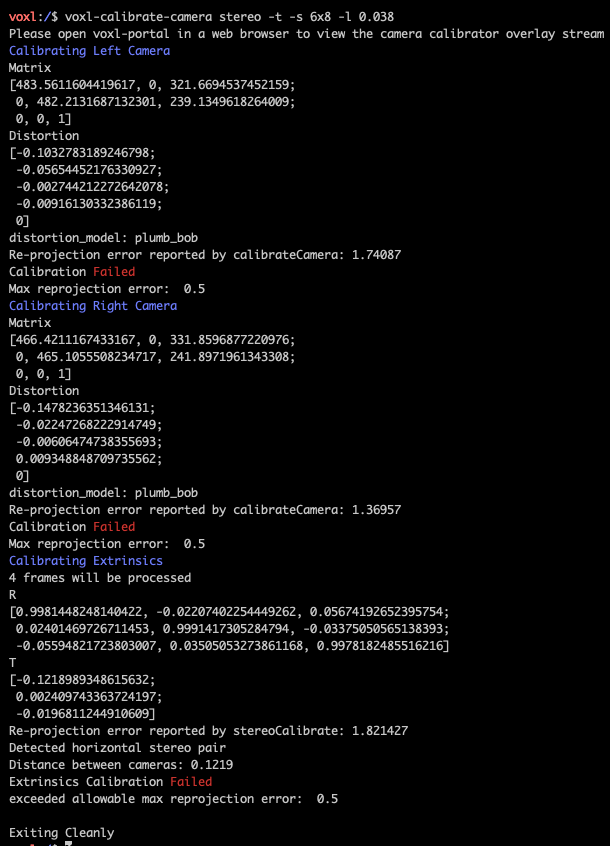
  • VOXL Calibrate Stereo Camera

    Unsolved
    2
    1
    0 Votes
    2 Posts
    646 Views
    Chad SweetC
    Your sensors need to be mounted co-planar and rigidly like you see in our drone and flight deck products
  • Static IP for Ethernet Adapter

    Unsolved
    1
    0 Votes
    1 Posts
    337 Views
    No one has replied
  • This topic is deleted!

    1
    1
    0 Votes
    1 Posts
    8 Views
    No one has replied
  • Multi tracking cam VIO

    Unsolved
    1
    0 Votes
    1 Posts
    418 Views
    No one has replied
  • Enable VOXL Portal on macOS

    Unsolved
    4
    1
    0 Votes
    4 Posts
    919 Views
    tomT
    @yx https://docs.modalai.com/platform-releases/#install
  • Configure camera on macOS

    Unsolved
    2
    0 Votes
    2 Posts
    591 Views
    modaltbM
    @yx the configuration isn't done on macOS. You need to get an SSH connection to VOXL or use adb to connect to a shell over adb, https://docs.modalai.com/setup-adb/
  • VOXL Portal Error

    Unsolved
    2
    1
    0 Votes
    2 Posts
    567 Views
    modaltbM
    @yx seens like the package manager link is out of date... e.g. this is last SDK http://voxl-packages.modalai.com/dists/apq8096/sdk-0.9/binary-arm64/ Perhaps easier to reflash with SDK 0.9.5 and go from there? https://docs.modalai.com/platform-releases/#install
  • Can't run voxl-qvio-server

    Unsolved
    7
    0 Votes
    7 Posts
    1k Views
    A
    @tom nevermind I found out the documentation here, and by reflashing the platform everything worked again! Thank you for the support!
  • No PWM output change in stabilized flight mode

    Unsolved
    4
    0 Votes
    4 Posts
    592 Views
    S
    @Eric-Katzfey I'll see if I can grab one here in a minute. Sorry, should mention it is going through a Voxl 2 IO board.