Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Hadron 640R integration with VOXL2 using Gremsy gimbal solution?

    Unsolved
    1
    0 Votes
    1 Posts
    496 Views
    No one has replied
  • GPS failing to display in QGroundControl from VOXL2

    Unsolved
    1
    0 Votes
    1 Posts
    407 Views
    No one has replied
  • Detaching voxl camera

    Unsolved
    1
    0 Votes
    1 Posts
    473 Views
    No one has replied
  • Payload Capacity of VOXL 2 Starling?

    Unsolved
    2
    0 Votes
    2 Posts
    656 Views
    ModeratorM
    @Brian-LeCocq The Starling 2 is not intended to carry a payload. The Starling 2 Max can carry 500g payload
  • Masking qVio

    Unsolved
    12
    0 Votes
    12 Posts
    4k Views
    D
    @Alex-Kushleyev said in Masking qVio: P5 160 120 255 ^@^@^@^@^@^@^ It is working now thanks. I have created mask in monochrome bmp and then used online tool to convert it into pgm but output had wrong header: P5 160 120 1 ^@^@^@^@^@^@^ I have used gimp now and exported with .pgm (binary) and it's working I put a preview mask on output image. [image: 1716379897238-d4604289-19d3-462f-99e3-89dcc788282c-image.png]
  • voxl-microdds-agent not installed on SDK1.2?

    Unsolved
    2
    0 Votes
    2 Posts
    480 Views
    tomT
    @Rowan-Dempster They've been released and are a part of the SDK but we just don't install them by default to save space. The .debs are onboard already and should install with an apt install In that context "blackisted" just means don't install by default.
  • Odd behavior from ModalAI 4 in 1 ESC

    Unsolved
    14
    0 Votes
    14 Posts
    3k Views
    Alex KushleyevA
    @Matthew-Wellner , As we discussed offline, I am going to post the summary for the likely issue here: By setting "demag_timing: 1" in esc params, it enabled some experimental feature, which fails to work correctly above certain rpm. It prevents motor from spinning faster when more power is applied (above a certain rpm). You can see from plots above, the desired command for motor 4 (purple) goes higher, but actual rpm is flat lined around 5700rpm (black). Also the current jumps up significantly for motor 4 (black) when it hits that ceiling. For your motor, please disable this "feature" by setting demag_timing to 0. Depending on your current timing advance, we may keep that the same or increase slightly. After disabling demag_timing-> 0, i would recommend performing rpm step tests to make sure the de-syncs still do not happen. I am sorry about this, I will update documentation to not recommend using this feature. [image: 1716325132668-9ac17b56-3431-408e-bd34-a7006eeb55ef-image.png] zoomed in [image: 1716325145165-c12f7747-3523-416b-8467-f462ee7b7561-image.png] Alex
  • Voxl-suite disappeared on Starling

    Unsolved
    3
    3
    0 Votes
    3 Posts
    724 Views
    tomT
    @viralp Behind the scenes "voxl-suite" is really just a meta package with dependencies on all of the debian packages in VOXL Suite. Therefore if any of the packages that voxl-suite depends on are modified (either removed or downgraded) then "voxl-suite" will no longer be installed. This includes the system image. Contained in the system image is another meta package called voxl2-system-image which is versioned the same as the System Image. Therefore if there is a system image / voxl-suite mismatch you will see the same effect. This isn't a major issue, it just means that you are straying from the exact package list defined by that version of VOXL Suite. If you would like to get to a known good state you download the latest SDK from our downloads page and install it with it's install.sh script
  • VOXL2 - HITL/VIO

    Unsolved
    14
    4
    0 Votes
    14 Posts
    3k Views
    Eric KatzfeyE
    @leonardo-Andrade-0 For the case where you are using only GPS and MAG the parameters need to reflect that. SYS_HAS_GPS = 1, SYS_HAS_MAG = 1, EKF2_MAG_TYPE = 0.
  • Image streaming slowdown when using voxl-mpa-to-ros2

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    C
    @Alex-Kushleyev Great, I will look into transferring compressed images. Thanks for the guidance!
  • Unable to subscribe to vehicle_command_position topic

    Unsolved
    3
    1
    0 Votes
    3 Posts
    1k Views
    B
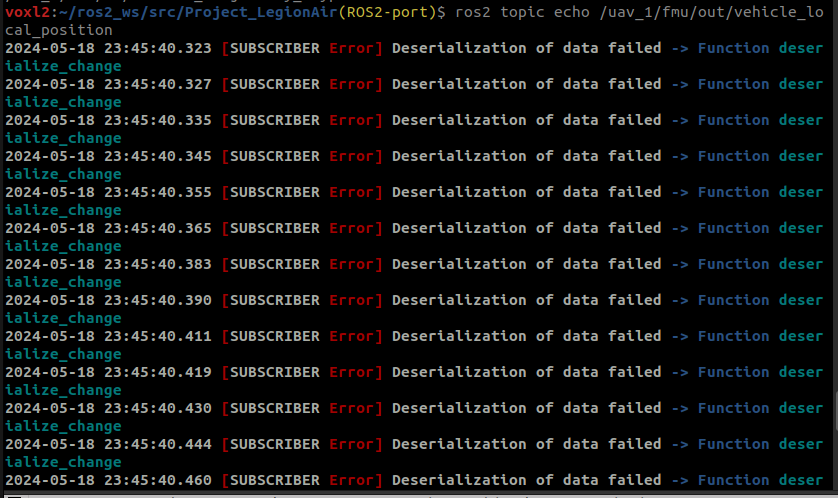
    @Darshit-Desai Here is the output from echo'ing local position. voxl2:~/colcon_ws$ ros2 topic list /fmu/in/obstacle_distance /fmu/in/offboard_control_mode /fmu/in/onboard_computer_status /fmu/in/sensor_optical_flow /fmu/in/telemetry_status /fmu/in/trajectory_setpoint /fmu/in/vehicle_attitude_setpoint /fmu/in/vehicle_command /fmu/in/vehicle_mocap_odometry /fmu/in/vehicle_rates_setpoint /fmu/in/vehicle_trajectory_bezier /fmu/in/vehicle_trajectory_waypoint /fmu/in/vehicle_visual_odometry /fmu/out/failsafe_flags /fmu/out/position_setpoint_triplet /fmu/out/sensor_combined /fmu/out/timesync_status /fmu/out/vehicle_attitude /fmu/out/vehicle_control_mode /fmu/out/vehicle_local_position /fmu/out/vehicle_odometry /fmu/out/vehicle_status /parameter_events /rosout voxl2:~/colcon_ws$ ros2 topic echo /fmu/out/vehicle_local_position timestamp: 1716299017260605 timestamp_sample: 1716299017259933 xy_valid: false z_valid: true v_xy_valid: false v_z_valid: true x: -0.015882886946201324 y: -0.006520443130284548 z: 3.26619815826416 delta_xy: [-9.292006097894046e-08, -1.9959152552928572e-07] xy_reset_counter: 1 delta_z: 0.0 z_reset_counter: 1 vx: 0.0007984319818206131 vy: -0.001192234456539154 vz: 0.006735446862876415 z_deriv: 0.014136962592601776 delta_vxy: [-1.0643154382705688e-05, -2.2861408069729805e-05] vxy_reset_counter: 1 delta_vz: 1.583993434906006e-05 vz_reset_counter: 1 ax: 0.042993903160095215 ay: -0.06323475390672684 az: -0.10127022862434387 heading: -0.12067540735006332 delta_heading: 0.0 heading_reset_counter: 0 heading_good_for_control: false xy_global: false z_global: false ref_timestamp: 0 ref_lat: .nan ref_lon: .nan ref_alt: .nan dist_bottom: 0.10000000149011612 dist_bottom_valid: false dist_bottom_sensor_bitfield: 0 eph: 0.012850395403802395 epv: 0.3351651430130005 evh: 0.04047877714037895 evv: 0.06853056699037552 dead_reckoning: true vxy_max: .inf vz_max: .inf hagl_min: .inf hagl_max: .inf --- Voxl version system-image: 1.7.4-M0054-14.1a-perf kernel: #1 SMP PREEMPT Fri Feb 9 21:59:24 UTC 2024 4.19.125 -------------------------------------------------------------------------------- hw platform: M0054 mach.var: 1.0 -------------------------------------------------------------------------------- voxl-suite: 1.1.3-1 Packages: Repo: http://voxl-packages.modalai.com/ ./dists/qrb5165/sdk-1.1/binary-arm64/ Last Updated: 2024-05-21 13:30:13 List: kernel-module-voxl-fsync-mod-4.19.125 1.0-r0 kernel-module-voxl-gpio-mod-4.19.125 1.0-r0 kernel-module-voxl-platform-mod-4.19.125 1.0-r0 libmodal-cv 0.4.0 libmodal-exposure 0.1.0 libmodal-journal 0.2.2 libmodal-json 0.4.3 libmodal-pipe 2.9.2 libqrb5165-io 0.4.2 libvoxl-cci-direct 0.2.1 libvoxl-cutils 0.1.1 mv-voxl 0.1-r0 qrb5165-bind 0.1-r0 qrb5165-dfs-server 0.2.0 qrb5165-imu-server 1.0.1 qrb5165-rangefinder-server 0.1.1 qrb5165-slpi-test-sig 01-r0 qrb5165-system-tweaks 0.2.6 qrb5165-tflite 2.8.0-2 voxl-bind-spektrum 0.1.0 voxl-camera-calibration 0.5.3 voxl-camera-server 1.8.9 voxl-ceres-solver 2:1.14.0-10 voxl-configurator 0.5.2 voxl-cpu-monitor 0.4.7 voxl-docker-support 1.3.0 voxl-elrs 0.1.3 voxl-esc 1.4.0 voxl-feature-tracker 0.3.2 voxl-flow-server 0.3.3 voxl-fsync-mod 1.0-r0 voxl-gphoto2-server 0.0.10 voxl-gpio-mod 1.0-r0 voxl-jpeg-turbo 2.1.3-5 voxl-lepton-server 1.2.0 voxl-libgphoto2 0.0.4 voxl-libuvc 1.0.7 voxl-logger 0.3.5 voxl-mavcam-manager 0.5.3 voxl-mavlink 0.1.1 voxl-mavlink-server 1.3.2 voxl-microdds-agent 2.4.1-0 voxl-modem 1.0.8 voxl-mongoose 7.7.0-1 voxl-mpa-to-ros 0.3.7 voxl-mpa-to-ros2 0.0.2 voxl-mpa-tools 1.1.3 voxl-neopixel-manager 0.0.3 voxl-open-vins 0.4.4 voxl-open-vins-server 0.2.18 voxl-opencv 4.5.5-2 voxl-platform-mod 1.0-r0 voxl-portal 0.6.3 voxl-px4 1.14.0-2.0.63 voxl-px4-imu-server 0.1.2 voxl-px4-params 0.3.3 voxl-qvio-server 1.0.0 voxl-remote-id 0.0.9 voxl-ros2-foxy 0.0.1 voxl-streamer 0.7.4 voxl-suite 1.1.3-1 voxl-tag-detector 0.0.4 voxl-tflite-server 0.3.1 voxl-utils 1.3.8 voxl-uvc-server 0.1.6 voxl-vision-hub 1.7.3 voxl2-system-image 1.7.4-r0 voxl2-wlan 1.0-r0 -------------------------------------------------------------------------------- px4_msgs branch voxl2:~/colcon_ws/src/px4_msgs(release/1.14)$ git branch * release/1.14
  • Operational range of the VOXL 2 mini

    Unsolved
    13
    0 Votes
    13 Posts
    3k Views
    VinnyV
    Hi @Bilal-Hussain Please see our docs specifically for Doodle Labs here: https://docs.modalai.com/doodle-labs-user-guide/ VOXL2 Mini cannot use any of the plug-in boards noted above in that table. The VBUS is very limited and will require your Doodle to use an external power supply sourced from your battery. Thanks!
  • Voxl-Mapper pipe to ROS2

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    Jeffrey MaoJ
    Nevermind I figured it out. Once the voxl_mapper service is running it is automatically configured to run the voxl_mpa_ros2 as a pointcloud
  • Calibrating Stereo Cams for DFS

    Unsolved
    1
    0 Votes
    1 Posts
    381 Views
    No one has replied
  • Something wrong with my Starling

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    ModeratorM
    @Darshit-Desai what do those do when you're flying? Sitting on the ground isn't really stressing the system
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    233 Views
    No one has replied
  • 0 Votes
    5 Posts
    1k Views
    ModeratorM
    @Gary-Holmgren is your checkerboard mounted perfectly flat on a very stiff backing? If there is any inconsistencies in the checkerboard it can cause issues
  • Starling 2 charging while powered on

    Unsolved
    6
    0 Votes
    6 Posts
    1k Views
    J
    @Vinny no problem for now I didn't try to charge it while being used it was just a question. Julien
  • VOXL2 microdds agent namespace

    Unsolved
    8
    0 Votes
    8 Posts
    2k Views
    Darshit DesaiD
    @Eric-Katzfey I know this is a question for the px4 forum, but can you guys help me figure out how to run the https://github.com/PX4/px4_ros_com/blob/main/src/examples/offboard/offboard_control_srv.cpp service server here. I changed the namespace for my microdds client as you know and I am not sure if that service server is running or not, I can't find the server when I do ros2 service list or ros2 service find
  • Use SPI as UART with VOXL2 board

    Unsolved voxl2 uart device tree drivers
    7
    0 Votes
    7 Posts
    2k Views
    L
    @modaltb Hey Travis, Thank you very much for your explanation and for passing on the link. I understand how it was done now. I will consider what is the next possible option for the project.   I appreciate your time. Best Regards, Leon