Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • voxl-streamer through IPv6

    Unsolved
    2
    0 Votes
    2 Posts
    717 Views
    Eric KatzfeyE
    Unfortunately, we have never tried anything but IPv4, and don't really have much of any experience using IPv6 in general.
  • Can't find April tag settings in system image 3.3.0

    Unsolved
    2
    1
    0 Votes
    2 Posts
    418 Views
    ?
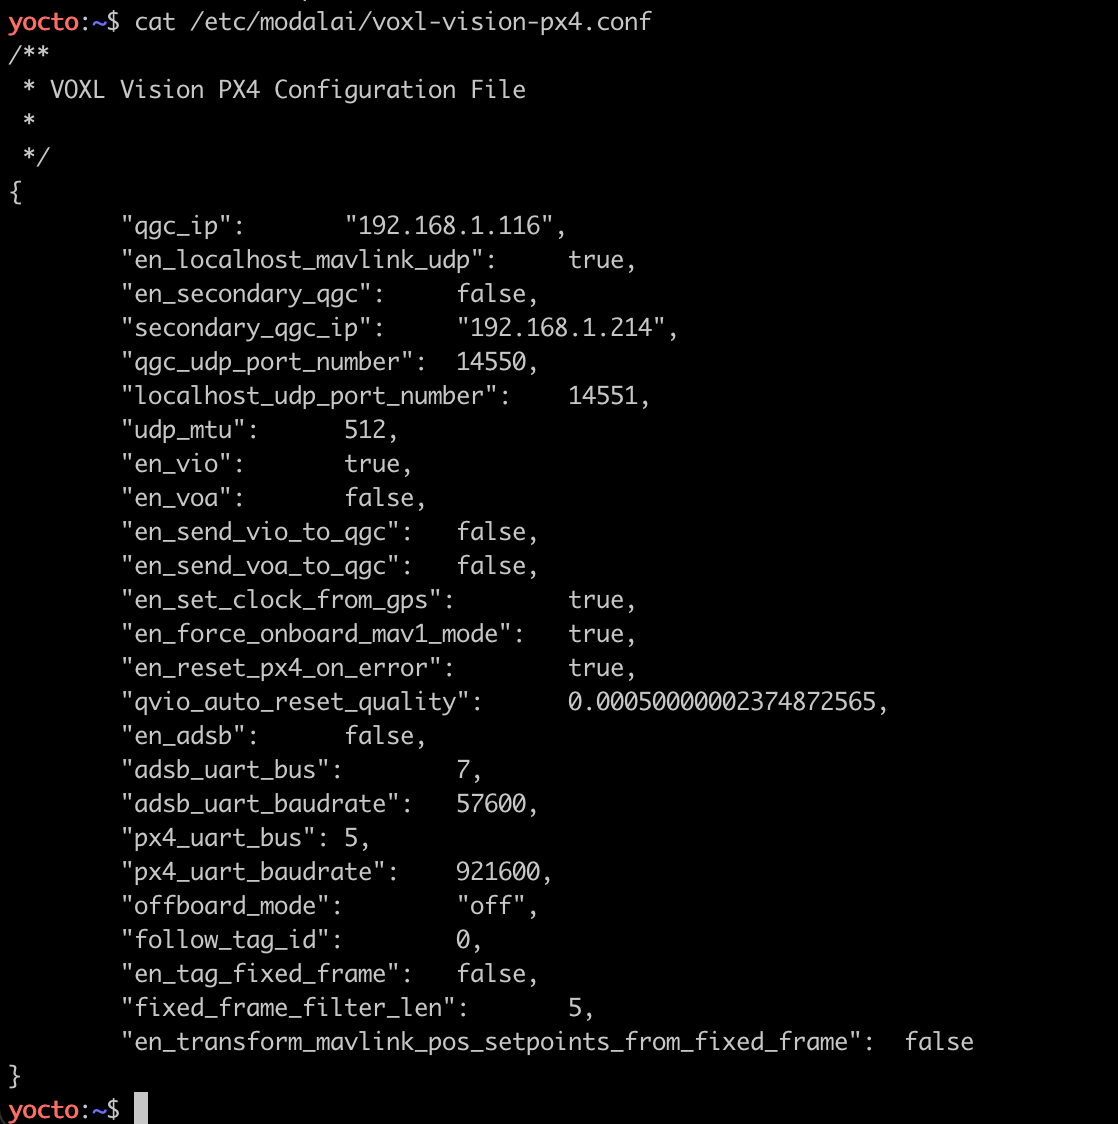
    The vvpx4 option is the second to last one there: "en_tag_fixed_frame". In order to use tag localization, make sure the voxl-tag-detector service is running. The config file for this is at /etc/modalai/voxl-tag-detector.conf and you can specify the tag locations at /etc/modalai/tag_locations.conf
  • Error in building voxl-build

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    tomT
    Great, thank you!
  • 0 Votes
    10 Posts
    2k Views
    modaltbM
    Hi @DarkKnightCH , It's likely something you can setup in your transmitter, or perhaps reset the transmitter to default state. What make and model do you have?
  • Documentation clarification in Camera IMU coordinate frames

    Unsolved
    2
    0 Votes
    2 Posts
    607 Views
    Chad SweetC
    That page needs to be updated. The concepts are good but that xml format is out of date. So, voxl-configure-extrinsics is likely the right approach for changing the values We will try to get that page updated in the next day or two to be more clear
  • How to Power Xavier boards from VOXL?

    Unsolved
    2
    0 Votes
    2 Posts
    484 Views
    Chad SweetC
    We have never used a Xavier, sorry
  • 0 Votes
    1 Posts
    417 Views
    No one has replied
  • Why VOXL-M500 choose Spektrum satellite receiver as the receiver?

    Unsolved
    2
    0 Votes
    2 Posts
    693 Views
    modaltbM
    Hi @DarkKnightCH , We offer other receivers to be installed on the m500 as well, but roughly: weight and size, indoor flying was a primary first use case, spectrum is good for that. For outdoor it works but the range isn’t great, so you could use another receiver. The satellite receiver 100 percent works as we’ve shipped hundreds in this config, but please choose from the options that fit your need for longer range. If you need BVLOS, consider LTE instead, but you should be savvy to setup a VPN server! No main reciever needed. The satellite receiver is put into binding mode via a button in QGC. We’ve bound hundreds of vehicles this way. After pressing the button, the reciever flashes it’s LED quickly to indicate it’s in binding mode. Please note, there are knock offs “spektrums” in the world that may not work.
  • Position Drift in Outdoor GPS Flight (non-VIO)

    Unsolved
    2
    0 Votes
    2 Posts
    584 Views
    B
    Here is a link to my .param file: https://drive.google.com/file/d/14DA0fQ8Q4PowwlFXMUfU_w1wteXpM9rk/view?usp=sharing
  • Autonomous Gimbal Clarification

    Unsolved
    5
    0 Votes
    5 Posts
    1k Views
    Chad SweetC
    We do plan to bring the gimbal version back to life, hopefully by the end of the year. We have other, higher priority, products in the pipeline right now.
  • Connecting VOXL to Jetson NX

    Unsolved
    7
    0 Votes
    7 Posts
    2k Views
    PawelJP
    Thanks, I just wanted to check if I was totally off track. I'll let you know how it goes, the potential of over the air adb updates are very tantalizing
  • Where is apriltag relocalization used in control error signal?

    Unsolved
    2
    0 Votes
    2 Posts
    797 Views
    PawelJP
    Where does the april tag localization change the drone position being sent to the pixhawk to affect the error signal of target-position? I will need to use this position so I can correctly offset my path starting point The setpoints are are sent to uart_mavlink.c where they are transformed by geometry_transform_fixed_setpoints_to_local where the april tag transformation matrix is used to convert from fixed to local frame, which is sent off to the pixhawk. If no april tags are used local_frame == fixed_frame Does the px4 expect path in the same reference frame as vio state (ie position in world coordinates, velocities in body frame?) px4 expects setpoints in local frame, but offboard figure eight assumes they are set in fixed frame (see above). Please correct me if I am wrong here. Cheers
  • snav fails to find libsensor_imu.so

    Unsolved
    10
    1
    0 Votes
    10 Posts
    2k Views
    L
    I see! Yes after changing this params I can calibrate the imu now with snav!! Thanks for your help!
  • Clarification on px4 home position in vvpx4

    Unsolved
    1
    0 Votes
    1 Posts
    540 Views
    No one has replied
  • Is it possible to know the thrust of the quadcopter?

    Unsolved
    2
    0 Votes
    2 Posts
    739 Views
    D
    Also, is it possible to log the IMU data of PX4? Will you provide some library functions to implement that?
  • This topic is deleted!

    2
    0 Votes
    2 Posts
    8 Views
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    5 Views
    No one has replied
  • Gimbal commands

    Unsolved
    3
    0 Votes
    3 Posts
    586 Views
    modaltbM
    @Daniel-Ryu , here's a possibility: https://docs.modalai.com/voxl-m500-gimbal-user-guide/#mavsdk-behavior-with-mavlink This gimbal is fairly simple, the stabilization occurs on bootup automatically only.
  • Can't get QGroundControl to connect

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    P
    @Alex-Gardner thank you. I'll head down that path with ROS. Any readmes/docs/guidance on how I can extract the telemetry/pose data via UART(J10)? I have the hardware connected, but a bit lost on where to start. Would it be easier if I added the Flight Core to the VOXL to get the telemetry ports J4/J5? Is Flight Core required to allow qGroundControl to connect to VOXL? Thanks.
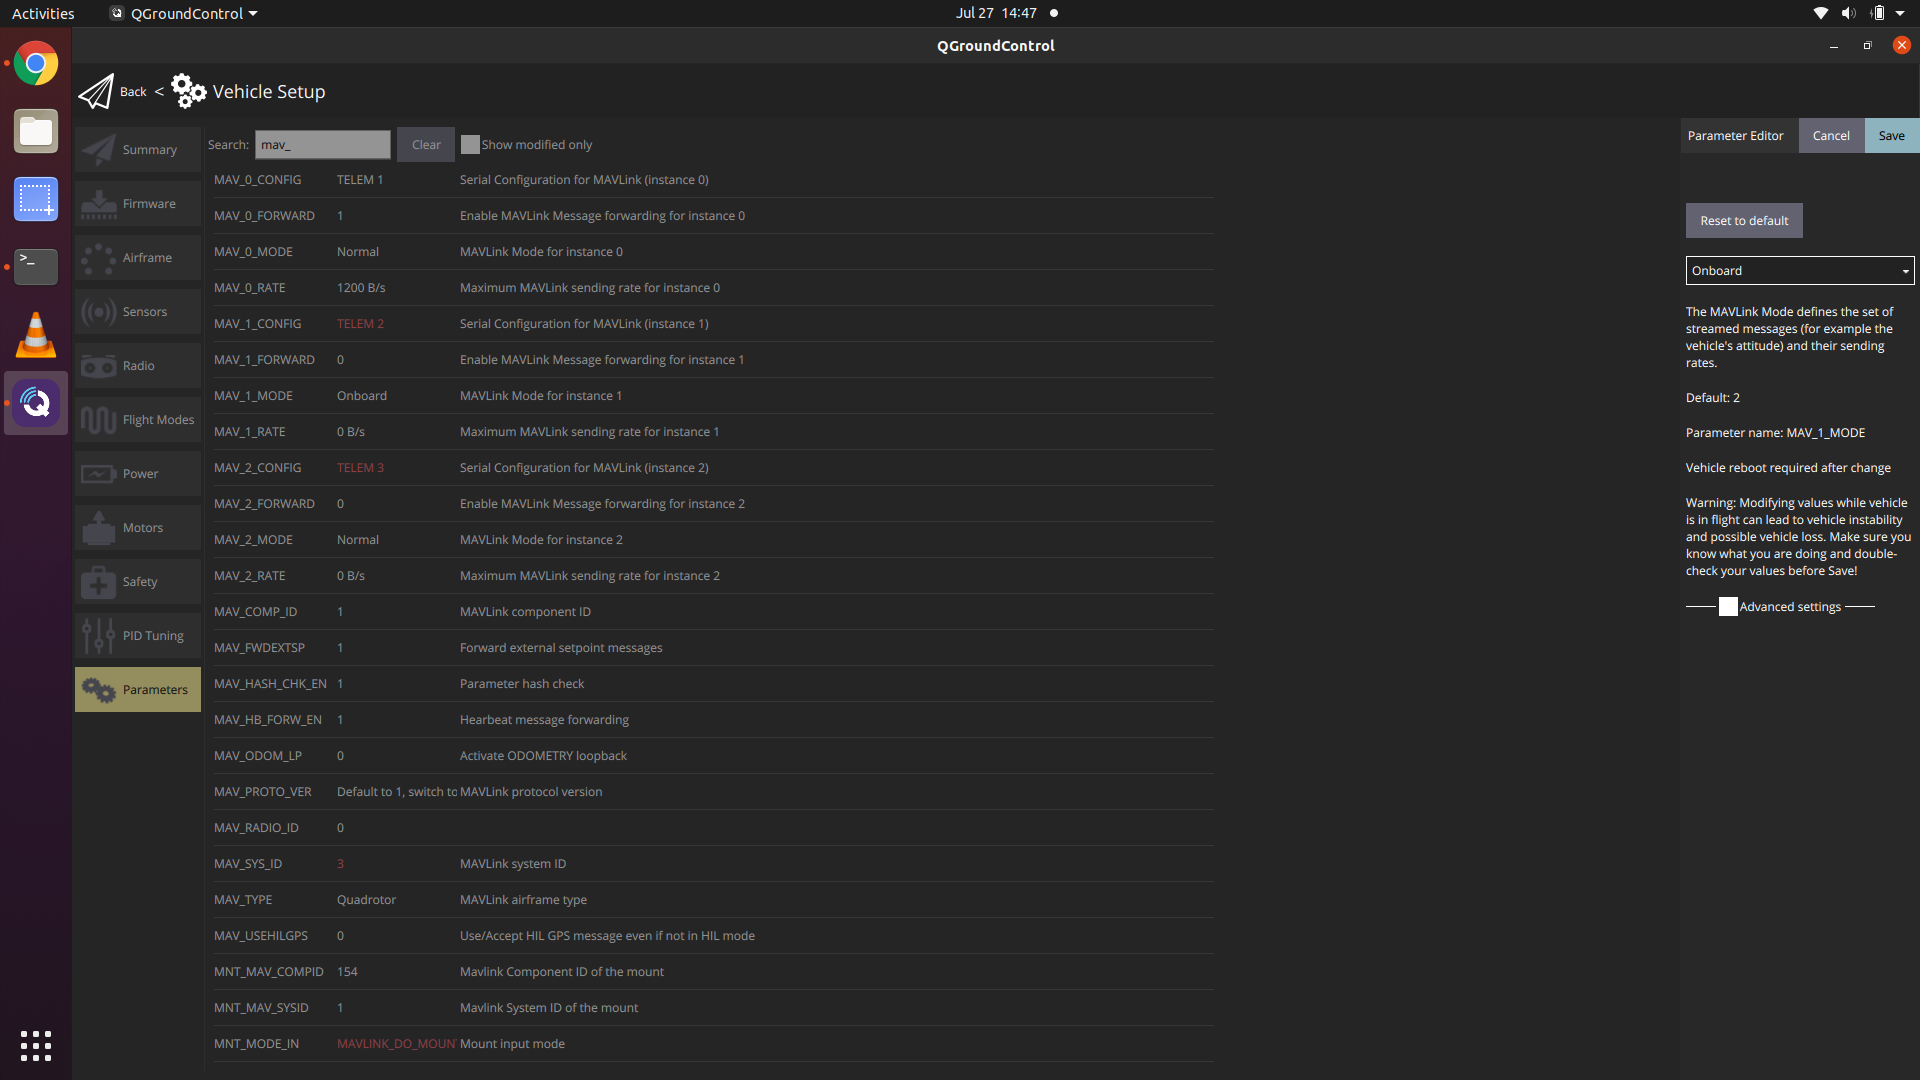
  • MAV_1_MODE not changing from Onboard on QGC

    Unsolved
    2
    1
    0 Votes
    2 Posts
    511 Views
    modaltbM
    If you have an M500, it contains either a VOXL Flight, and there's an internal UART from the PX4 processor (STM32F7) to the Snapdragon processor running linux. This is setup on MAV1, and if changed would halt comms between the two systems. https://github.com/PX4/PX4-Autopilot/blob/master/boards/modalai/fc-v1/init/rc.board_defaults#L23