Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • FC v2 Collision prevention issue with voxl 2

    Unsolved
    19
    0 Votes
    19 Posts
    3k Views
    Eric KatzfeyE
    @Jetson-Nano Can you rebuild to add UAVCAN? The code is here: https://github.com/modalai/px4-firmware/tree/v1.14.0-2.0.133-dev
  • UAVCAN error in FC v2 px4 firmware

    Unsolved
    5
    0 Votes
    5 Posts
    671 Views
    Jetson NanoJ
    @Eric-Katzfey UAVCAN is working in the latest versions, when enabled. And yes I meant heading error, thats my mistake. The collision prevention is the major issue I am having. The heading error is in the latest version, and I also came across it in the issues section and it was shown solved, but I did not test it out still with VIO, I was testing with only Optical flow and it was not working.
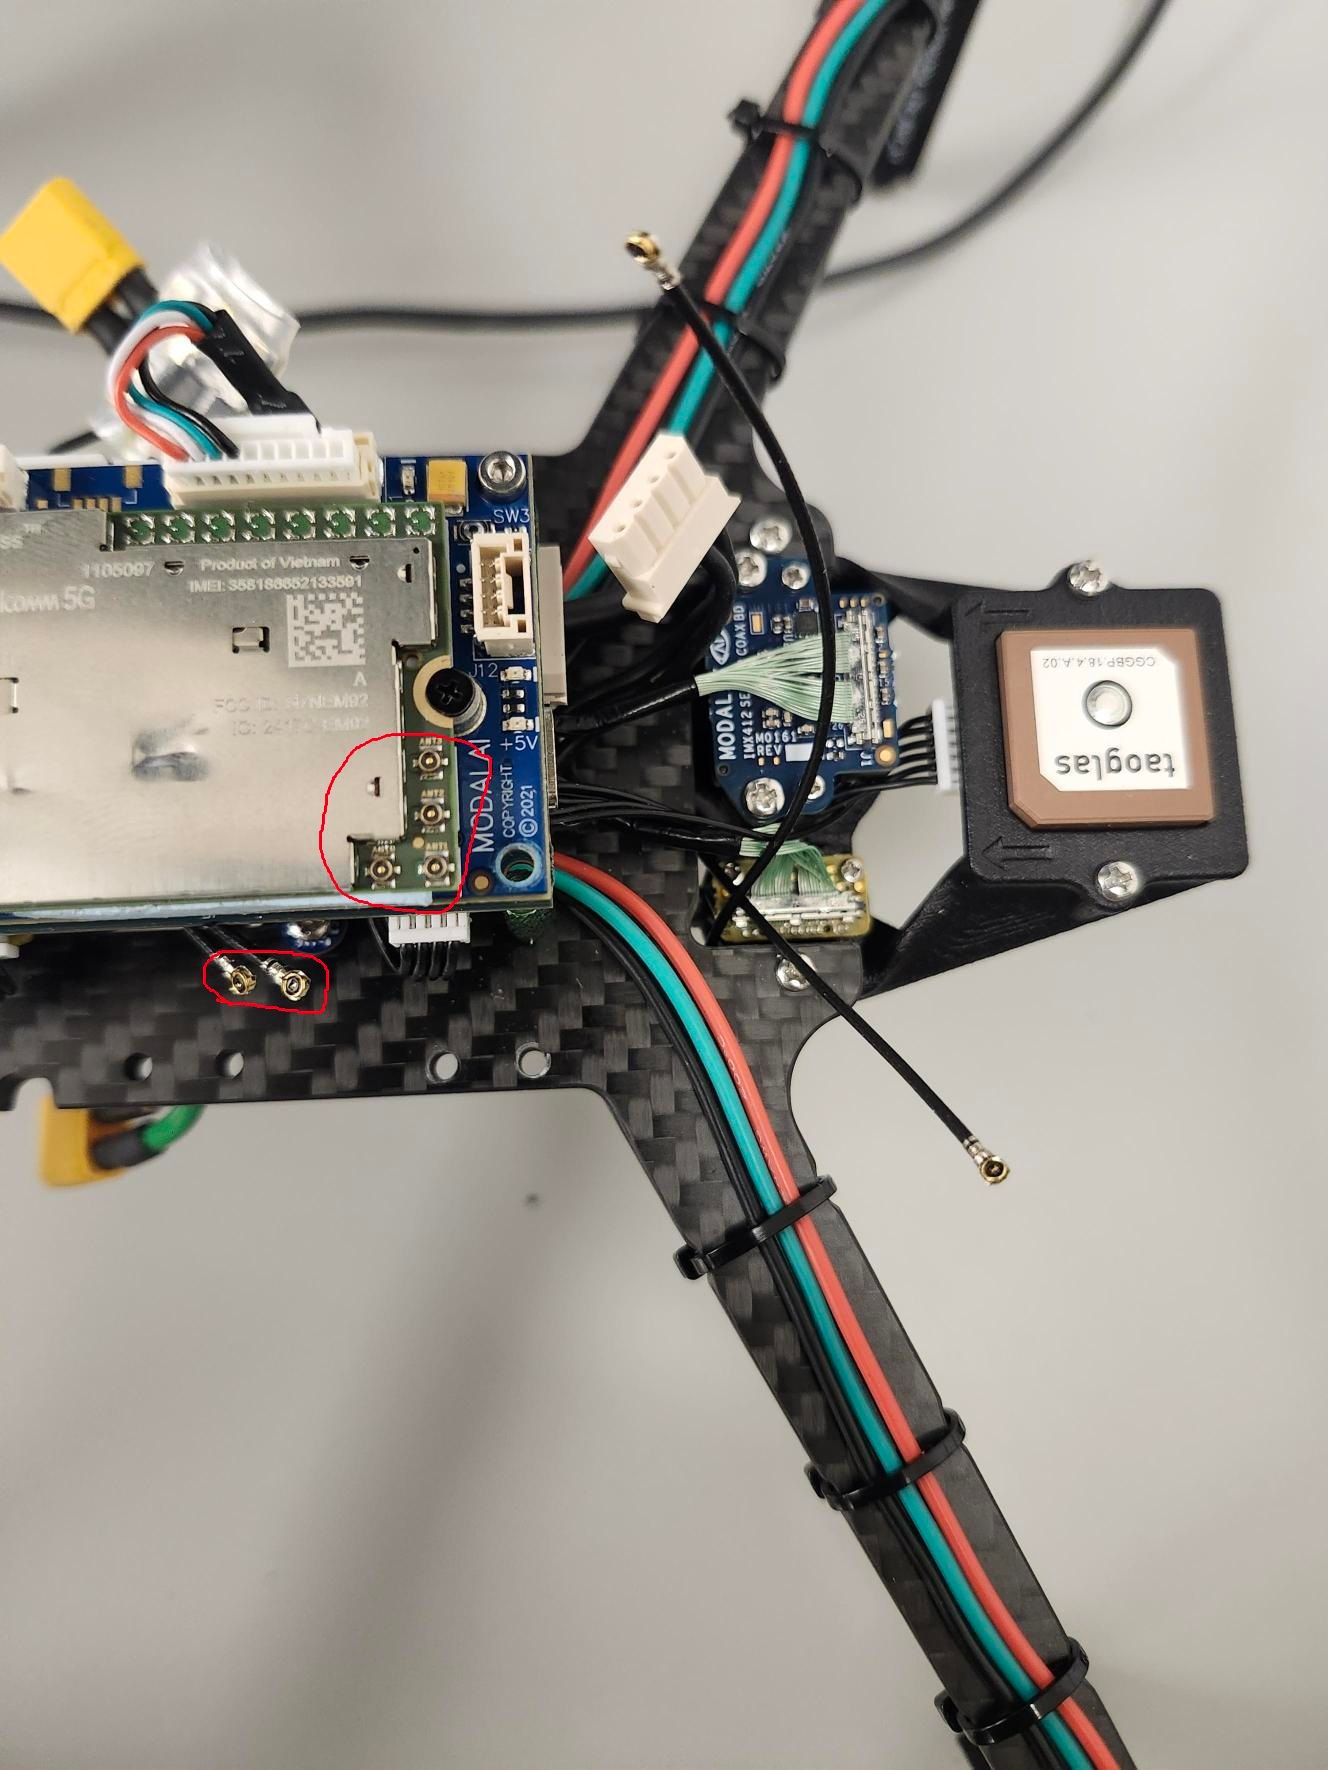
  • 5G Antenna Replacement Kit MRP-D0004-1-06

    Unsolved
    1
    1
    0 Votes
    1 Posts
    754 Views
    No one has replied
  • Microhard pDDL Carrier stopped working

    Unsolved
    10
    0 Votes
    10 Posts
    1k Views
    VinnyV
    @gerard I also just remembered we had a stint of bad MCBL-00010's a few months ago... We have since cleared that up, but there is no telling how long ago you may have ordered that cable... Please see this thread for guidance and if you do think your MCBL-00010 is at fault, we will replace your M0048, just reference both threads in your RMA (this one and this one -->) https://forum.modalai.com/topic/4632/flight-core-2-firmware-update-through-qgc?_=1781284416780
  • VOXL2 and QGC via USB Connection Issues

    Unsolved
    4
    0 Votes
    4 Posts
    381 Views
    nickanickN
    @Eric-Katzfey We reinstalled the QGC in a new laptop and it is working fine now.
  • VOXL2 USB Host Port J18 Not initializing

    Unsolved
    9
    0 Votes
    9 Posts
    744 Views
    nickanickN
    @Eric-Katzfey We are experiencing connection issues between VOXL2 and QGC. QGroundControl is showing disconnected after inputting the comms link with 192.168.7.2:14550 in UDP. mavlink_to_gcs and mavlink_from_gcs are both reporting data. voxl-px4 and voxl-mavlink-server are running. voxl-my-ip 192.168.7.2 (usb0)
  • Starling 2 max Not detecting Wifi hardware

    Unsolved
    6
    0 Votes
    6 Posts
    795 Views
    tomT
    @vmbasvi That appears to be a Microhard modem, not a WiFi dongle.
  • Additional PWN Connection Recommendation For VOXL2/IO - IO Currently Full

    Unsolved
    3
    0 Votes
    3 Posts
    304 Views
    M
    @Alex-Kushleyev At a bare minimum I just need the additional pwn channels to be controlled by joysticks via QGC. They don't need to be connected to PX4/Autopilot at this point. Does this allow for an easier solution? Thanks! Matt
  • 0 Votes
    2 Posts
    141 Views
    Alex KushleyevA
    @j-angel , We had a small batch of color AR0144, but those have run out and due to low demand, we do not have any stock. I would like to clarify something. Motion blur is present when using any camera (global shutter or rolling shutter). Global shutter cameras also have exposure control and long exposure times will cause motion blur. I think what you may be referring to, which is different in rolling shutter cameras (compared to global shutter), is the rolling shutter skew. Rolling shutter cameras use a technique where the start of exposure of each image row is offset slightly, so each row is essentially exposed over a different time frame. The offset is usually very small (4-30 microseconds per line, depends on the camera, mode), but from top to bottom, the rolling shutter effect can add up and be visible when there are moving features in the scene. The fastest rolling shutter camera we have right now is IMX412 and in the 2x2 binning mode, the 1920x1080 resolution, the total frame readout time is 4ms. (https://docs.modalai.com/camera-video/low-latency-video-streaming/#camera-pipeline-latency-in-different-operating-modes). This means that the difference of the center of exposure between the first and last image row is 4ms. Considering the information above, 4ms can seem a lot, but keep in mind that is the time delay across the whole image. depending on the size of features, the rolling shutter effect across a smaller image area will be smaller. Using the height of 1080, we can compute the time offset for each line, 4ms / 1080 ~ 4us. Depending on the size of features that are being tracked, the rolling shutter may not create a lot of local skew. Additionally, the camera timing is deterministic, so it is possible to calculate the time offset of the center of exposure of each line (with respect to the first line). If you want to provide some more details on type of perception, I could provide more guidance. Unfortunately, right now, we do not have a color global shutter camera option. Alex
  • VOXL 2 and WIFI Dongle

    Unsolved
    2
    0 Votes
    2 Posts
    361 Views
    Alex KushleyevA
    @nickanick , can you please clarify which exact WIFI Dongle you would like to use?
  • voxl-slpi-uart-bridge

    Unsolved
    2
    0 Votes
    2 Posts
    140 Views
    Eric KatzfeyE
    @jon You can use a J19 UART from the apps processor. Take a look at the code in voxl-elrs (https://gitlab.com/voxl-public/voxl-sdk/utilities/voxl-elrs/-/tree/dev?ref_type=heads), specifically the file src/elrs_slpi.c. This project accesses SLPI UARTs from an AP userspace process through voxl_io, not through POSIX termios. You cannot have a flight controller running at the same time though so PX4 / ArduPilot / etc. would need to be stopped first.
  • voxl-px4 startup failure - parameter_client_set_value timeout

    Unsolved
    6
    0 Votes
    6 Posts
    318 Views
    Eric KatzfeyE
    @jon When running that way make sure you wait a few seconds before restarting. If you ctrl-c out of voxl-px4 and immediately restart voxl-px4 you will see that error condition.
  • LTE Modem v2 Pro

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    tomT
    @Michael-Hatton Did you run through the voxl-configure-modem setup in order to configure APN, etc? https://docs.modalai.com/voxl-modem/#usage
  • Starling 2 Max GPS - denied Development Drone Batteries

    Unsolved
    2
    0 Votes
    2 Posts
    149 Views
    Eric KatzfeyE
    @Michael-Hatton Yes, you need to have a separate battery charger. I'll see if I can get a recommendation from the team on a good charger to use. I use a Hota D6 Pro, personally.
  • Image Stabilization calibration and pipe size clarification

    Unsolved
    14
    0 Votes
    14 Posts
    2k Views
    J
    @Alex-Kushleyev Aha yes that was my original understanding. Yes knew you'd need a zoom level for it to actually look good/work effectively. Would probably have a lower bound of 1.2-1.3 likely from what I experimented with. TBD on dimensions. Sorry, was confused, sounds good!
  • voxl-microdds-agent for connection to external fcu over uart (J10)

    Unsolved
    4
    0 Votes
    4 Posts
    357 Views
    Eric KatzfeyE
    @jon And you can find a lot of detailed information about the agent, including the start options, here: https://docs.px4.io/main/en/middleware/uxrce_dds
  • Powering Starling 2 Max

    Unsolved
    2
    0 Votes
    2 Posts
    1k Views
    Eric KatzfeyE
    @Michael-Hatton When you arm the drone it is in flight mode and the motors start to spin. It's that spinning of the motors that you don't want while plugged into a power supply. Only use your battery to actually spin the motors and fly.
  • How to install LTE Modem v2 Pro

    Unsolved
    1
    0 Votes
    1 Posts
    743 Views
    No one has replied
  • Existing stock / second-hand sellers of Starling Max 2

    Unsolved
    1
    0 Votes
    1 Posts
    185 Views
    No one has replied
  • Voxl2 + M0041 RevB Battery Monitor on Arducopter

    Unsolved
    11
    0 Votes
    11 Posts
    776 Views
    Dan JenningsD
    @Eric-Katzfey I'm not sure what may have changed, before when setting BATT_MONITOR to 21 the param would write but we wouldn't get the additional parameters that that setting should have enabled. Last week I tried it again to reply to your last message and we got the BATT_I2C_BUS parameter and were able to get it all working. Gotta love when things seem to magically fix themselves, thanks for the support. PS, we have built a parallel system on the latest SDK and will be migrating the current one over to match.