Skip to content

General Questions

2.3k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • How do Framework customers get component origin documentation?

    Unsolved
    1
    0 Votes
    1 Posts
    137 Views
    No one has replied
  • Binding Problem Starling2Max with Radiomaster Boxer

    Unsolved
    5
    0 Votes
    5 Posts
    433 Views
    Ben LinneB
    @heiko.lizan Any elrs radio that's 900mhz or dual band compatible should work when in low band mode. If the transmitter is running v4+ you should be able to downgrade it to v3 following the elrs update guide It's normal that some services aren't running. You may need to re-enable px4 with systemctl enable voxl-px4
  • 0 Votes
    1 Posts
    125 Views
    No one has replied
  • Pre-purchase inquiry: Starling 2 Max Hardware Revisions (V4/GPS) & ROS2 Integration

    Unsolved
    2
    0 Votes
    2 Posts
    755 Views
    D
    I hope you get an answer. They seem to be pretty unresponsive. It seems like a compelling platform, but when I reached out to contact@modalai to ask if the unit operates safely with the current GPS (I thought it was a pretty benign request), they just directed me to the forum. I'm not holding my breath on a response.
  • VOXL2 + VOXL ESC FPV 4-in-1, voxl-suite 1.6.3 — battery_status never published

    Solved
    27
    0 Votes
    27 Posts
    2k Views
    Alex KushleyevA
    OK, thanks for checking. maybe there was a typo before
  • 0 Votes
    11 Posts
    2k Views
    Alex KushleyevA
    @zaimin78 , It looks like I got this working. I modified the kernel to do the following not use the combo mode for J6L and allow using J6U as independent camera GPIO109 is used as a shared reset for cameras in slot 1 and 3 (because that's how the signal routing works on VOXL2 + M0135), so the kernel knows that this reset pin is shared this setup is not set up for camera sync - all cameras are running independently I have not tested any cameras in J8U, it may not work - but it should be possible to enable it, just need to test it. You will need to update the kernel on your voxl2: https://storage.googleapis.com/modalai_public/temp/quad_ov7251_boson/qti-ubuntu-robotics-image-m0054-boot-quad-ov7251.img this kernel is based off the kernel that ships with SDK 1.6.3 you can test it before overwriting the current kernel: https://docs.modalai.com/voxl2-kernel-build-guide/#test -- you should do to reduce the chance of bricking your VOXL2 (just in case) HW Configuration: VOXL2 four OV7251 plugged in to J6L. J6U, J7L, J7U via two M0135 adapters without any mods boson320 plugged into J8L via M0194 (you can use M0181 also) there are no shared CCI buses between the ov7251 cameras - slots 0-3 use CCI 0-3 respectively, so no CCI slave address conflicts SW configuration appropriate sensormodules placed into /usr/lib/camera/ -- you can get them from /usr/share/modalai/chi-cdk/ov7251 and ../boson folders: com.qti.sensormodule.ov7251_0.bin com.qti.sensormodule.ov7251_1.bin com.qti.sensormodule.ov7251_2.bin com.qti.sensormodule.ov7251_3.bin com.qti.sensormodule.boson_4.bin use provided voxl-camera-server.conf : https://storage.googleapis.com/modalai_public/temp/quad_ov7251_boson/voxl-camera-server-quad-ov7251-boson.conf may need to modify your Boson resolution from 320x256 to 640x512 if you you have Boson640 Testing after you have all the cameras connected, boot using the test kernel test to see if all cameras are detected: voxl-camera-server -l ... DEBUG: Cam idx: 0, Cam slot: 0, Slave Address: 0x00E2, Sensor Id: 0x7750 DEBUG: Cam idx: 1, Cam slot: 1, Slave Address: 0x00E2, Sensor Id: 0x7750 DEBUG: Cam idx: 2, Cam slot: 2, Slave Address: 0x00E2, Sensor Id: 0x7750 DEBUG: Cam idx: 3, Cam slot: 3, Slave Address: 0x00E2, Sensor Id: 0x7750 DEBUG: Cam idx: 4, Cam slot: 4, Slave Address: 0x00D4, Sensor Id: 0x00FF ... start voxl-camera-server inspect sterams: voxl-inspect-cam ov7251_0 ov7251_1 ov7251_2 ov7251_3 boson [image: 1785341477366-ee693f10-dcf2-4b76-8181-a11a78db9546-image.jpeg] Please give it a shot and let me know if it works! Alex
  • Questions on Starling 2 Max

    Unsolved
    6
    1
    0 Votes
    6 Posts
    451 Views
    Maxwell SchaeferM
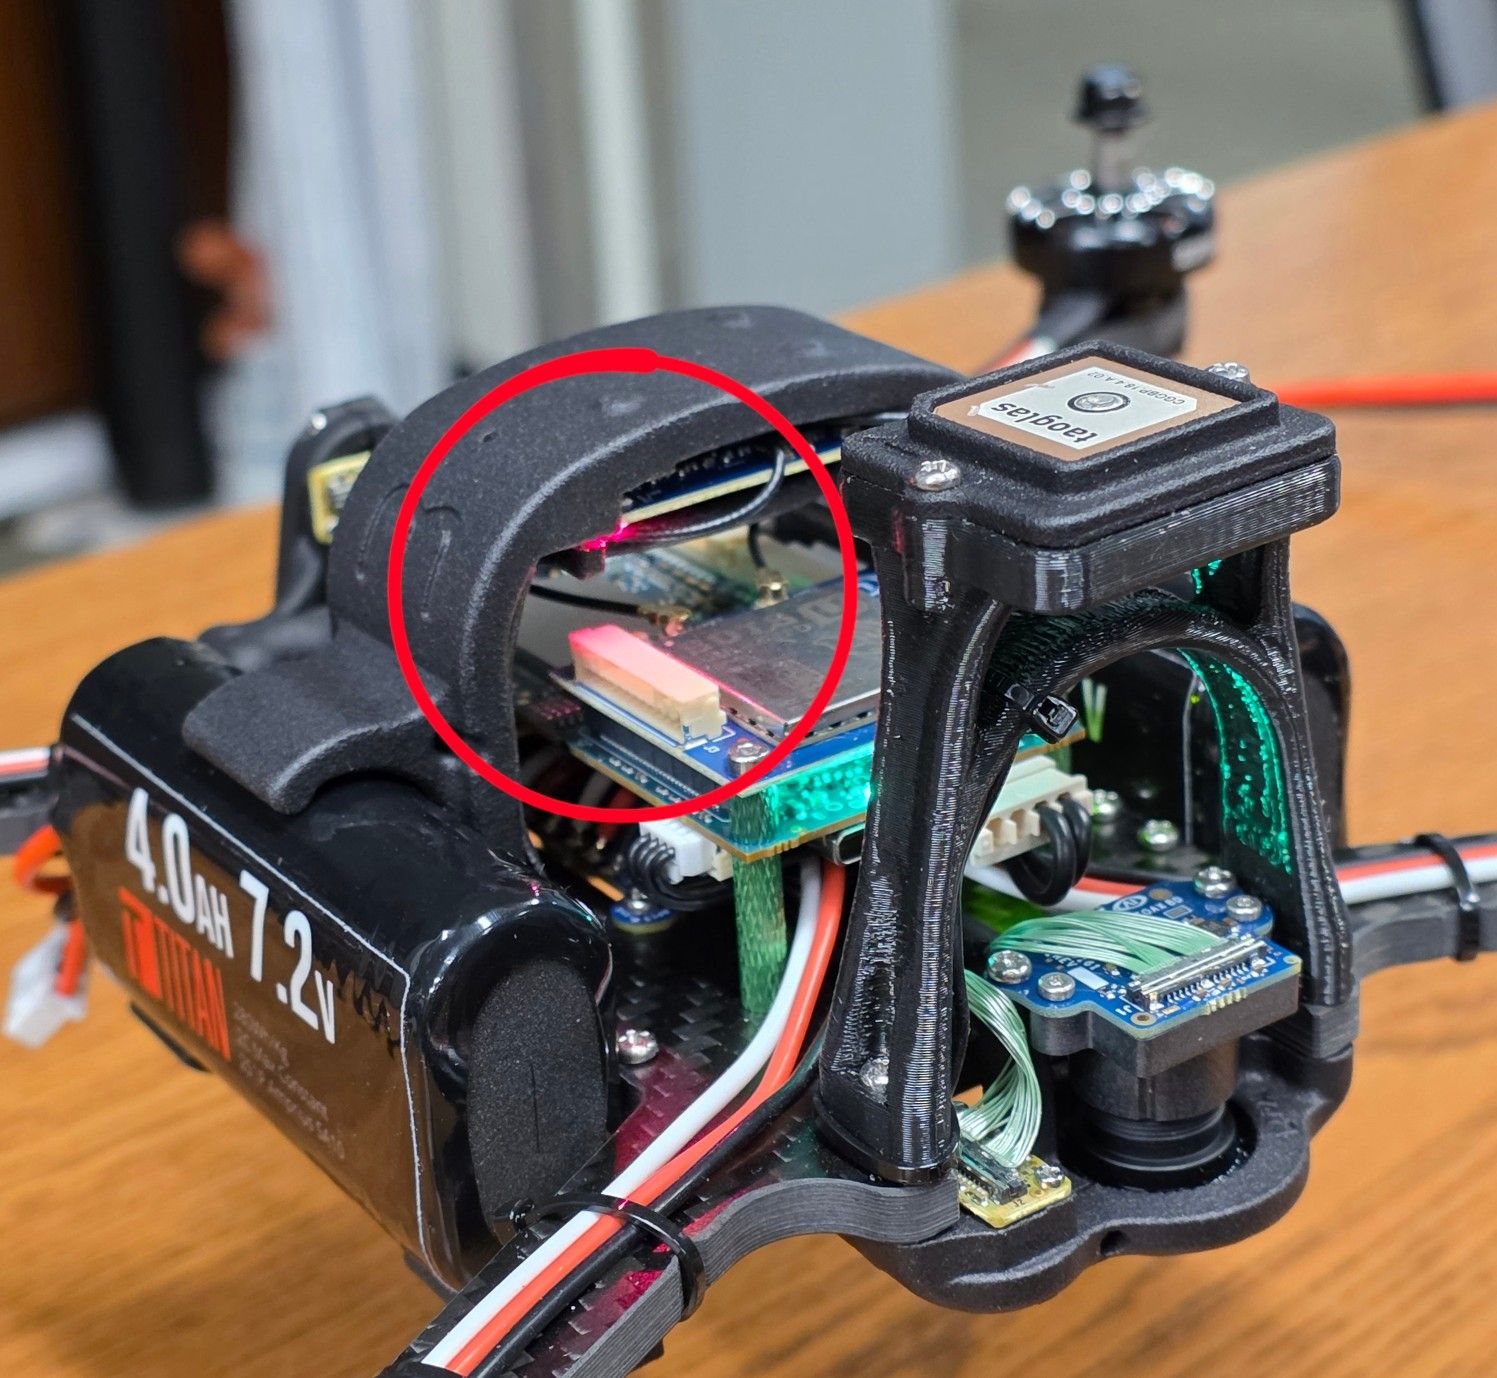
    That red light is for the M0184 ELRS receiver. A constant slow blink from the light means it is disconnected. It will turn solid with a connection. Other LED states are documented here.
  • GPS performance noted on the sales page

    Unsolved
    1
    0 Votes
    1 Posts
    99 Views
    No one has replied
  • Starling 2 VOXL 2 - Suspect 5V bus power margin shortage

    Unsolved
    3
    0 Votes
    3 Posts
    249 Views
    VinnyV
    Hi @electroAJ, thanks for the detailed writeup and follow-up SKU info. From a hardware standpoint, the 200mV droop you are observing on VDC_5V_LOCAL and VDC_5V_LOCAL_USB1 during ToF activity is not a concern at the rail level. That kind of transient is most likely localized contact/pin loss at the connector interface rather than a bulk supply issue. On a 5V rail, 200mV is well within normal operating margin. The eFuse on that rail does not assert until approximately 4.4V, so a 200mV droop from 5V puts you nowhere near that threshold. Downstream logic is regulated from a 3.8V VBAT rail that has demonstrated margin well above the minimum needed, and that rail is permitted to droop past 3.3V before any real issue occurs. The ToF-induced droop is not your RC dropout culprit. Additionally, the M0129 VOXL Mini ESC power stage has been proven to the same load capability and test rigor as our standalone M0041 power module, using the same parts, so the supply itself is not a suspect to me. Would hate to see you chase a red herring. The I2C errors and UART dropout sequencing are worth looking at together as they may share a common upstream cause. Beyond that, this one is likely better handled by our software team who can dig into the dmesg and service state in more detail. I will flag this thread for them.
  • Starling 2 - RC link dropout debug assistance

    Unsolved
    4
    0 Votes
    4 Posts
    283 Views
    E
    @Ben-Linne I'm likely able to perform those updates. A fix is good, but root cause understanding of the issue is better at this point, so I will try updates once all other debug opportunities are spent if I can't reach a deterministic resolution. receiver antenna [...] understood and checked out. I've confirmed the umcc(u.fl) connection is fully seated and no damage is present anywhere. If the transmitter is showing signal but the drone is not responding it's possible you are bound to another transmitter. this is a state I will confirm. So far though, I believe the failure mode is observable with no other transmitters powered, but i will confirm. Thanks.
  • Starling 2 - Mag Alignment

    Unsolved
    4
    0 Votes
    4 Posts
    243 Views
    Eric KatzfeyE
    That'a a calibration parameter that is set automatically by the mag calibration procedure. Normally it should properly detect the orientation / rotation and set it. I'm not sure why that wasn't happening for you when you calibrated the mag.
  • M0213 Wifi board pinout and availability

    Unsolved
    15
    0 Votes
    15 Posts
    5k Views
    Muqing CaoM
    @Vinny we recently experienced wifi disconnection issue with the m0213 board. During flight the wifi just completely disconnected with does not regain connectivity. It seems that the wifi chipset stopped working. We had to do a complete power cycle to regain connectivity. It happened several times during our test. Could you suggest how to resolve this issue? Or is there a way to do soft-reset of the board if we detect wifi connectivity loss?
  • voxl2 mini flashing

    Unsolved
    1
    0 Votes
    1 Posts
    117 Views
    No one has replied
  • Doodle Labs For Voxl 2

    Unsolved
    4
    0 Votes
    4 Posts
    2k Views
    M
    @emarcphera Thanks for the info! What antennas do you use for your setup if you don't mind me asking?
  • Longer Camera cables between M0173 and M0166 / M0161

    Unsolved
    1
    0 Votes
    1 Posts
    117 Views
    No one has replied
  • PX4 Beta Sofware

    Unsolved
    6
    0 Votes
    6 Posts
    399 Views
    Eric KatzfeyE
    Yes, the beta release is fine. It was beta only for some features that are not used on our development drones. Otherwise it was a stable release.
  • Lost the original Zorro Blue model

    Unsolved
    2
    0 Votes
    2 Posts
    190 Views
    Maxwell SchaeferM
    @Omri-Eival The Zorro Blue User Manual should answer most of your questions, with a shell script to copy all of the latest data to a handset in the provided zip file. While you are there, if your firmware is out of date it may be worth going through the update process.
  • Re: [voxl2 is not booting](/topic/4984/voxl2-is-not-booting)

    Solved
    3
    0 Votes
    3 Posts
    235 Views
    tomT
    @Jetson-Nano Given the crash and hardware issues I'd recommend sending this board in for an RMA
  • Queries regarding voxl 2 mini, ESC, flight core v2 and Camera break out board

    Unsolved
    2
    0 Votes
    2 Posts
    534 Views
    Jetson NanoJ
    @ModalAI-Team Help me out here . I want to purchase some new components, but with out having a clear idea on the architecture I won't be able to do it. Please guide me here.
  • 0 Votes
    1 Posts
    108 Views
    No one has replied