Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • VIO flying configuration

    Unsolved m500
    2
    0 Votes
    2 Posts
    615 Views
    ?
    Hi, It looks like the data on that documentation page was erroneously copied over from a different platform, I'll update it shortly but in the future for QVIO needs this docs page is more actively maintained by the software team. For reference the commands in the voxl sdk for doing the things you asked about are voxl-inspect-qvio and voxl-configure-qvio. These are the standard formats for the commands in our SDK, so you can tab out voxl-inspect- or voxl-configure- to see all of the other things you can inspect or configure.
  • Issues with Docker, and WiFi connection

    Unsolved m500
    10
    1
    0 Votes
    10 Posts
    2k Views
    Steve SagerS
    @Cristian-Adam The aircraft (M500) still does not connect to the WiFi at my office. Modal Devs and I are assuming my problem is related to the firewall settings IT set up at my work. Although I type the command correctly and the aircraft finds the wifi, it cannot connect and fails.
  • M500 will not connect to QGC, but still has shh connection

    Unsolved m500
    23
    1
    0 Votes
    23 Posts
    6k Views
    Steve SagerS
    @tom Yeah I am on 0.9 platform release
  • One FrSky request, LTE question..

    Unsolved seeker
    7
    0 Votes
    7 Posts
    1k Views
    B
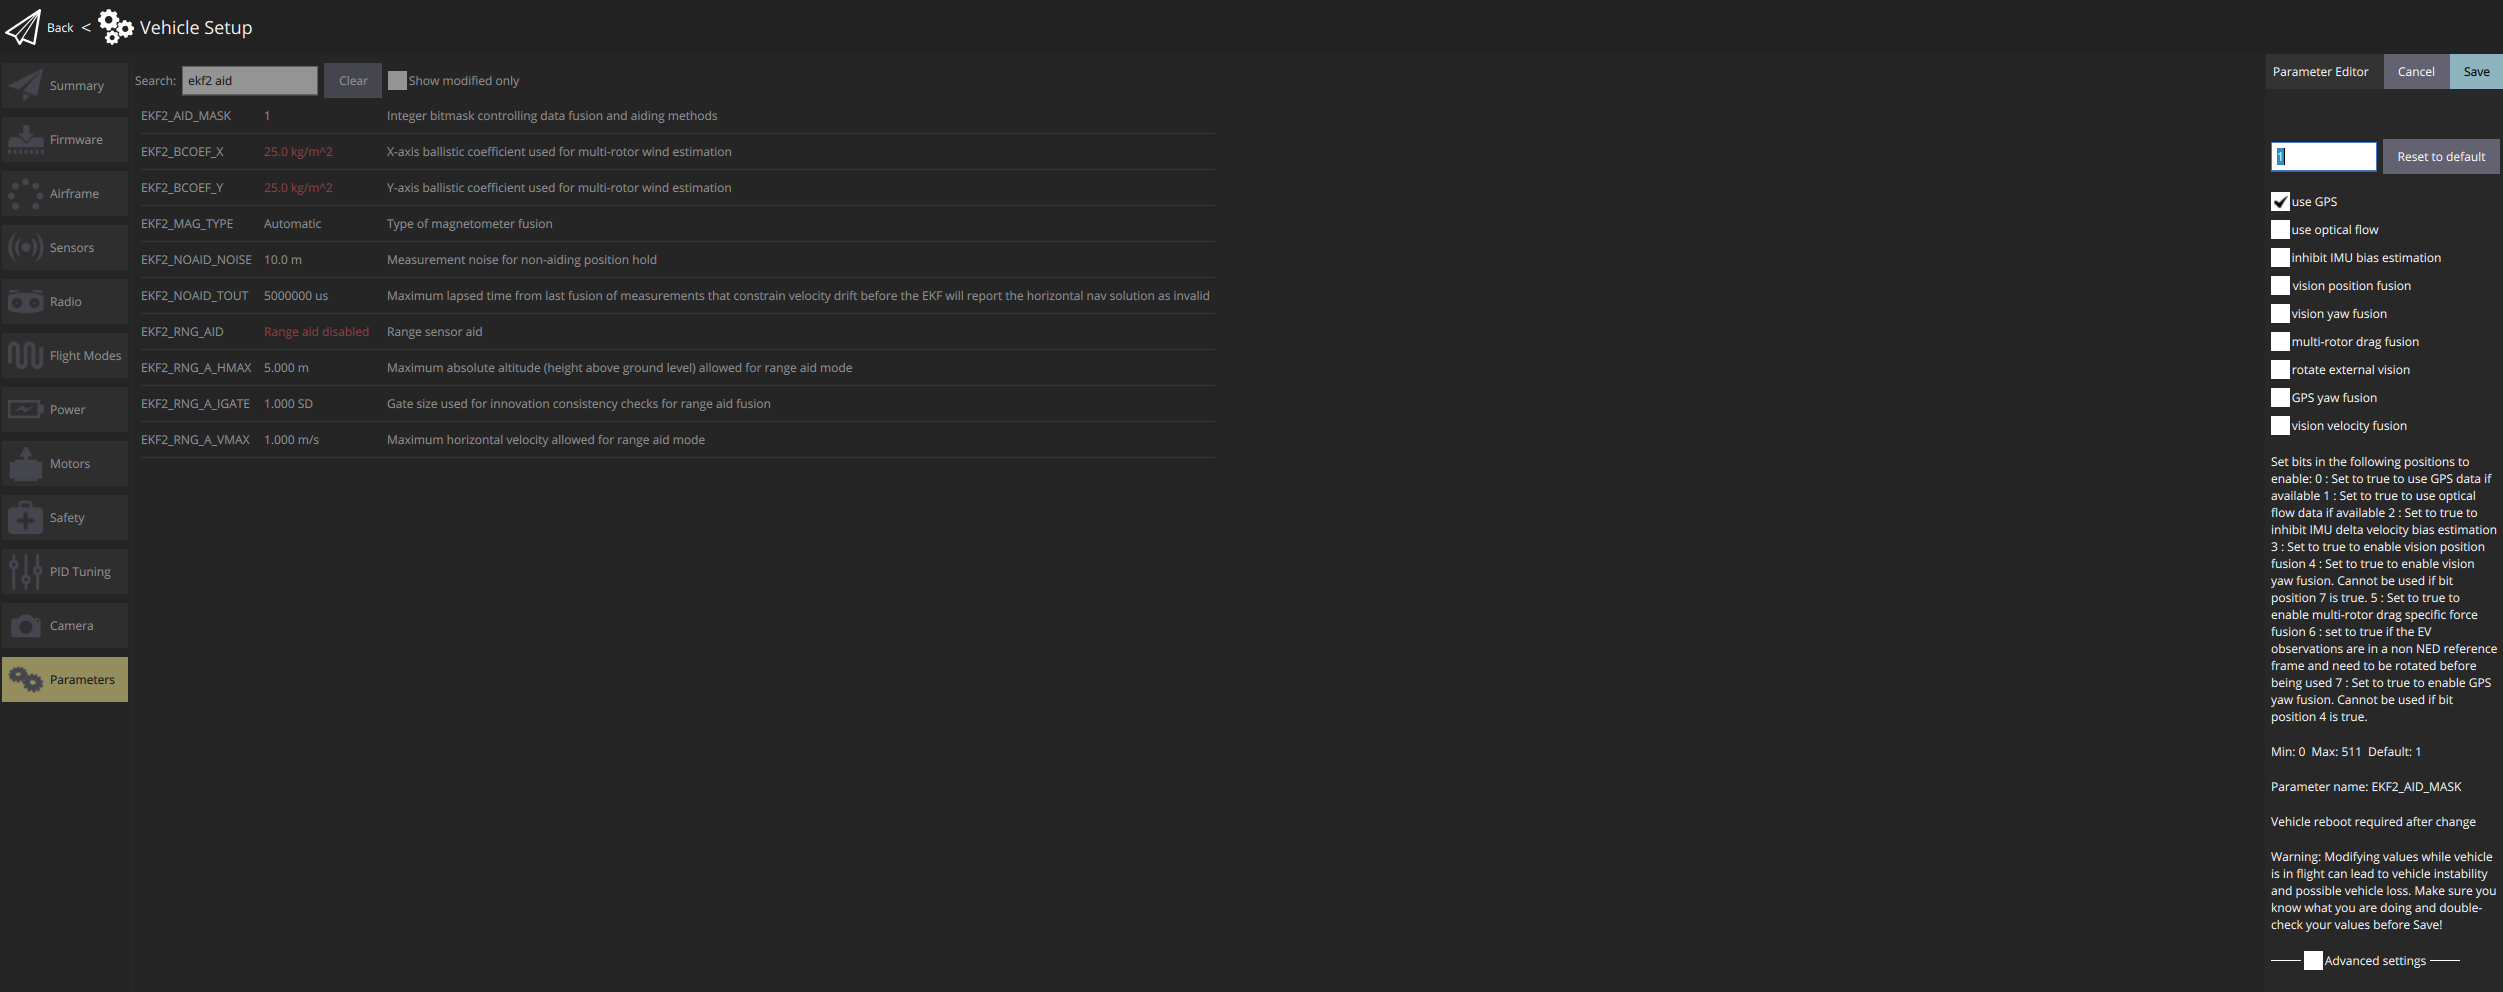
    Vinny! You're the man! Good news but a little backround first. I've been building drones for a long time, but I come from the "Other side" using a windows box to configure APMs then Pixhawks with Arducopter using Mission Planner. When I got this thing, I literally built an Ubuntu workstation just to talk to it. I'm an old guy that used to live on the DOS commandl line, but I really have to hone my Linux skills (almost nonexistent..) for this project. Outside of the Arduino IDE and some ancient BASIC, I'm no coder, but I understand microcontrollers, serial, I2C, CAN etc pretty well because I come from an industrial automation background. (Amazon Fulfillment Center Controls lead configuring Cognex and Sick every day..) I figured out the serial ports. (I was using the freaking asterisk in the QGC parameter search box like a typical DOS jockey!) I found that in the 1.11.3 firmware the serial parameters are bit masks and numeric with no real reference for me, but in the latest PX4 release they have a dropdown and real names and values, so I loaded it, changed TELEM1 to 921k and Mavlink mode 2 (offboard), saved the params, then loaded your 1.11.3 custom version back up and restored the params. Done deal. Now I just need the level shifters I ordered today and I can try it out. BTW I also ordered two connector kits, one with a pile of GH 1.25's and the other with a pile of DF13's. I've been meaning to get them for a while cause' I have a huge collection of parts that just don't quite match up and also because I wear my super-re-pinner badge proudly! I'll let you guys know how the level shifters work. I ordered two types, one with multiple mosfets and one with the TXS0108E chip so I can see what works best when it goes back together. Thanks for your prompt and helpful reply!
  • Landing Gear Stud Size, and Motor Temperature

    Unsolved m500
    4
    0 Votes
    4 Posts
    1k Views
    Steve SagerS
    Our team would greatly appreciate feedback about the motor over heating issue. Both our aircraft (two M500 platforms) have this issue. The high temperature has caused a failure and we are requesting guidance on understanding why the aircraft has this heating issue. Would a calibration of the system help fix an issue like this?
  • m500 motor replacement

    Unsolved m500
    7
    0 Votes
    7 Posts
    2k Views
    Juan de Dios Oseas Gutiérrez OrtizJ
    @yu-zhang Hi! I got quite confuse with this topic but, I would like to know. Did it work using the new Holybro motors with 920kv? I guess all the answers from Adrian were to get to make them work. I ask because it has been difficult to find the motors I need for the m500. Regards.
  • issue with voxl streamer not reconnecting

    Unsolved rb5
    5
    0 Votes
    5 Posts
    1k Views
    S
    Discussion moved to https://forum.modalai.com/topic/1647/voxl-streamer-does-not-handle-teardown-request-signal-correctly/4
  • Battery options

    Unsolved seeker
    4
    0 Votes
    4 Posts
    663 Views
    S
    Thanks, Adrian! I will look into building two batteries with Sony VTC6 cells.
  • VOXL m500, mpa-to-ros not publishing tflite-data topic

    Unsolved m500
    4
    0 Votes
    4 Posts
    927 Views
    ?
    This functionality was added to voxl-mpa-to-ros in v0.2.2 and it seems you have some very old software on this drone. I recommend upgrading to the latest sdk by downloading and flashing the VOXL Platform 0.9 release from https://developer.modalai.com/
  • Docker MAVSDK cannot find camera

    Unsolved m500
    14
    1
    0 Votes
    14 Posts
    3k Views
    tomT
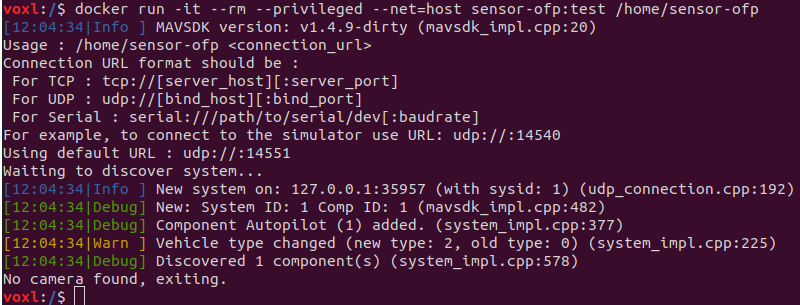
    https://docs.modalai.com/voxl-logger/ I would try out the "-k" option
  • Qualcomm RB5 Drone cant be turned on

    Unsolved rb5
    4
    0 Votes
    4 Posts
    911 Views
    VinnyV
    Hi @Alejandro-M It's highly likely the ESC or Power Module board was irreversibly damaged from this configuration (normal lab wall power supplies cannot power a drone without near certainty of failure). If there is a short on the +5V_DCIN to GND, you can easily observe that, but the other failure mode could be an open circuit which will not show up on a DMM easily. Your best course of action may be an RMA with us so we can explore the drone and find the failure(s) and offer you replacement options to get this platform back up and running. https://www.modalai.com/pages/rma
  • Factory Calibration/ Param file

    Unsolved sentinel
    5
    0 Votes
    5 Posts
    1k Views
    tomT
    @McMason That is how we usually calibrate our sensors, you should have no issue doing so. I will send your camera calibration files to the email you have registered with the forum.
  • Overheating Issues with the Seeker - Looking for Guidance

    Unsolved seeker
    5
    0 Votes
    5 Posts
    1k Views
    M
    @Chad-Sweet Thanks; any comment on what temperatures you or the team have seen trying to stream higher than vga resolution through voxl-streamer? Interested if you are seeing the same using 1080p or the full resolution of the sensor, for example.
  • Sentinel/Graupner gr-16/ Voxl2 IO

    Unsolved sentinel
    4
    0 Votes
    4 Posts
    1k Views
    M
    Thank you @Chad-Sweet. Have you seen any issues with connecting a graupner receiver output to pin11(uart rx) on J19? Just looking for RC input without taking up more space with the IO board, and due to specifics we cant use certain radios. I cant find too much data on if the receiver has an inverted signal like the FrSky does.
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    2 Views
    No one has replied
  • RB5 not detected by QGroundControl

    Unsolved rb5
    14
    2
    0 Votes
    14 Posts
    3k Views
    alfa budimanA
    @Alejandro-M I documented the steps I took to get my RB5 drone from out of the box to flying programmatically with MAVROS. It includes intermediate steps such as wifi and QGround control setup. https://github.com/albud187/uav_nav_ops/blob/manual/RB5_Drone_Setup.docx
  • Drone IP Address keeps changing

    Unsolved rb5
    7
    0 Votes
    7 Posts
    2k Views
    alfa budimanA
    I setup wifi connectivity on the RB5 drone by executing voxl-wifi station ssid password It automatically connects to any network with that matching ssid and password, whether it is a hotspot setup by my cellphone or setup by my personal laptop, regardless of their IP address. This is the functionality that I want. If the IP address of the drone changes because it is connected on a different network, that is fine. The issue is the drone IP address changing even though it is re-connecting on the same network after being turned off and turned back on. @tom said in Drone IP Address keeps changing: @alfa-budiman The ROUTE_IP and LOCAL_IP depend on the format of the IP addresses on the WiFi network you are attempting to connect to. I would connect to your WiFi network and check the IP address given to your drone by the network. If it gives you an IP address in the format 192.168.X.Y you'll want to set the ROUTER_IP to 192.168.X.1 then set LOCAL_IP to whatever IP you want to request from the router, it will need to be in the format 192.168.X.Z where Z is the number you want to request. My concern with entering these IP addresses is that it would then cause the cause drone to search for a specific IP address or else it will not connect. I documented the steps I took to setup my drone here: https://github.com/albud187/uav_nav_ops/blob/manual/RB5_Drone_Setup.docx
  • Why does QRB5 switch from Position mode to Hold mode?

    Unsolved rb5
    2
    1
    0 Votes
    2 Posts
    790 Views
    K
    Actually, I realized that the Hold mode can be switched back to Position mode once I move sticks more than 30%. However, the switching from Position to Hold mode was too fast (i.e., within 1 second), so whatever changes during that time was discarded and after moving 30% of sticks in order to switch from Hold to Position, the Altitude is either too high or too low for the next move. Do you know which parameters postpone the process of switching from Position to Hold mode? Thank you.
  • Voxl stuck in waiting after unbricking

    Unsolved voxl m500
    12
    0 Votes
    12 Posts
    4k Views
    wilkinsafW
    Wanted to update this by saying I experienced same issue, but I resolved this by disconnecting tracking camera that had been installed upside down. So, if anyone is reading this in the future....try disconnecting your cameras attached to the board
  • Issue controlling the RB5

    Unsolved rb5
    9
    0 Votes
    9 Posts
    2k Views
    S
    Yes, things are working fine now. Thanks for the support.@RichieRich