Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • Manual Flight Mode to match Position Flight Mode

    Unsolved seeker
    1
    0 Votes
    1 Posts
    770 Views
    No one has replied
  • Unable to connect to QGroundControl

    Unsolved sentinel
    5
    0 Votes
    5 Posts
    1k Views
    A EvansA
    @modaltb Thanks for this, managed to just reinstall a few packaged from there, bit nervous to go the factory reset, we've had the drone for a while now but we are going to try a first flight soon. seems okay.
  • Technical Questions on RB5

    Unsolved rb5
    6
    0 Votes
    6 Posts
    1k Views
    Eric KatzfeyE
    @adrianpang With regards to ArduPilot, VOXL2 is currently only able to run a version of PX4 on target. If you need ArduPilot you will have to use an external flight controller and connect it to VOXL2 with UART. We hope to have an implementation of ArduPilot that runs directly on VOXL2 in the future but there is no firm date on when this would be available.
  • Basic Qualcomm Flight RB5 5G Drone Development Kit

    Unsolved rb5
    4
    0 Votes
    4 Posts
    772 Views
    Chad SweetC
    @rpaston The Sentinel and QC Flight RB5 are drones for software development - they are a reference so ultimately so you can build your own drones from our components. From your questions, it looks like you are looking for a more complete system. We need a 3-axis gimbal with 4K/8K camera, IR and laser rangefinder for testing. Which gimbal with 4K/8K cameras, IR and laser rangefinders are supported. Any suggestions? No We need precision landing on a moving base station (RTH) in wind. Does the platform have Dynamic RTH? No What is the IPxx rating? None Is the SDK open source? Yes, see https://code.modalai.com (based on Pixhawk/Python) and would it be compatible with Autel, Parrot or Aurelia? The flight controller is PX4 It would not be compatible with Autel, Parrot or Aurelia
  • Voxl-camera-server crash

    Unsolved seeker
    3
    0 Votes
    3 Posts
    1k Views
    Chad SweetC
    If you do reprogram your Seeker, this is the configure script voxl-configure-mpa -p --family seeker
  • 5G testing capabilities

    Unsolved rb5
    2
    0 Votes
    2 Posts
    628 Views
    Eric KatzfeyE
    @JoshRebello This is the 5G module we are using: https://www.modalai.com/collections/modems/products/quectel-rm502q-ae. This also works well with our Sentinel drone which uses our VOXL 2 board instead of the RB5 board and has better capabilities. https://www.modalai.com/pages/sentinel. Even though it doesn't have 5G in it's name it uses the same 5G modem as the RB5 based drone.
  • Issues with Takeoff RB5 full throttle when armed.

    Unsolved rb5
    2
    0 Votes
    2 Posts
    691 Views
    Chad SweetC
    Hi Daniel, can you please clarify "Note: We have recently updated the firmware to VOXL 2 and the default RB5 firmware worked fine."? The VOXL 2 platform image will not work properly on RB5 Flight. You need to use specific RB5 Flight software. The VOXL SDK works on both platforms, but there are low-level differences in the system image and specifically PX4 is configured differently between RB5 Flight and VOXL 2. See this page for how to load the RB5 Flight platform image https://docs.modalai.com/Qualcomm-Flight-RB5-voxl-sdk-upgrade-guide/
  • Snapshot crashes voxl-camera-server

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    770 Views
    modaltbM
    Hi @mkwan , I'm not positive if resolved but there's newer SDK available, any chance you can try to update? voxl2_platform_0.9.tar.gz https://developer.modalai.com/ https://docs.modalai.com/platform-releases/#install I can have someone test this out on 0.9 release next week as well.
  • wwan0 carrier lost

    Unsolved rb5
    4
    0 Votes
    4 Posts
    841 Views
    N
    Hi @tom ! Thank you for your response, the issue was solved by deactivating this service. Thank you so much
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    21 Views
    No one has replied
  • VOXL m500 crash

    Unsolved m500
    5
    0 Votes
    5 Posts
    1k Views
    G
    Hello, This is third time I do this, because the questions I did are a very important issue and my company and I want to solve what happened during the flight. So if you have any answer to the questions I did 27 days ago please respond them. Gonzalo
  • Upside down TOF?

    Unsolved seeker
    3
    0 Votes
    3 Posts
    1k Views
    B
    Hey Adrian, thanks for the reply! Chad also replied this morning affirming the inverted image in the portal is normal. I was afraid to fly it until I could confirm that. On the SIM, like I said in the other post, after inserting the new EIOT SIM I ordered and A: Killing the voxl modem service temporarily then B: booting up and killing the WiFi then running the shell script to configure the modem with the new custom APN for the new sim (which, by the way, is running on the same ATT network as the prepaid ATT phone sim I was trying to use.. it has to be the provisioning on the carrier side that keeps it from working in the modem) thus making the WWAN gateway the default gateway, I can now get a response to any ping I throw at the internet through the wan. I believe the issue with the SIM card socket that makes me have to take things apart to get the sim to actually click into place properly has to do with board "tweakage" or flexing just enough to make the rather delicate sim card locking mechanism bind. You know the board is basically held in position by the two corner silicone grommets and the B2B connector... it doesn't have any kind of screws or standoffs holding it precisely where you want it against the frame. It's just kind of sandwiched in there. if you were to continue to develop the product, I'd look into screwing it down,, Anyway, now that I have a working SIM, all I have to do is keep it active and hopefully never take the Voxl Cam apart again!
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    4 Views
    No one has replied
  • Flight time estimate?

    Unsolved sentinel
    2
    0 Votes
    2 Posts
    792 Views
    tomT
    @tangotoo You can see the specs here: https://docs.modalai.com/sentinel-functional-description/
  • QGC shows me a gps error with my m500 drone and M8N gps

    Unsolved m500
    4
    0 Votes
    4 Posts
    579 Views
    Chad SweetC
    You need to be outdoors, with clear visibility to the sky, to receive GPS
  • Can't find how to configure the hires camera

    Unsolved sentinel
    6
    0 Votes
    6 Posts
    2k Views
    A
    Thank you very much I'll try that
  • reverting back to RB5 SDK and flight image

    Unsolved rb5
    6
    1
    0 Votes
    6 Posts
    1k Views
    tomT
    @Sam-Kiley We don't use the RB5 SDK anymore so haven't had experience with that specific version of quectel-CM is quite some time. We have a lot of customers using 5G via. voxl-modem on the latest VOXL SDK without issues.
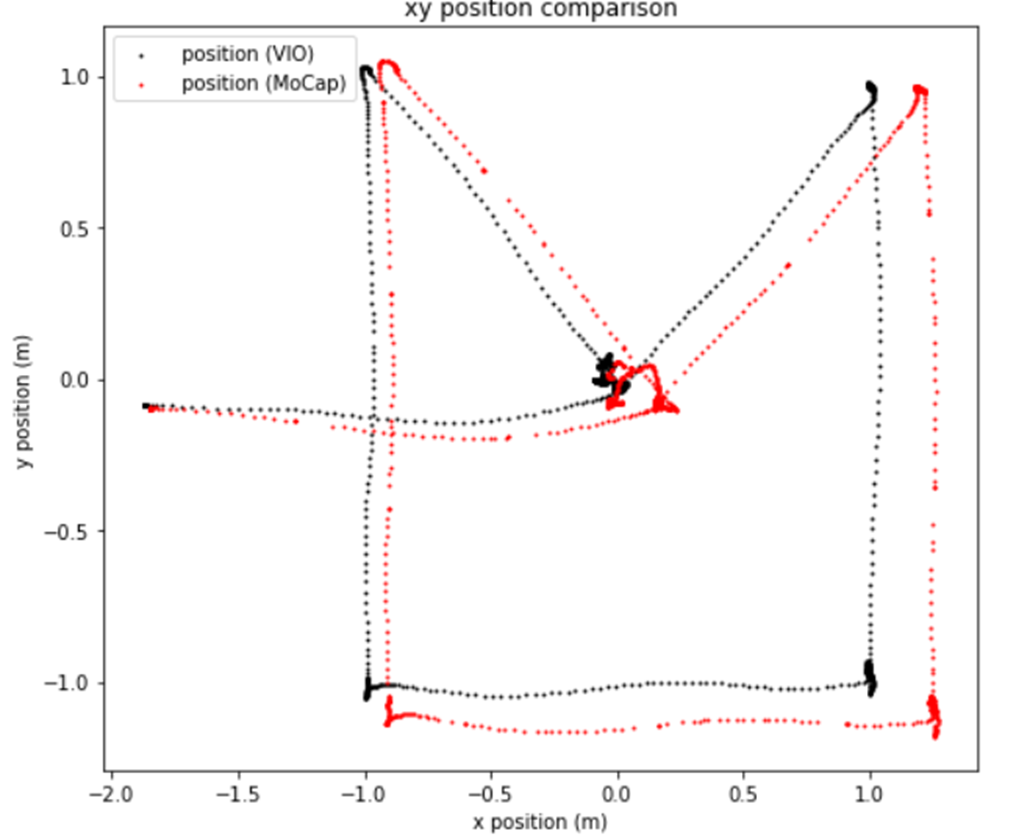
  • Improving VIO accuracy

    Unsolved rb5
    2
    4
    0 Votes
    2 Posts
    784 Views
    ?
    Hi, This is all down to the VIO algorithm. You'd be able to make major tweaks if you're postprocessing the data after, like detecting a reset and continuing from the last valid position (we do this in vvpx4), but changing the px4 params or other fusion techniques that only use the same sensors as the initial vio algorithm will likely not yield any improvements. As for improving the vio algorithm itself, the QVIO's mvVISLAM package is proprietary code(even to us, we don't have the source) that we usually quote at 2% error over distance, which seems to match the test you've run here (you've flown a bit under 10 meters and it looks like you've drifted ~0.15-0.2 meters. We've been working on and experimenting with other algorithms internally, but don't have a hard date on when these will be fully tested/published. It's worth mentioning that most of our experimentation with these is to attempt to open-source our solution and add support for other features (like multiple cameras) but that generally the 2% error is considered very good especially in real-world environments. The 2 main things you can do out of the box to ensure that your VIO is working as best it can are ensuring that it has accurate camera and imu calibrations, and that your extrinsics file is accurate.
  • How to send MAVSDK commands from Raspberry Pi AI to the M500

    Unsolved m500
    2
    0 Votes
    2 Posts
    796 Views
    Chad SweetC
    Please review the External UDP Mavlink Connection documentation
  • voxl-streamer does not handle "teardown-request" signal correctly

    Unsolved rb5
    7
    0 Votes
    7 Posts
    2k Views
    ?
    Everything looks good, gave it a glance and a quick test, it's been merged to our dev and staging branches in v0.4.2 and will be in the next release, thanks!