Skip to content

Development Drones

642 Topics 3.3k Posts

Starling 2, Starling 2 Max, Sentinel, Seeker, m500, RB5, the PX4 Autonomy Developer Kit and Stinger FPV: flying, tuning, repairs and spare parts.

  • ALFA radios failing to communicate in adhoc

    Unsolved starling
    1
    0 Votes
    1 Posts
    281 Views
    No one has replied
  • Cannot perform QDL

    Unsolved rb5
    5
    0 Votes
    5 Posts
    2k Views
    U
    @Vinny Still no luck. Went in to RB5 images UFS folder. Attached power to J4 and then USBc. Launched the command. [image: 1721646892292-img.jpeg] user@desktop:~/2021-07-16-M0052.r9.1.QUP10/ufs$ sudo qdl --debug --storage ufs --include . prog_firehose_ddr.elf rawprogram_unsparse0.xml rawprogram1.xml rawprogram2.xml rawprogram3.xml rawprogram4.xml rawprogram5.xml patch0.xml patch1.xml patch2.xml patch3.xml patch4.xml patch5.xml HELLO version: 0x2 compatible: 0x1 max_len: 1024 mode: 0 READ64 image: 13 offset: 0x0 length: 0x40 READ64 image: 13 offset: 0x40 length: 0x348 READ64 image: 13 offset: 0x1000 length: 0x1000 READ64 image: 13 offset: 0x2000 length: 0xc78 READ64 image: 13 offset: 0x3000 length: 0x1000 READ64 image: 13 offset: 0x4000 length: 0x1000 READ64 image: 13 offset: 0x5000 length: 0x1000 READ64 image: 13 offset: 0x6000 length: 0x1000 READ64 image: 13 offset: 0x7000 length: 0x1000 READ64 image: 13 offset: 0x8000 length: 0x1000 READ64 image: 13 offset: 0x9000 length: 0x1000 READ64 image: 13 offset: 0xa000 length: 0x1000 READ64 image: 13 offset: 0xb000 length: 0x1000 READ64 image: 13 offset: 0xc000 length: 0x1000 READ64 image: 13 offset: 0xd000 length: 0x1000 READ64 image: 13 offset: 0xe000 length: 0x1000 READ64 image: 13 offset: 0xf000 length: 0x1000 READ64 image: 13 offset: 0x10000 length: 0x1000 READ64 image: 13 offset: 0x11000 length: 0x1000 READ64 image: 13 offset: 0x12000 length: 0x1000 READ64 image: 13 offset: 0x13000 length: 0x1000 READ64 image: 13 offset: 0x14000 length: 0x1000 READ64 image: 13 offset: 0x15000 length: 0x1000 READ64 image: 13 offset: 0x16000 length: 0x1000 READ64 image: 13 offset: 0x17000 length: 0x1000 READ64 image: 13 offset: 0x18000 length: 0x1000 READ64 image: 13 offset: 0x19000 length: 0x1000 READ64 image: 13 offset: 0x1a000 length: 0x1000 READ64 image: 13 offset: 0x1b000 length: 0x1000 READ64 image: 13 offset: 0x1c000 length: 0x1000 READ64 image: 13 offset: 0x1d000 length: 0x1000 READ64 image: 13 offset: 0x1e000 length: 0x1000 READ64 image: 13 offset: 0x1f000 length: 0x1000 READ64 image: 13 offset: 0x20000 length: 0x1000 READ64 image: 13 offset: 0x21000 length: 0x1000 READ64 image: 13 offset: 0x22000 length: 0x1000 READ64 image: 13 offset: 0x23000 length: 0x1000 READ64 image: 13 offset: 0x24000 length: 0x1000 READ64 image: 13 offset: 0x25000 length: 0x1000 READ64 image: 13 offset: 0x26000 length: 0x1000 READ64 image: 13 offset: 0x27000 length: 0x1000 READ64 image: 13 offset: 0x28000 length: 0x1000 READ64 image: 13 offset: 0x29000 length: 0x1000 READ64 image: 13 offset: 0x2a000 length: 0x1000 READ64 image: 13 offset: 0x2b000 length: 0x1000 READ64 image: 13 offset: 0x2c000 length: 0x1000 READ64 image: 13 offset: 0x2d000 length: 0x1000 READ64 image: 13 offset: 0x2e000 length: 0x1000 READ64 image: 13 offset: 0x2f000 length: 0x1000 READ64 image: 13 offset: 0x30000 length: 0x1000 READ64 image: 13 offset: 0x31000 length: 0x1000 READ64 image: 13 offset: 0x32000 length: 0x1000 READ64 image: 13 offset: 0x33000 length: 0x1000 READ64 image: 13 offset: 0x34000 length: 0x1000 READ64 image: 13 offset: 0x35000 length: 0x1000 READ64 image: 13 offset: 0x36000 length: 0x1000 READ64 image: 13 offset: 0x37000 length: 0x1000 READ64 image: 13 offset: 0x38000 length: 0x1000 READ64 image: 13 offset: 0x39000 length: 0x1000 READ64 image: 13 offset: 0x3a000 length: 0x1000 READ64 image: 13 offset: 0x3b000 length: 0x1000 READ64 image: 13 offset: 0x3c000 length: 0x1000 READ64 image: 13 offset: 0x3d000 length: 0x1000 READ64 image: 13 offset: 0x3e000 length: 0x1000 READ64 image: 13 offset: 0x3f000 length: 0x1000 READ64 image: 13 offset: 0x40000 length: 0x1000 READ64 image: 13 offset: 0x41000 length: 0x1000 READ64 image: 13 offset: 0x42000 length: 0x1000 READ64 image: 13 offset: 0x43000 length: 0x1000 READ64 image: 13 offset: 0x44000 length: 0x1000 READ64 image: 13 offset: 0x45000 length: 0x1000 READ64 image: 13 offset: 0x46000 length: 0x1000 READ64 image: 13 offset: 0x47000 length: 0x1000 READ64 image: 13 offset: 0x48000 length: 0x1000 READ64 image: 13 offset: 0x49000 length: 0x1000 READ64 image: 13 offset: 0x4a000 length: 0x1000 READ64 image: 13 offset: 0x4b000 length: 0x1000 READ64 image: 13 offset: 0x4c000 length: 0x1000 READ64 image: 13 offset: 0x4d000 length: 0x1000 READ64 image: 13 offset: 0x4e000 length: 0x1000 READ64 image: 13 offset: 0x4f000 length: 0x1000 READ64 image: 13 offset: 0x50000 length: 0x1000 READ64 image: 13 offset: 0x51000 length: 0x1000 READ64 image: 13 offset: 0x52000 length: 0x1000 READ64 image: 13 offset: 0x53000 length: 0x1000 READ64 image: 13 offset: 0x54000 length: 0x1000 READ64 image: 13 offset: 0x55000 length: 0x1000 READ64 image: 13 offset: 0x56000 length: 0x1000 READ64 image: 13 offset: 0x57000 length: 0x1000 READ64 image: 13 offset: 0x58000 length: 0x1000 READ64 image: 13 offset: 0x59000 length: 0x1000 READ64 image: 13 offset: 0x5a000 length: 0x1000 READ64 image: 13 offset: 0x5b000 length: 0x1000 READ64 image: 13 offset: 0x5c000 length: 0x1000 READ64 image: 13 offset: 0x5d000 length: 0x1000 READ64 image: 13 offset: 0x5e000 length: 0x1000 READ64 image: 13 offset: 0x5f000 length: 0x1000 READ64 image: 13 offset: 0x60000 length: 0x1000 READ64 image: 13 offset: 0x61000 length: 0x1000 READ64 image: 13 offset: 0x62000 length: 0x1000 READ64 image: 13 offset: 0x63000 length: 0x1000 READ64 image: 13 offset: 0x64000 length: 0x62c READ64 image: 13 offset: 0x64630 length: 0x1000 READ64 image: 13 offset: 0x65630 length: 0x1000 READ64 image: 13 offset: 0x66630 length: 0x1000 READ64 image: 13 offset: 0x67630 length: 0x1000 READ64 image: 13 offset: 0x68630 length: 0x1000 READ64 image: 13 offset: 0x69630 length: 0x1000 READ64 image: 13 offset: 0x6a630 length: 0x1000 READ64 image: 13 offset: 0x6b630 length: 0x1000 READ64 image: 13 offset: 0x6c630 length: 0x1000 READ64 image: 13 offset: 0x6d630 length: 0x1000 READ64 image: 13 offset: 0x6e630 length: 0x1000 READ64 image: 13 offset: 0x6f630 length: 0x1000 READ64 image: 13 offset: 0x70630 length: 0x550 READ64 image: 13 offset: 0x70b80 length: 0x1000 READ64 image: 13 offset: 0x71b80 length: 0x1000 READ64 image: 13 offset: 0x72b80 length: 0x1000 READ64 image: 13 offset: 0x73b80 length: 0x1000 READ64 image: 13 offset: 0x74b80 length: 0x1000 READ64 image: 13 offset: 0x75b80 length: 0x1000 READ64 image: 13 offset: 0x76b80 length: 0x1000 READ64 image: 13 offset: 0x77b80 length: 0x1000 READ64 image: 13 offset: 0x78b80 length: 0x1000 READ64 image: 13 offset: 0x79b80 length: 0x1000 READ64 image: 13 offset: 0x7ab80 length: 0x1000 READ64 image: 13 offset: 0x7bb80 length: 0x1000 READ64 image: 13 offset: 0x7cb80 length: 0x1000 READ64 image: 13 offset: 0x7db80 length: 0x1000 READ64 image: 13 offset: 0x7eb80 length: 0x1000 READ64 image: 13 offset: 0x7fb80 length: 0x1000 READ64 image: 13 offset: 0x80b80 length: 0xcc READ64 image: 13 offset: 0x80c50 length: 0xac READ64 image: 13 offset: 0x80cfc length: 0x1000 READ64 image: 13 offset: 0x81cfc length: 0x1000 READ64 image: 13 offset: 0x82cfc length: 0x1000 READ64 image: 13 offset: 0x83cfc length: 0x1000 READ64 image: 13 offset: 0x84cfc length: 0x1000 READ64 image: 13 offset: 0x85cfc length: 0x1000 READ64 image: 13 offset: 0x86cfc length: 0x1000 READ64 image: 13 offset: 0x87cfc length: 0x1000 READ64 image: 13 offset: 0x88cfc length: 0x1000 READ64 image: 13 offset: 0x89cfc length: 0x72c READ64 image: 13 offset: 0x8a428 length: 0x1000 READ64 image: 13 offset: 0x8b428 length: 0x1000 READ64 image: 13 offset: 0x8c428 length: 0x1000 READ64 image: 13 offset: 0x8d428 length: 0x1000 READ64 image: 13 offset: 0x8e428 length: 0x1000 READ64 image: 13 offset: 0x8f428 length: 0xbf0 READ64 image: 13 offset: 0x90018 length: 0x1000 READ64 image: 13 offset: 0x91018 length: 0x1000 READ64 image: 13 offset: 0x92018 length: 0x1000 READ64 image: 13 offset: 0x93018 length: 0x1000 READ64 image: 13 offset: 0x94018 length: 0x1000 READ64 image: 13 offset: 0x95018 length: 0xbf0 READ64 image: 13 offset: 0x95c08 length: 0x1000 READ64 image: 13 offset: 0x96c08 length: 0x1000 READ64 image: 13 offset: 0x97c08 length: 0x1000 READ64 image: 13 offset: 0x98c08 length: 0x1000 READ64 image: 13 offset: 0x99c08 length: 0x1000 READ64 image: 13 offset: 0x9ac08 length: 0xbf0 READ64 image: 13 offset: 0x9b7f8 length: 0x1000 READ64 image: 13 offset: 0x9c7f8 length: 0x1000 READ64 image: 13 offset: 0x9d7f8 length: 0x1000 READ64 image: 13 offset: 0x9e7f8 length: 0x1000 READ64 image: 13 offset: 0x9f7f8 length: 0x1000 READ64 image: 13 offset: 0xa07f8 length: 0x1000 READ64 image: 13 offset: 0xa17f8 length: 0x1000 READ64 image: 13 offset: 0xa27f8 length: 0x1000 READ64 image: 13 offset: 0xa37f8 length: 0x1000 READ64 image: 13 offset: 0xa47f8 length: 0x1000 READ64 image: 13 offset: 0xa57f8 length: 0x1000 READ64 image: 13 offset: 0xa67f8 length: 0x1000 READ64 image: 13 offset: 0xa77f8 length: 0x1000 READ64 image: 13 offset: 0xa87f8 length: 0x1000 READ64 image: 13 offset: 0xa97f8 length: 0x1000 READ64 image: 13 offset: 0xaa7f8 length: 0x1000 READ64 image: 13 offset: 0xab7f8 length: 0x1000 READ64 image: 13 offset: 0xac7f8 length: 0x1000 READ64 image: 13 offset: 0xad7f8 length: 0x1000 READ64 image: 13 offset: 0xae7f8 length: 0x1000 READ64 image: 13 offset: 0xaf7f8 length: 0x1000 READ64 image: 13 offset: 0xb07f8 length: 0x1000 END OF IMAGE image: 13 status: 0 DONE status: 1 FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Binary build date: Apr 14 2021 @ 04:09:57" /></data> LOG: INFO: Binary build date: Apr 14 2021 @ 04:09:57 FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Binary build date: Apr 14 2021 @ 04:09:57 " /></data> LOG: INFO: Binary build date: Apr 14 2021 @ 04:09:57 FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Chip serial num: 1469368341 (0x5794c815)" /></data> LOG: INFO: Chip serial num: 1469368341 (0x5794c815) FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Supported Functions (15):" /></data> LOG: INFO: Supported Functions (15): FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: program" /></data> LOG: INFO: program FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: read" /></data> LOG: INFO: read FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: nop" /></data> LOG: INFO: nop FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: patch" /></data> LOG: INFO: patch FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: configure" /></data> LOG: INFO: configure FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: setbootablestoragedrive" /></data> LOG: INFO: setbootablestoragedrive FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: erase" /></data> LOG: INFO: erase FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: power" /></data> LOG: INFO: power FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: firmwarewrite" /></data> LOG: INFO: firmwarewrite FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: getstorageinfo" /></data> LOG: INFO: getstorageinfo FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: benchmark" /></data> LOG: INFO: benchmark FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: emmc" /></data> LOG: INFO: emmc FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: ufs" /></data> LOG: INFO: ufs FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: fixgpt" /></data> LOG: INFO: fixgpt FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: getsha256digest" /></data> LOG: INFO: getsha256digest FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: End of supported functions 15" /></data> LOG: INFO: End of supported functions 15 qdl: firehose operation timed out FIREHOSE WRITE: <?xml version="1.0"?> <data><configure MemoryName="ufs" MaxPayloadSizeToTargetInBytes="1048576" verbose="0" ZLPAwareHost="1" SkipStorageInit="0"/></data> FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Calling handler for configure" /></data> LOG: INFO: Calling handler for configure FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Storage type set to value UFS" /></data> LOG: INFO: Storage type set to value UFS FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <response value="ACK" MemoryName="UFS" MinVersionSupported="1" Version="1" MaxPayloadSizeToTargetInBytes="1048576" MaxPayloadSizeToTargetInBytesSupported="1048576" MaxXMLSizeInBytes="4096" DateTime="Apr 14 2021 - 04:09:57" /></data> [CONFIGURE] max payload size: 1048576 FIREHOSE WRITE: <?xml version="1.0"?> <data><program SECTOR_SIZE_IN_BYTES="4096" num_partition_sectors="32776" physical_partition_number="0" start_sector="3154440" filename="qti-ubuntu-robotics-image-qrb5165-rb5-sysfs_1.ext4"/></data> FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <log value="INFO: Calling handler for program" /></data> LOG: INFO: Calling handler for program FIREHOSE READ: <?xml version="1.0" encoding="UTF-8" ?> <data> <response value="ACK" rawmode="true" /></data> qdl: firehose operation timed out [PROGRAM] failed
  • Voxl Docker Mavsdk Python

    Unsolved m500
    4
    0 Votes
    4 Posts
    1k Views
    tomT
    @Samuel-Bryan To test if it's connected to the internet, try pinging a website like: ping google.com If connected you'll see something like this: ~ ping google.com ok | 09:39:00 AM PING google.com (142.250.217.142) 56(84) bytes of data. 64 bytes from lax31s19-in-f14.1e100.net (142.250.217.142): icmp_seq=1 ttl=56 time=5.12 ms 64 bytes from lax31s19-in-f14.1e100.net (142.250.217.142): icmp_seq=2 ttl=56 time=5.65 ms 64 bytes from lax31s19-in-f14.1e100.net (142.250.217.142): icmp_seq=3 ttl=56 time=5.41 ms 64 bytes from lax31s19-in-f14.1e100.net (142.250.217.142): icmp_seq=4 ttl=56 time=4.83 ms ^C --- google.com ping statistics --- 4 packets transmitted, 4 received, 0% packet loss, time 3005ms rtt min/avg/max/mdev = 4.830/5.253/5.653/0.309 ms ~ See here for info on connecting your VOXL to the internet: https://docs.modalai.com/voxl-wifi-setup/#configuration-and-connection
  • Purchasing Starling 2 Max with 4G

    Unsolved starling
    2
    0 Votes
    2 Posts
    561 Views
    ModeratorM
    @Mihir-Bala An order today should ship in about 4 weeks
  • RB5 can't leave the ground properly when flying in manual flight mode

    Unsolved rb5
    6
    0 Votes
    6 Posts
    2k Views
    V
    @Alex-Kushleyev After running "voxl-configure-px4-params --platform MRB-D0006" to configure RB5 PX4 parameters, I could perform an outdoors flight with RB5 using Position Flight Mode without GPS or motor problems: https://youtu.be/D8zP0hOx8wc It seems that the issue was RB5 running with Sentinel PX4 parameters after SDK upgrade. Thank you for your help
  • Outdoor navigation GPS problem

    Unsolved rb5
    16
    0 Votes
    16 Posts
    5k Views
    V
    @Eric-Katzfey @tom After running "voxl-configure-px4-params --platform MRB-D0006" to configure RB5 PX4 parameters, I could perform an outdoors flight with RB5 using Position Flight Mode without GPS or motor problems: https://youtu.be/D8zP0hOx8wc It seems that the issue was RB5 running with Sentinel PX4 parameters after SDK upgrade. Thank you very much guys for your help
  • Removing WiFi Adapter Hat from Starling

    Unsolved starling
    1
    0 Votes
    1 Posts
    375 Views
    No one has replied
  • Attempt to reduce drift with the help of stereo camera

    Unsolved starling
    7
    0 Votes
    7 Posts
    1k Views
    James StrawsonJ
    @Jetson-Nano If you are using a stereo-pair that are being published together on the same pipe like on a Seeker, M500, or Sentinel, then you should just need to set up the following config files: /etc/modalai/voxl-qvio-server.conf: "cam_name": "stereo", (or stereo_front for sentinel) "lens_cal_path": "/data/modalai/opencv_stereo_intrinsics.yml", (or stereo_front_intrinsics for Sentinel) "cam_extrinsics_name": "stereo_l", (or stereo_front_l for sentinel) "use_second_cam_if_stereo": false, To use the right camera, you can swap "use_second_cam_is_stereo" to true, and qvio will pull in instrinsic lens params from the right camera which is also part of the same intrinsics file. Note that we only have camera locations in the extrinsics files for the left camera, but you can add to /etc/modalai/extrinsics.conf an entry for the right camera if you wish.
  • Enabling Ghost atto RC input in HITL

    Unsolved starling
    3
    0 Votes
    3 Posts
    640 Views
    L
    @tom Perfect! That worked
  • Simulations to Practical Starling 2

    Unsolved starling
    3
    0 Votes
    3 Posts
    1k Views
    Z
    @tom I need to perform the autonomous indoor mission? Can I do it with VOXL 2 if yes How I can do it?
  • Outdoor and night slam performance

    Unsolved starling
    1
    0 Votes
    1 Posts
    478 Views
    No one has replied
  • VOXL 2 Starling

    Unsolved starling
    2
    0 Votes
    2 Posts
    637 Views
    ModeratorM
    @Zarrar The Starling 2 meets all of those specifications. The obstacle avoidance and gps-denied navigation are tuned to indoor environments
  • Starling Sensors still Recommended for New Designs?

    Unsolved starling
    3
    0 Votes
    3 Posts
    712 Views
    T
    @modaltb thanks for the follow up. I'll see if I can secure a starling 2 soon.
  • Cant Connect to Q Ground Control after SDK Update

    Unsolved m500
    3
    0 Votes
    3 Posts
    1k Views
    Samuel BryanS
    @Eric-Katzfey I am using SoftAP mode in Wifi.
  • Huge number of camera frames skipped using voxl-logger

    Unsolved m500
    7
    0 Votes
    7 Posts
    2k Views
    Alex KushleyevA
    @boga , Can you please double check the following: amount of free space in the /data partition: df | grep data check the write speed to the data partition : dd if=/dev/urandom of=/data/test.bin bs=1M count=1024 (this will write a test file of size 1GB). For example, using voxl2 i result i got was (on VOXL1 it will be a bit slower): #set cpu mode to perf voxl-set-cpu-mode perf #perform the write test using randomly generated data (may be limited by speed of /dev/urandom) voxl2:/data$ dd if=/dev/urandom of=/data/test.bin bs=1M count=1024 1024+0 records in 1024+0 records out 1073741824 bytes (1.1 GB, 1.0 GiB) copied, 2.85171 s, 377 MB/s (you can / should remove /data/test.bin after the test to free up the space) Alex
  • Modal M500 Voxl Streamer

    Unsolved m500
    9
    0 Votes
    9 Posts
    2k Views
    Eric KatzfeyE
    @Samuel-Bryan There are some examples here: https://docs.modalai.com/mpa-camera-interface/#sending-commands-back-to-the-server
  • 0 Votes
    3 Posts
    647 Views
    C
    Thanks for the response. Looking forward to the great work.
  • Regarding controlling drone flight using code

    Unsolved starling
    3
    0 Votes
    3 Posts
    653 Views
    C
    @Eric-Katzfey said in Regarding controlling drone flight using code: @cy208183395 I would take a look at the documentation for MAVSDK. It has a python interface available and can do drone control. Thanks for your reply
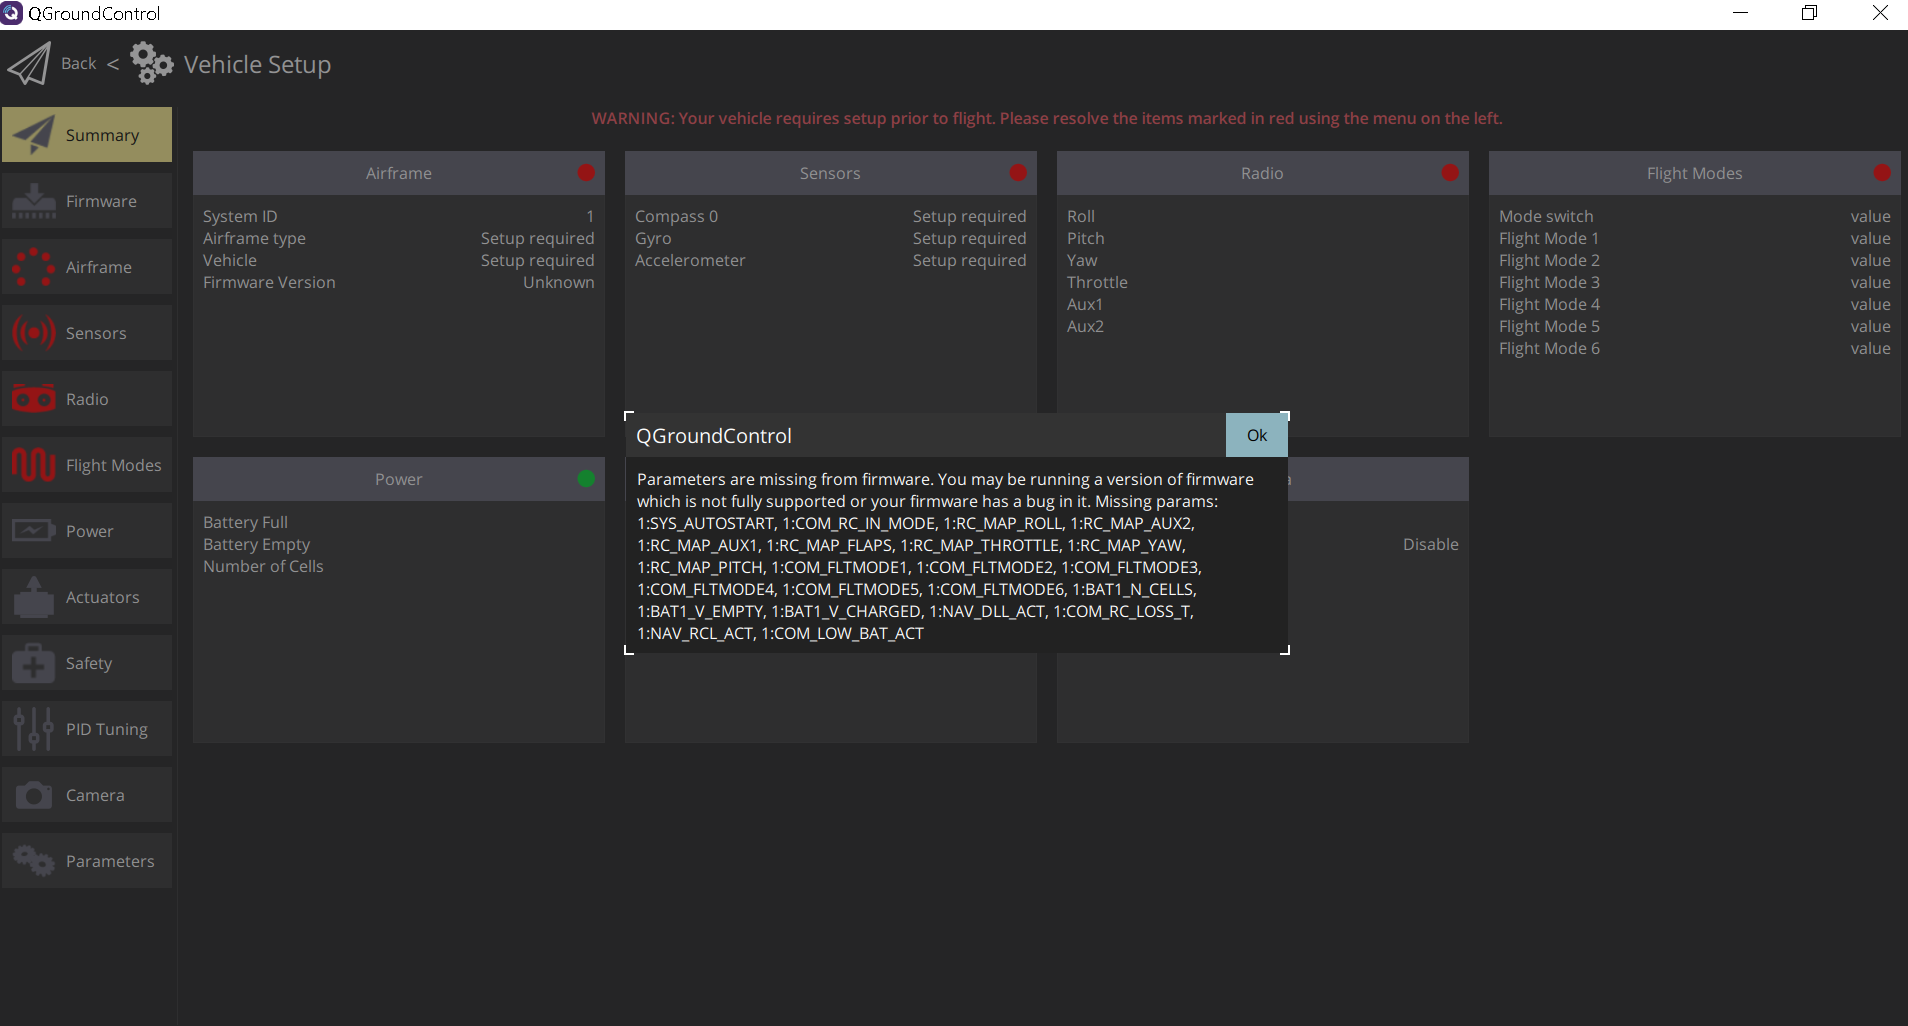
  • Unknown px4 firmware after SDK upgrade

    Unsolved rb5
    7
    3
    0 Votes
    7 Posts
    2k Views
    V
    I created a new topic about the GPS problem https://forum.modalai.com/topic/3612/outdoor-navigation-gps-problem
  • Sentinel Receiver Options

    Unsolved sentinel
    4
    0 Votes
    4 Posts
    954 Views
    modaltbM
    Yes new sentinels ship with M0154s. Let me check with the production team about retroffiting