Skip to content

General Questions

2.2k Topics 11.3k Posts

Not sure where your question goes? Ask here. ModalAI engineers and the community answer questions about any VOXL product.

  • Connecting VOXL to Jetson NX

    Unsolved
    7
    0 Votes
    7 Posts
    2k Views
    PawelJP
    Thanks, I just wanted to check if I was totally off track. I'll let you know how it goes, the potential of over the air adb updates are very tantalizing
  • Where is apriltag relocalization used in control error signal?

    Unsolved
    2
    0 Votes
    2 Posts
    750 Views
    PawelJP
    Where does the april tag localization change the drone position being sent to the pixhawk to affect the error signal of target-position? I will need to use this position so I can correctly offset my path starting point The setpoints are are sent to uart_mavlink.c where they are transformed by geometry_transform_fixed_setpoints_to_local where the april tag transformation matrix is used to convert from fixed to local frame, which is sent off to the pixhawk. If no april tags are used local_frame == fixed_frame Does the px4 expect path in the same reference frame as vio state (ie position in world coordinates, velocities in body frame?) px4 expects setpoints in local frame, but offboard figure eight assumes they are set in fixed frame (see above). Please correct me if I am wrong here. Cheers
  • snav fails to find libsensor_imu.so

    Unsolved
    10
    1
    0 Votes
    10 Posts
    2k Views
    L
    I see! Yes after changing this params I can calibrate the imu now with snav!! Thanks for your help!
  • Clarification on px4 home position in vvpx4

    Unsolved
    1
    0 Votes
    1 Posts
    515 Views
    No one has replied
  • Is it possible to know the thrust of the quadcopter?

    Unsolved
    2
    0 Votes
    2 Posts
    707 Views
    D
    Also, is it possible to log the IMU data of PX4? Will you provide some library functions to implement that?
  • This topic is deleted!

    2
    0 Votes
    2 Posts
    8 Views
  • This topic is deleted!

    1
    0 Votes
    1 Posts
    5 Views
    No one has replied
  • Gimbal commands

    Unsolved
    3
    0 Votes
    3 Posts
    538 Views
    modaltbM
    @Daniel-Ryu , here's a possibility: https://docs.modalai.com/voxl-m500-gimbal-user-guide/#mavsdk-behavior-with-mavlink This gimbal is fairly simple, the stabilization occurs on bootup automatically only.
  • Can't get QGroundControl to connect

    Unsolved
    8
    0 Votes
    8 Posts
    1k Views
    P
    @Alex-Gardner thank you. I'll head down that path with ROS. Any readmes/docs/guidance on how I can extract the telemetry/pose data via UART(J10)? I have the hardware connected, but a bit lost on where to start. Would it be easier if I added the Flight Core to the VOXL to get the telemetry ports J4/J5? Is Flight Core required to allow qGroundControl to connect to VOXL? Thanks.
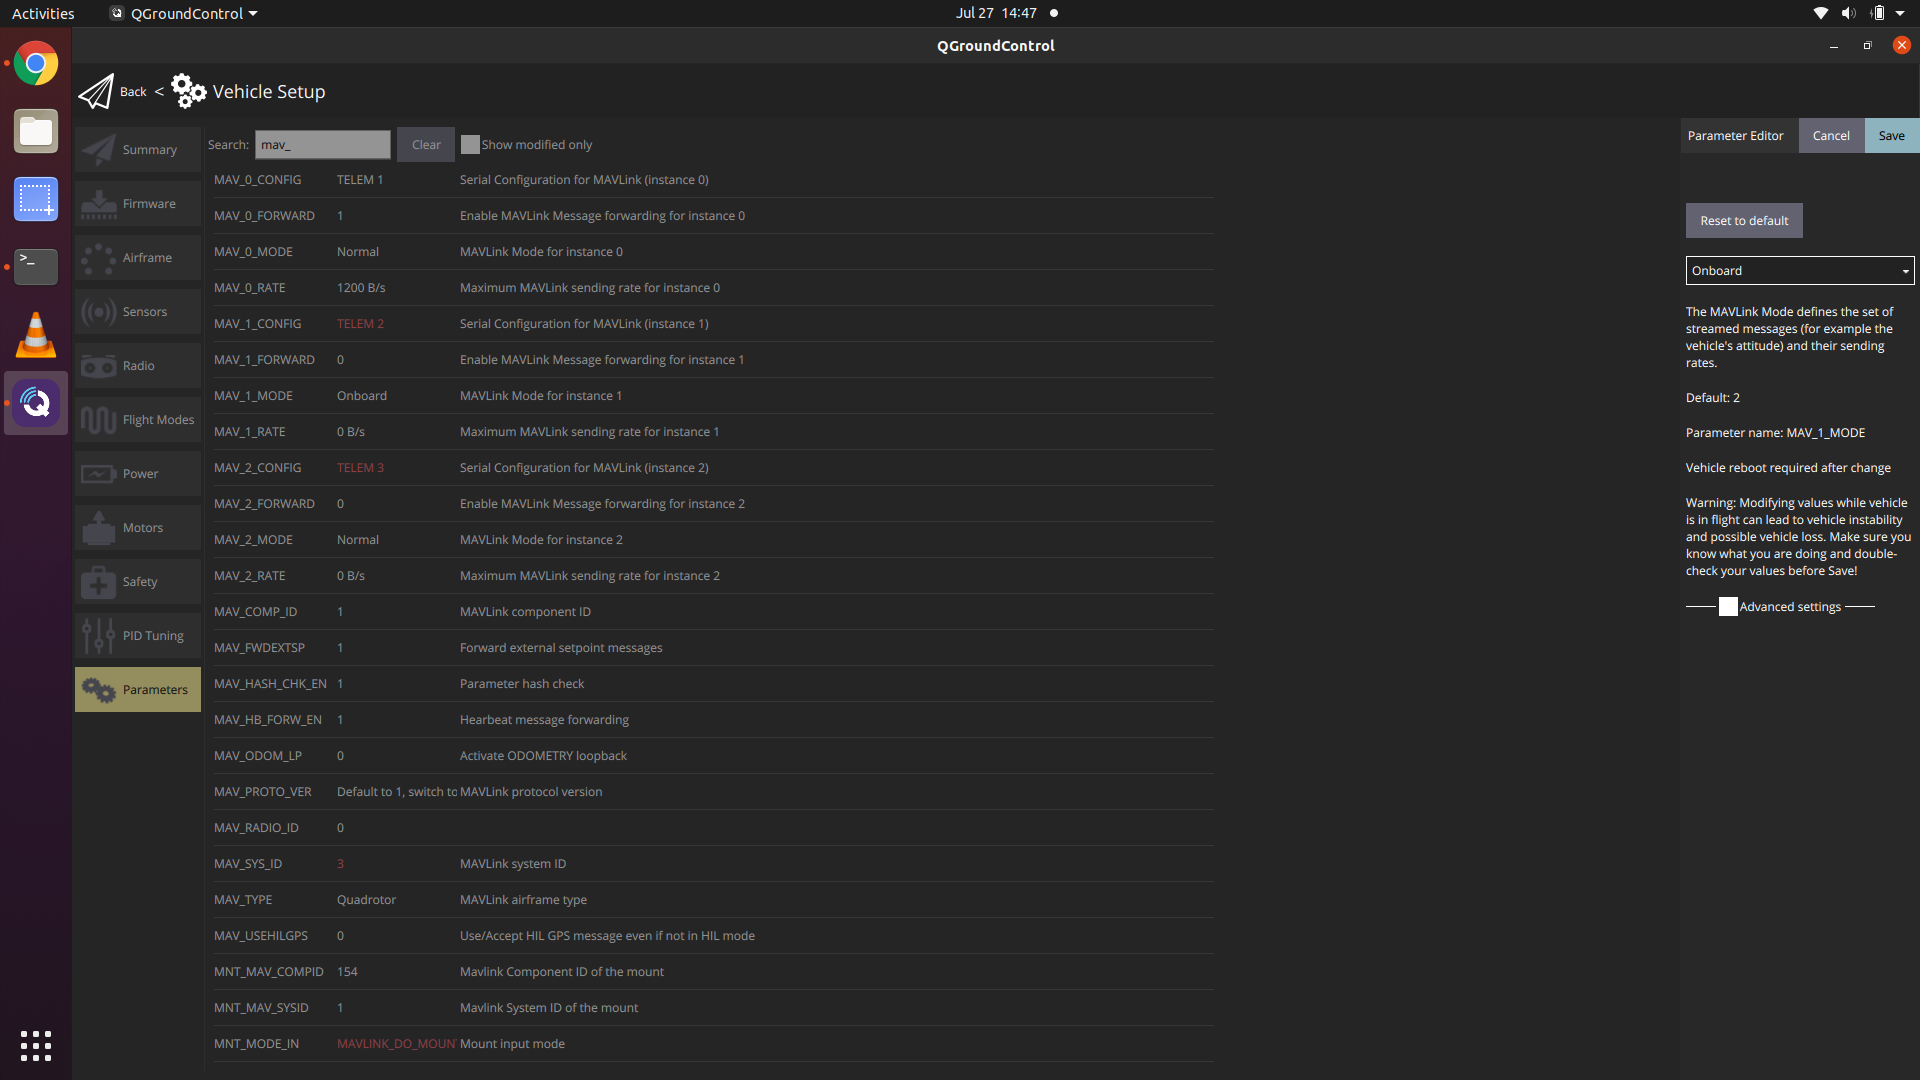
  • MAV_1_MODE not changing from Onboard on QGC

    Unsolved
    2
    1
    0 Votes
    2 Posts
    454 Views
    modaltbM
    If you have an M500, it contains either a VOXL Flight, and there's an internal UART from the PX4 processor (STM32F7) to the Snapdragon processor running linux. This is setup on MAV1, and if changed would halt comms between the two systems. https://github.com/PX4/PX4-Autopilot/blob/master/boards/modalai/fc-v1/init/rc.board_defaults#L23
  • camera client node for voxl-dfs-server or voxl-qvio-server

    Unsolved
    3
    0 Votes
    3 Posts
    729 Views
    S
    Great, Thank you for your reply.
  • NR Support

    Unsolved
    3
    0 Votes
    3 Posts
    539 Views
    M NortonM
    thank you
  • build voxl-qvio-server

    Unsolved
    2
    1
    0 Votes
    2 Posts
    530 Views
    ?
    MV is Qualcomm's Machine Vision library. The source is not public, but the binaries are baked into the voxl system image and the voxl-emulator docker image, so you won't need to do anything special to build/run a custom qvio server.
  • How to move gimbal autonomously

    Unsolved
    2
    0 Votes
    2 Posts
    462 Views
    modaltbM
    Hi @Daniel-Ryu , This isn't something we currently support. The gimbal is primarily for stabilized video, but there's no autonomous control in or stack at this time. Thanks, Travis
  • Issue with running cam calibration

    Unsolved
    4
    0 Votes
    4 Posts
    782 Views
    modaltbM
    Hey @Thomas-MacNamara , I totally hear you... We are reeeeal close to a big docs update...... Should be dropping on the server within days and hopefully we can clear things up. Appreciate the patience and please keep providing feedback as you have issues! -Travis
  • ADB will not find Flight Deck if the tracking camera is connected (J4)

    Unsolved
    20
    0 Votes
    20 Posts
    3k Views
    D
    Sorry for the late response, I've been doing some testing. so I've narrowed it down to the error lying in the stereo cameras, I connected each sensor one at a time, reconfigured, and ran the voxl-streamer and was able to get footage for the hires and tracking, but when it came to the stereo it would not work. When I would reboot the system and inspect the services I would see that the voxl-camera-server is running, but once I tried to voxl-streamer -c stereo it would get stuck at the same place and the voxl-camera-server would stop running. I've confirmed that both of my extension cables are working by testing them with the hires camera. I checked the physcial connections on the stereo cameras and there are no creases in them, they look just as they were folded with the original setup, and I believe that if any of the connections were inverted then the VOXL wouldn't even start up.
  • voxl-rtsp jpeg is all green

    Unsolved
    11
    1
    0 Votes
    11 Posts
    1k Views
    Alex KushleyevA
    The tracking camera (OV7251) is a grayscale camera, so it cannot sense color.
  • Flight Deck USB not connecting to QGroundControl

    Unsolved
    20
    0 Votes
    20 Posts
    4k Views
    tomT
    @DillonAllen Without WiFi, the only way you'll be able to debug VOXL related things is via. ADB so I would follow this guide: https://docs.modalai.com/setup-adb/ in order to setup ADB on your host computer.
  • max MIPI cable extension length

    Unsolved
    4
    0 Votes
    4 Posts
    957 Views
    Alex KushleyevA
    Like Chad said, this depends on many factors. I just wanted to add a bit more details. TOF is not pushing nearly as much data as, say, 4K30 camera, so it is using CSI speeds vs 4K camera. There is a chance it may work with double extender. You should try it! Regarding Raspberry pi (and corresponding discussions), I have personally tried a few of those cables and found that some long cables (~50cm) with raspberry pi and pi camera and saw that long cables result in pixel noise in the image. But it looks kind of strange, since the raspberry pi ISP tries to de-noise the noise and image ends up being kind of noisy and more blurry at the same time and the colors are off. I don't remember exactly what the picture looks like, but the failure mode of long cables may not always be "no image" (no image in the worst case). On VOXL, I have seen some bad cables (occasionally) and I was seeing frame sync issues (image rolling up/down) or sometimes no image at all. I don't think you can damage the camera or VOXL by using too long of a cable, but at some length you will get corruptions and that length depends on the camera and its operating mode. Alex
  • Does the VPN reduces internet speed on drone

    Unsolved
    2
    0 Votes
    2 Posts
    598 Views
    modaltbM
    Although we aren't VPN experts (yet), this is something I've seen myself. There are parameters that can be configured by VPN server/clients that may affect bandwidth (e.g. MTU). There are various types of client/servers out there so it varies how these could be setup. Also, depending on where the VPN server is located, you might be going to a server far away, and depending on the VPN server quality, they may or may be sharing resources with you.